top of page
Robotic Cable-Winding System
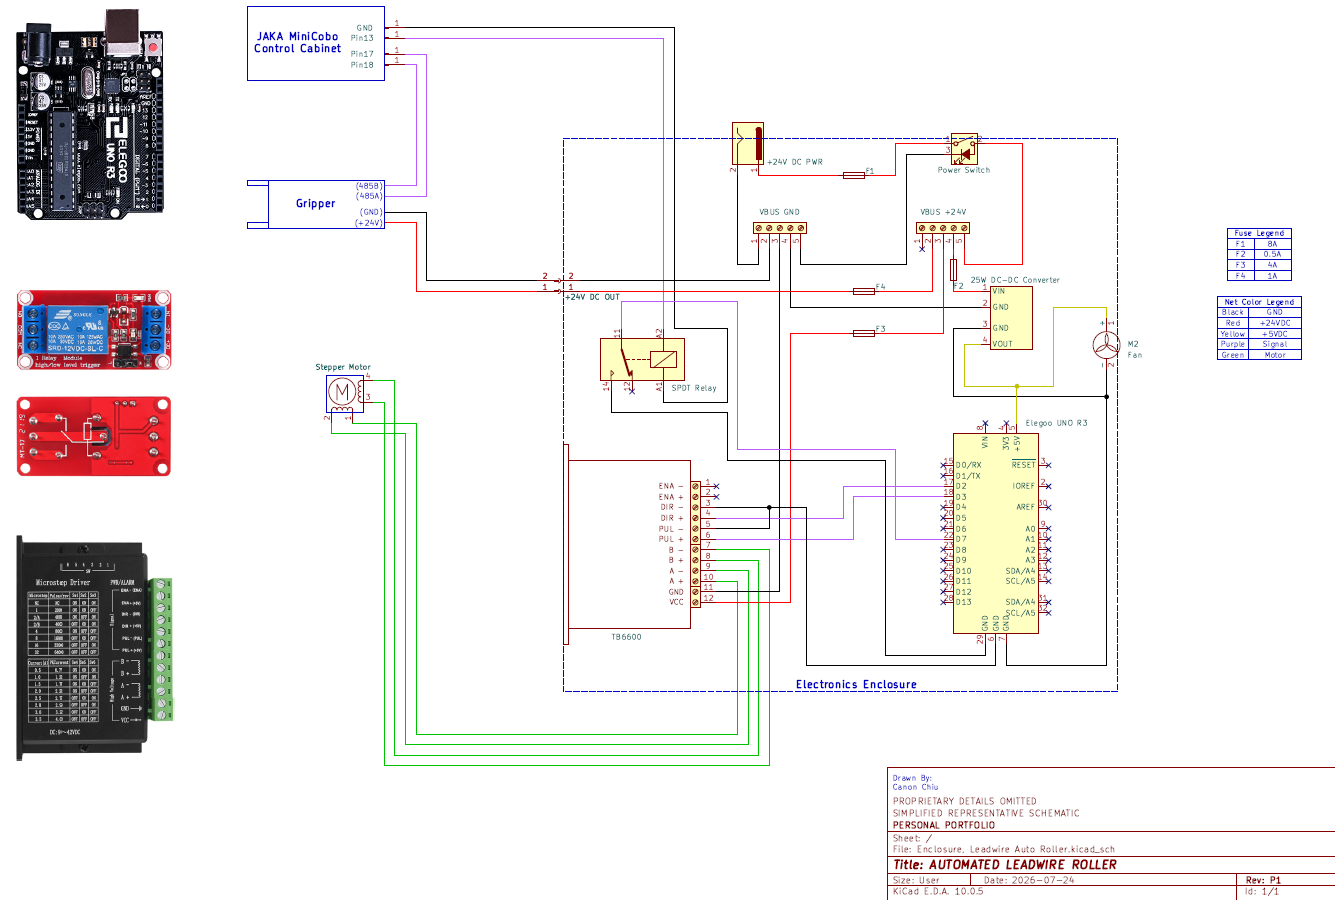
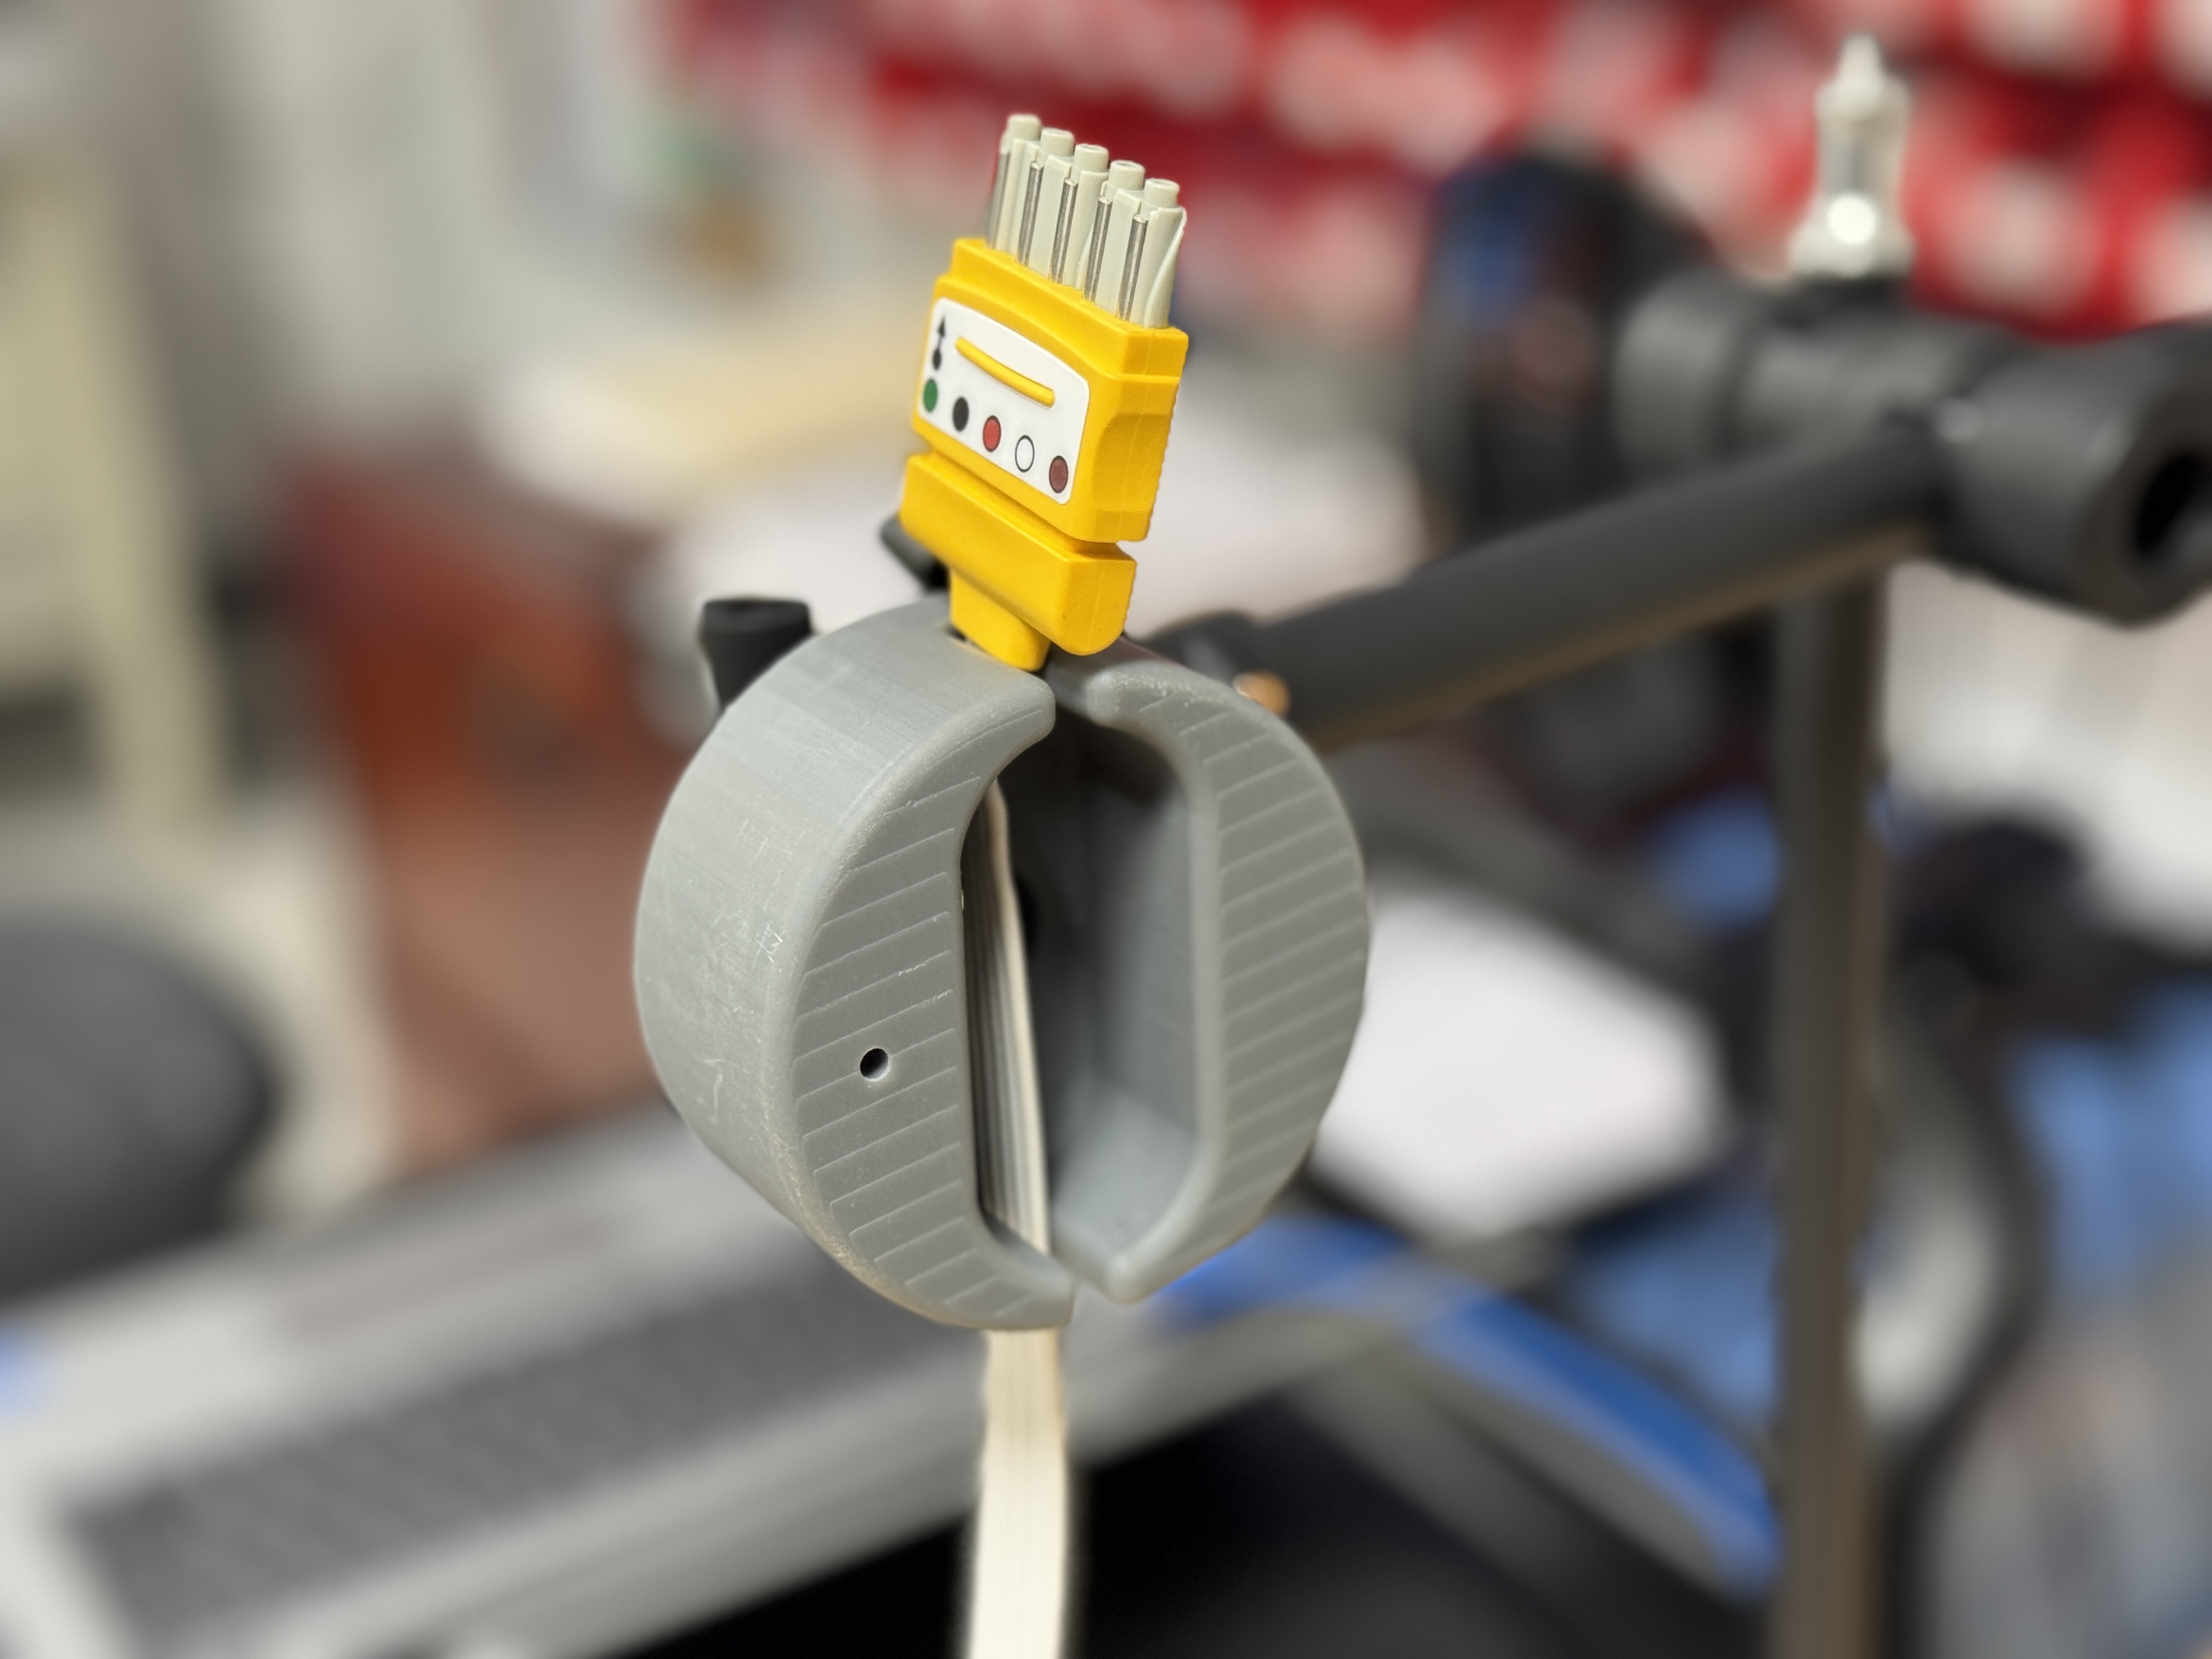
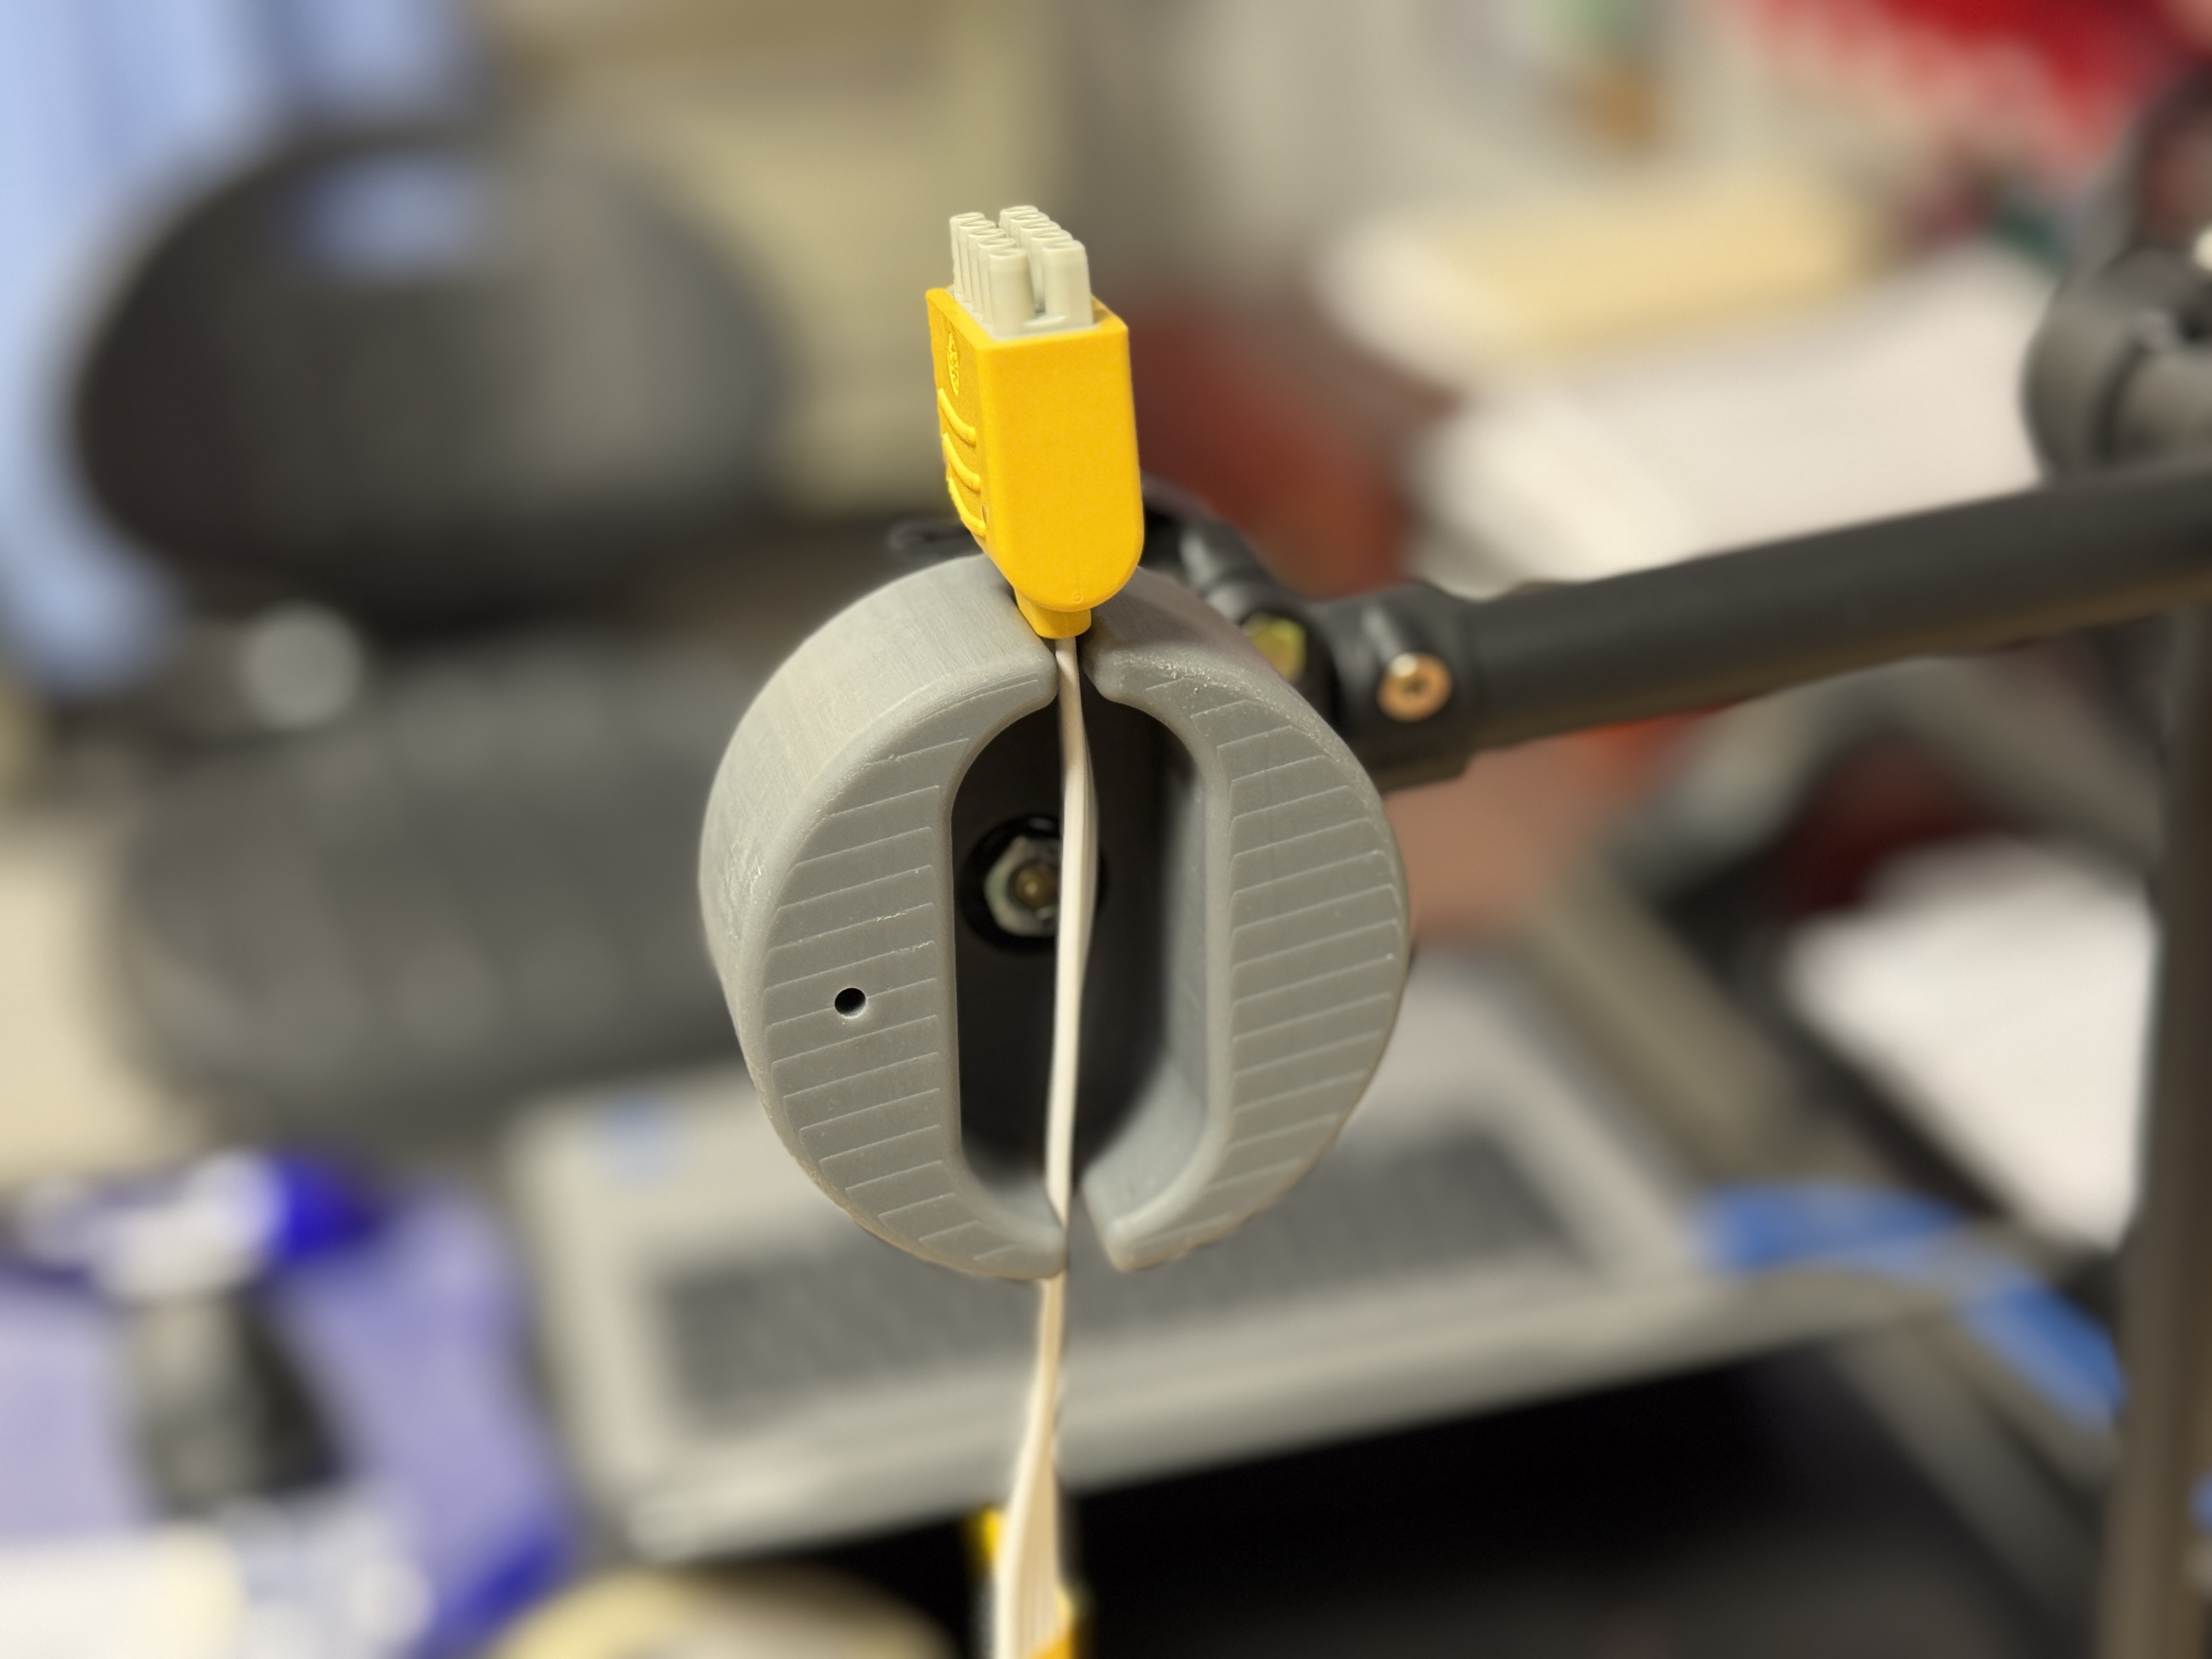
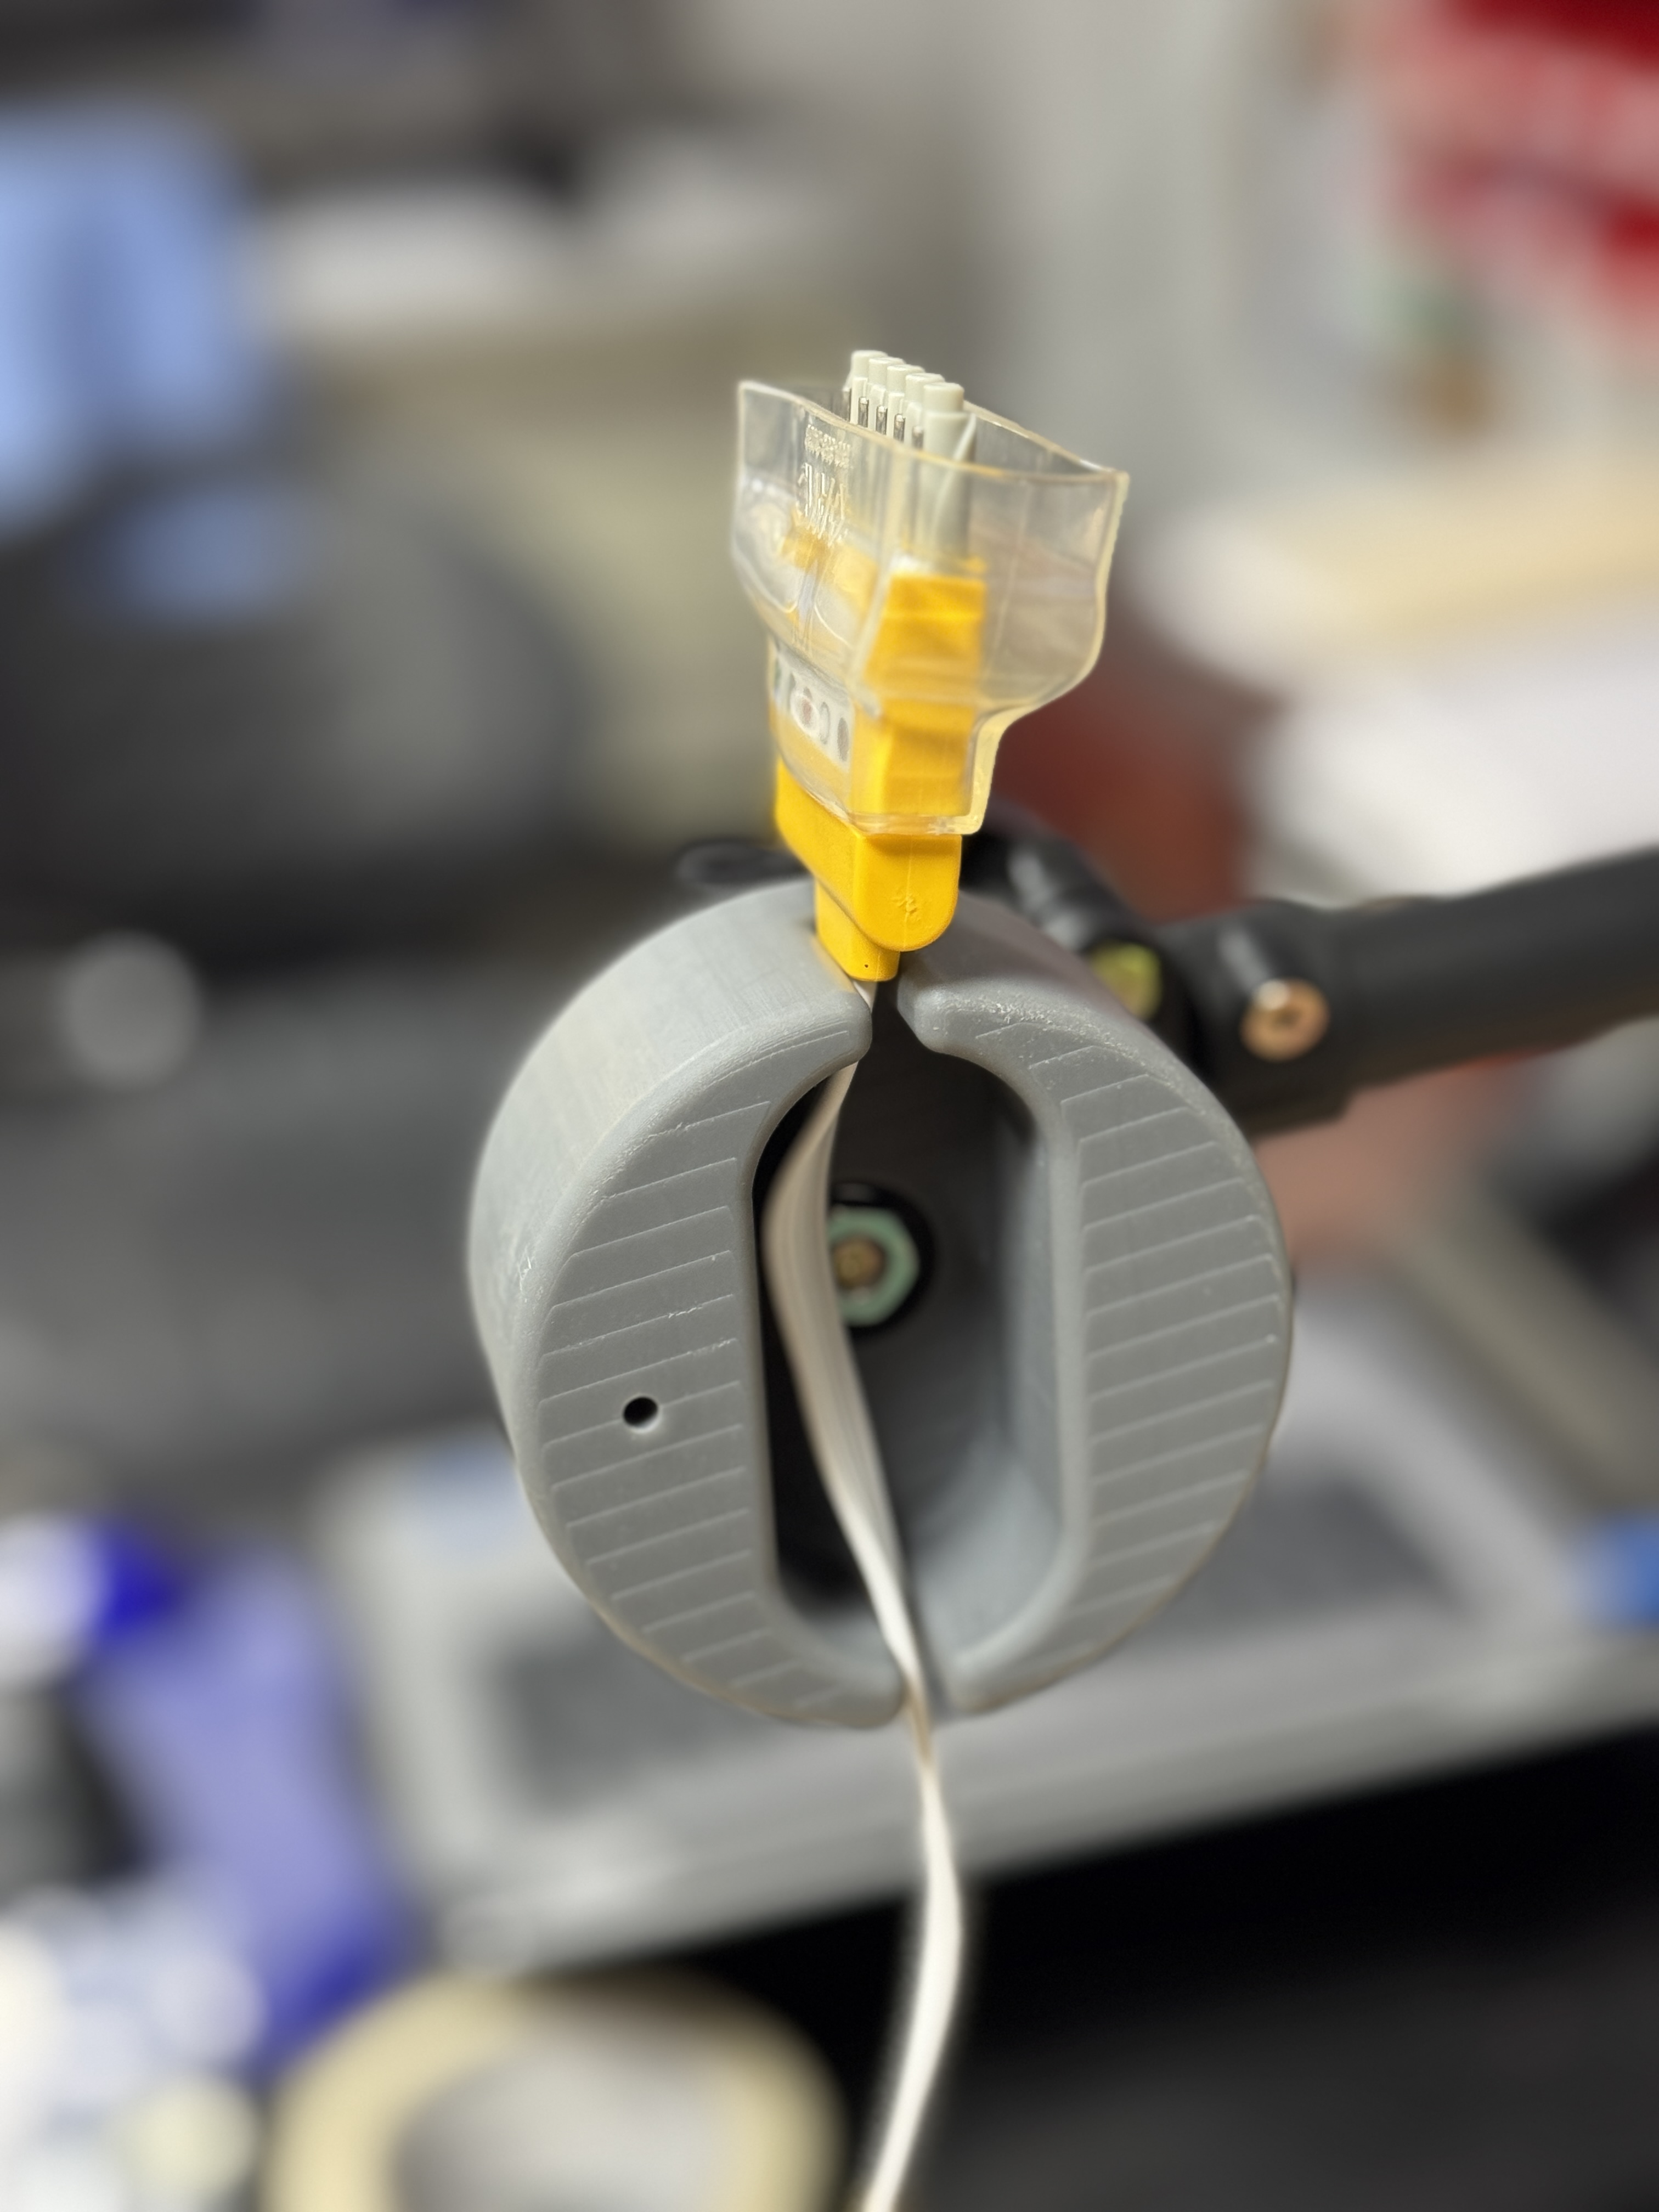
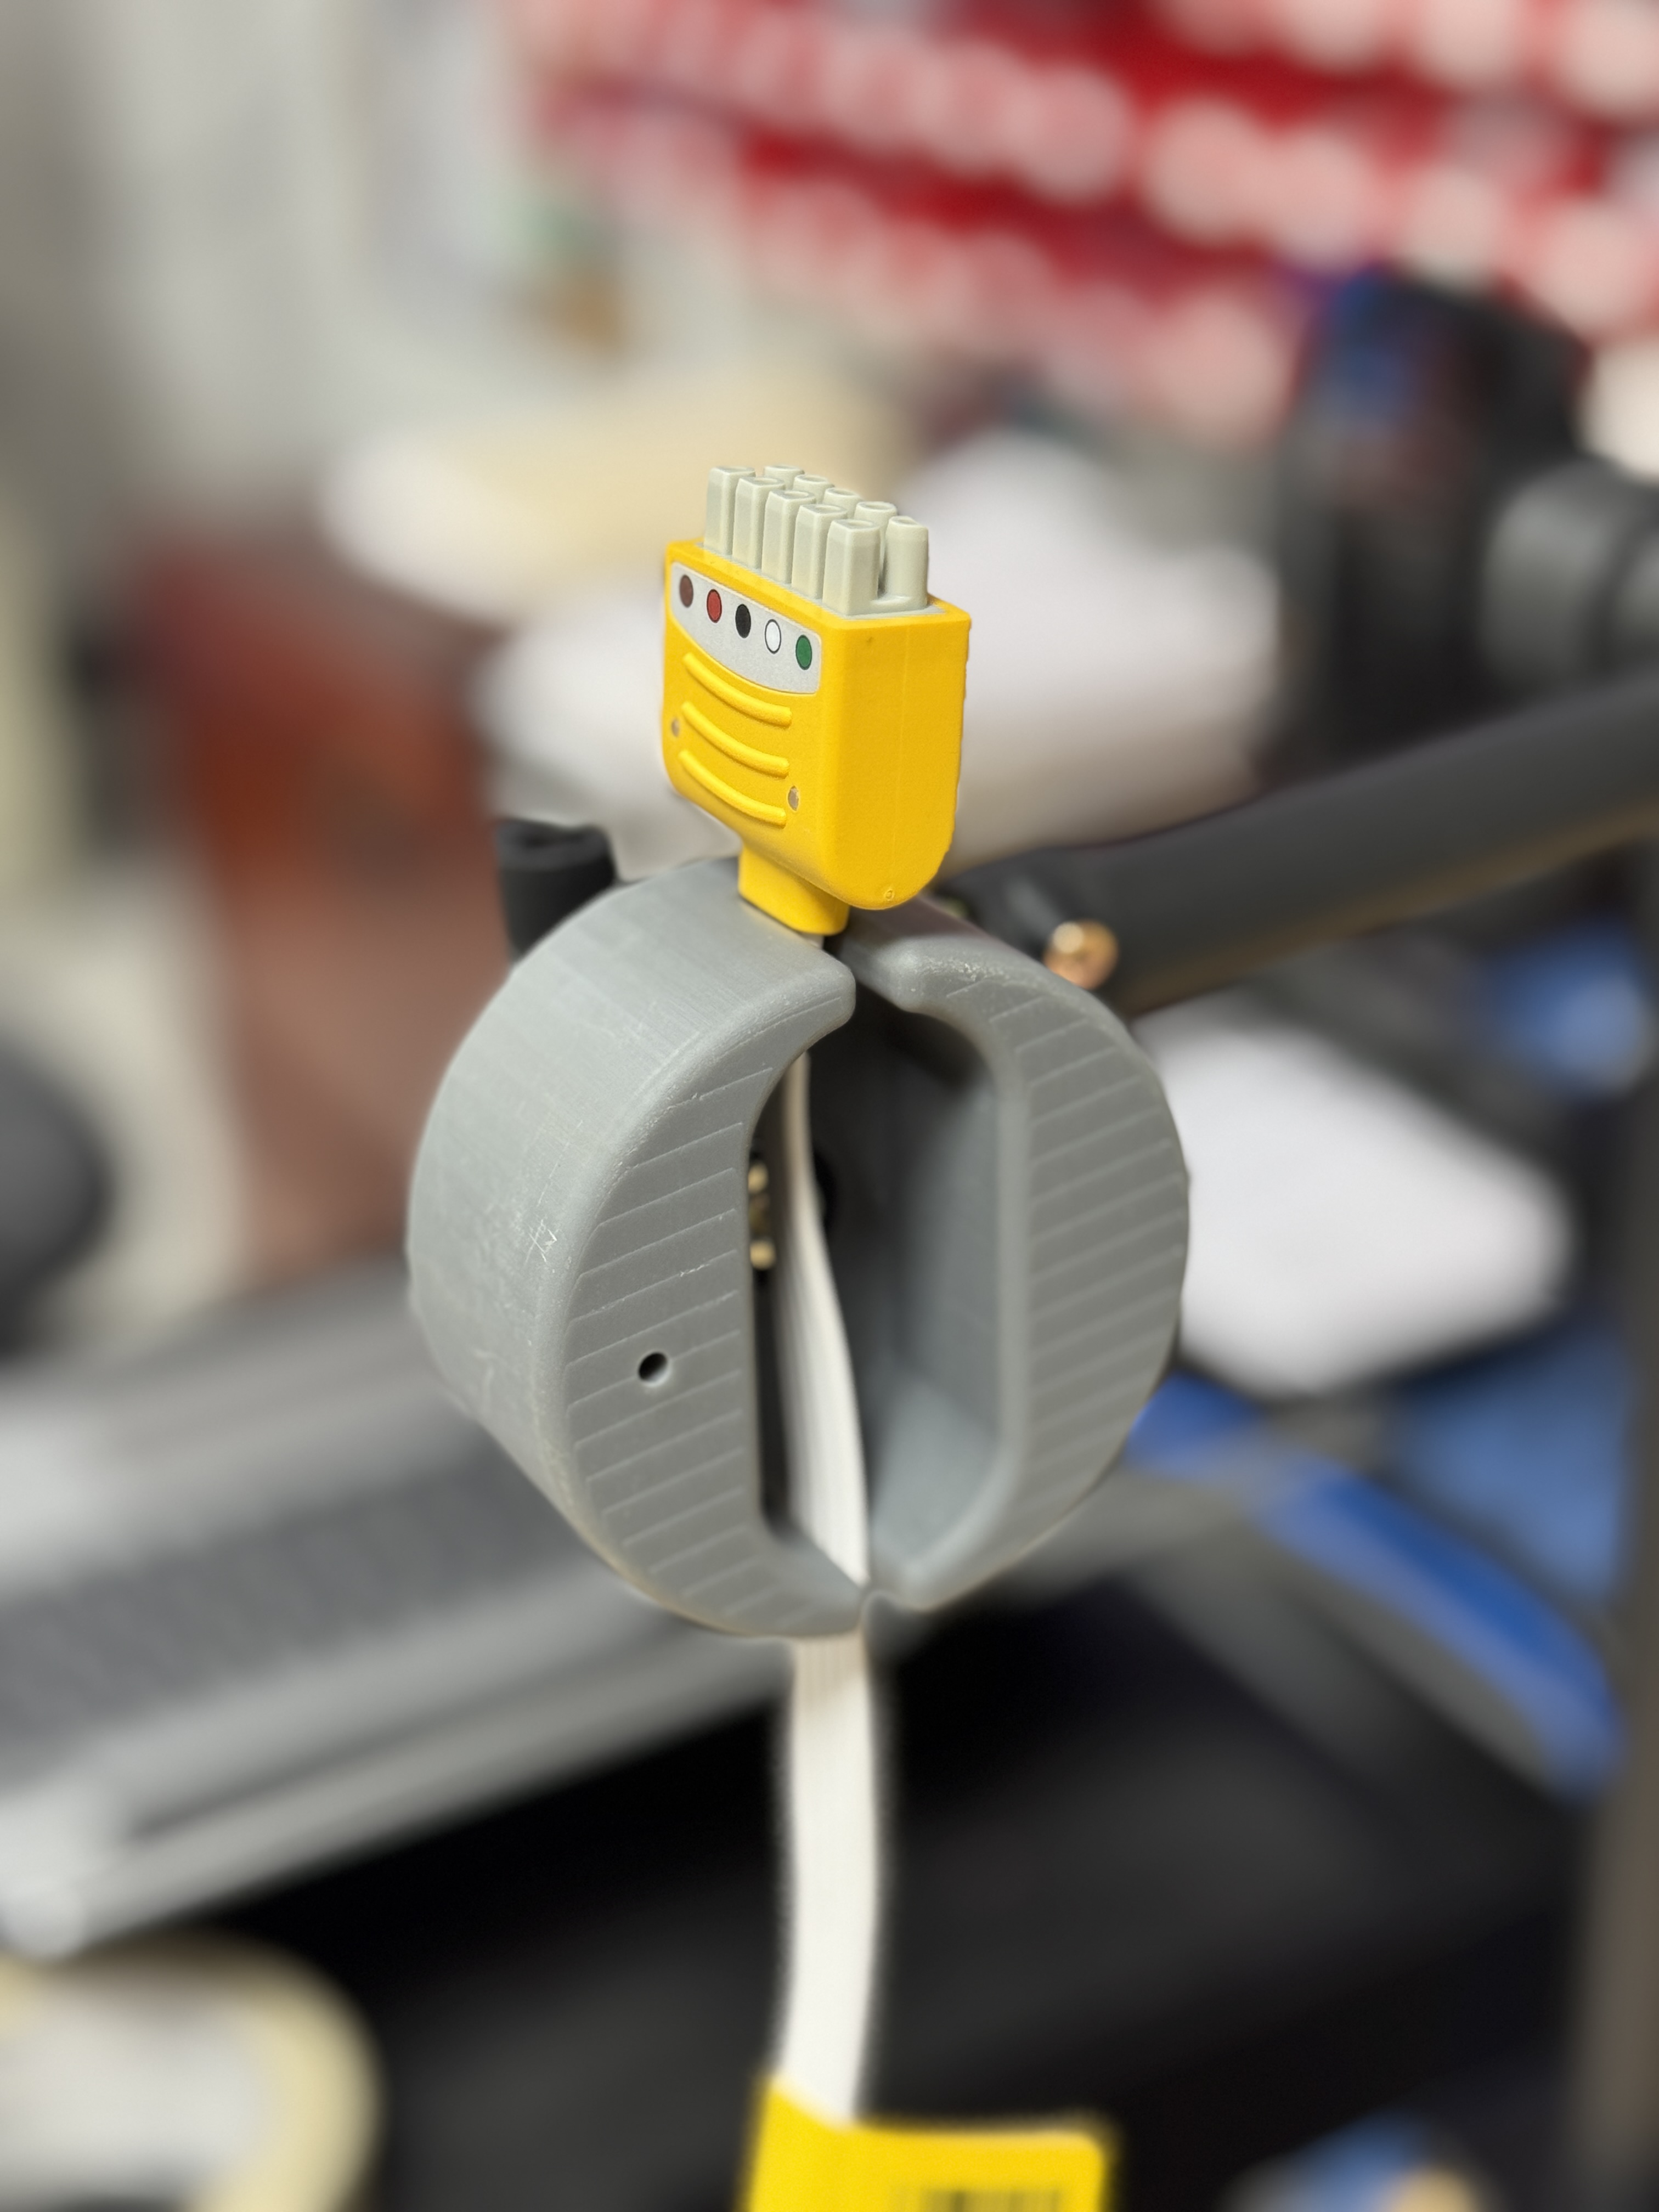
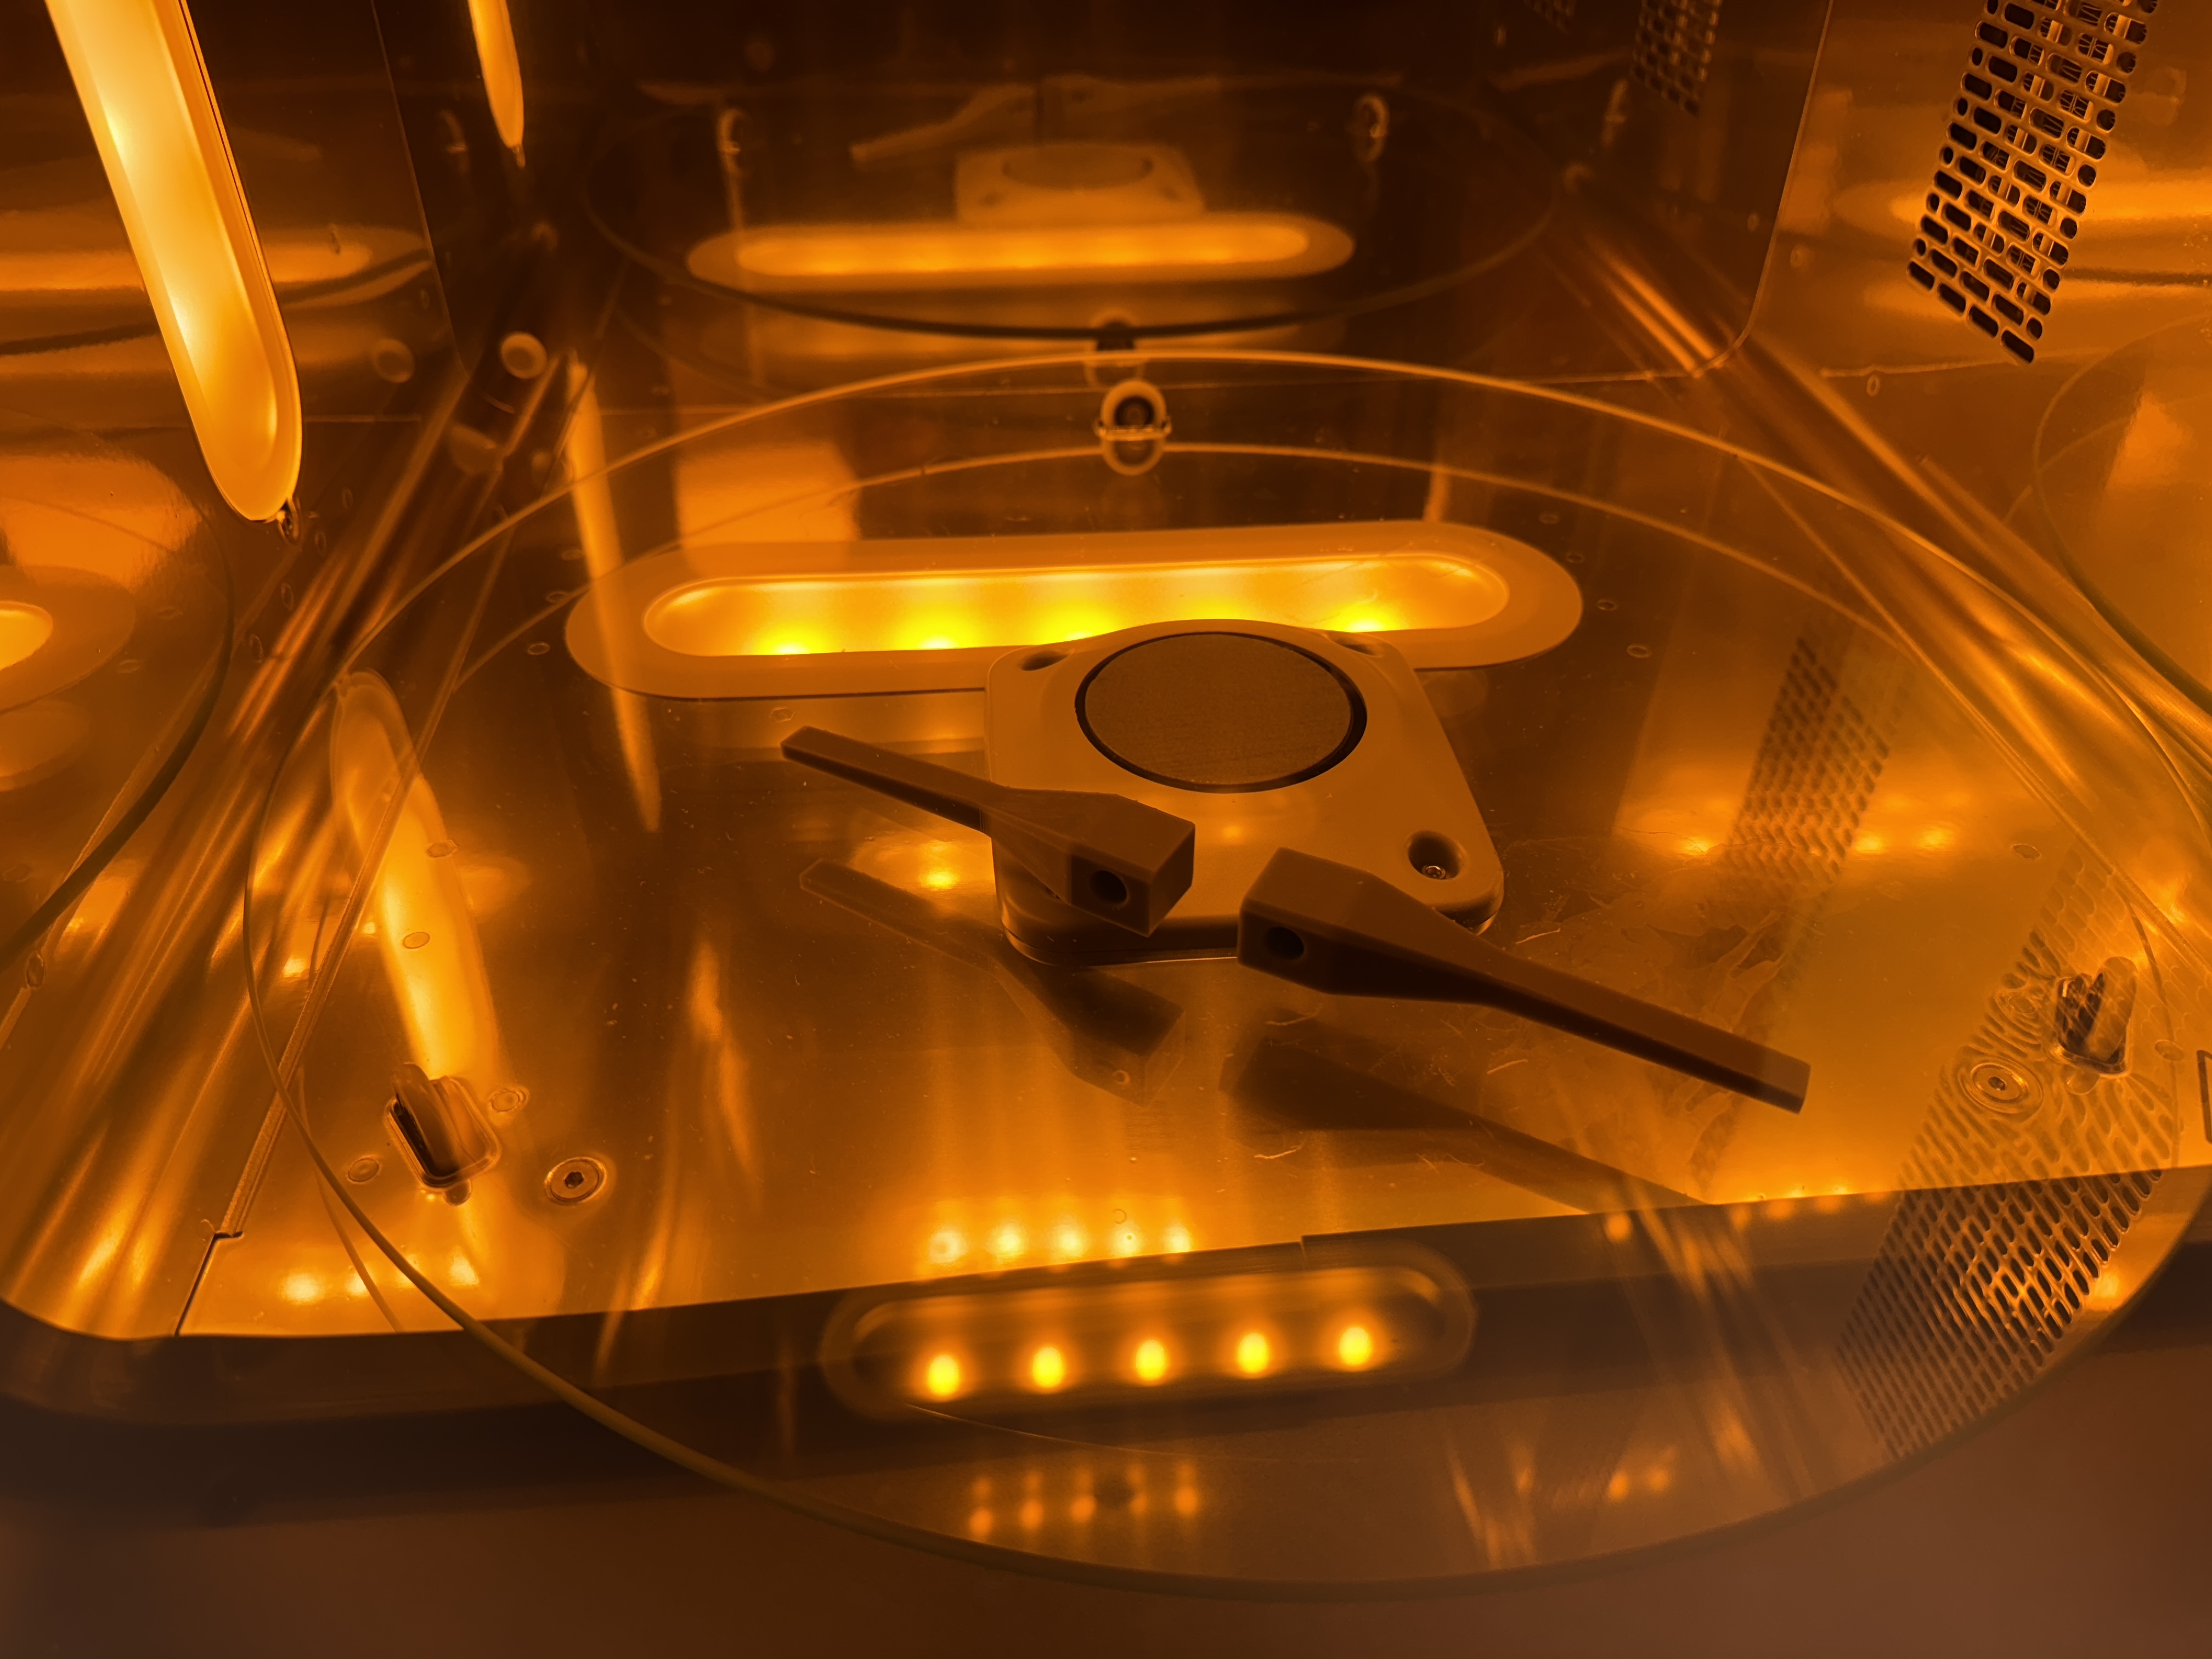
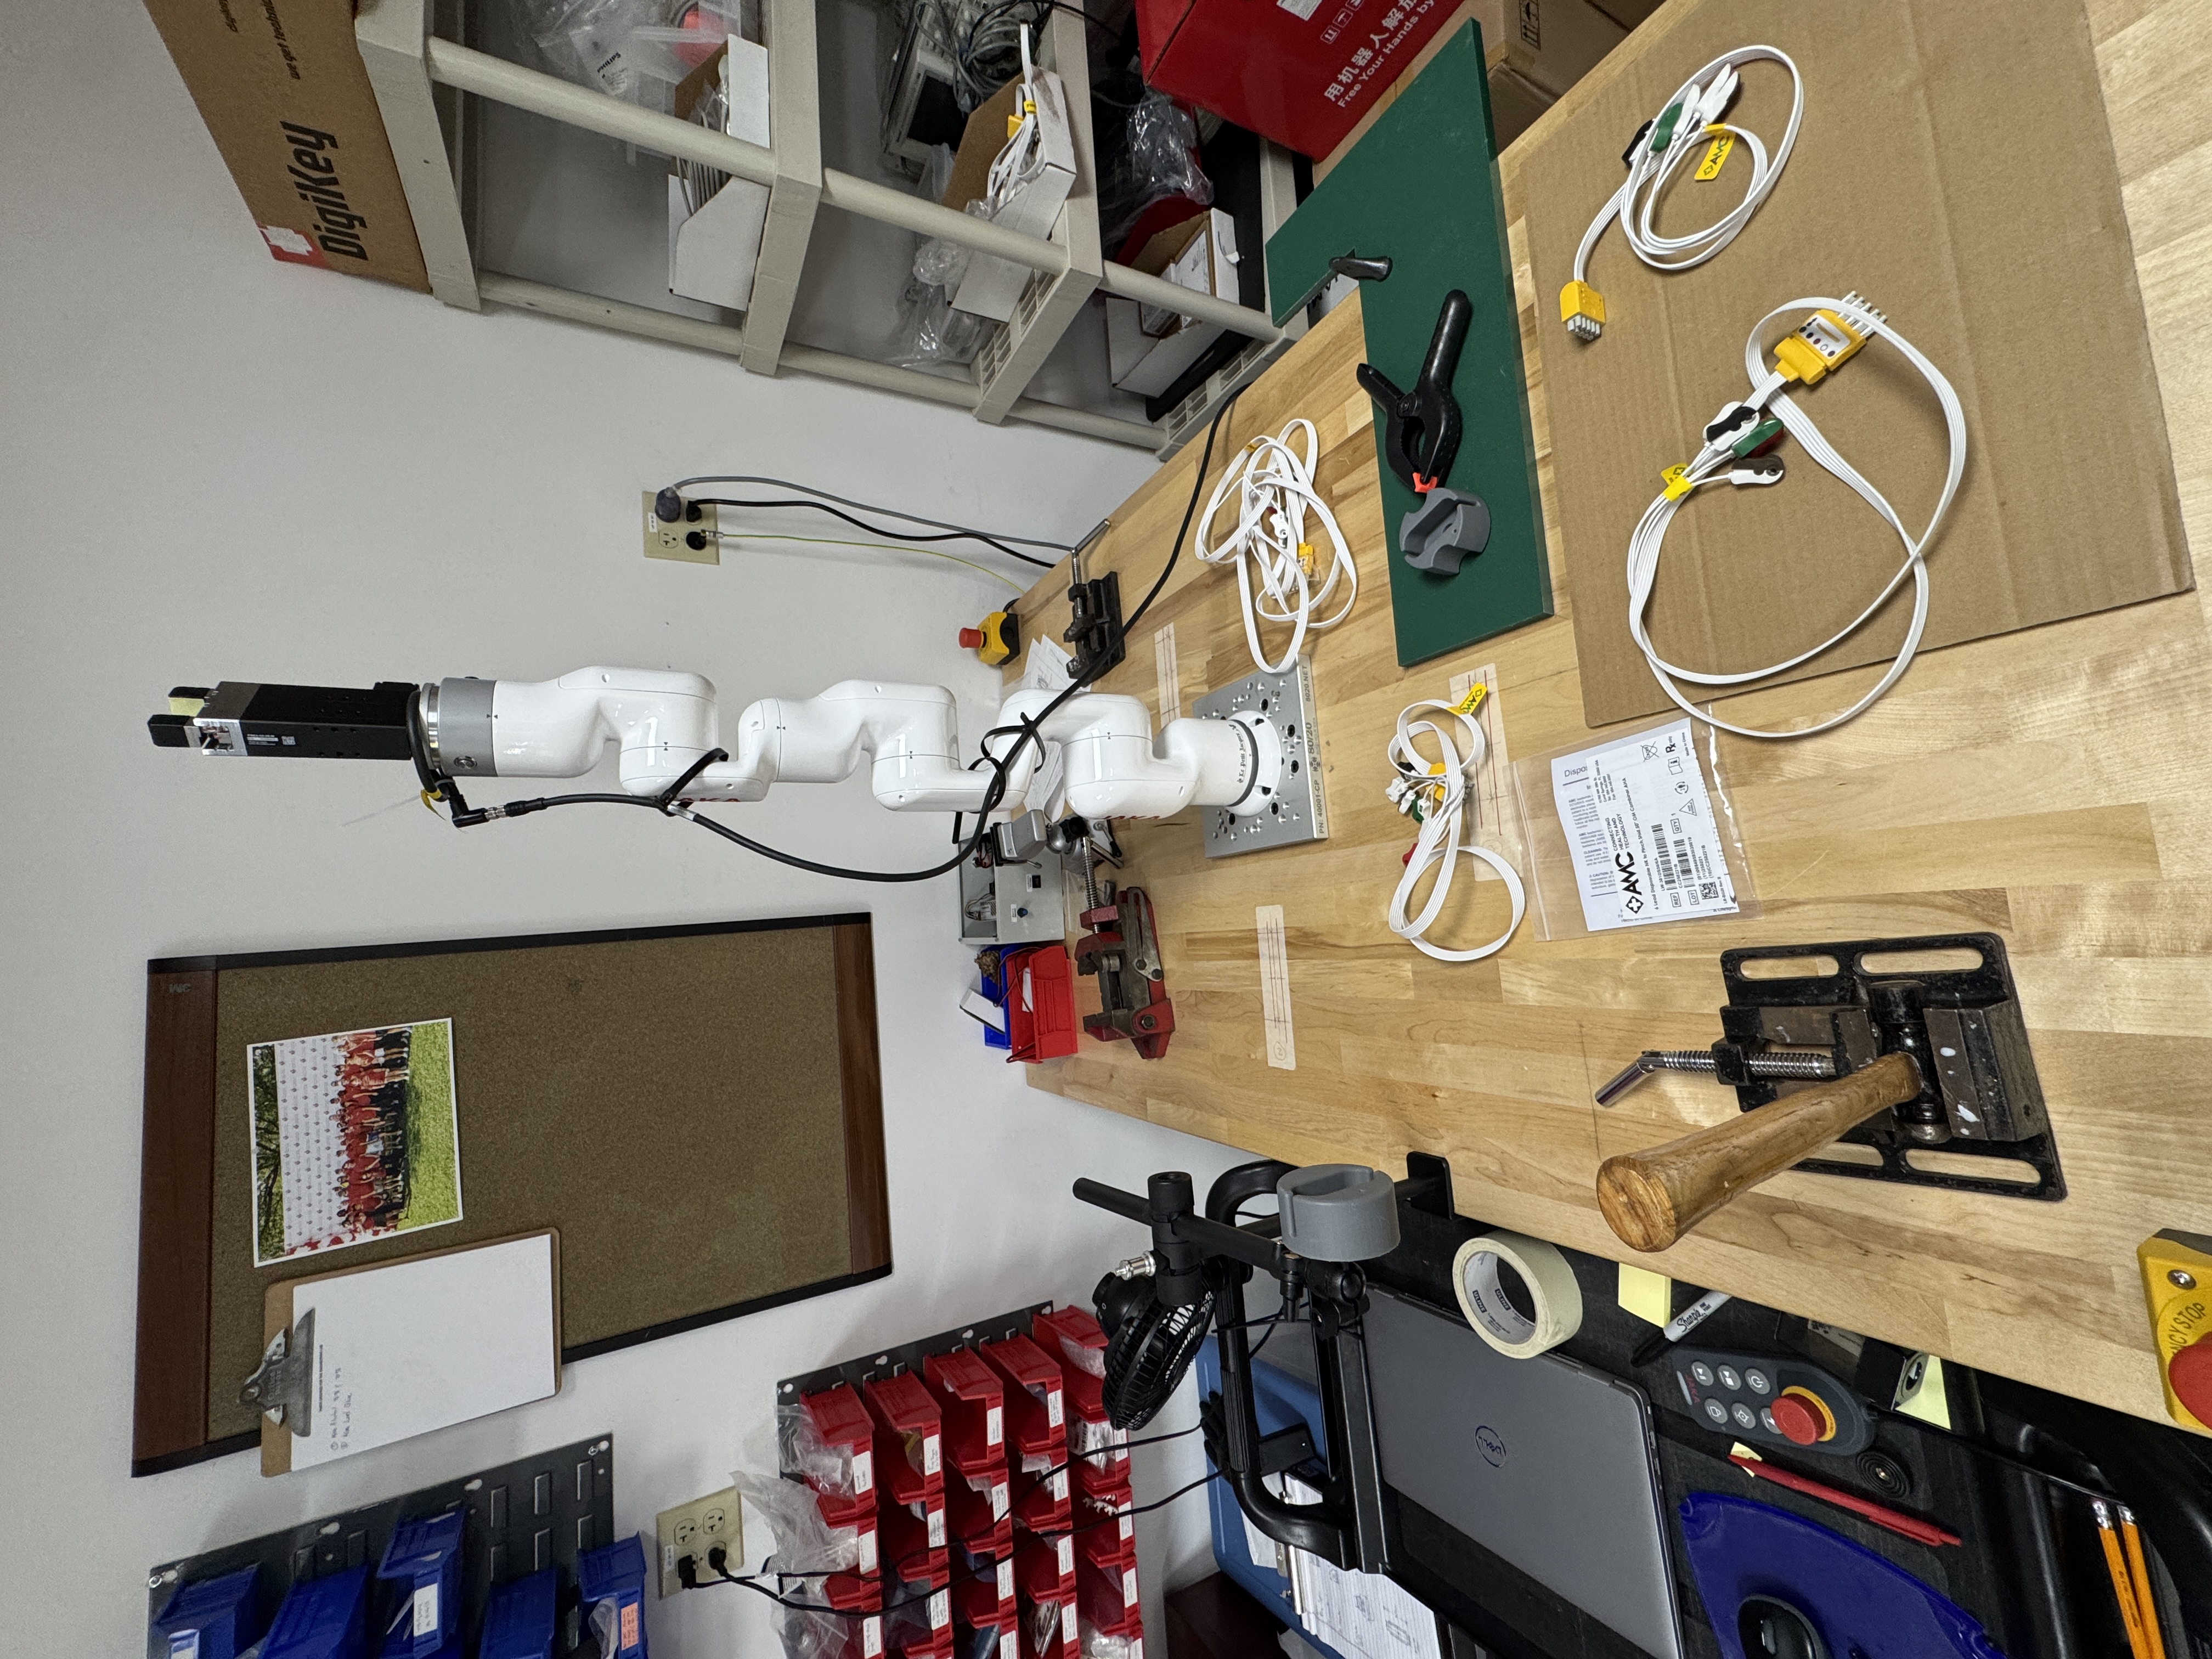
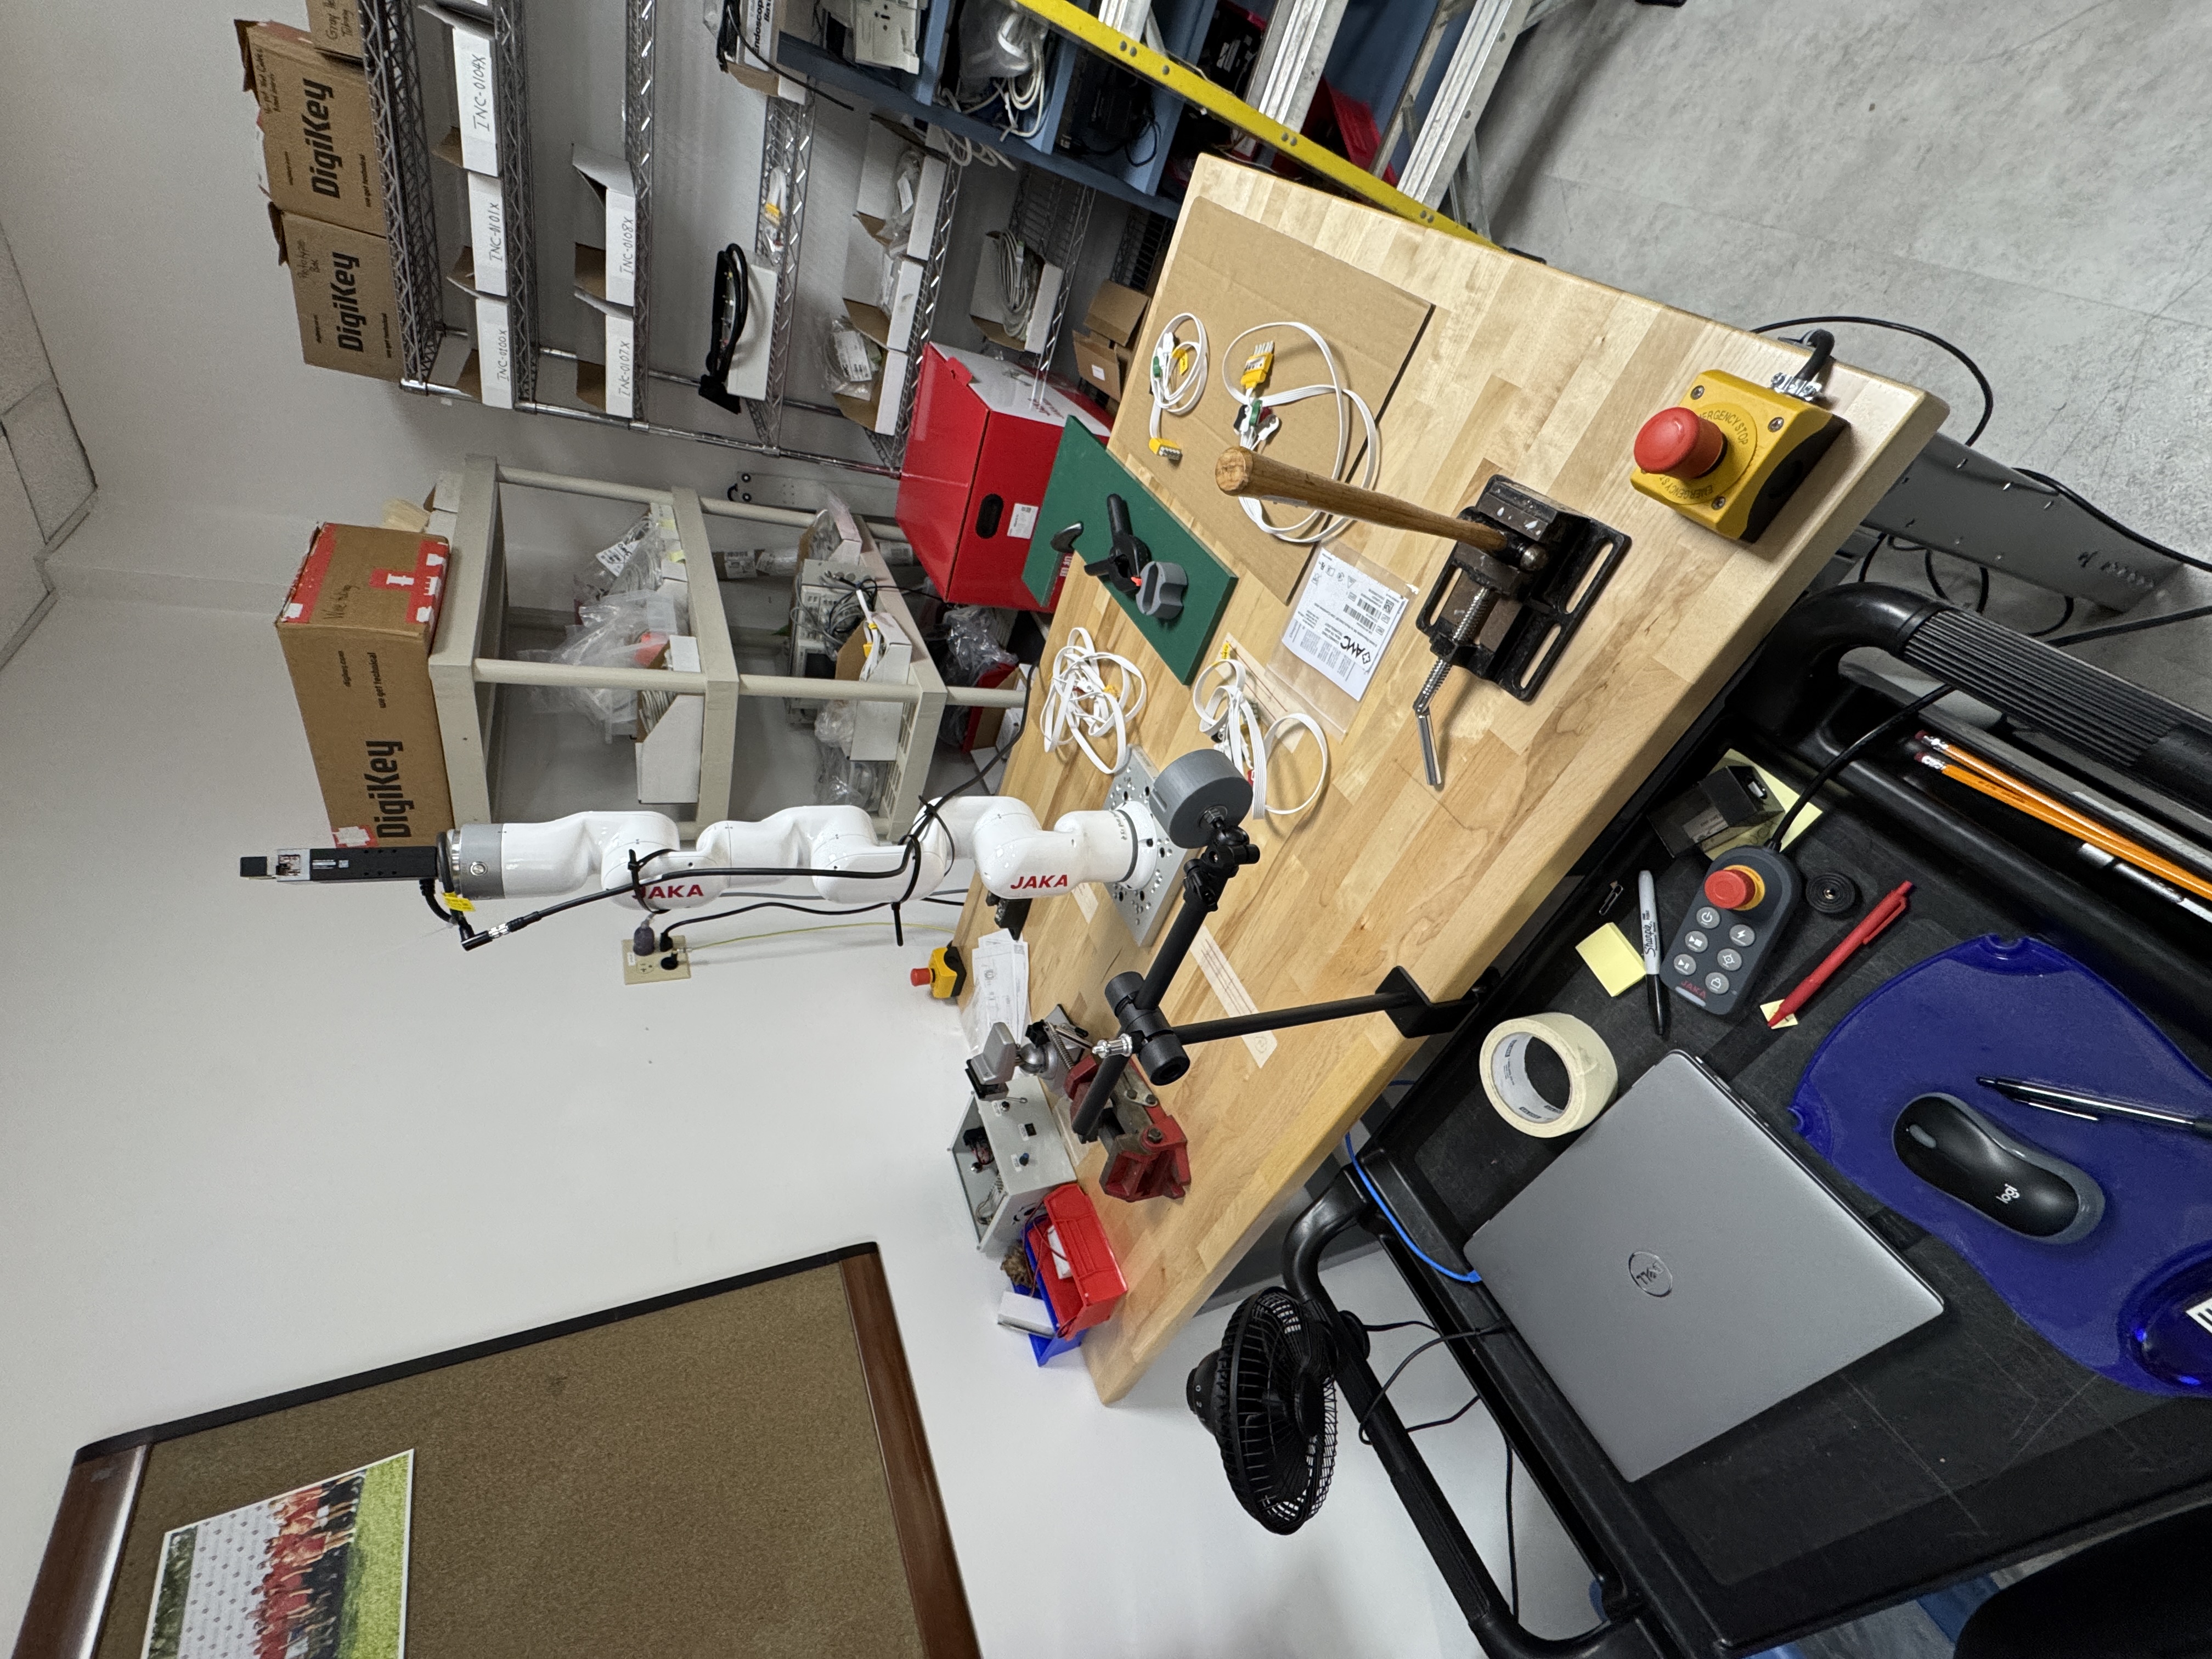
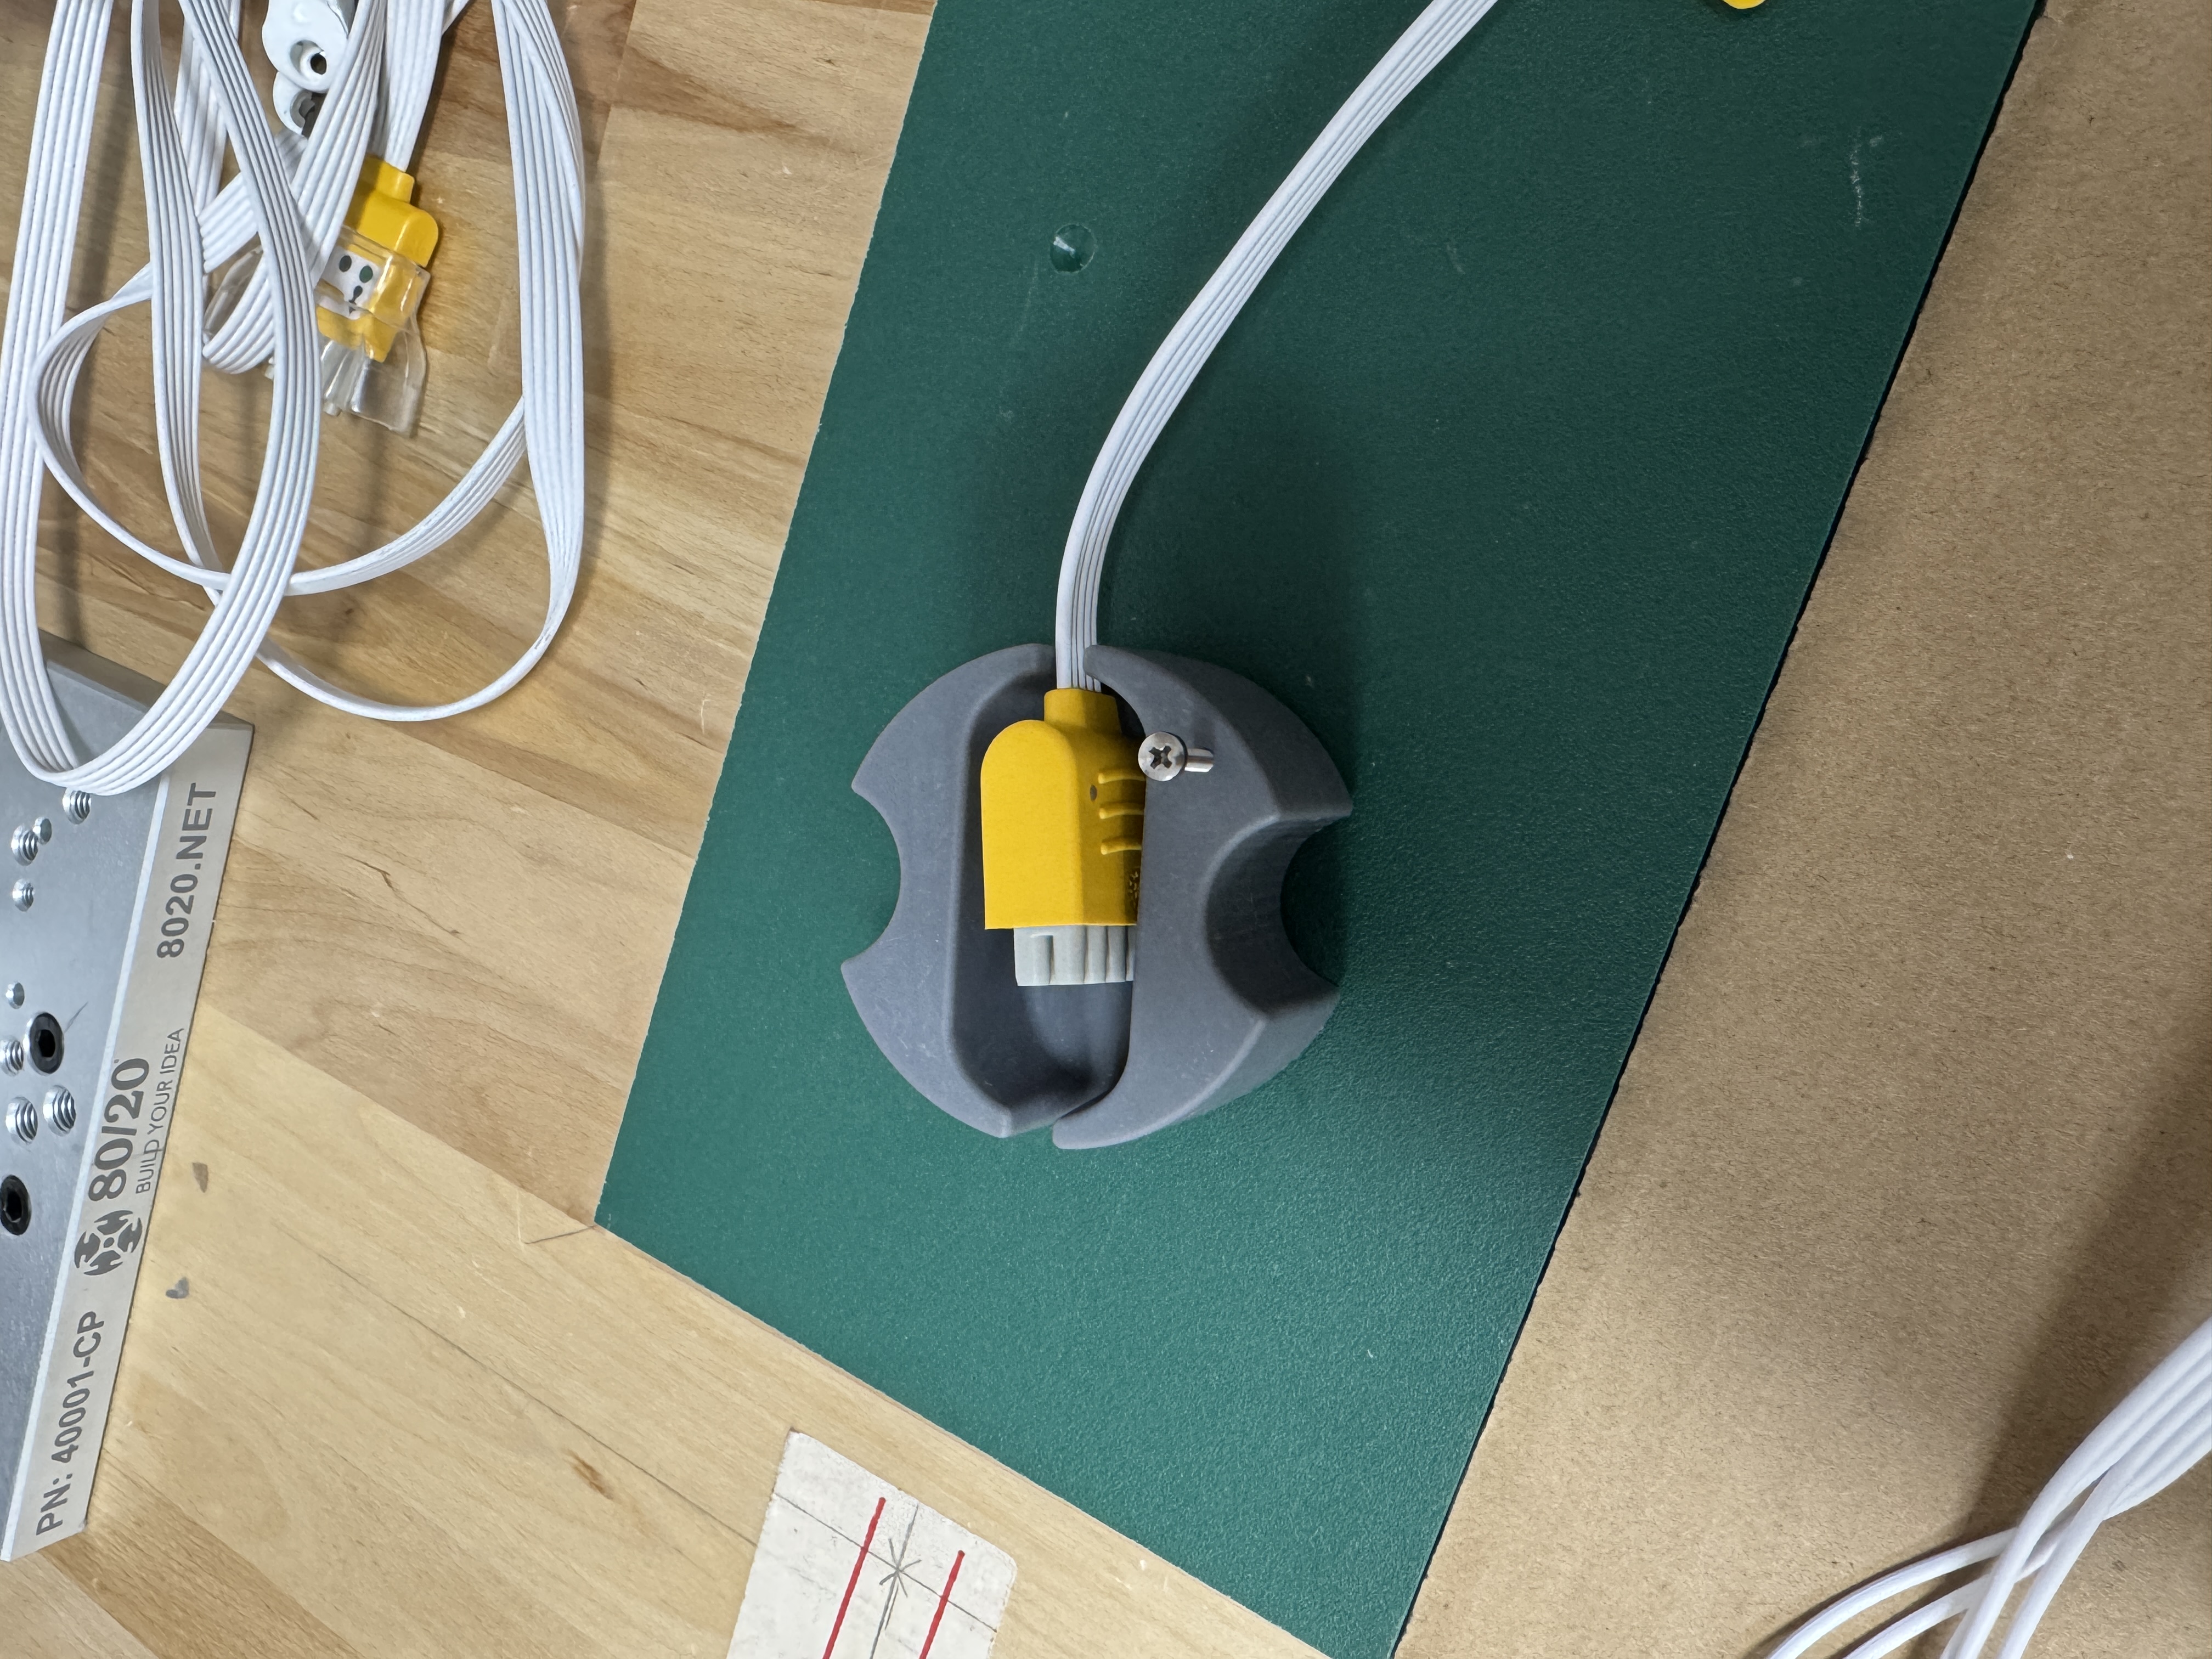
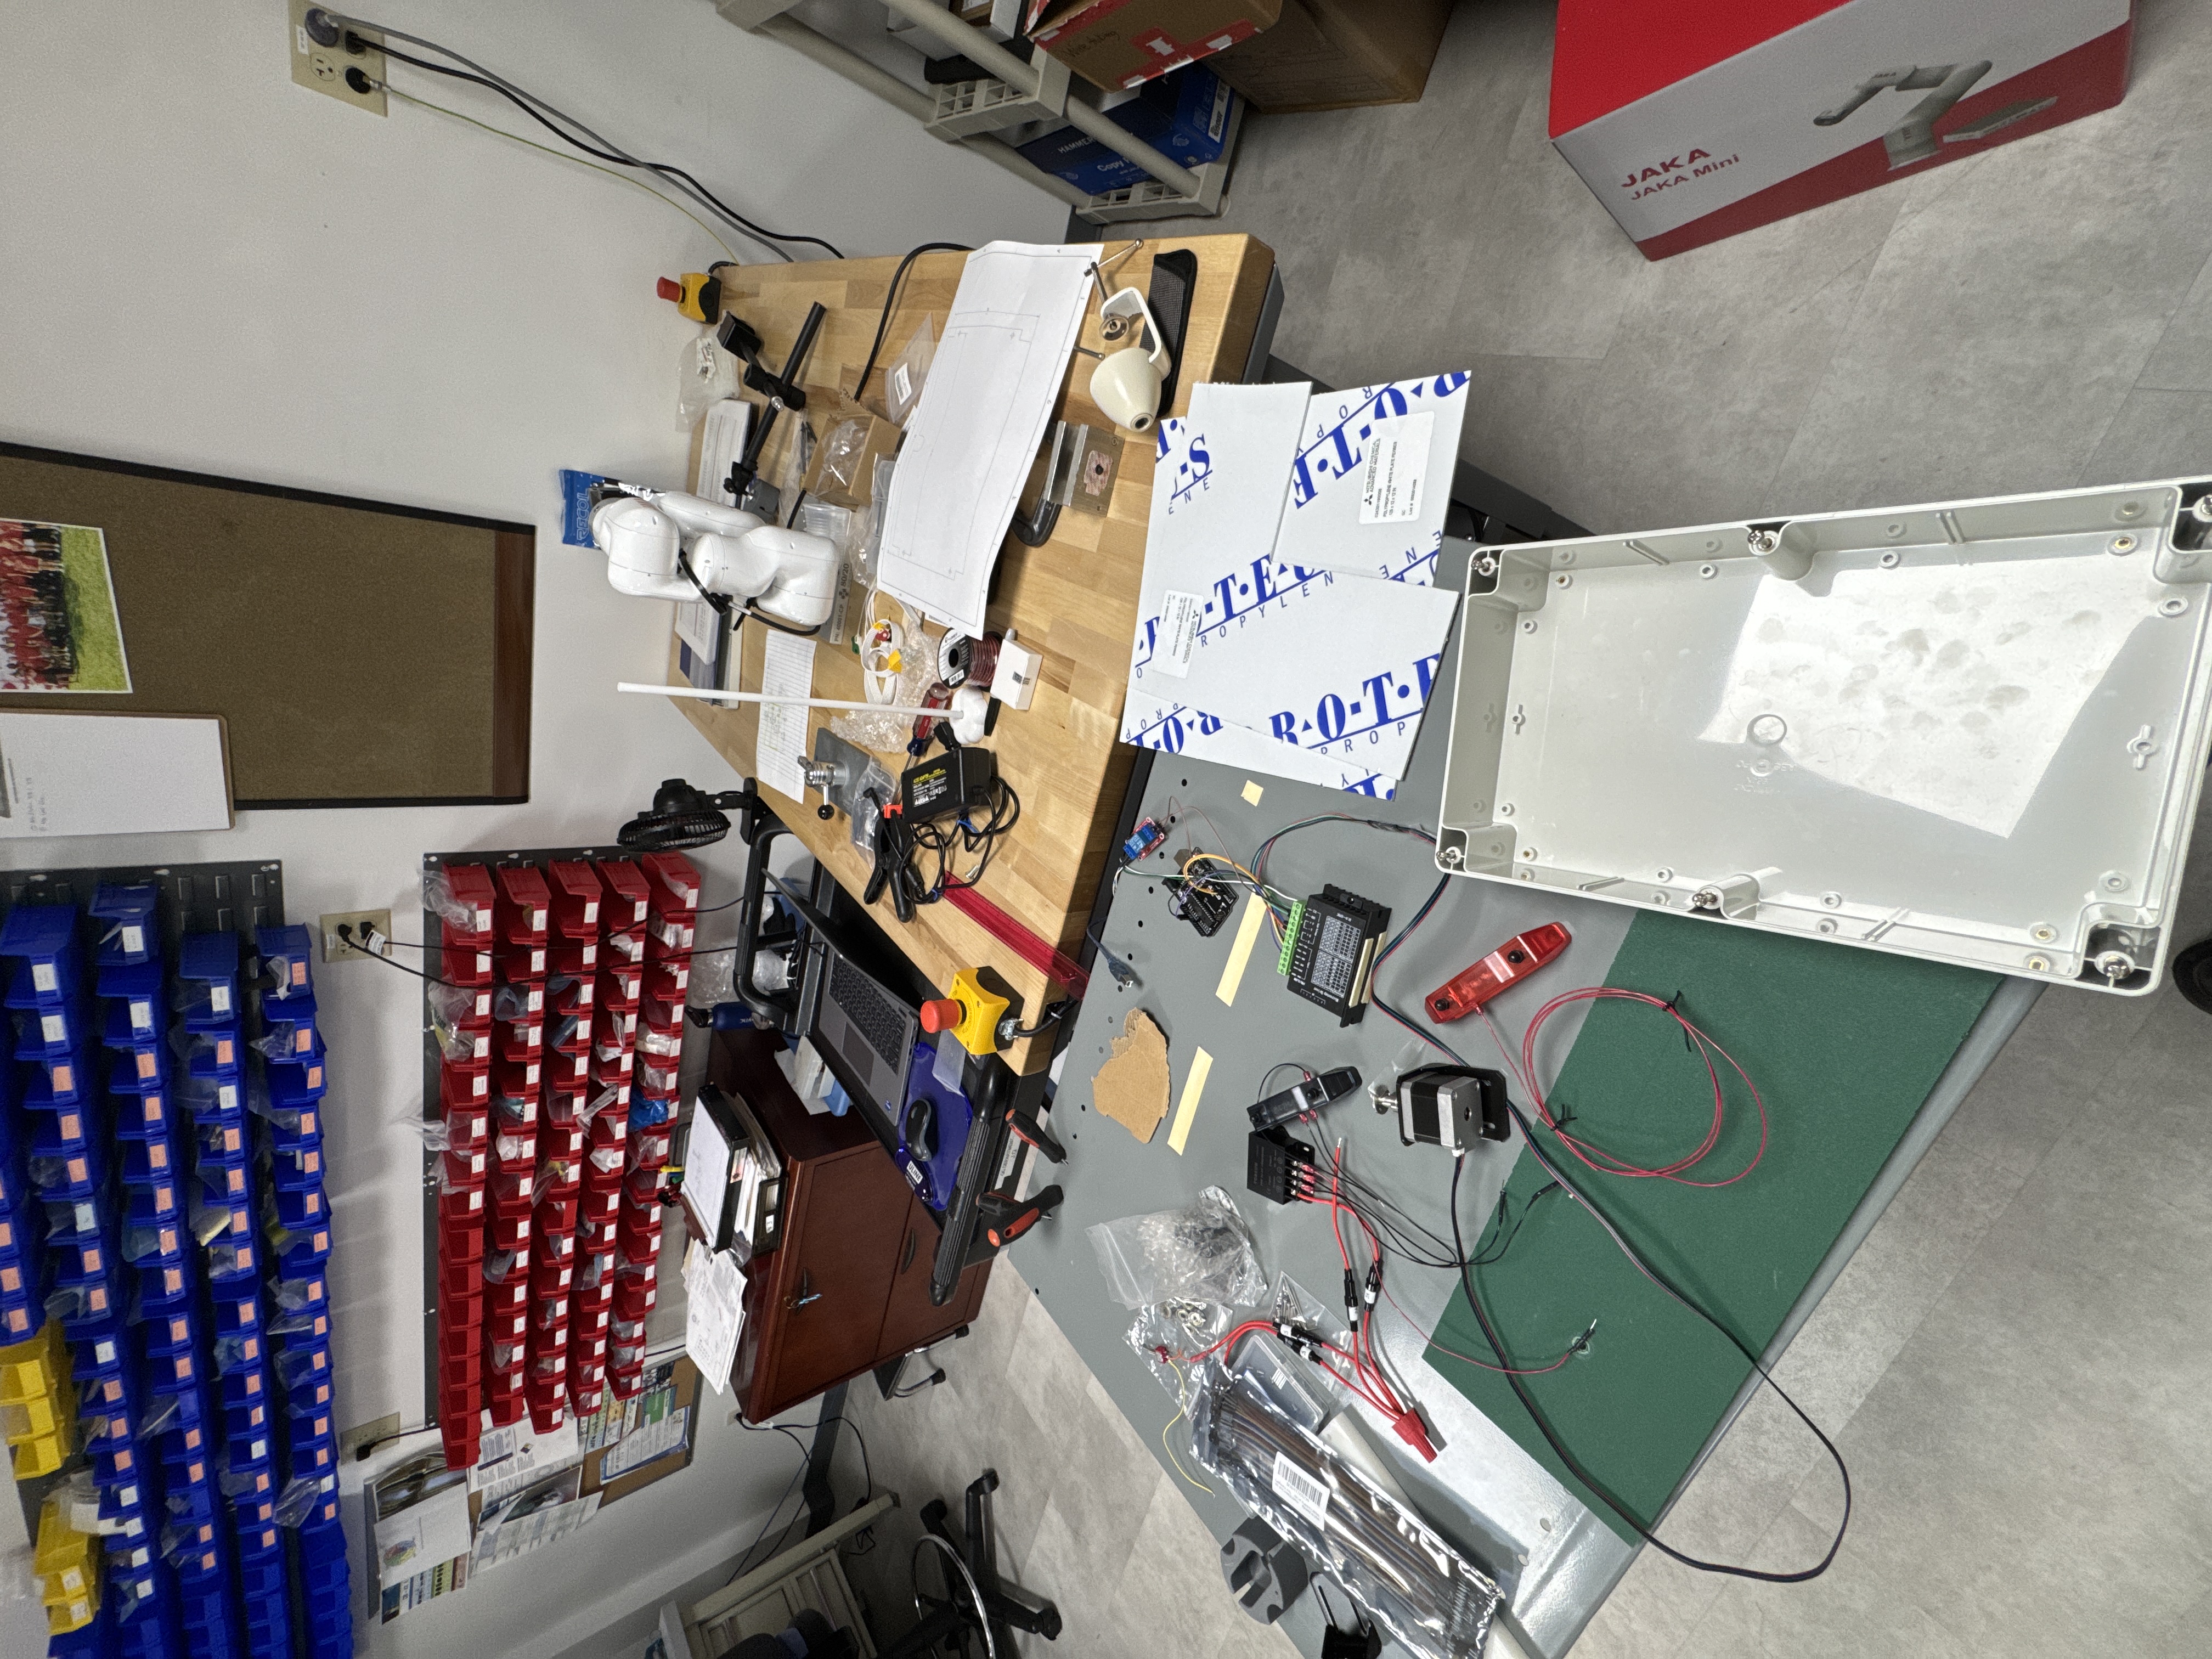
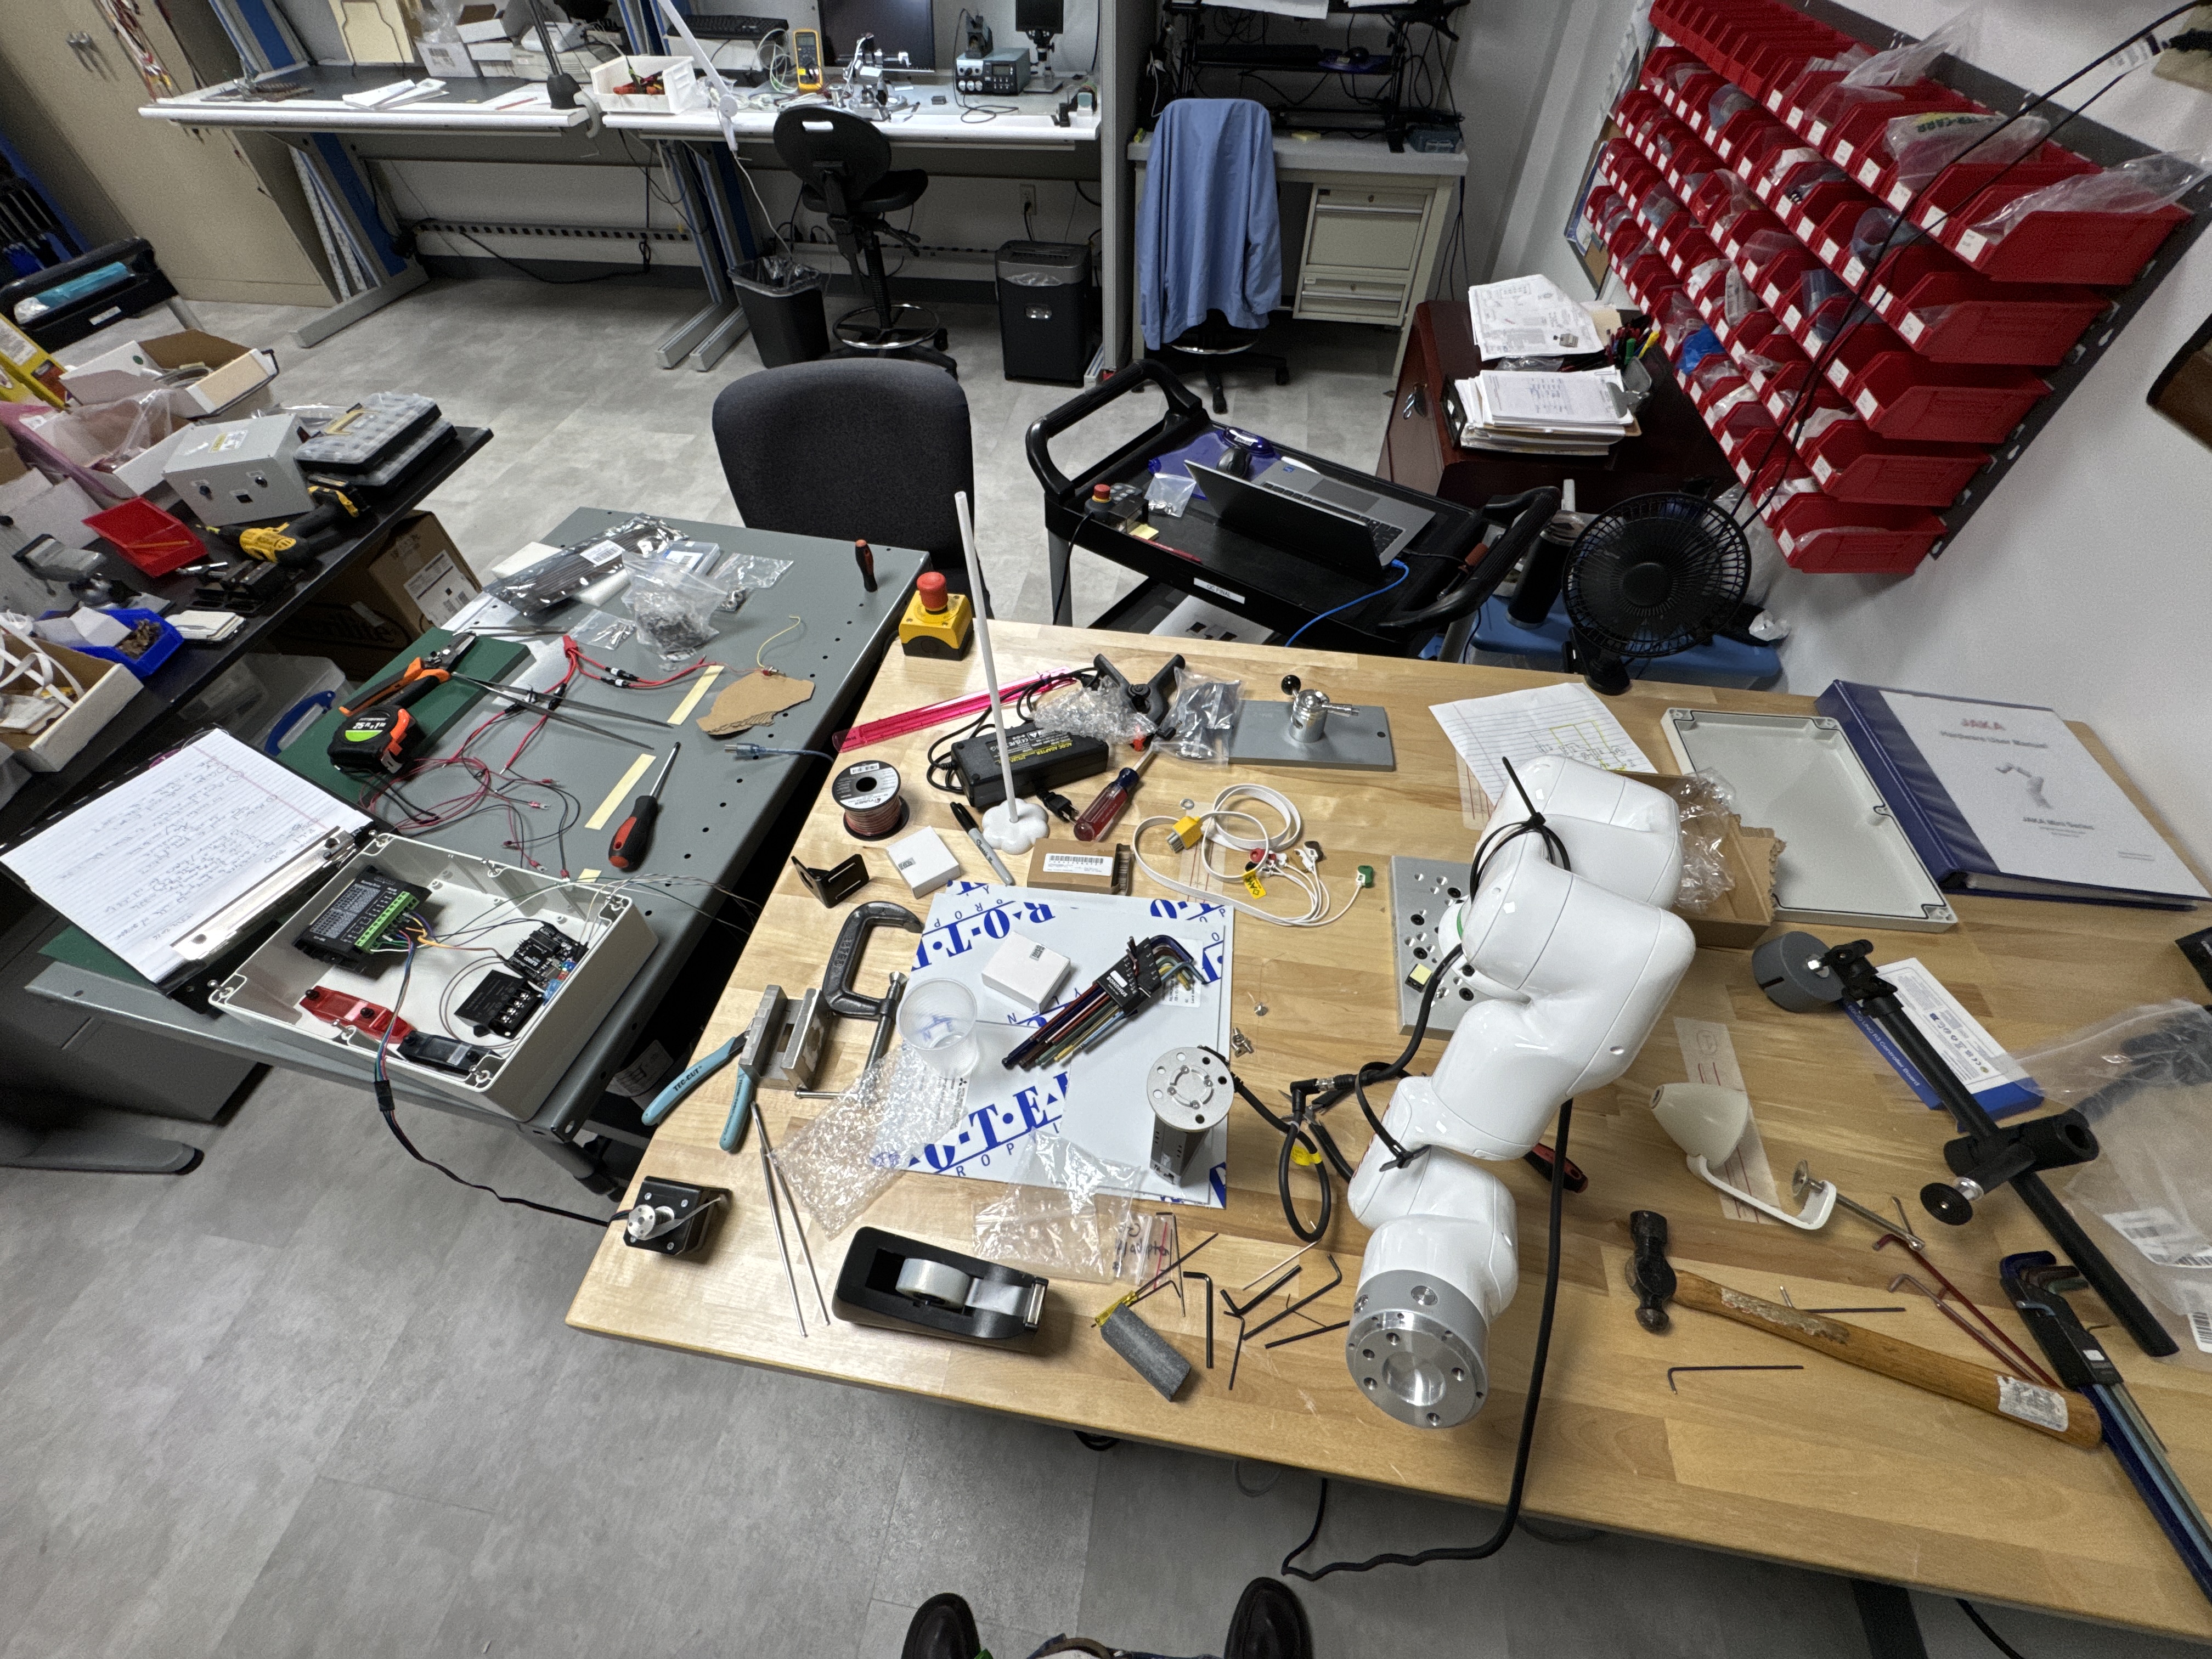
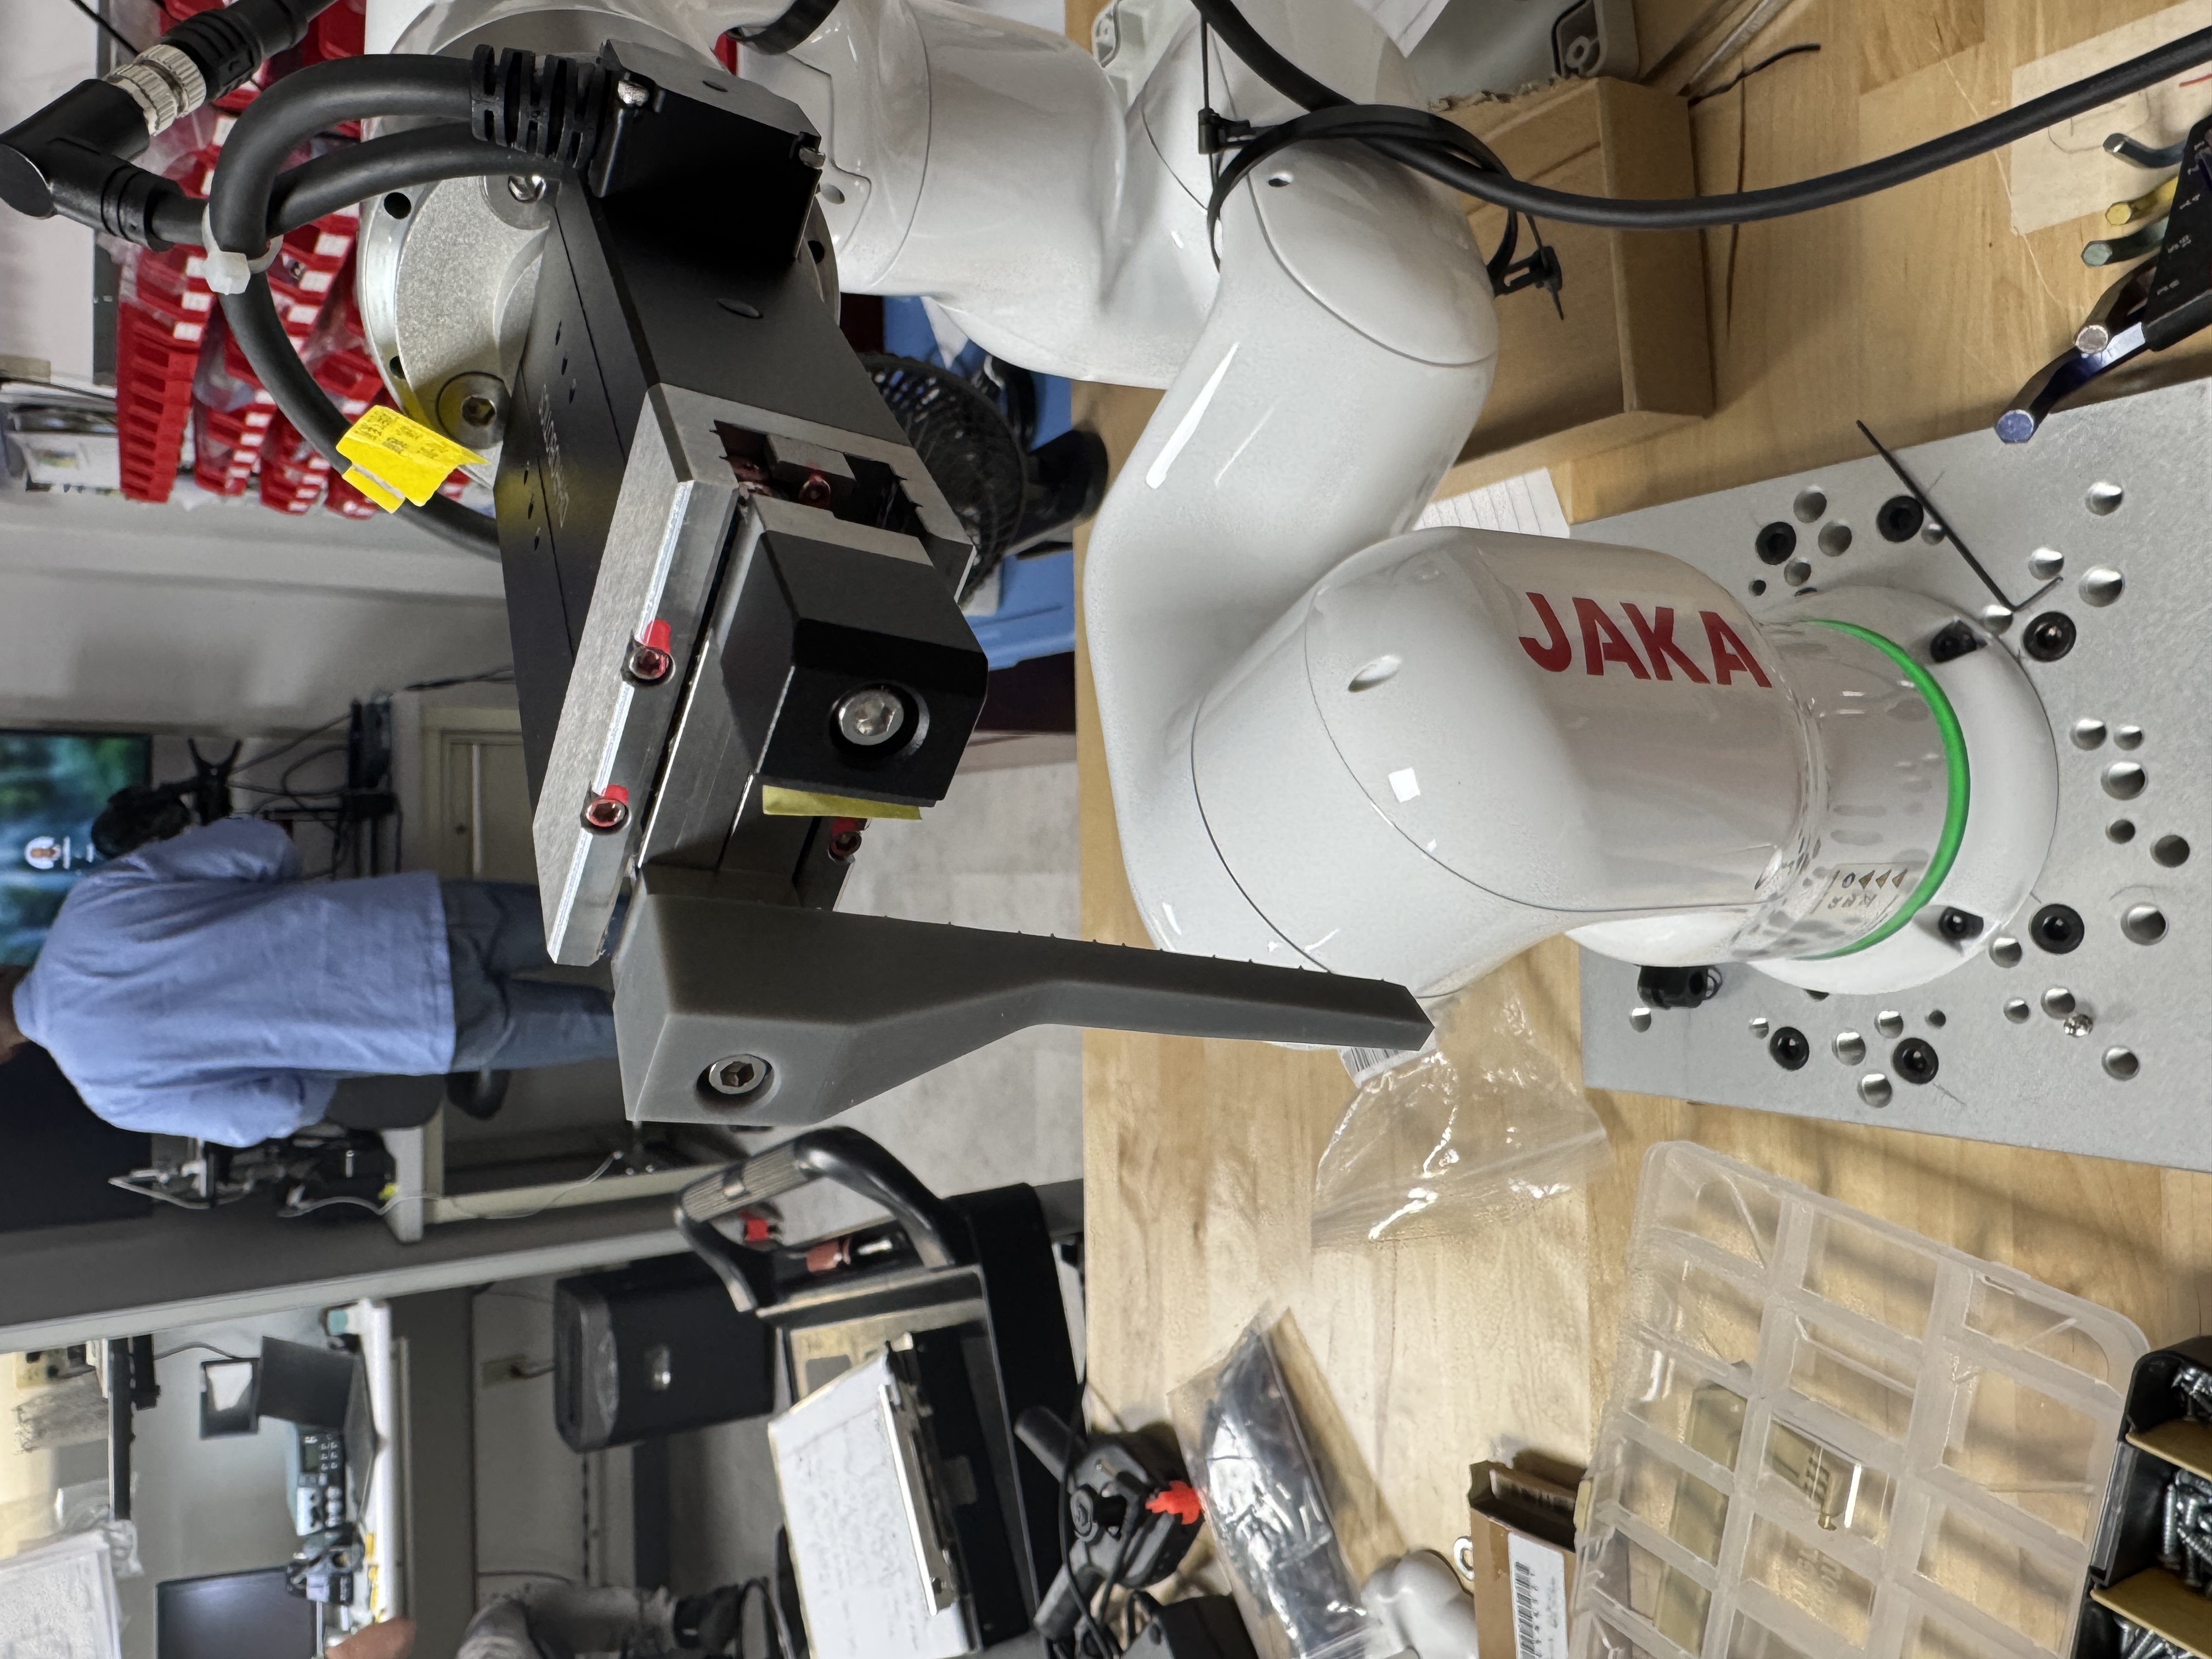
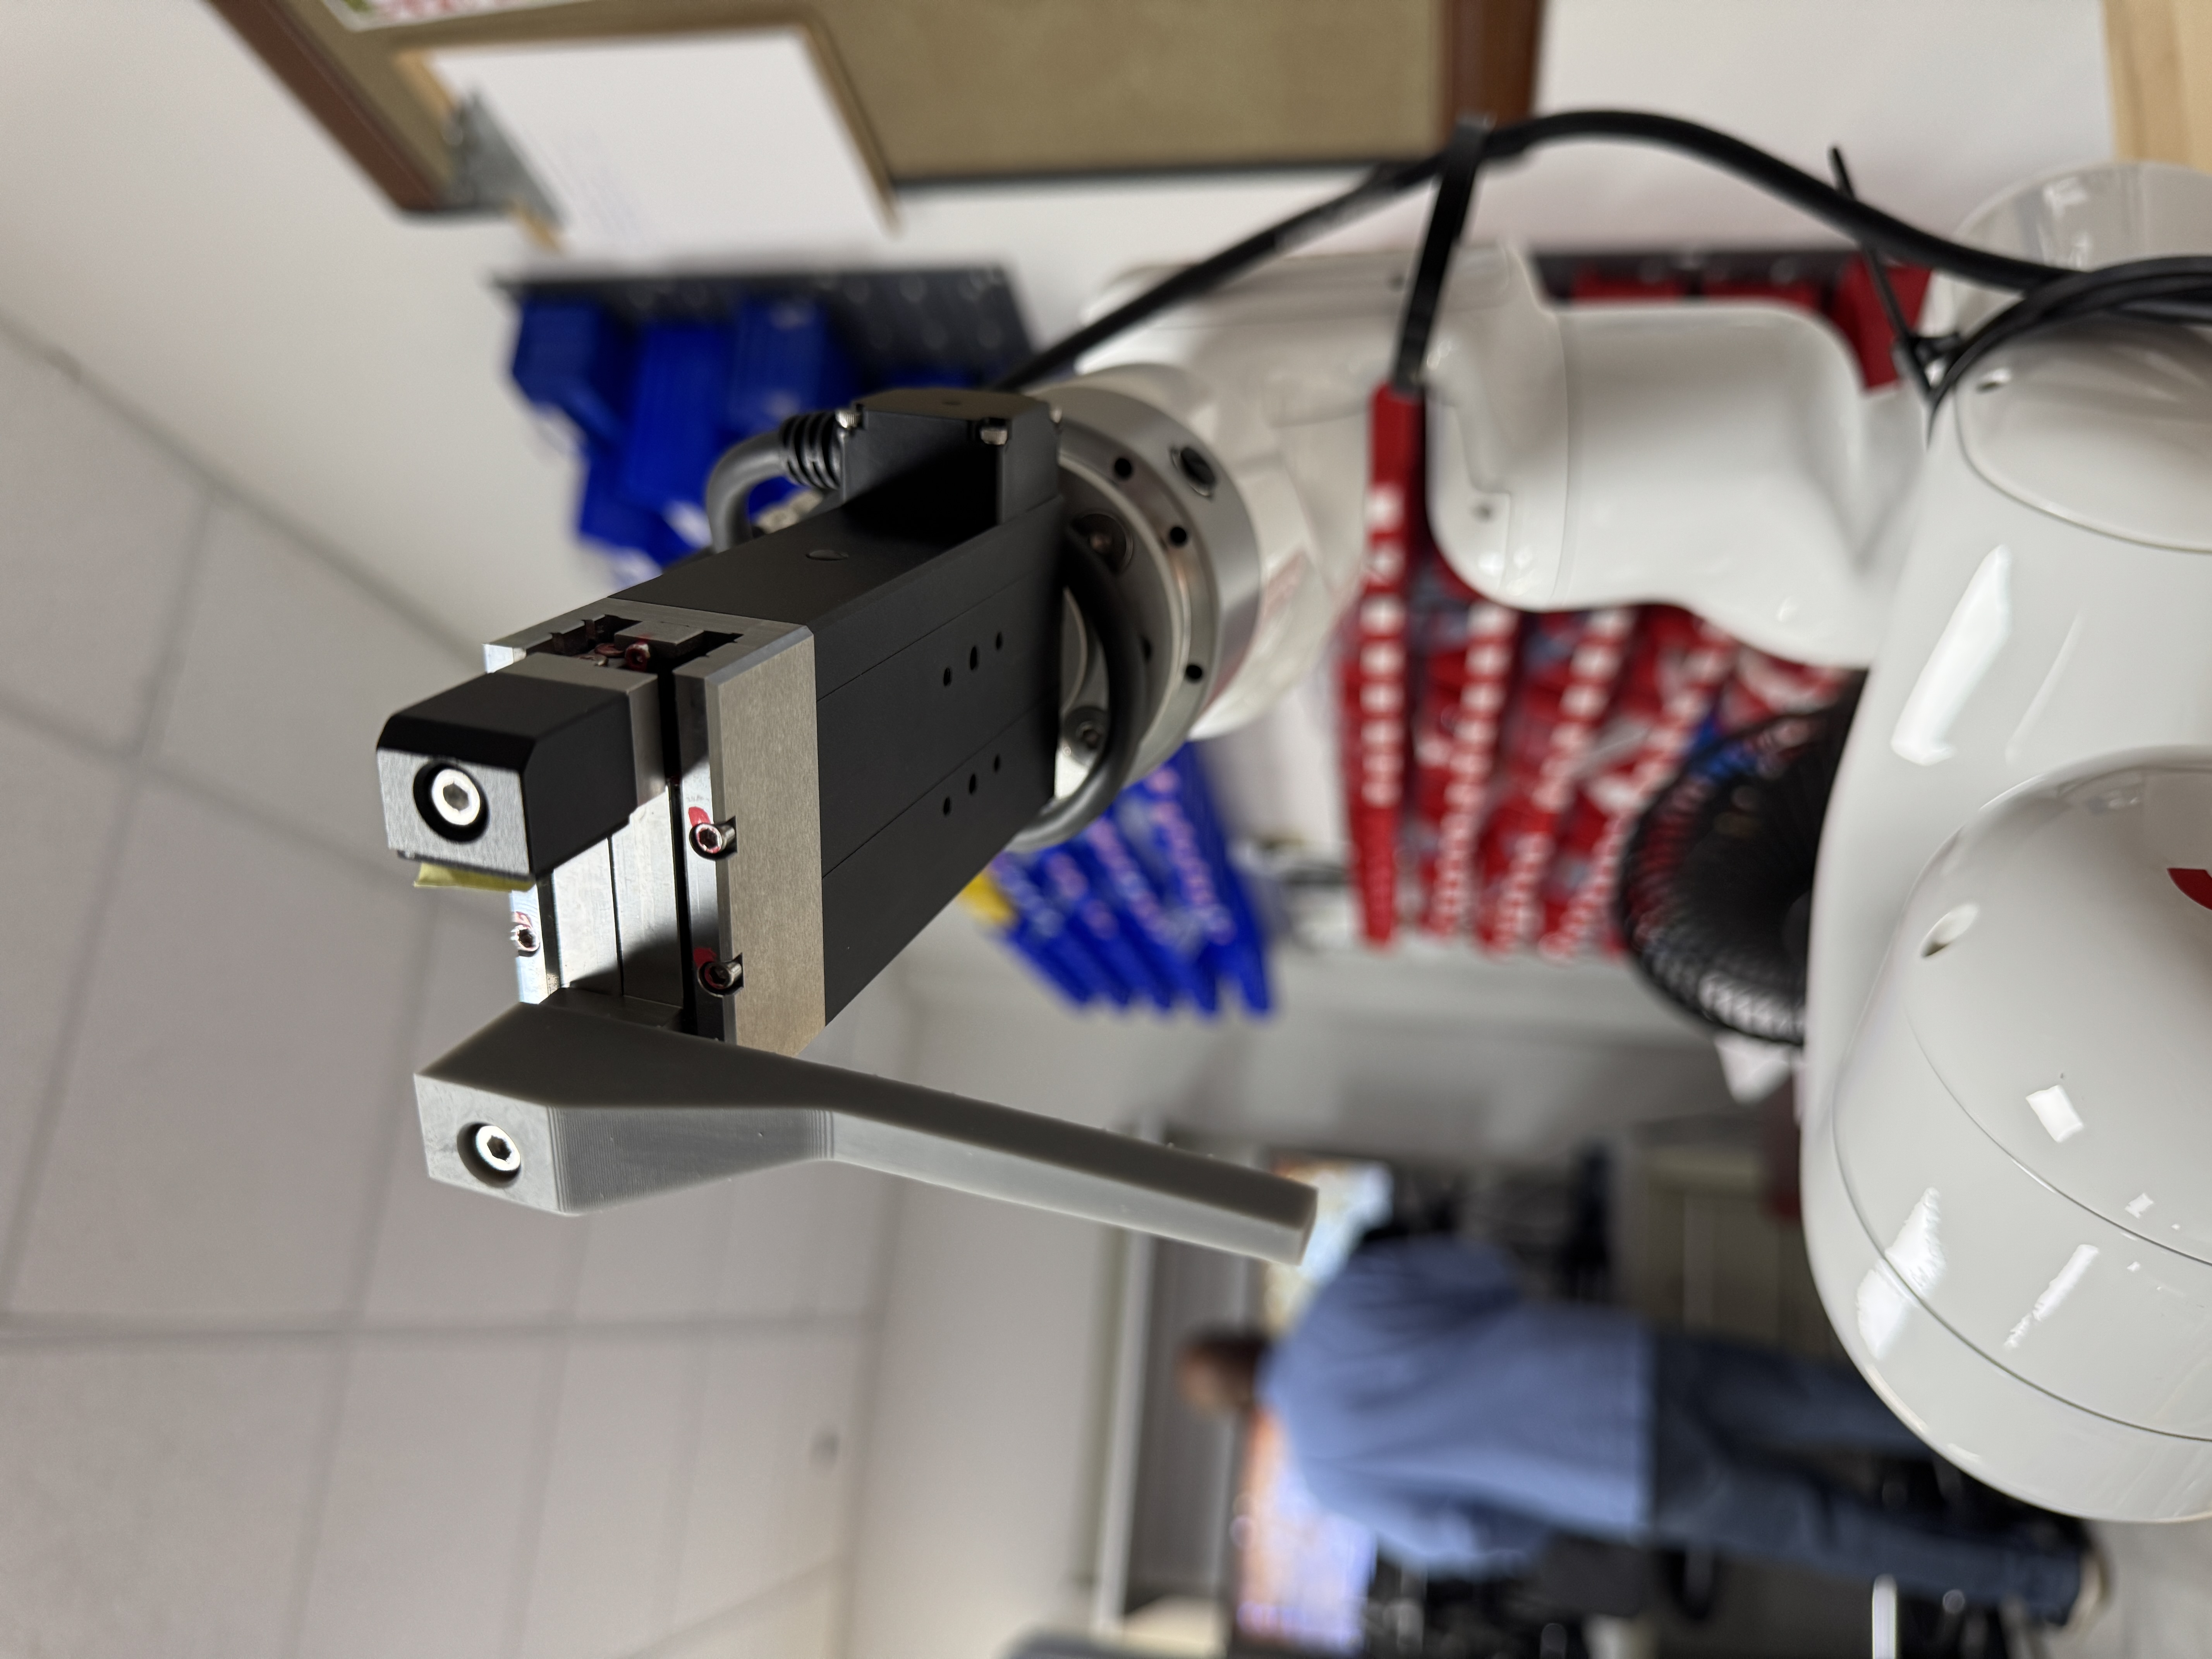
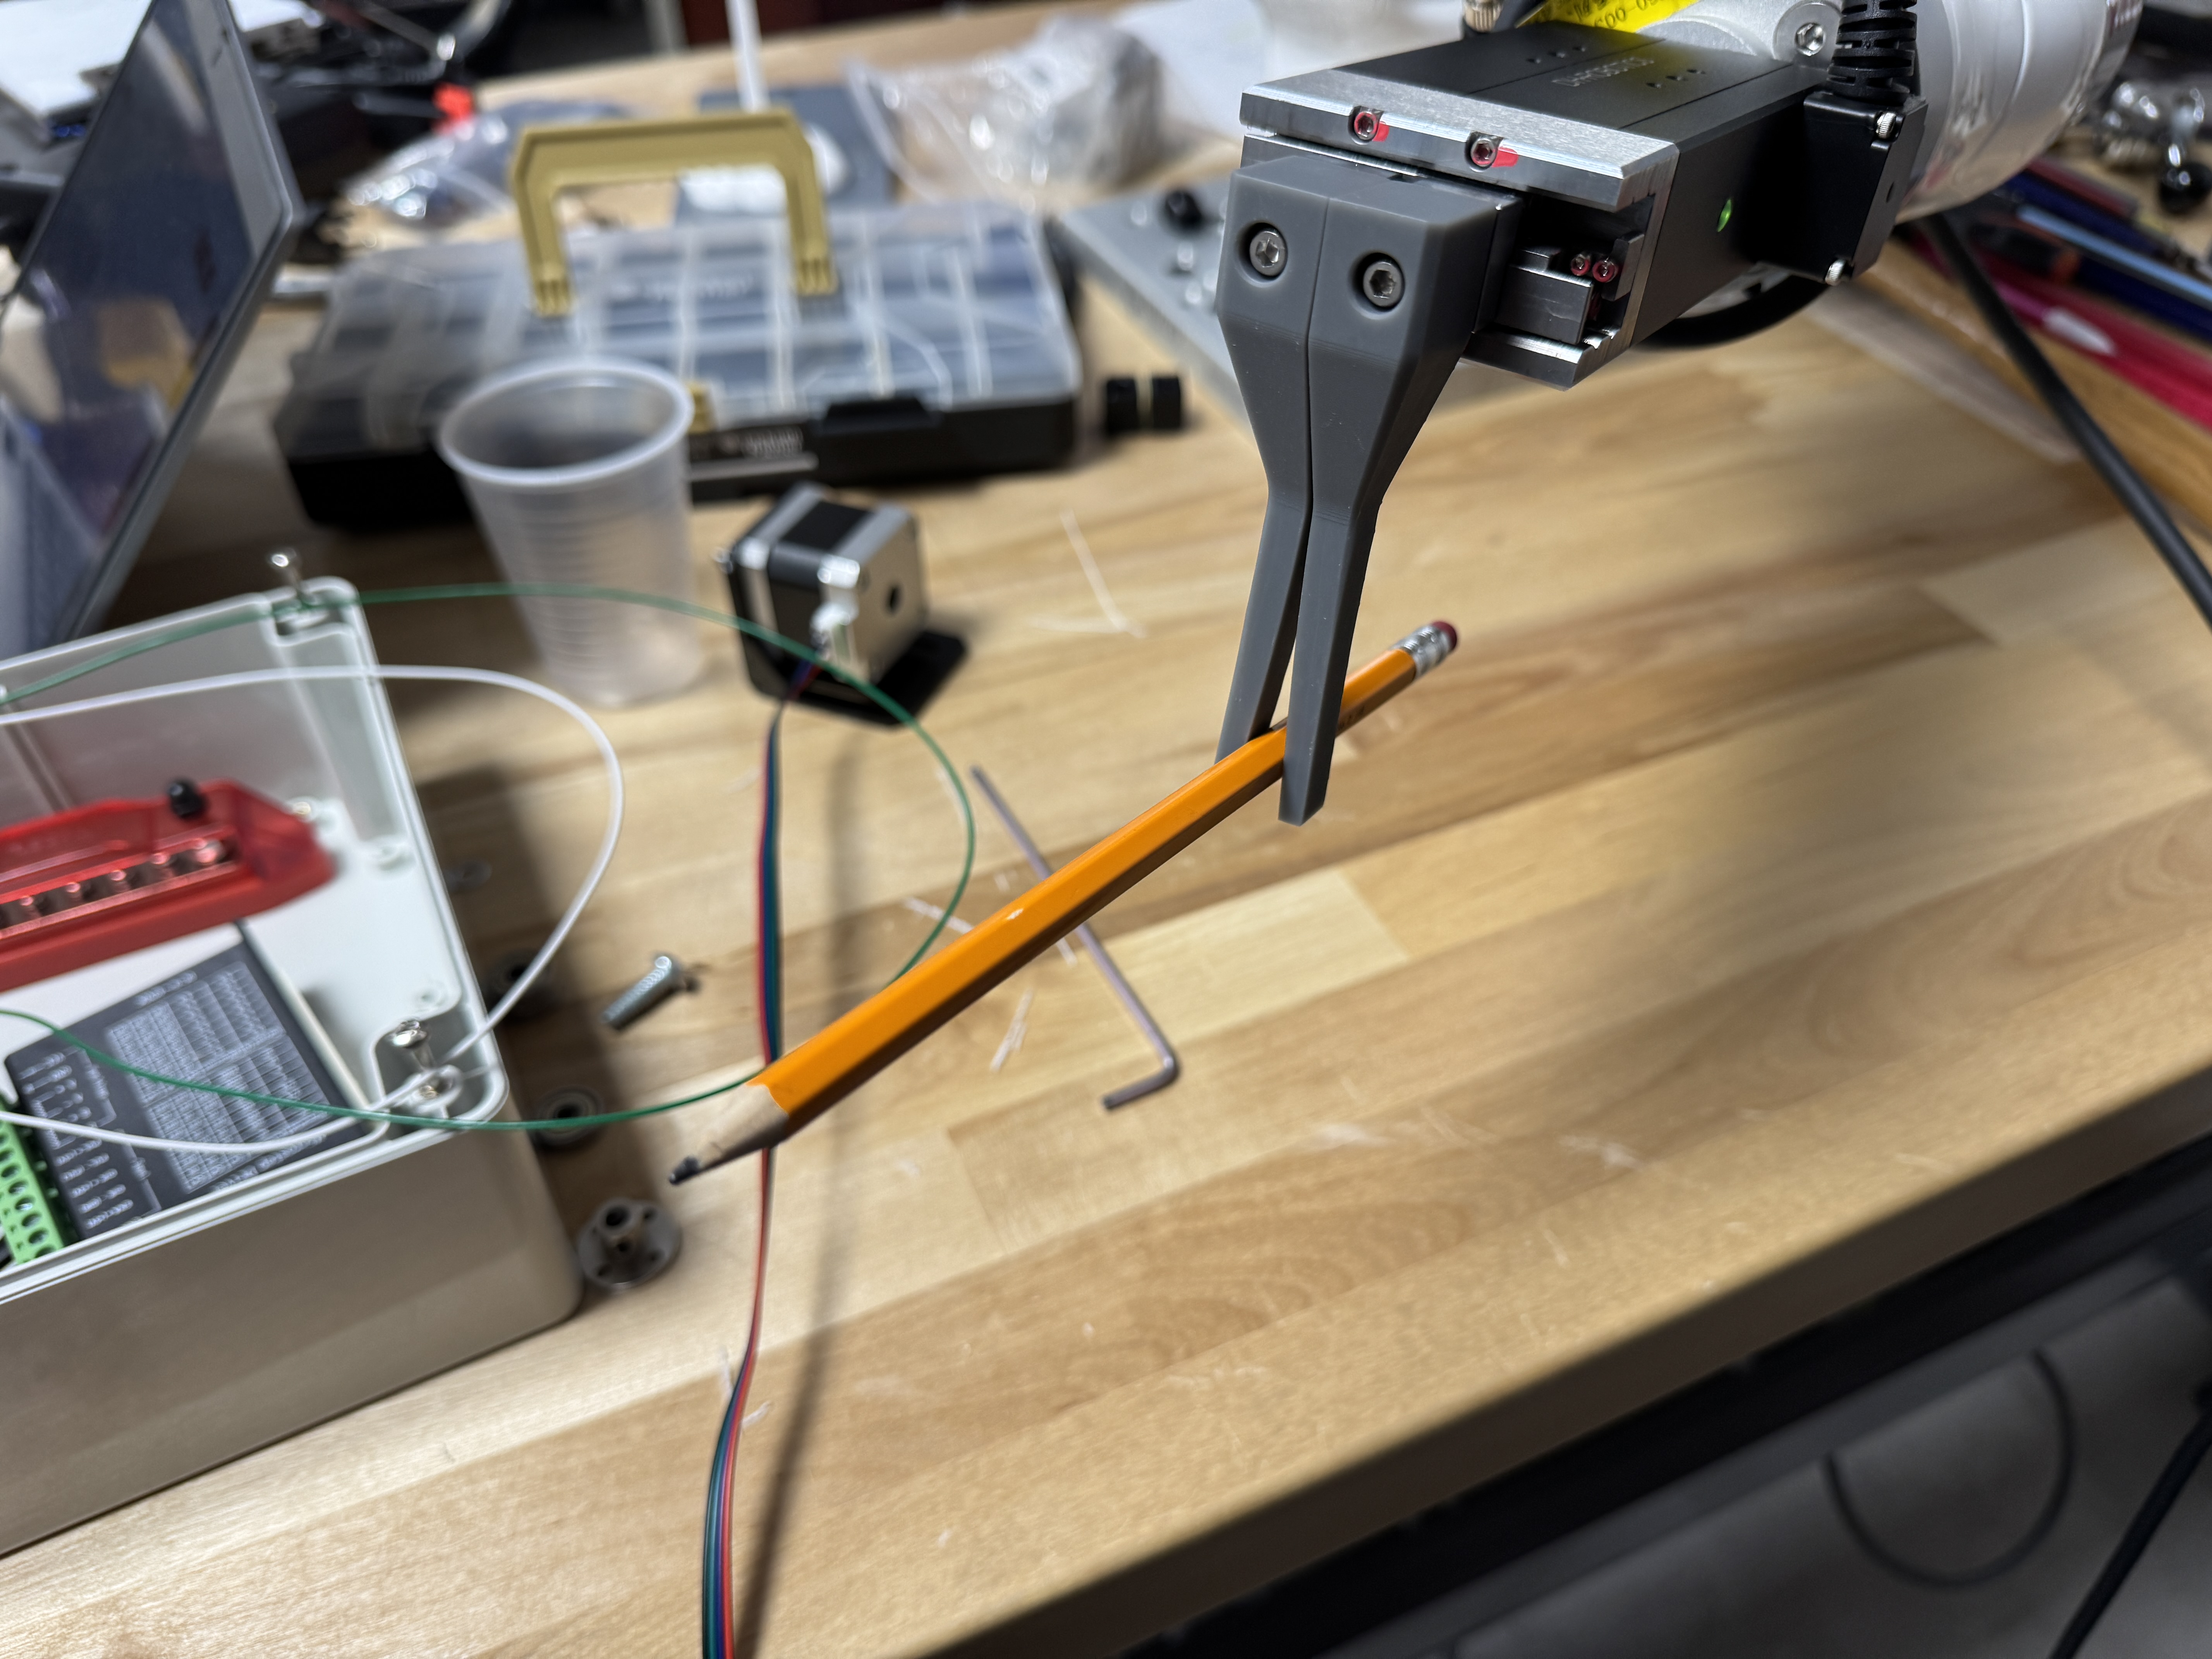
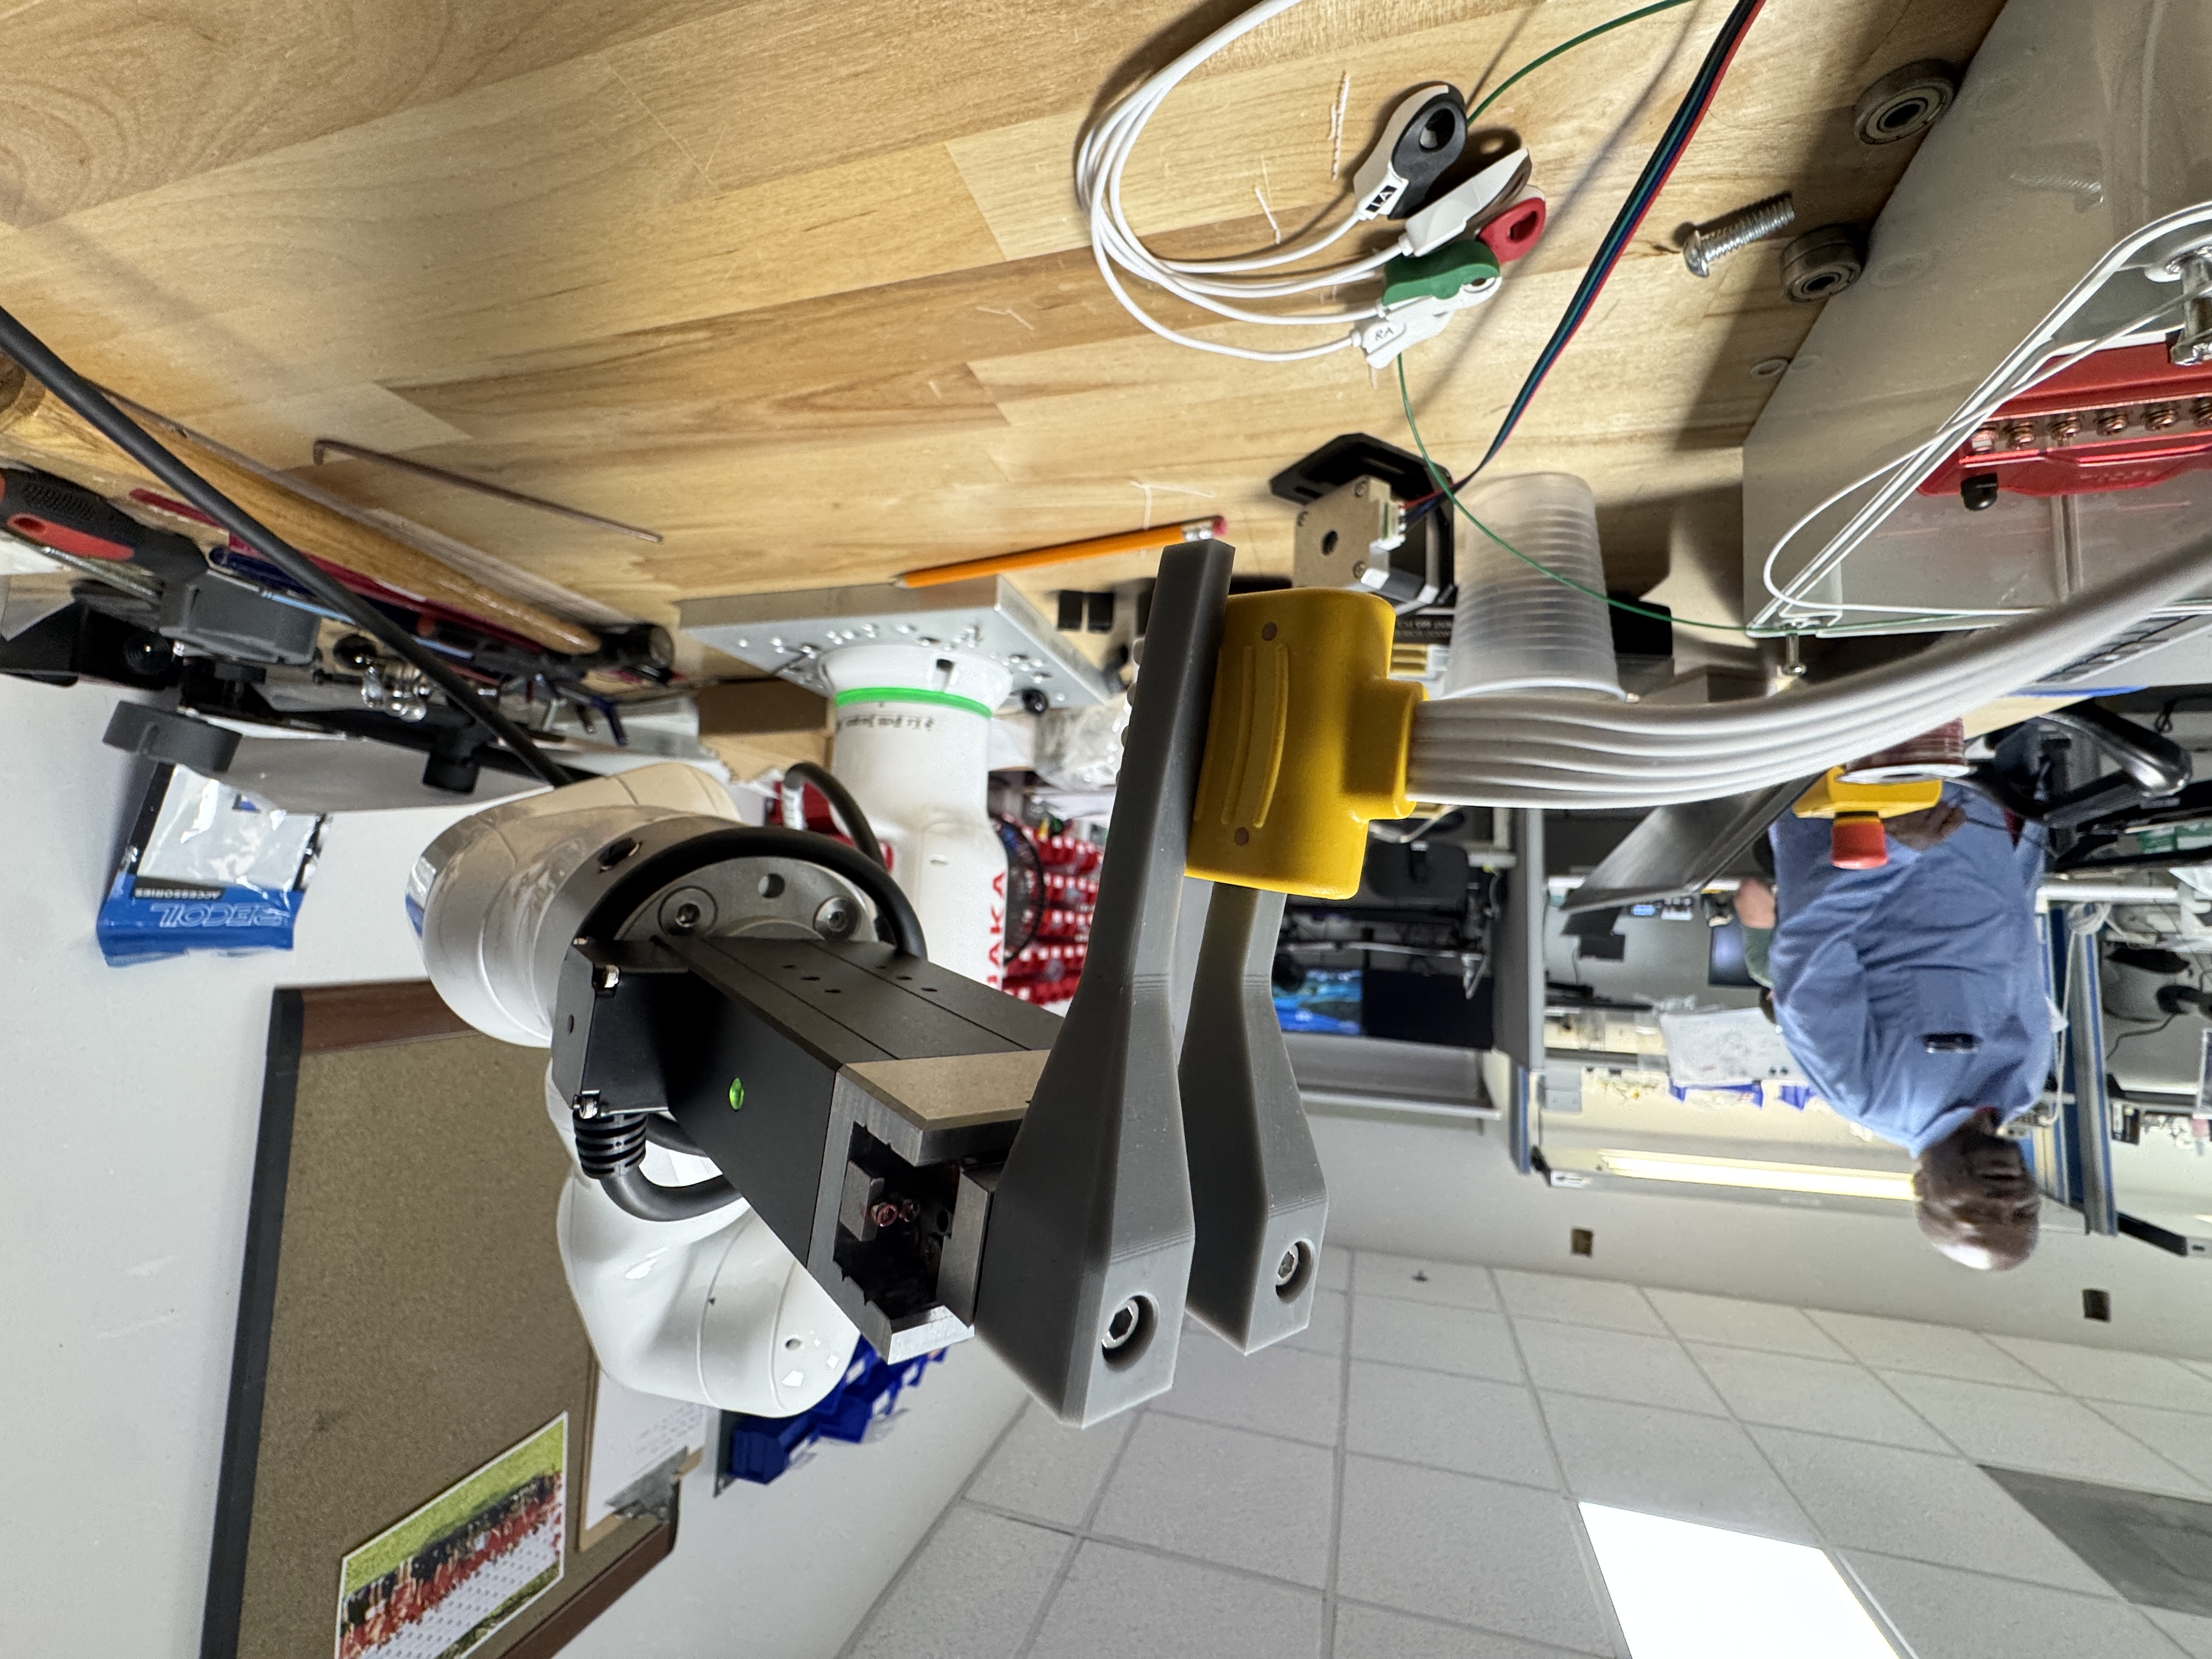
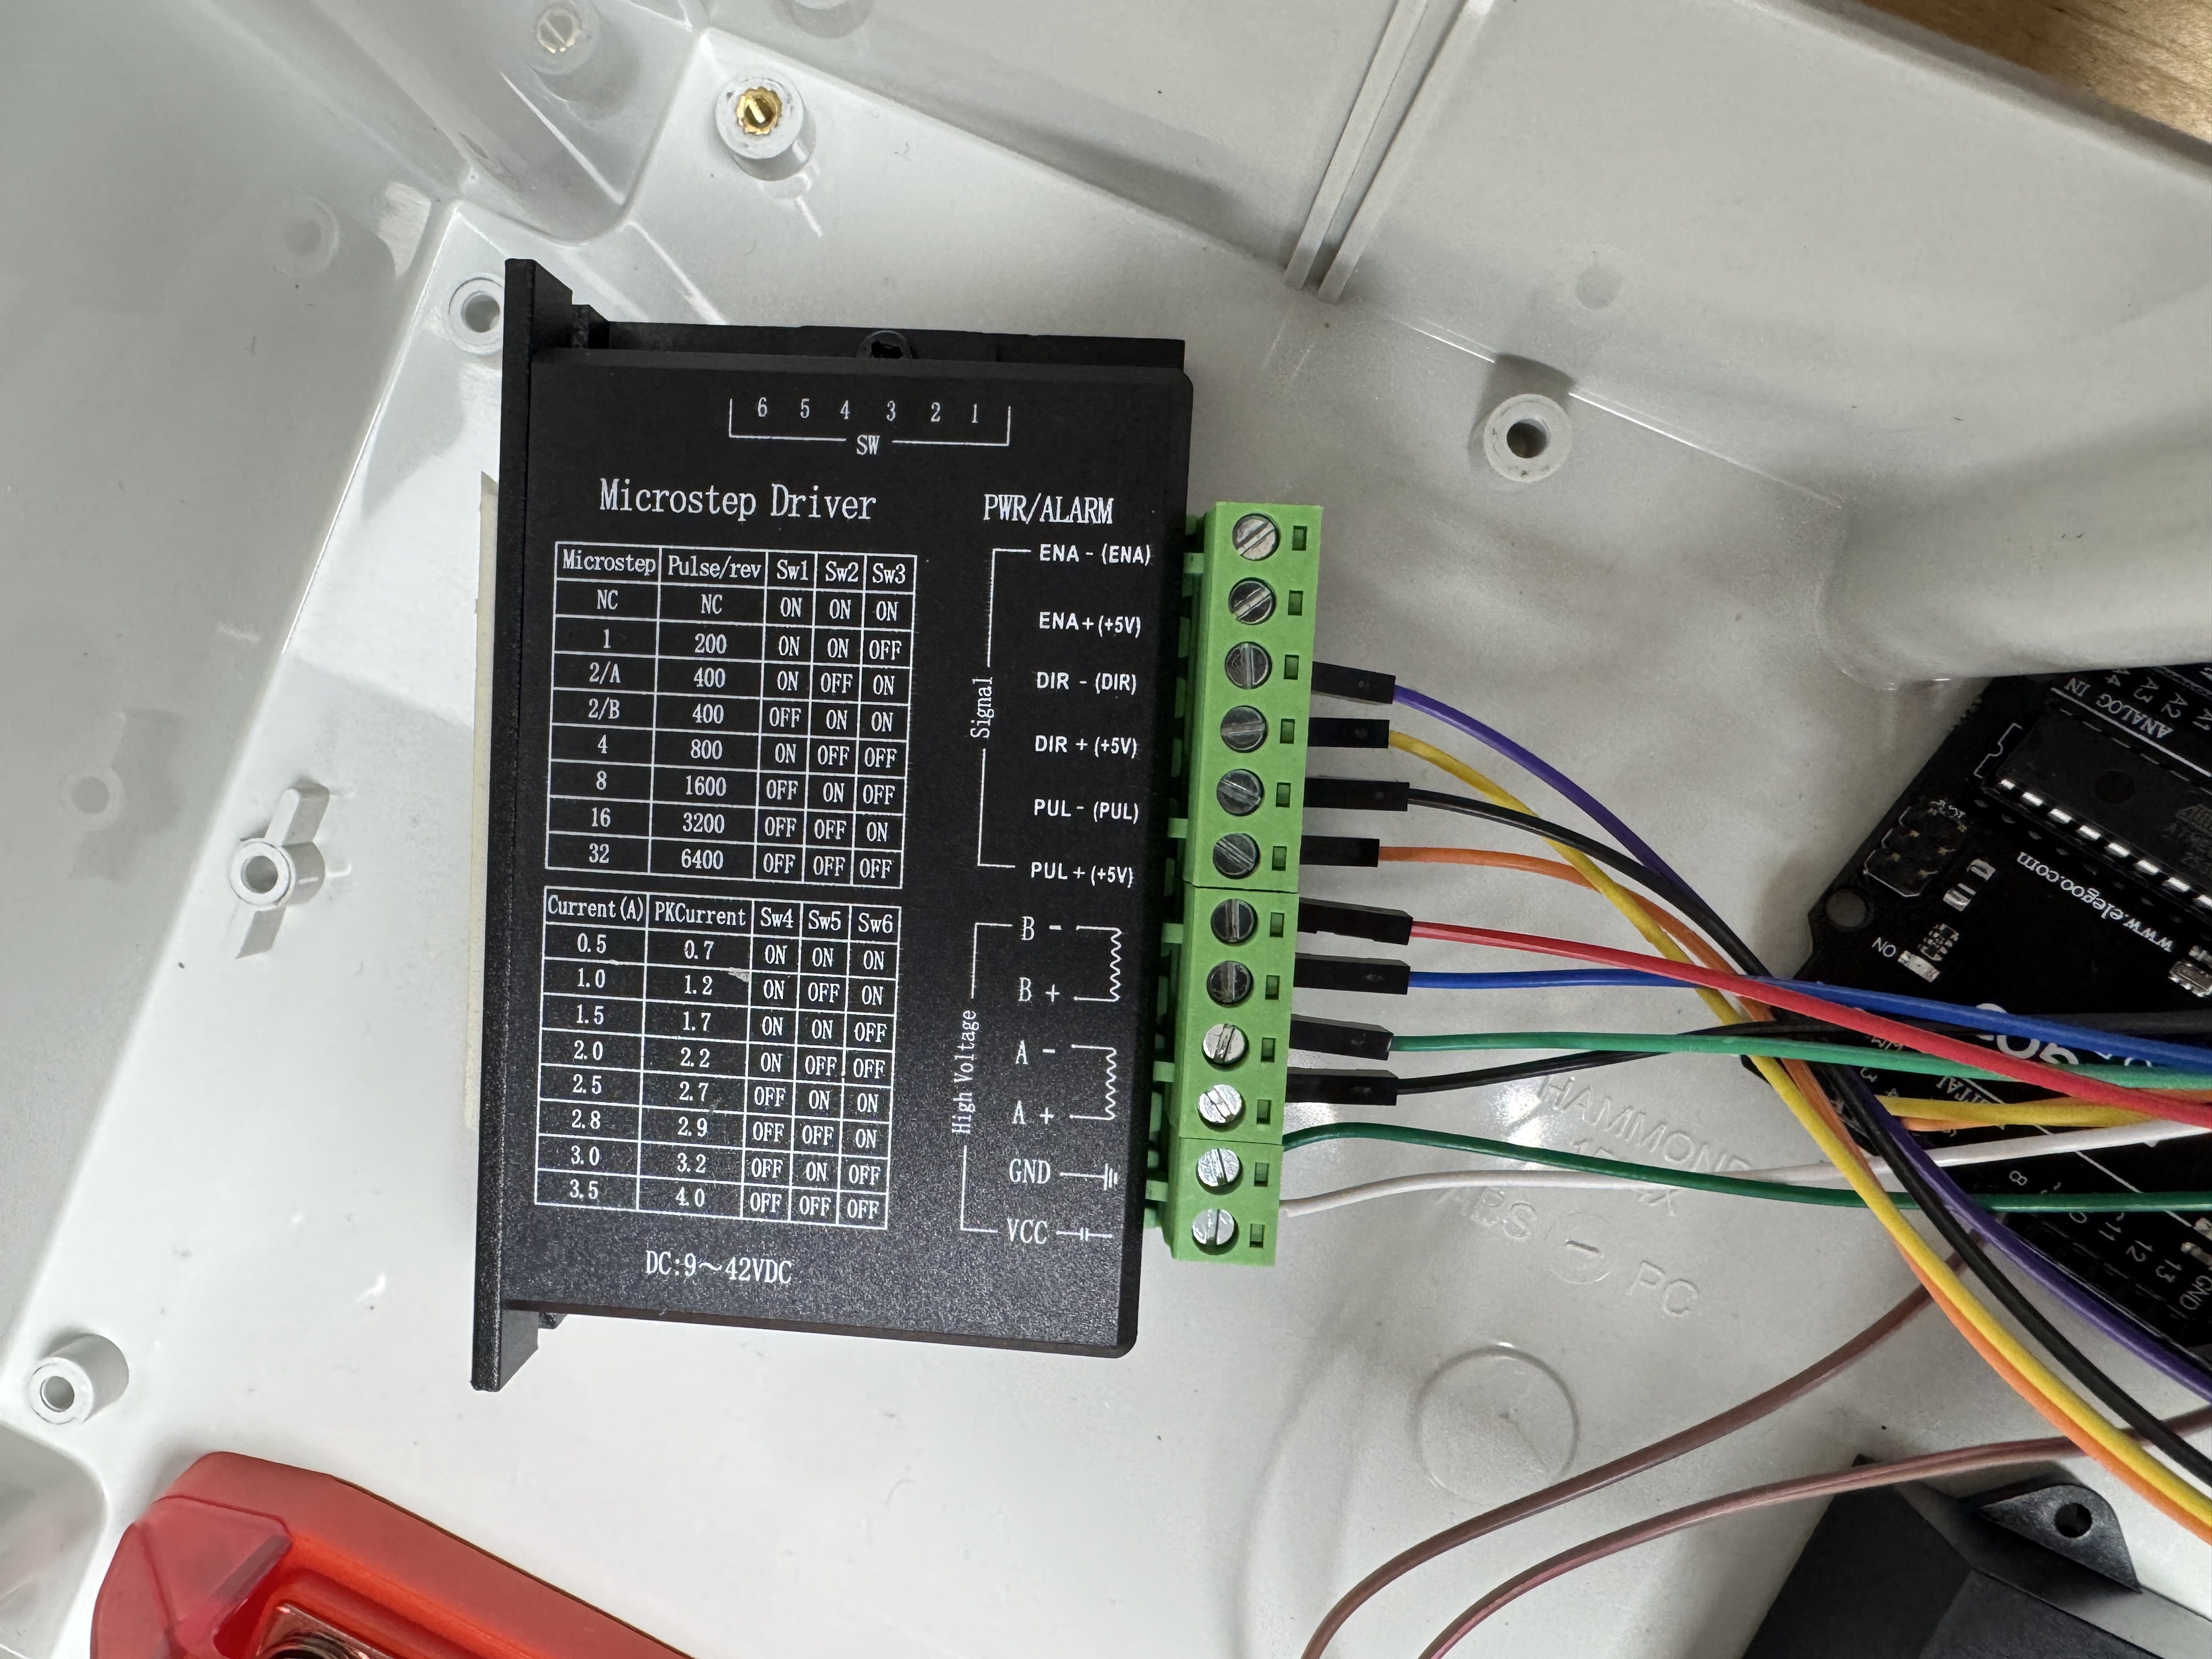
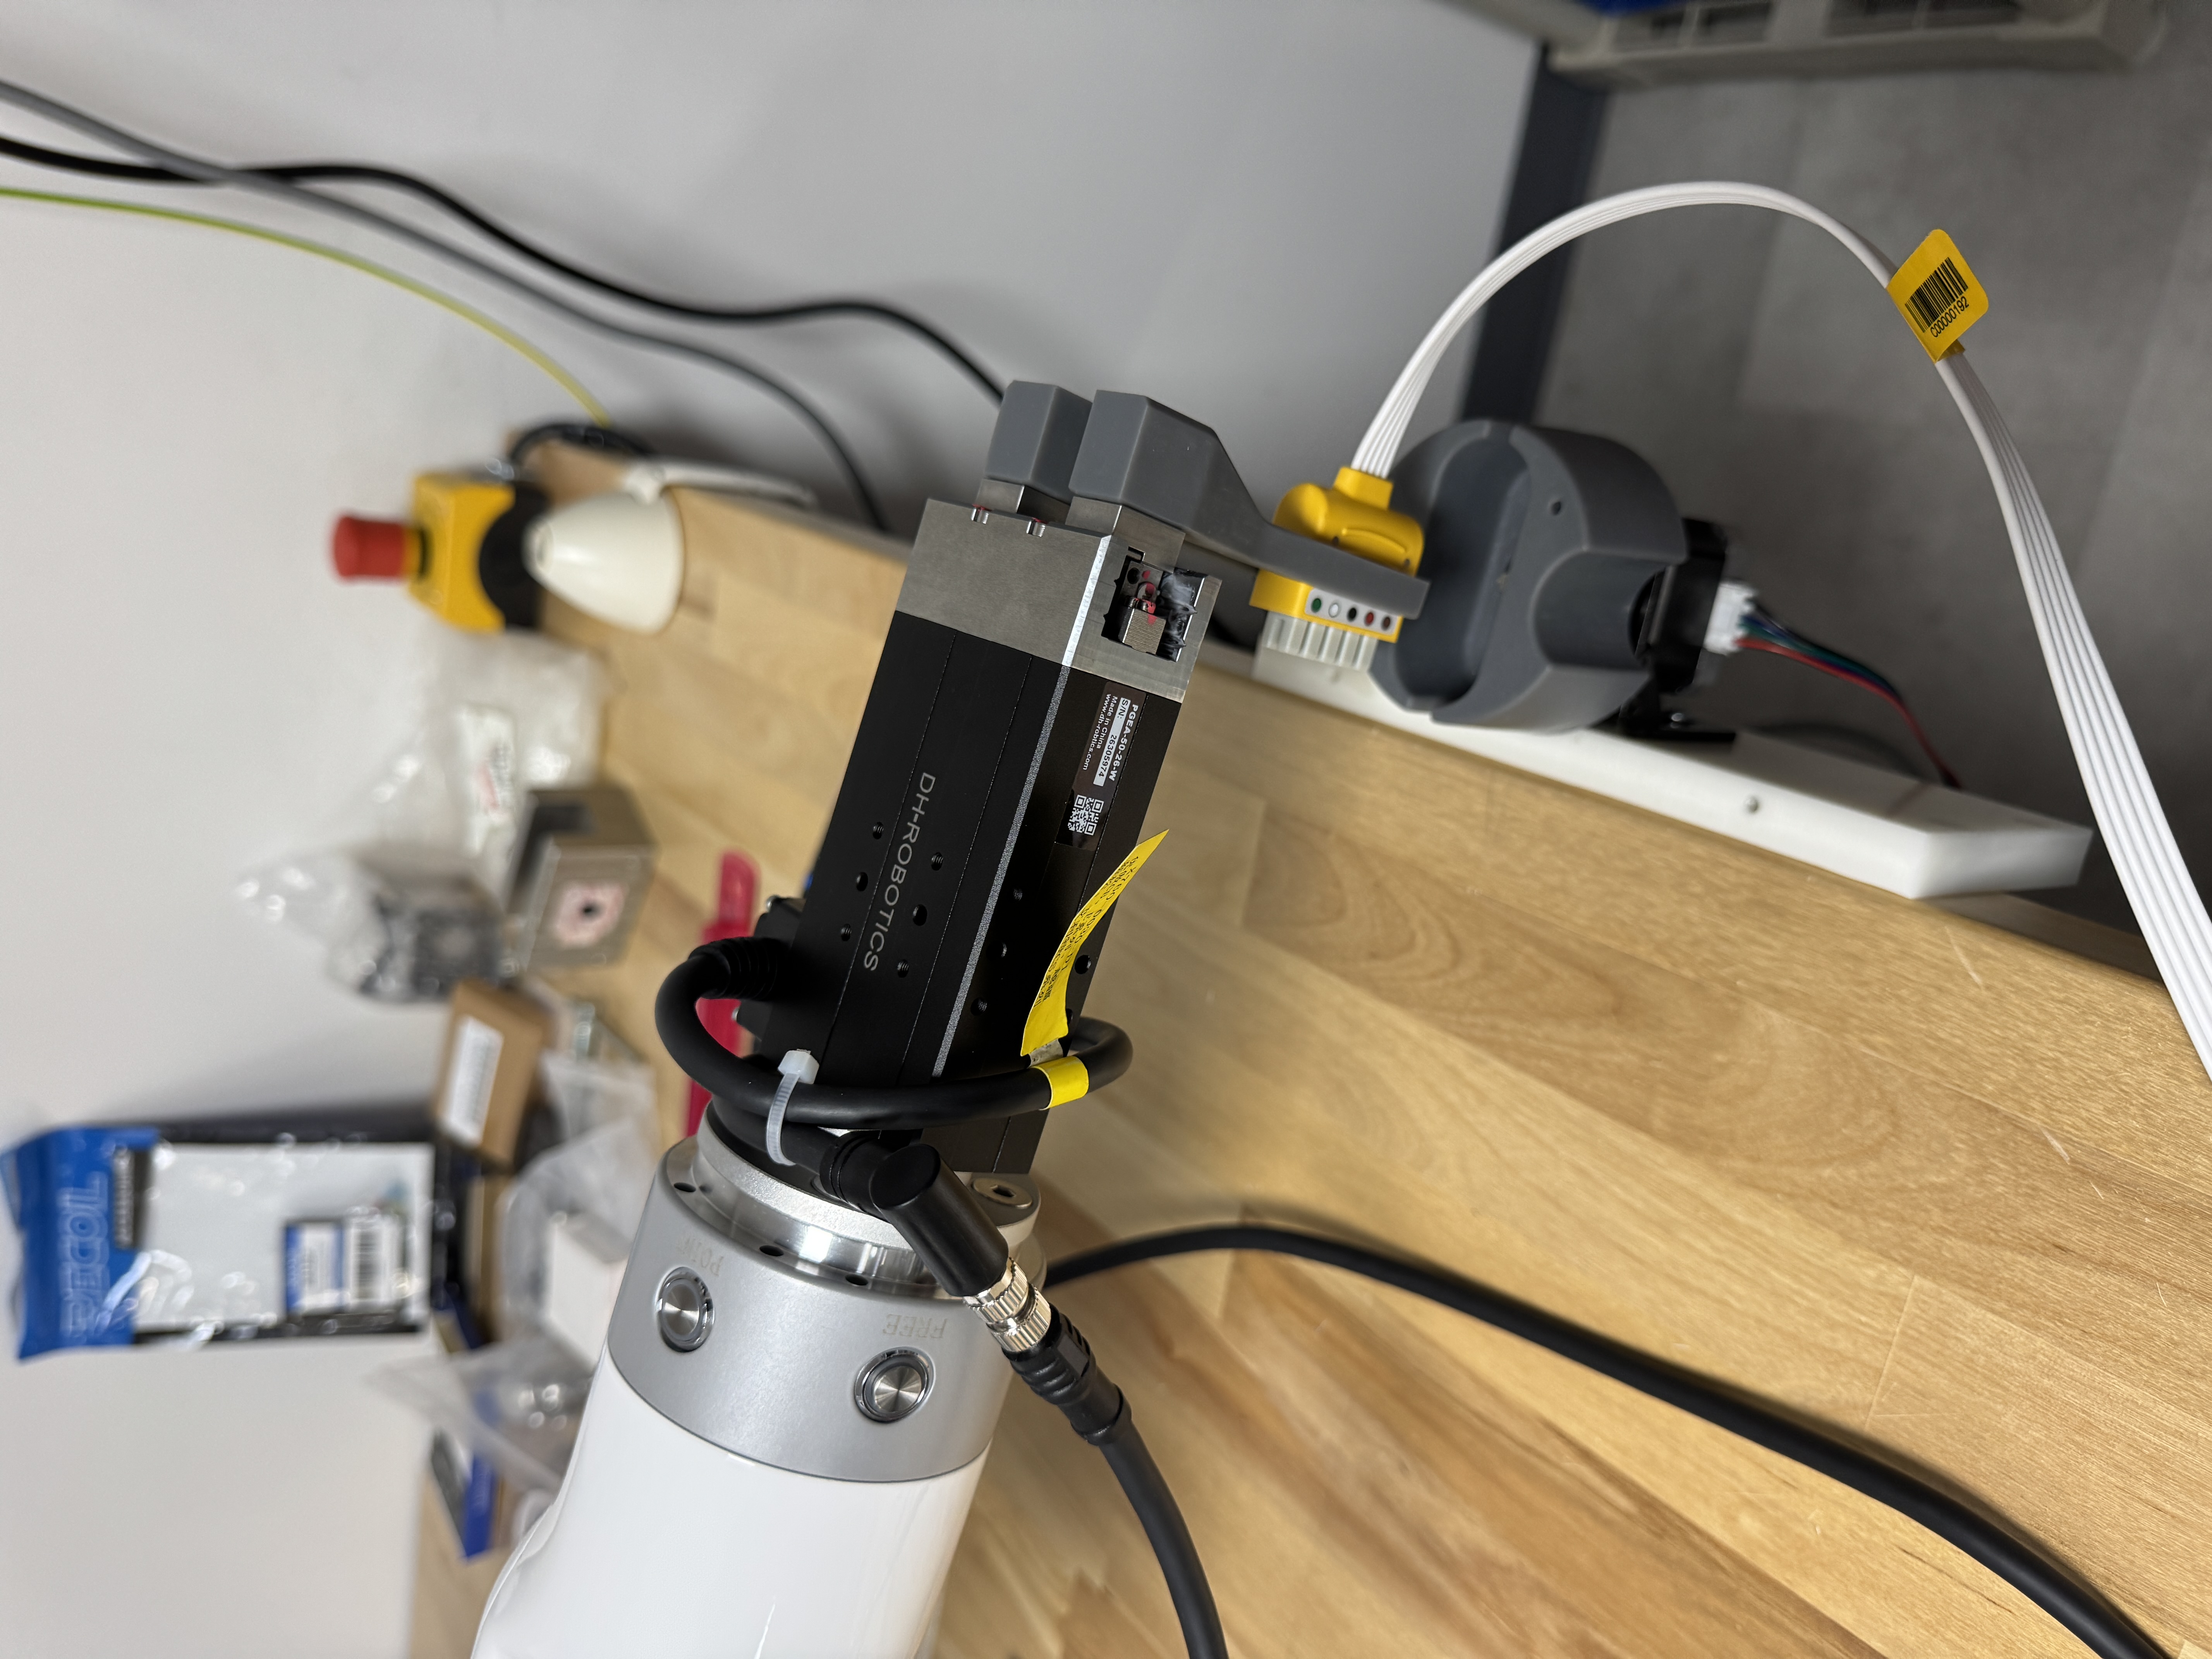
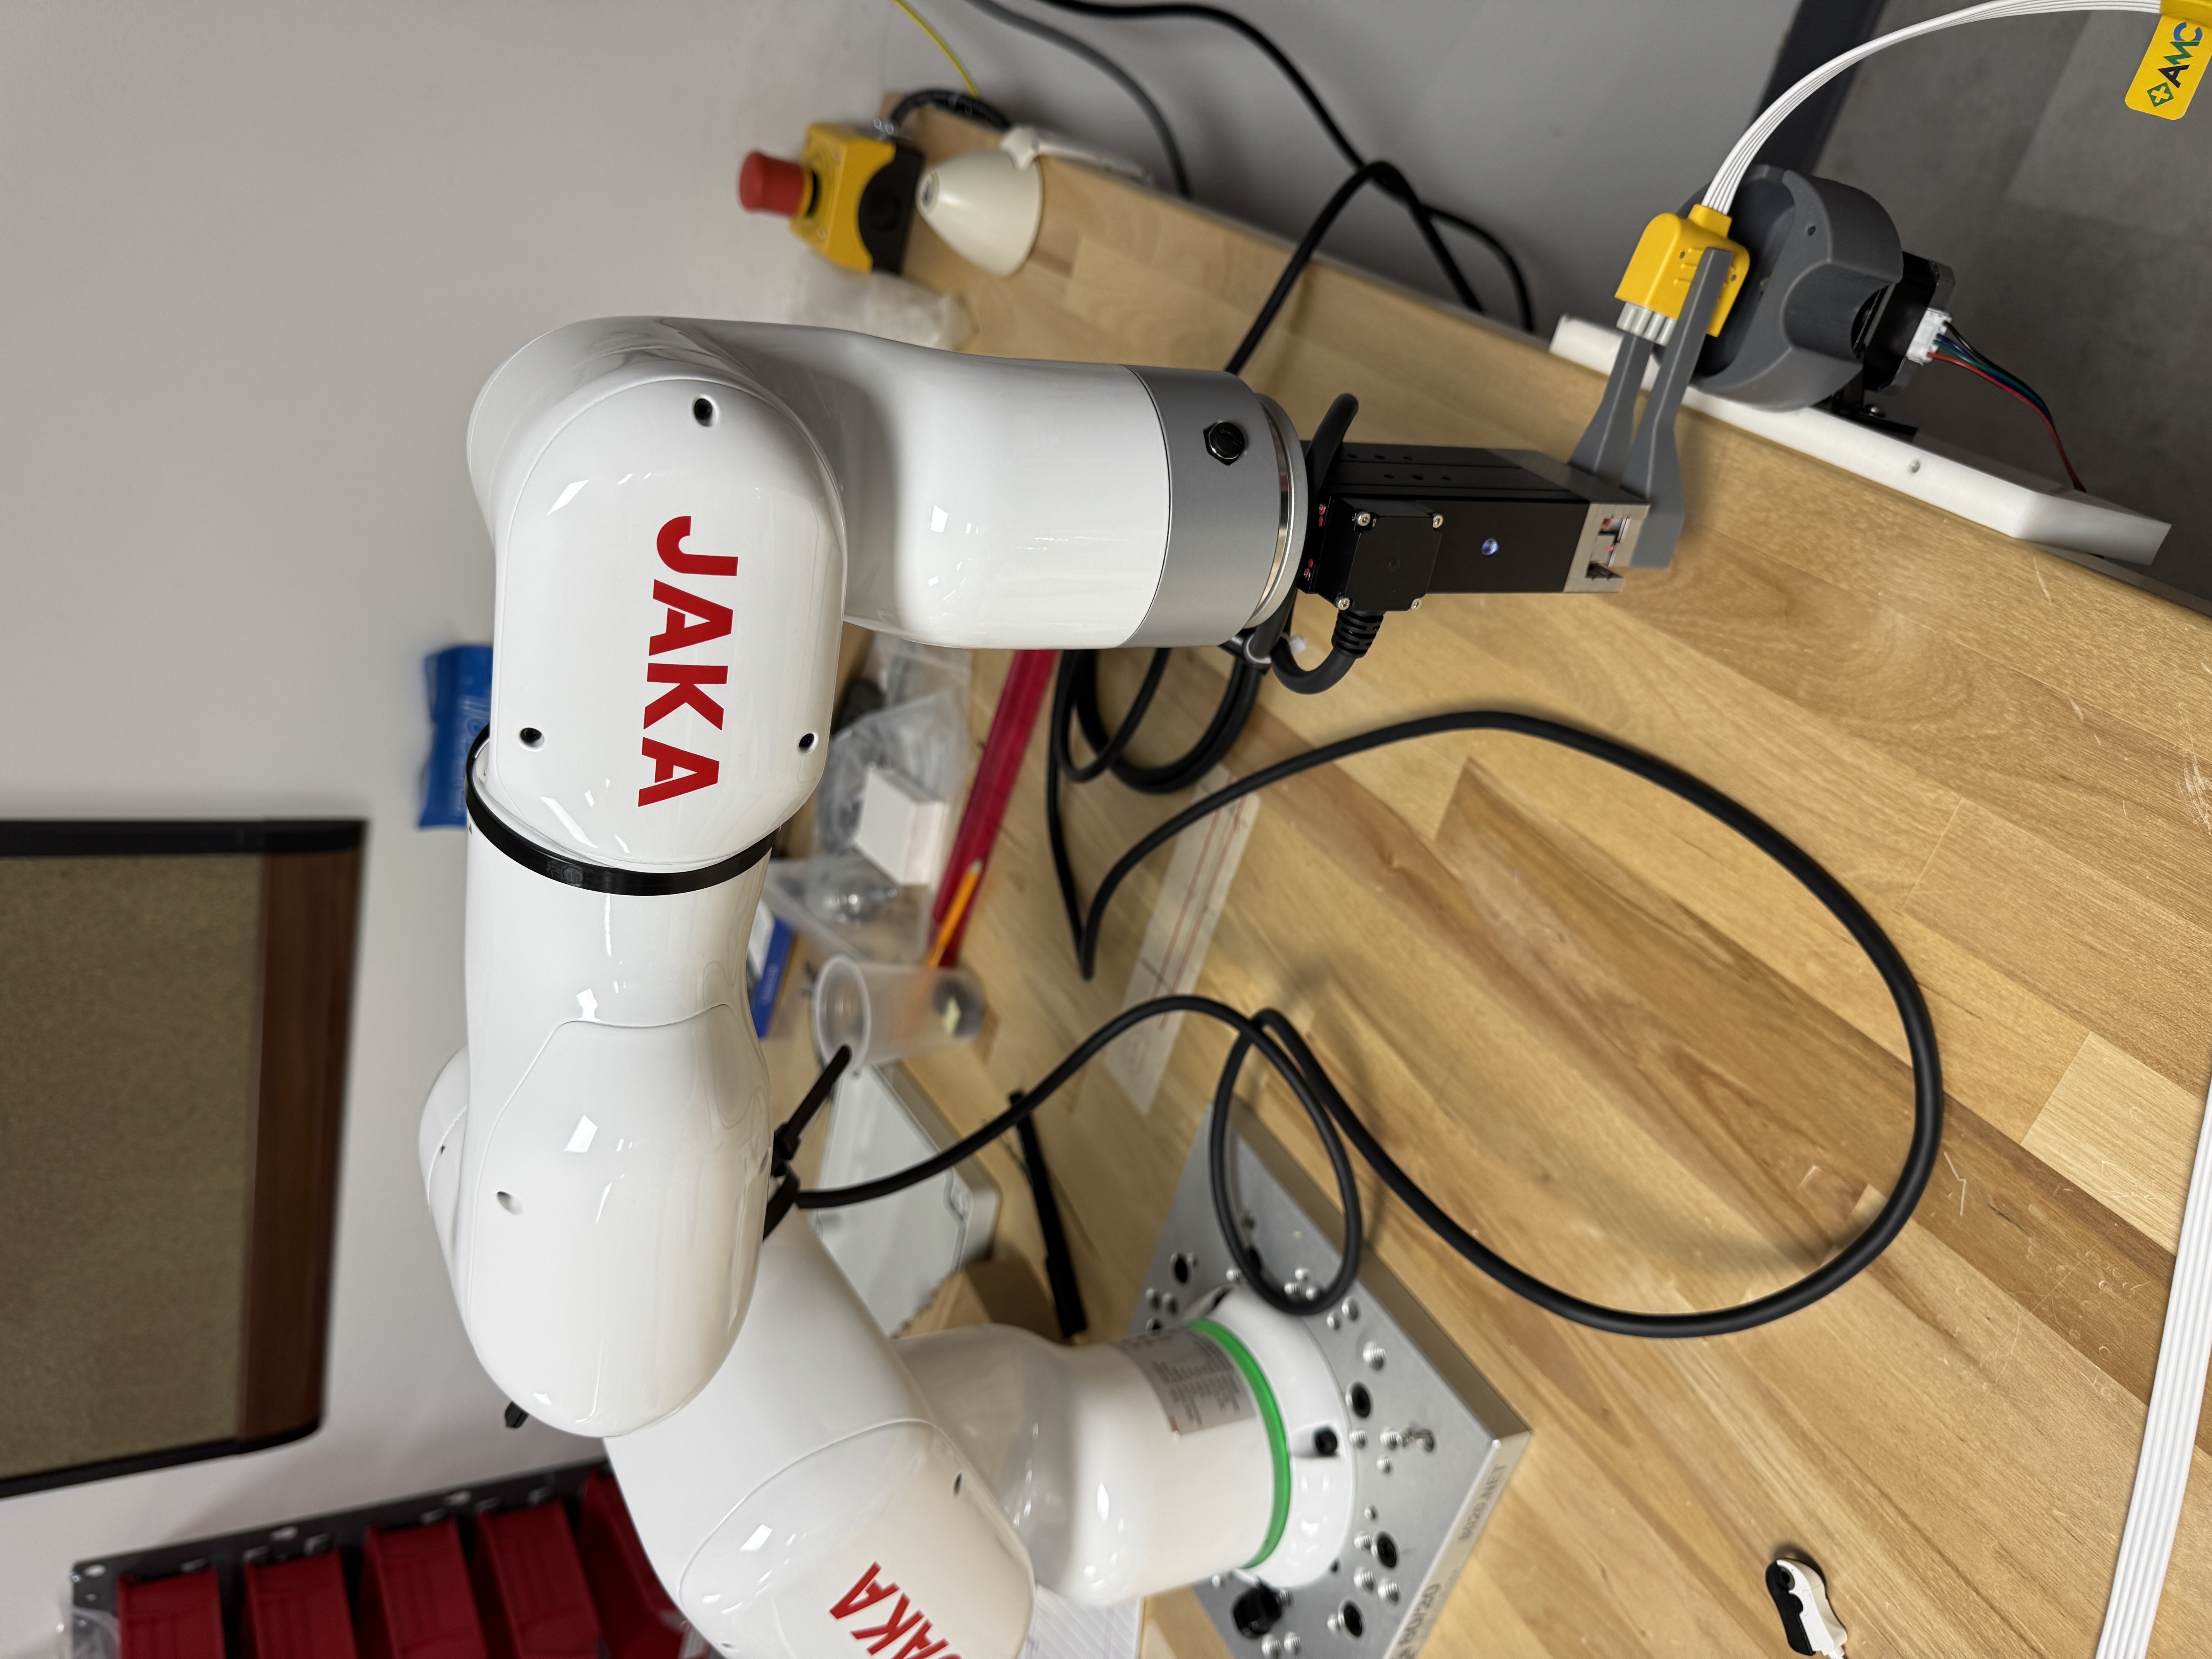
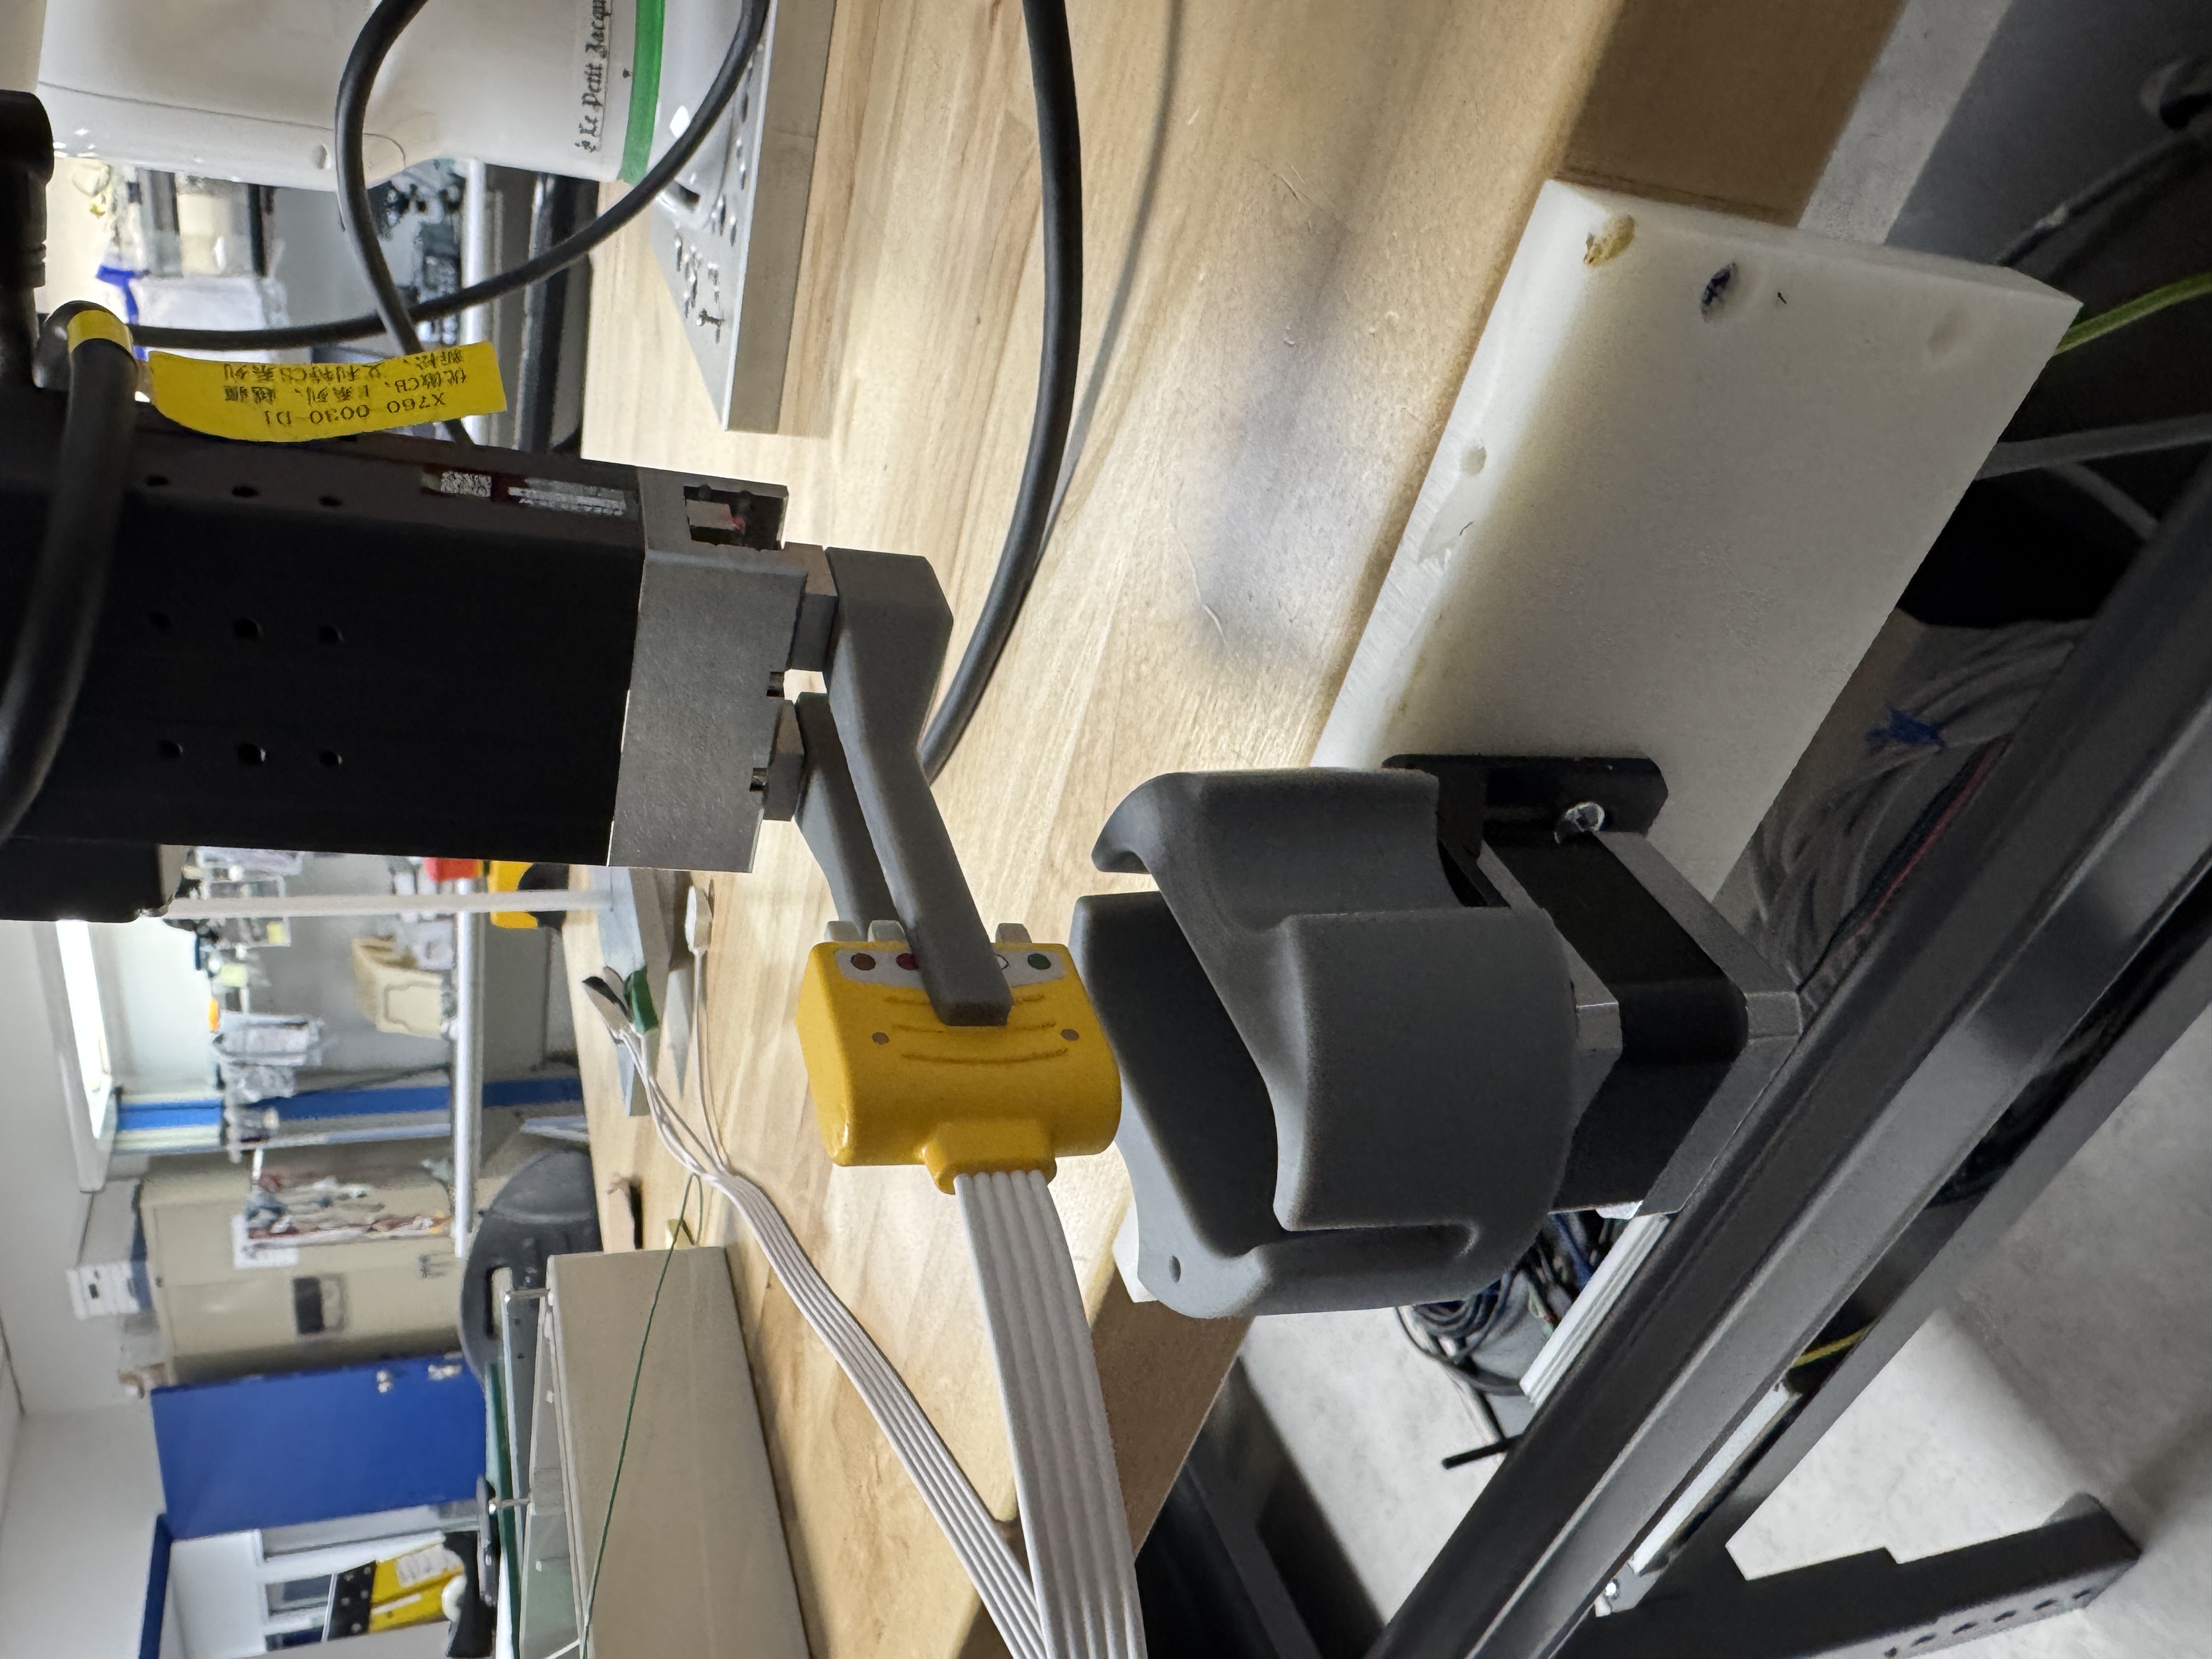
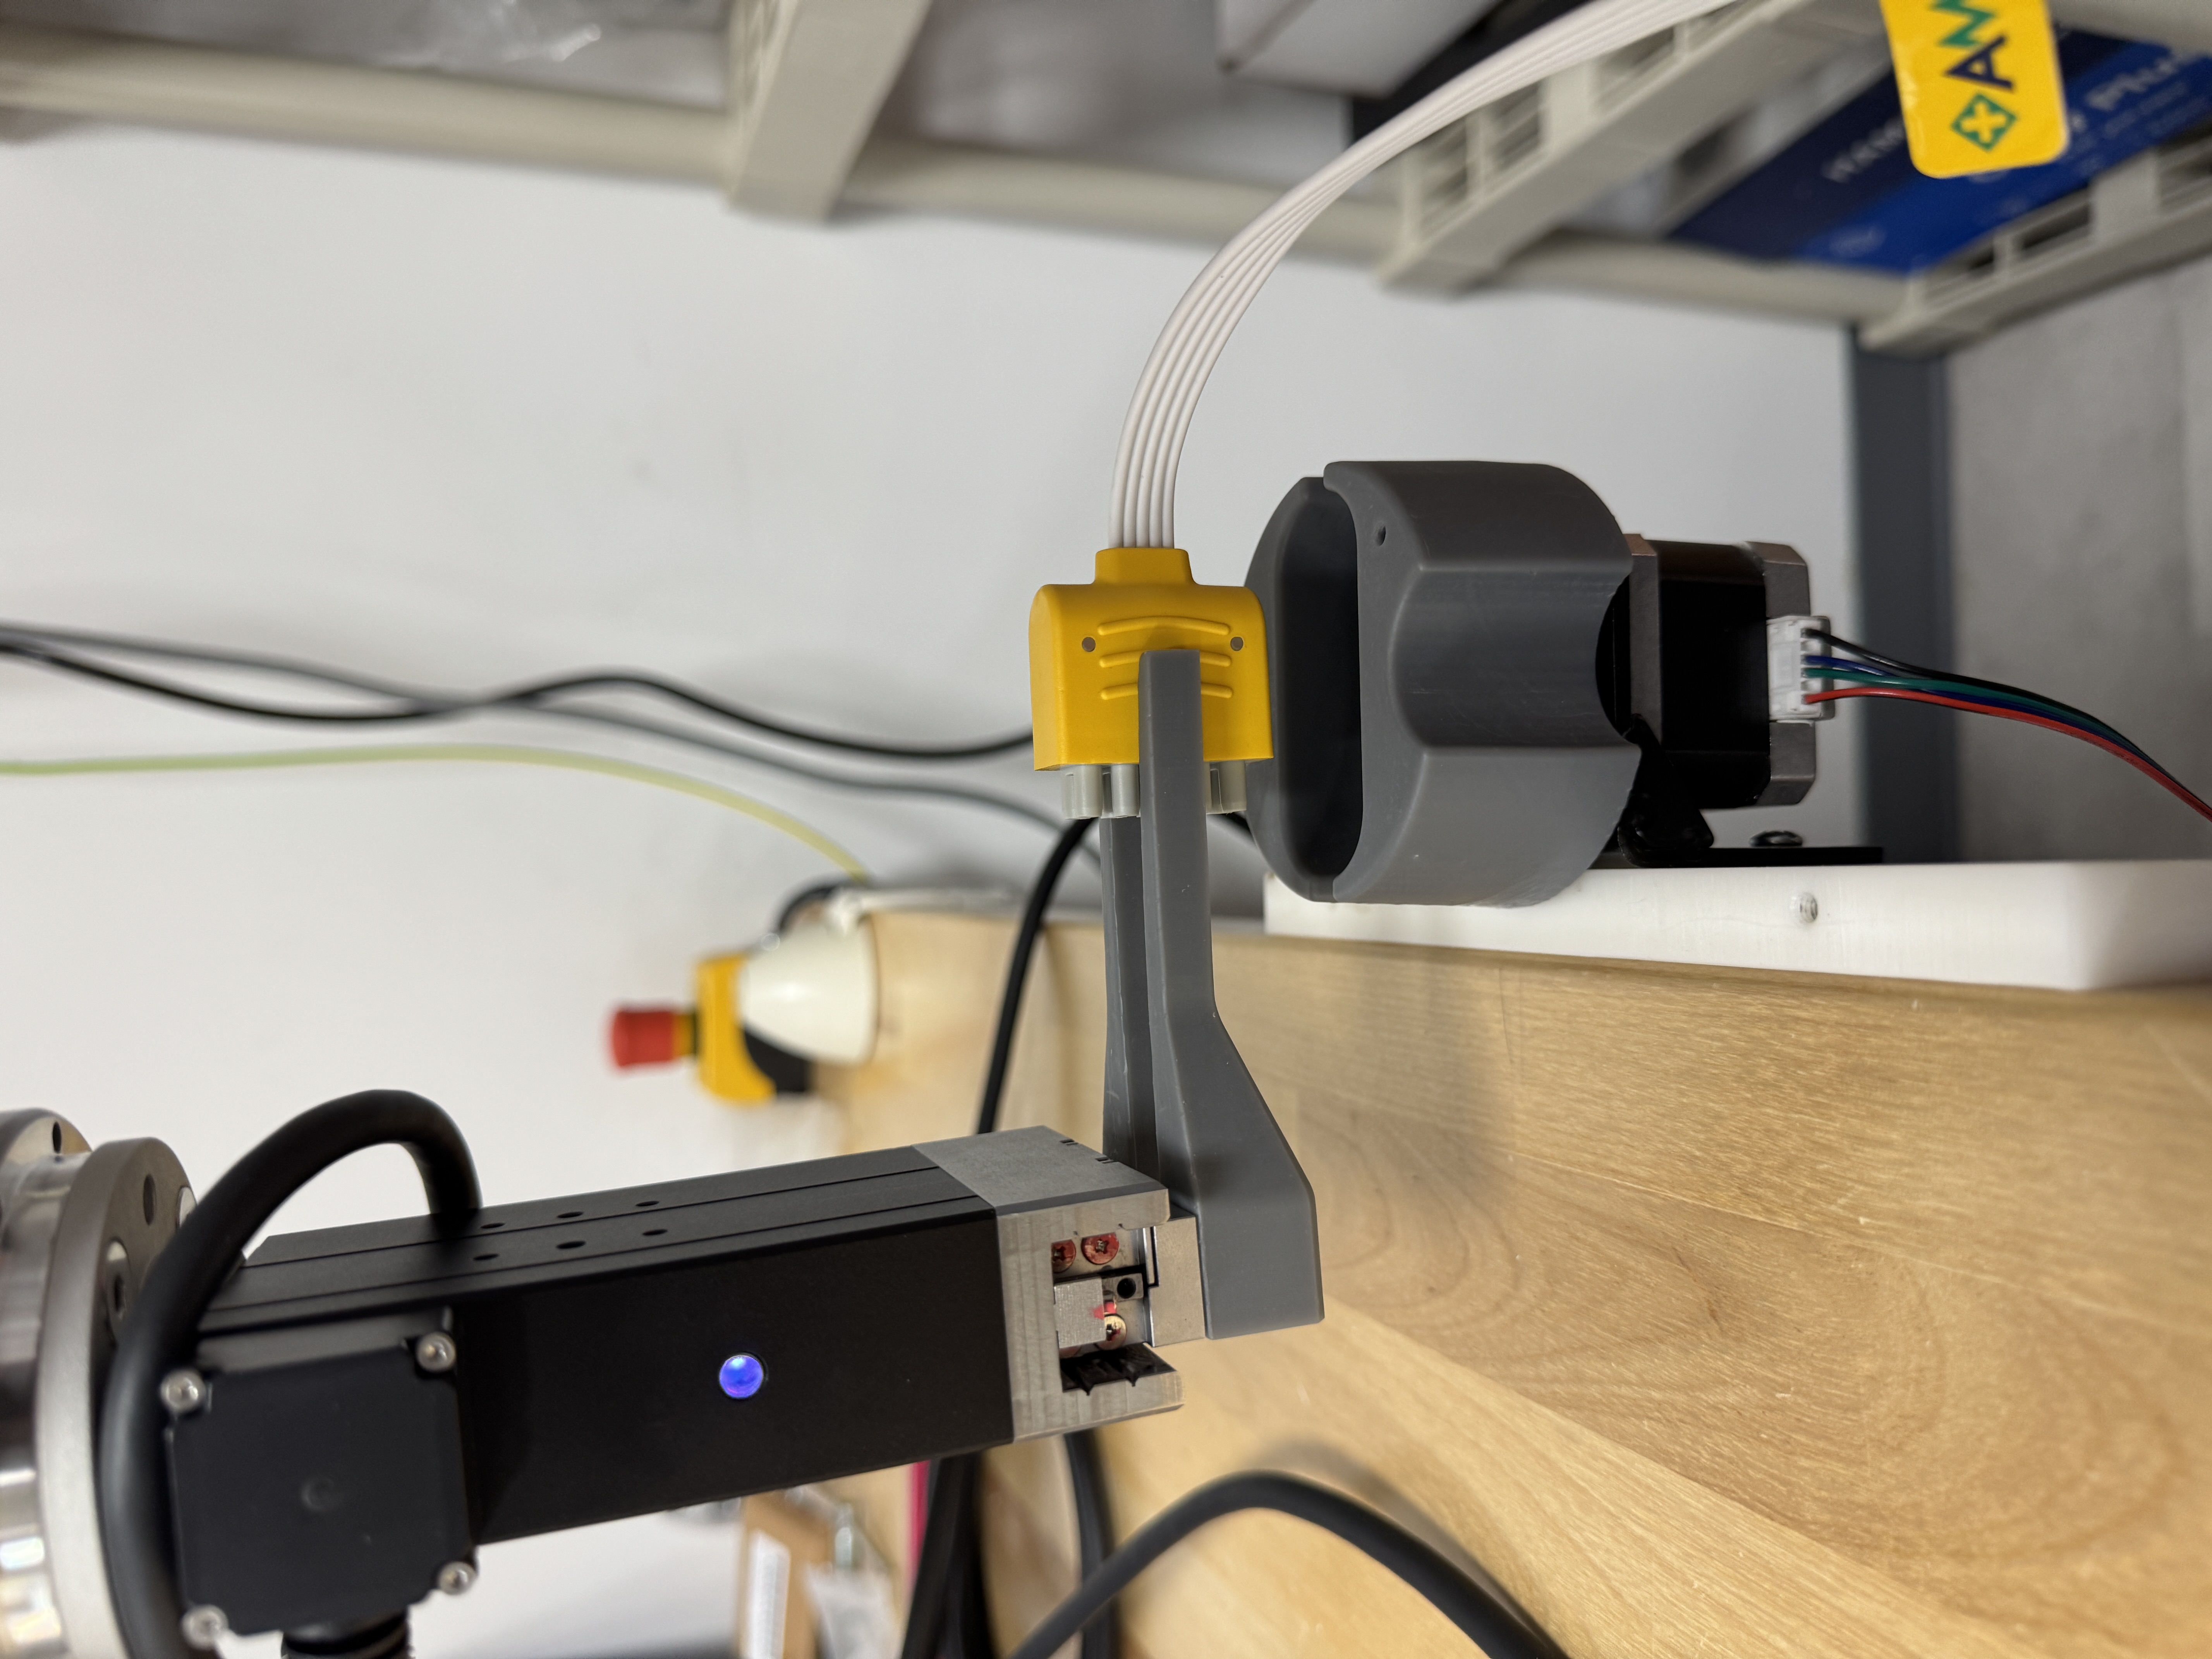
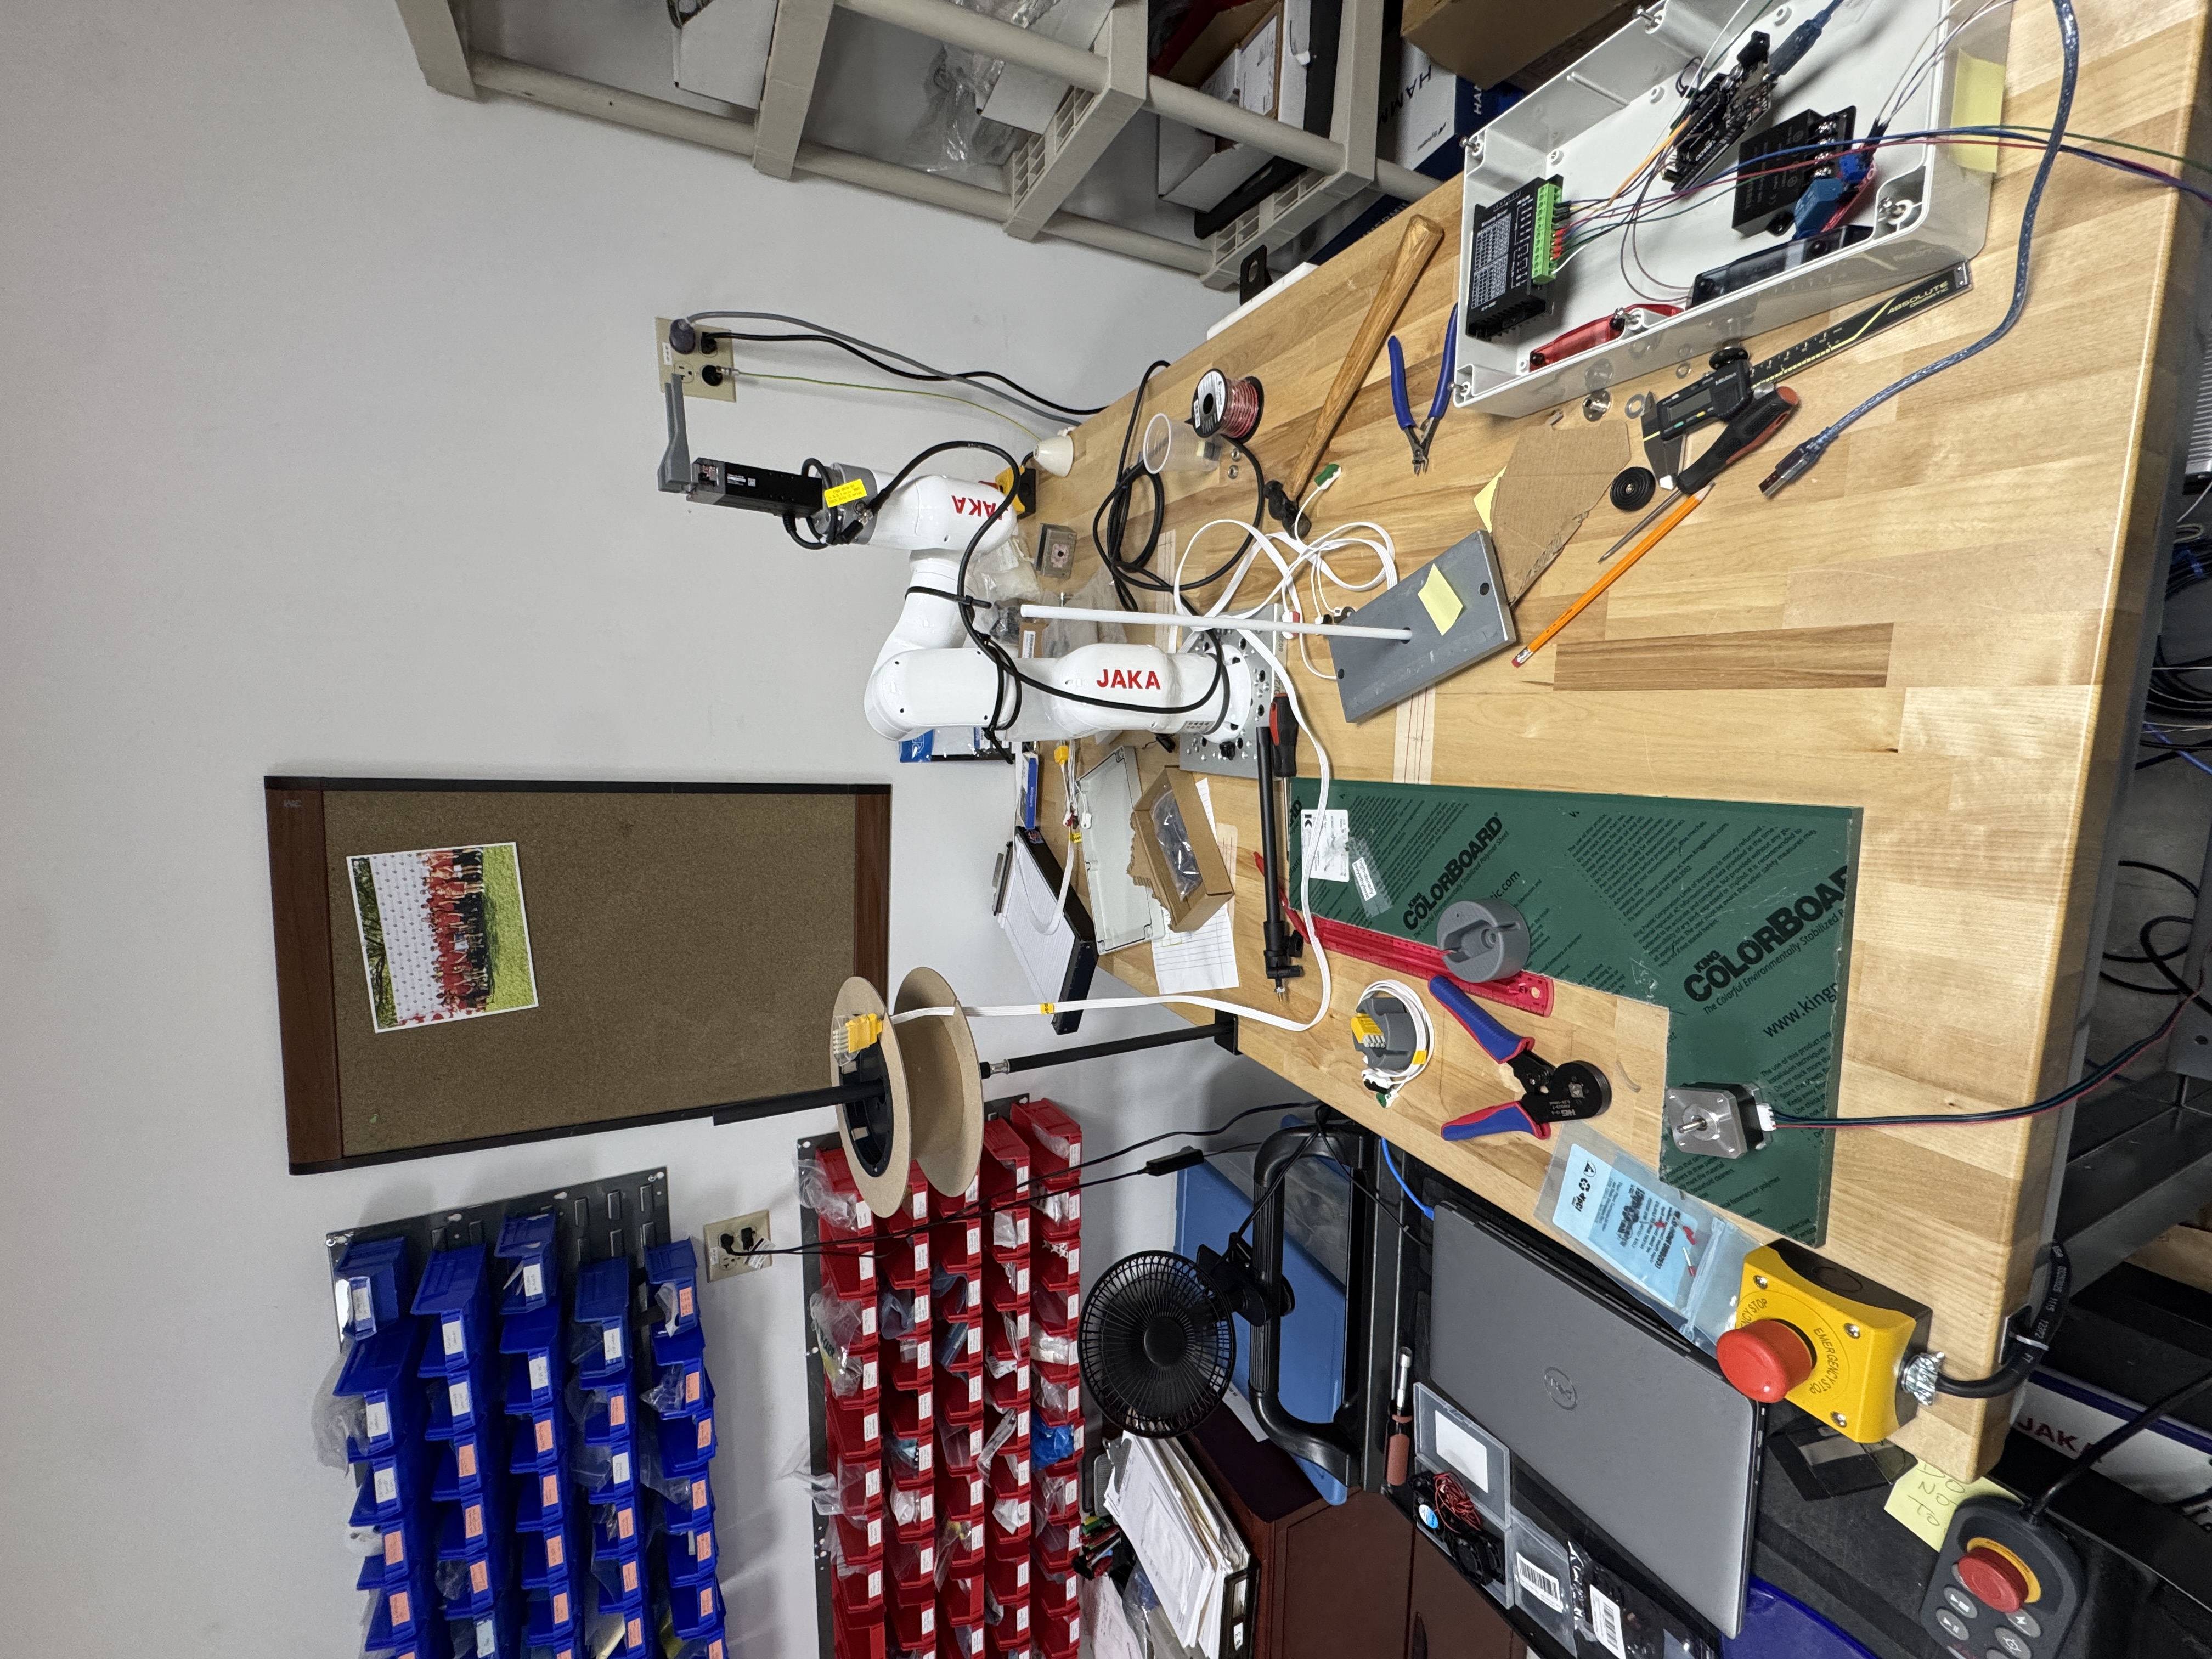
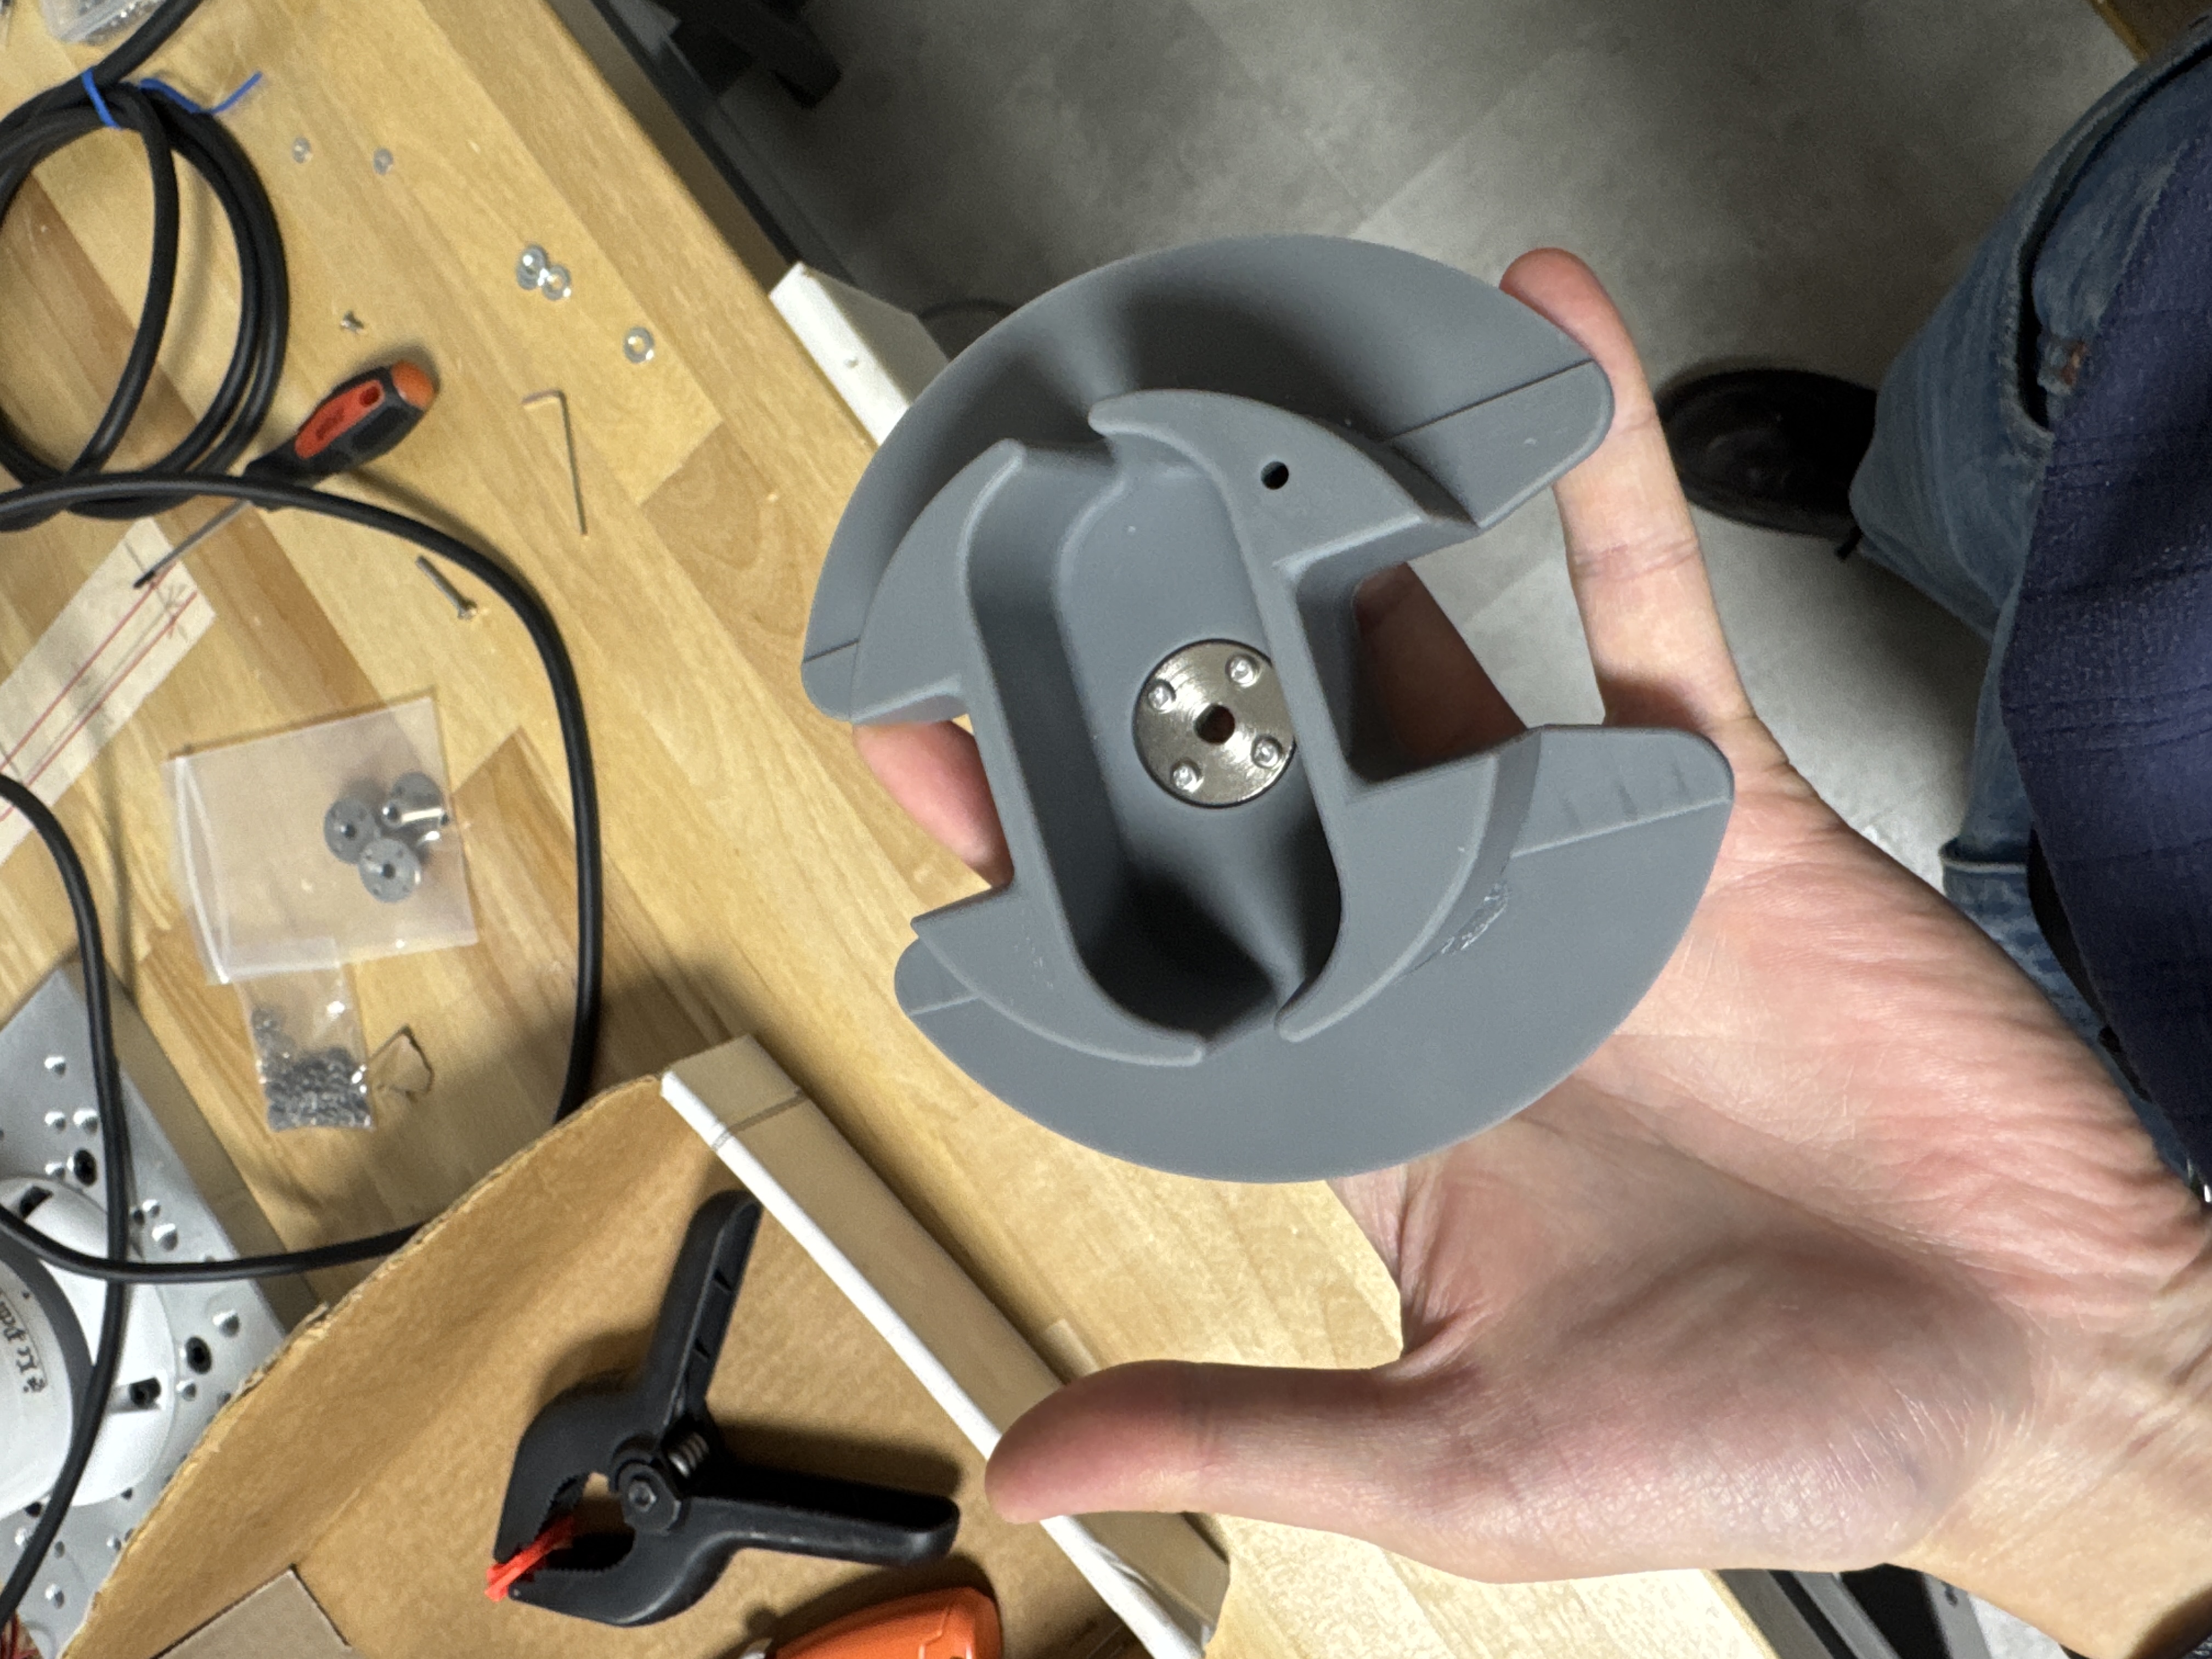
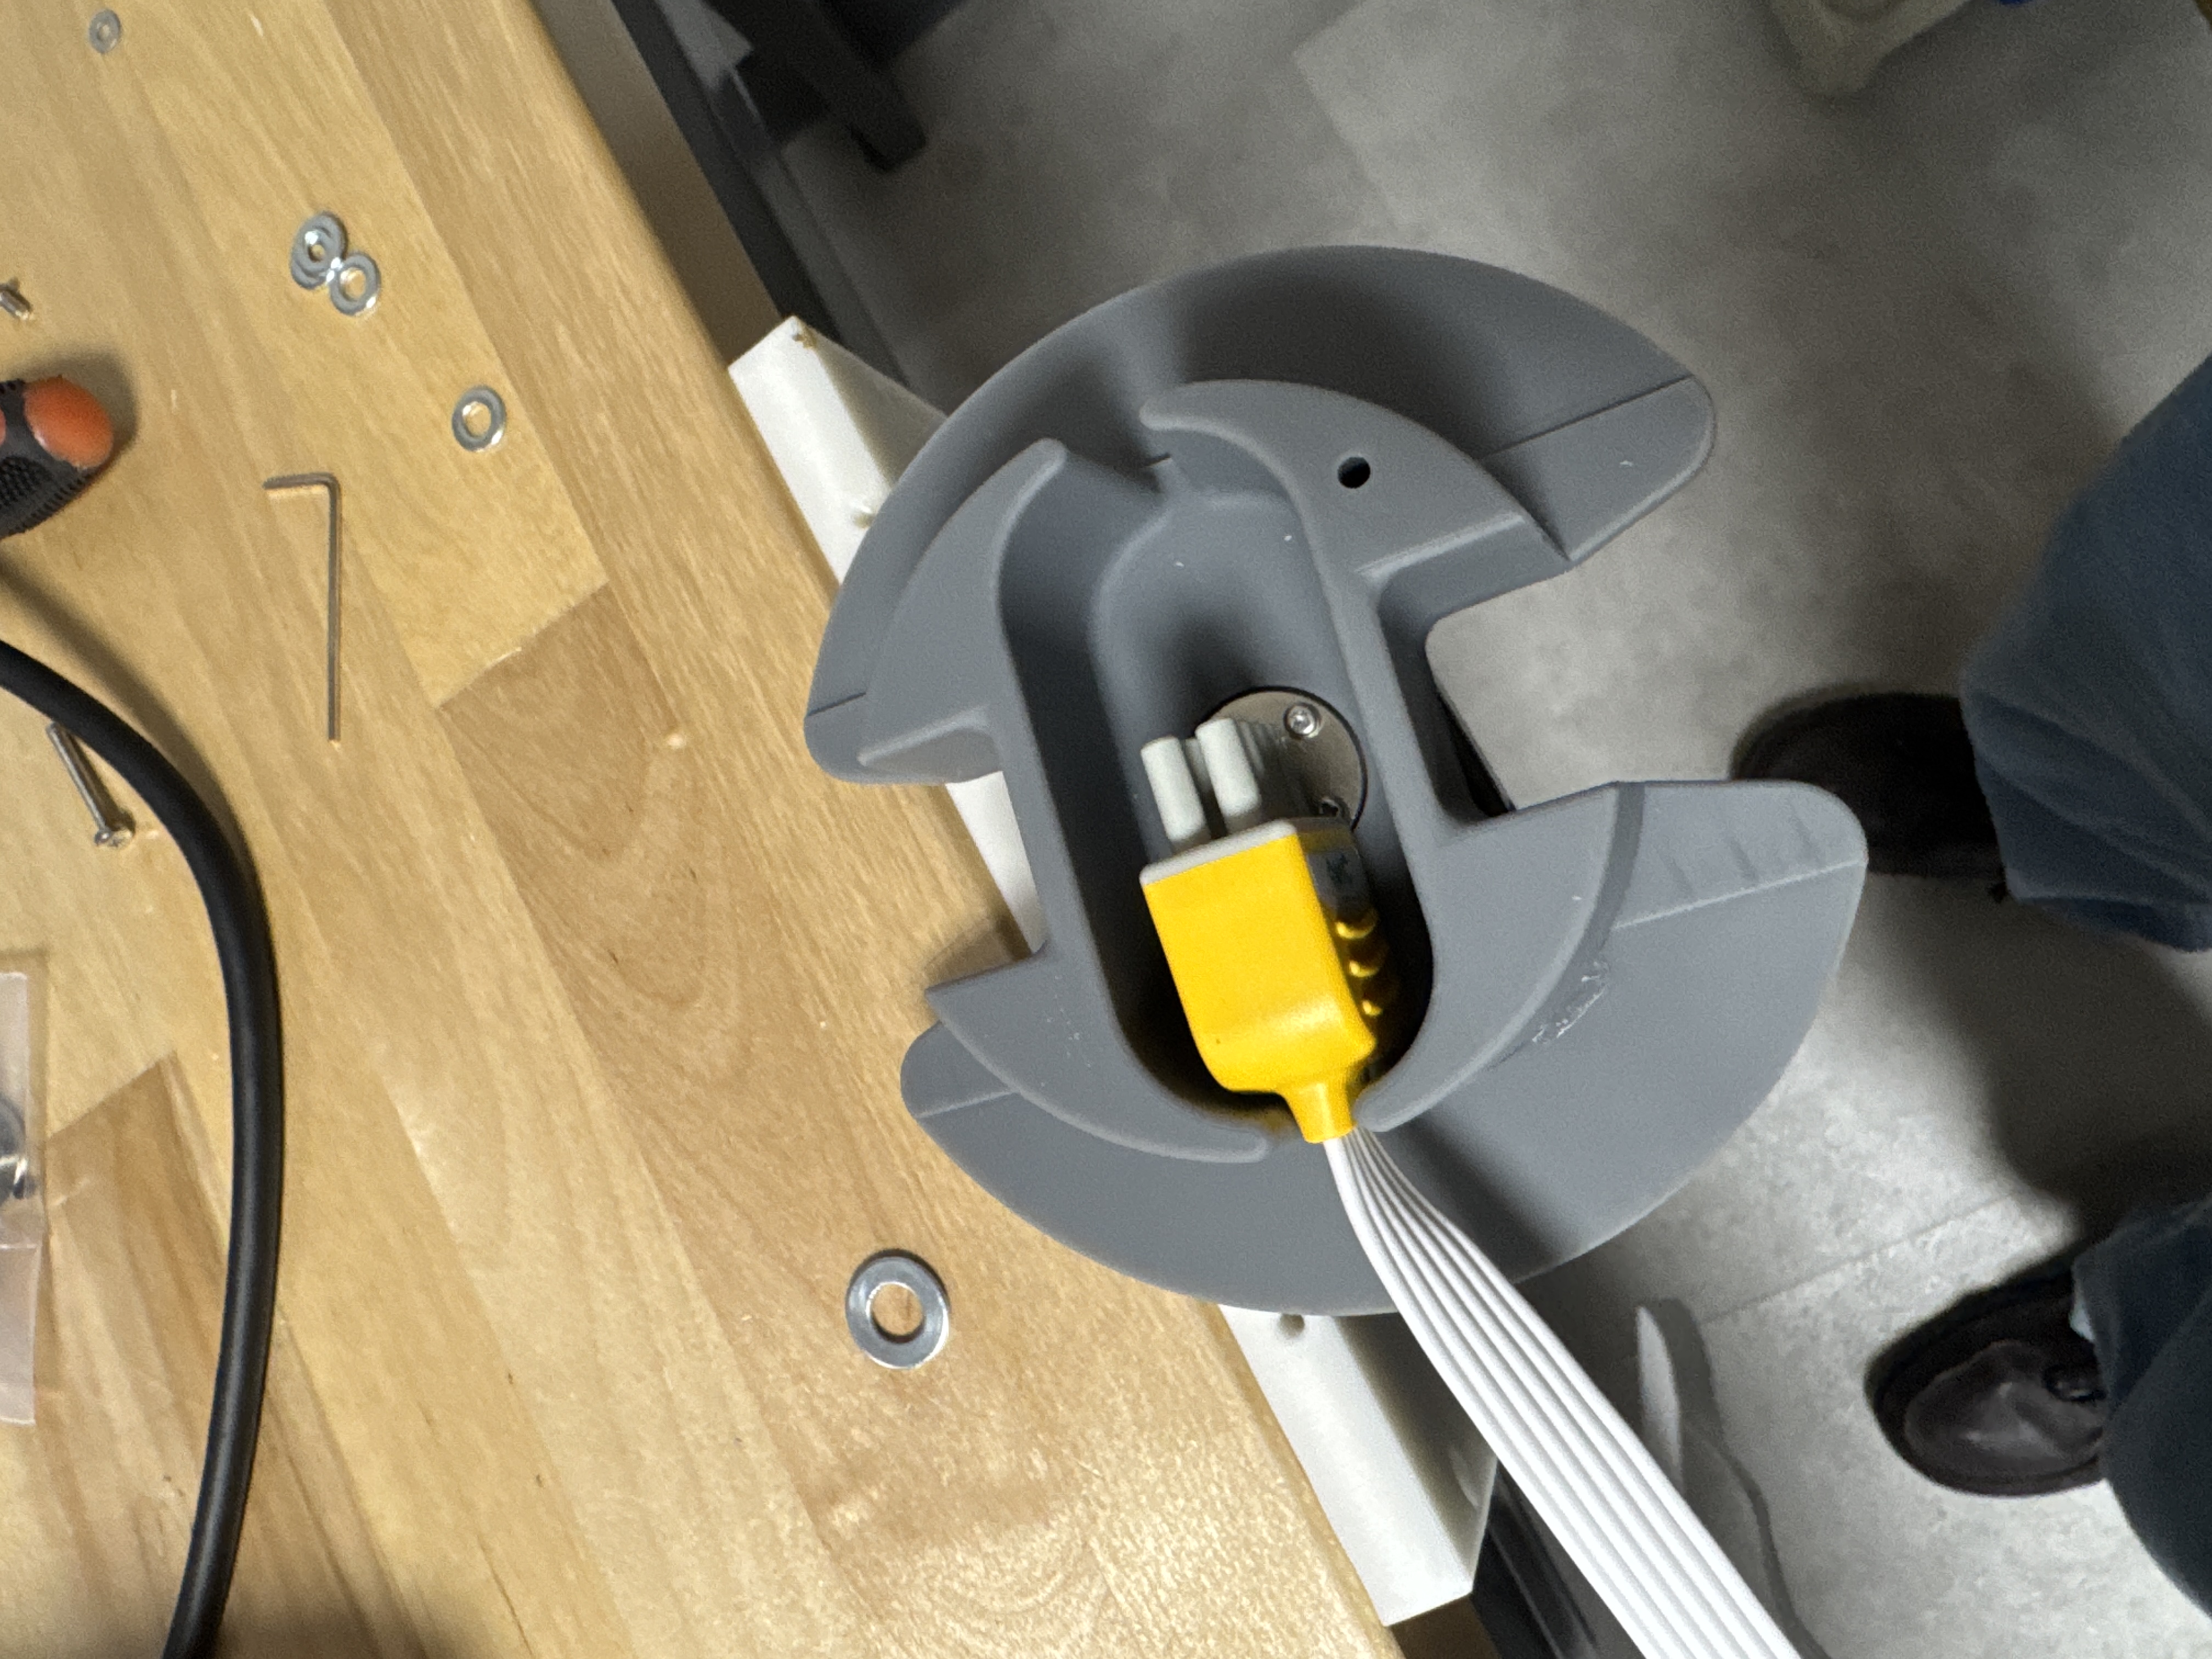
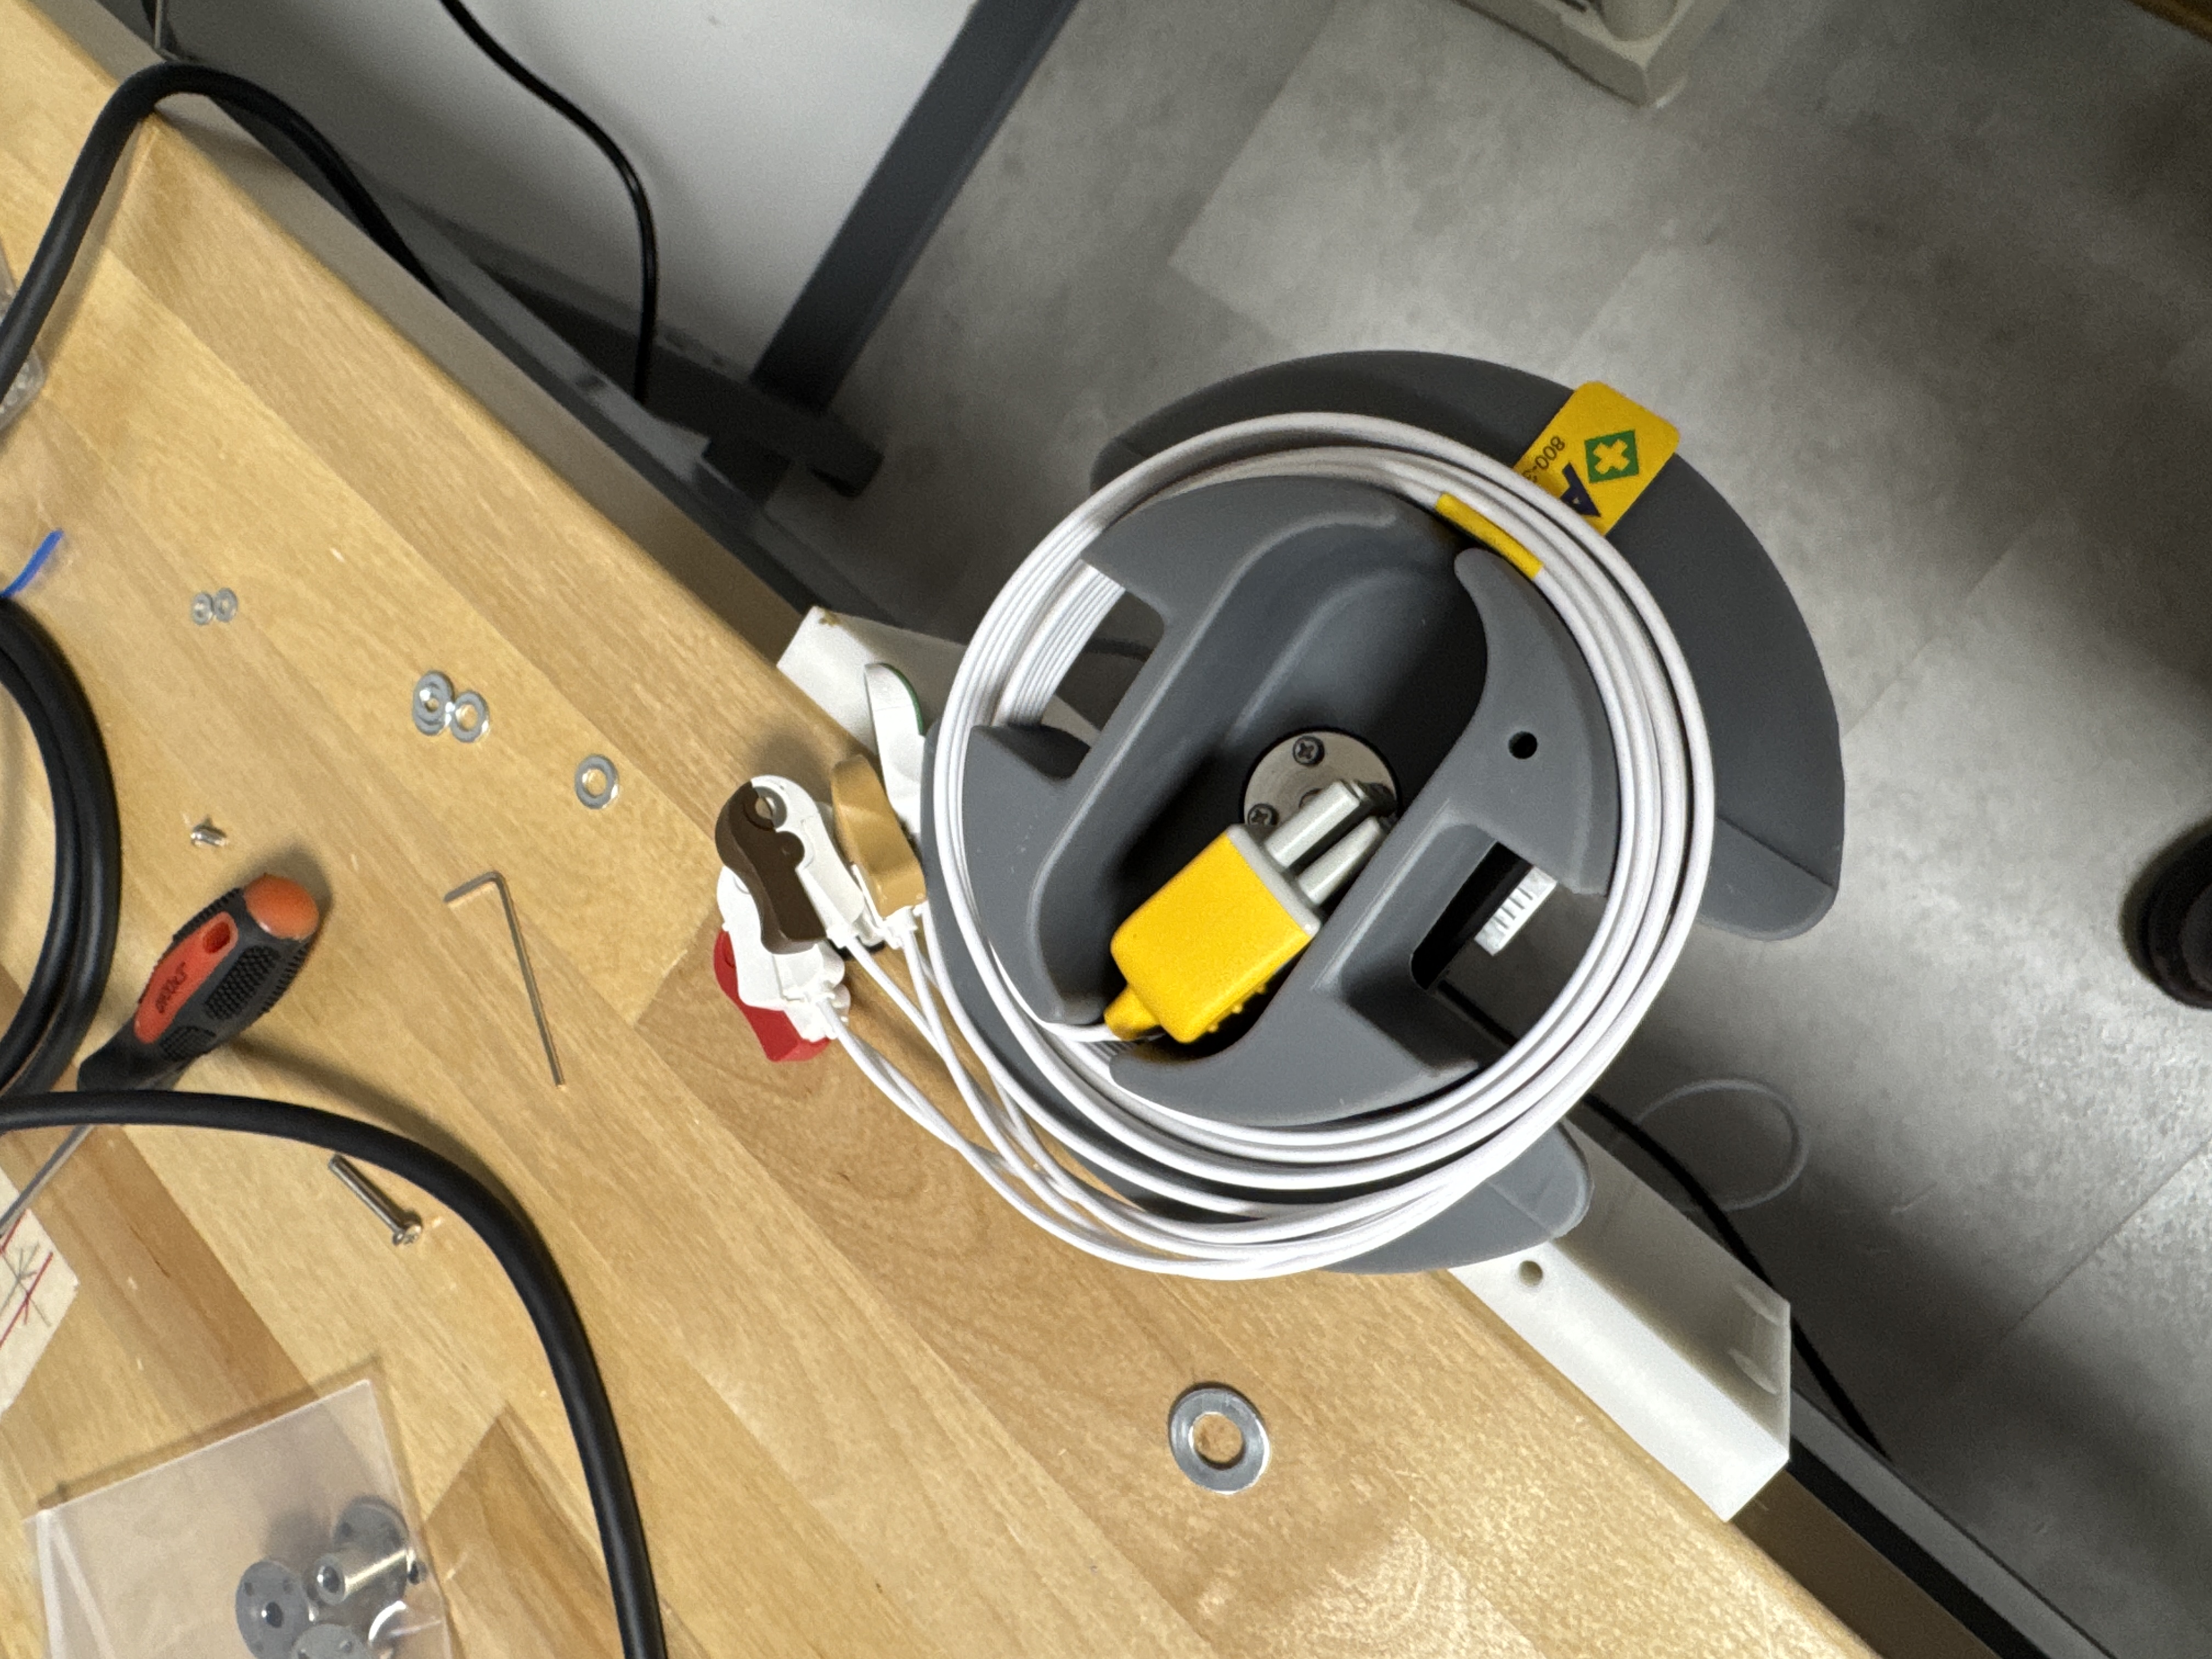
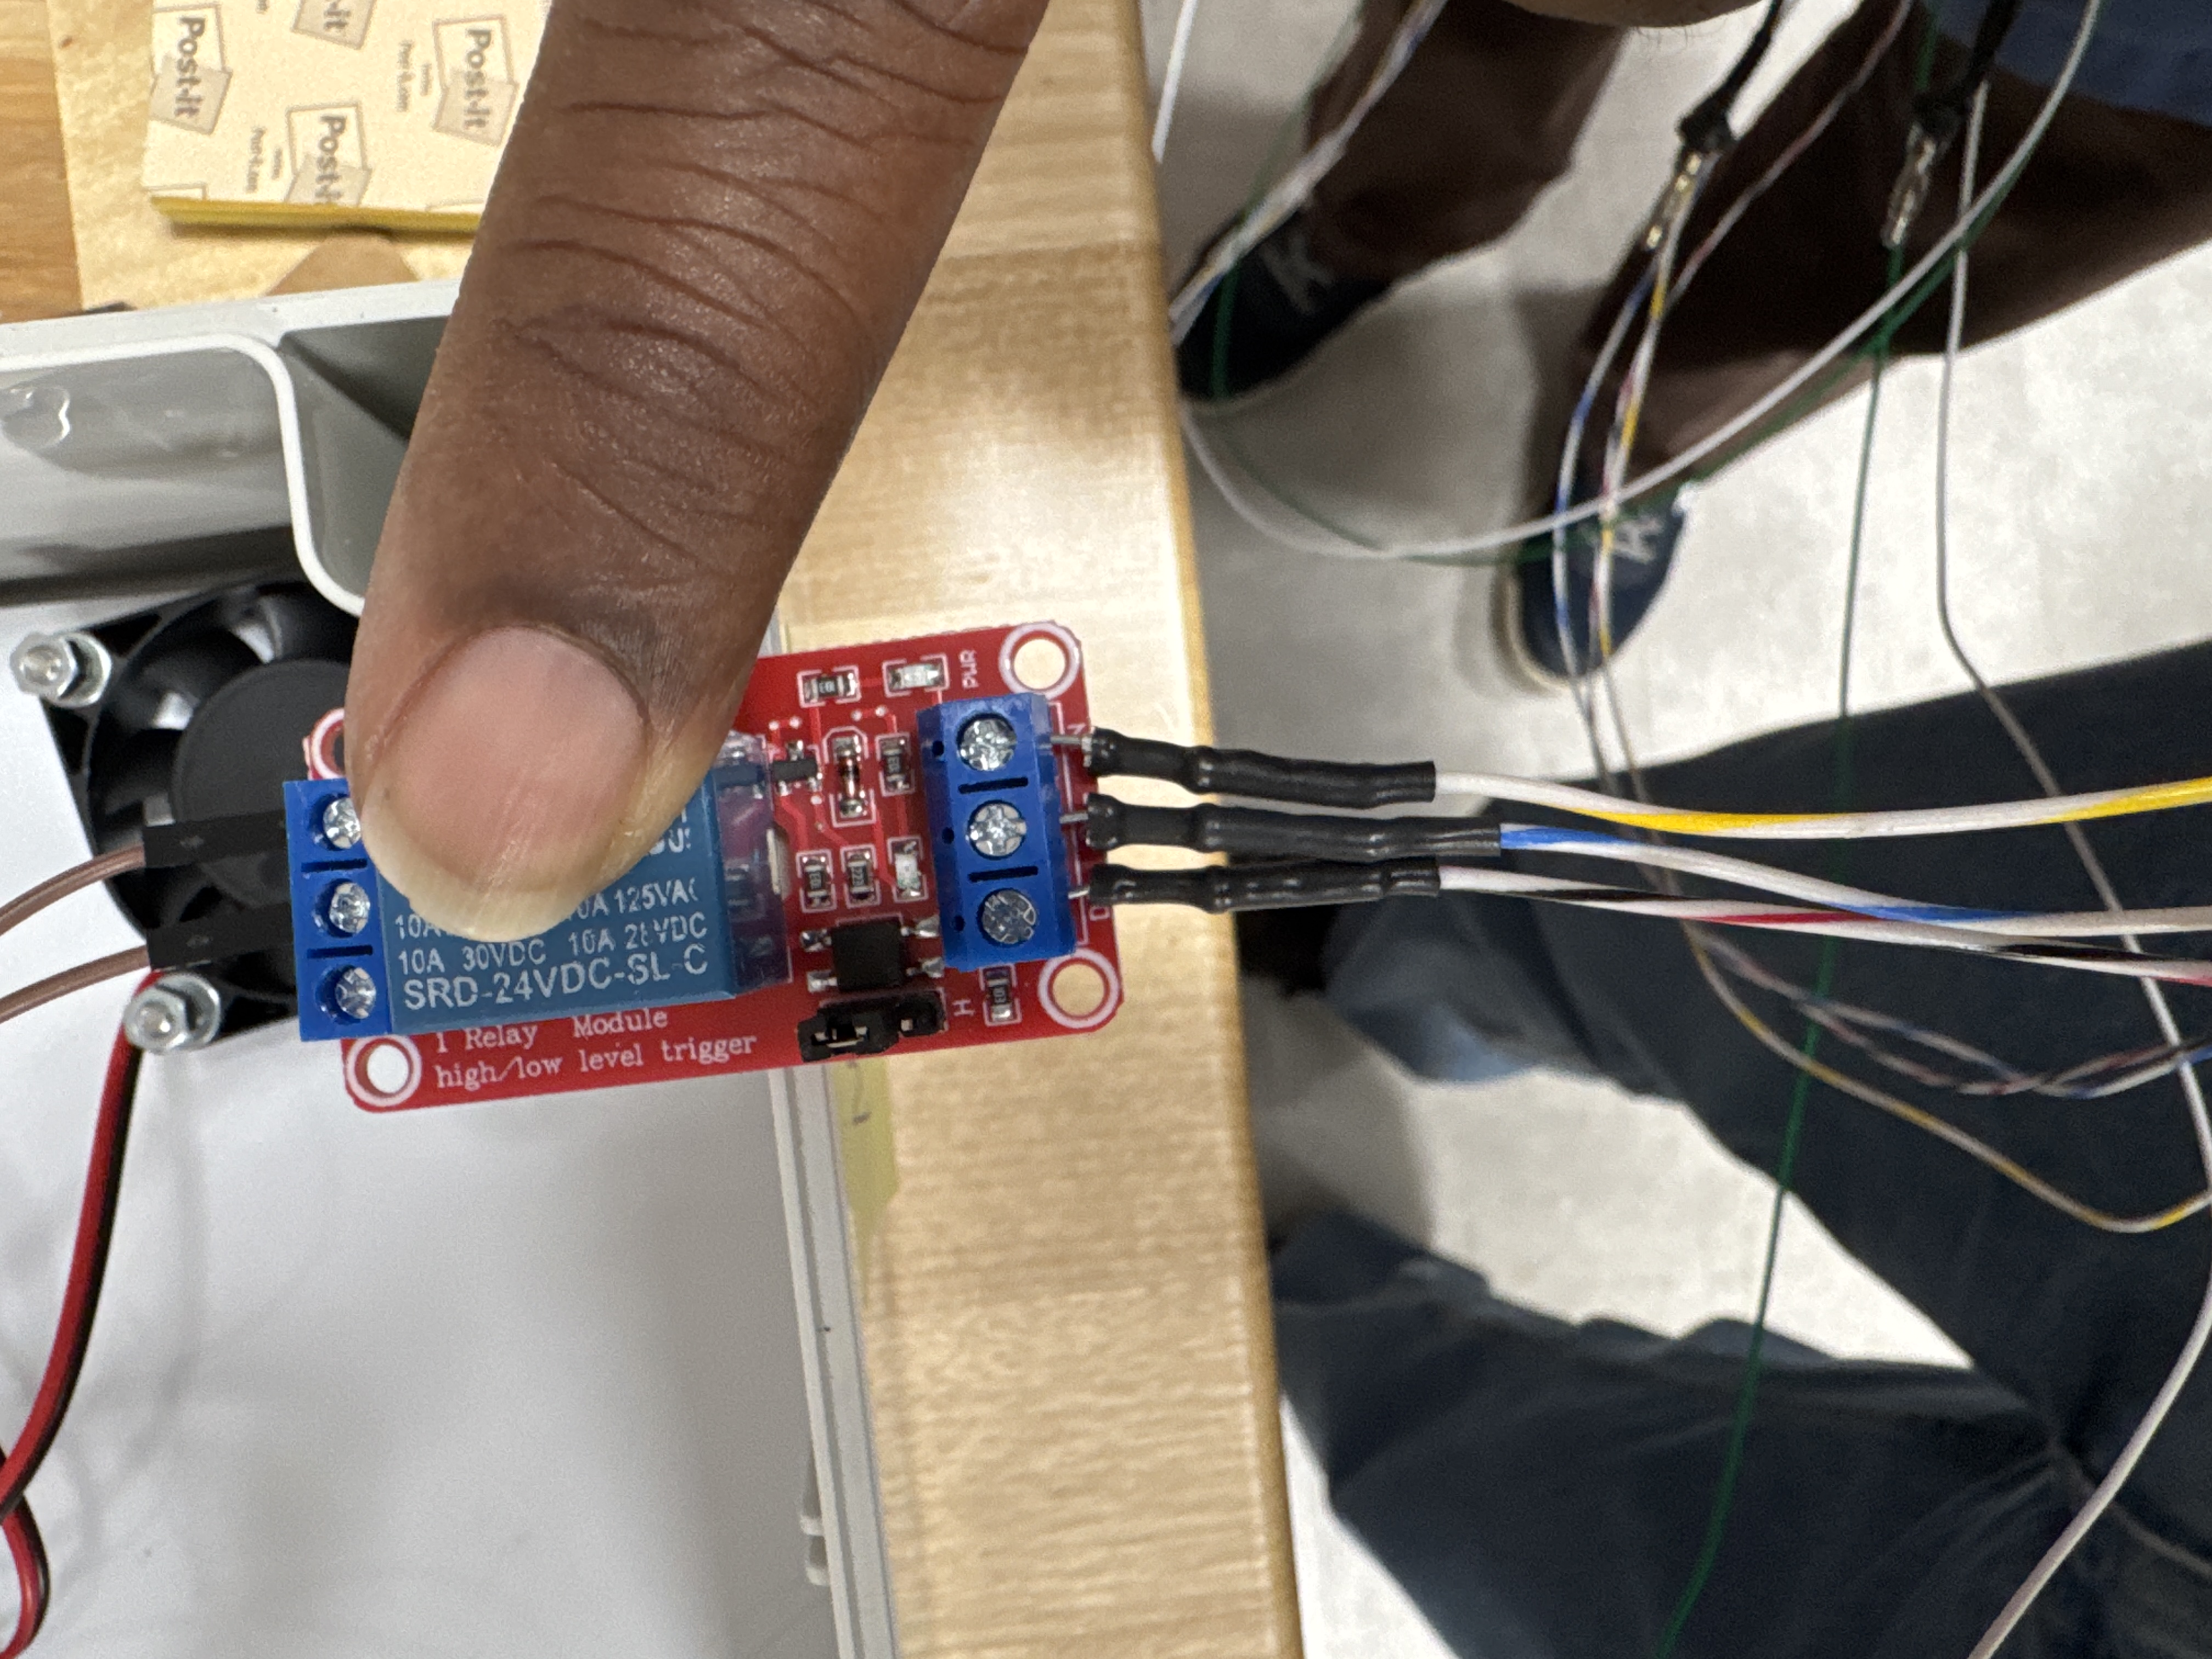
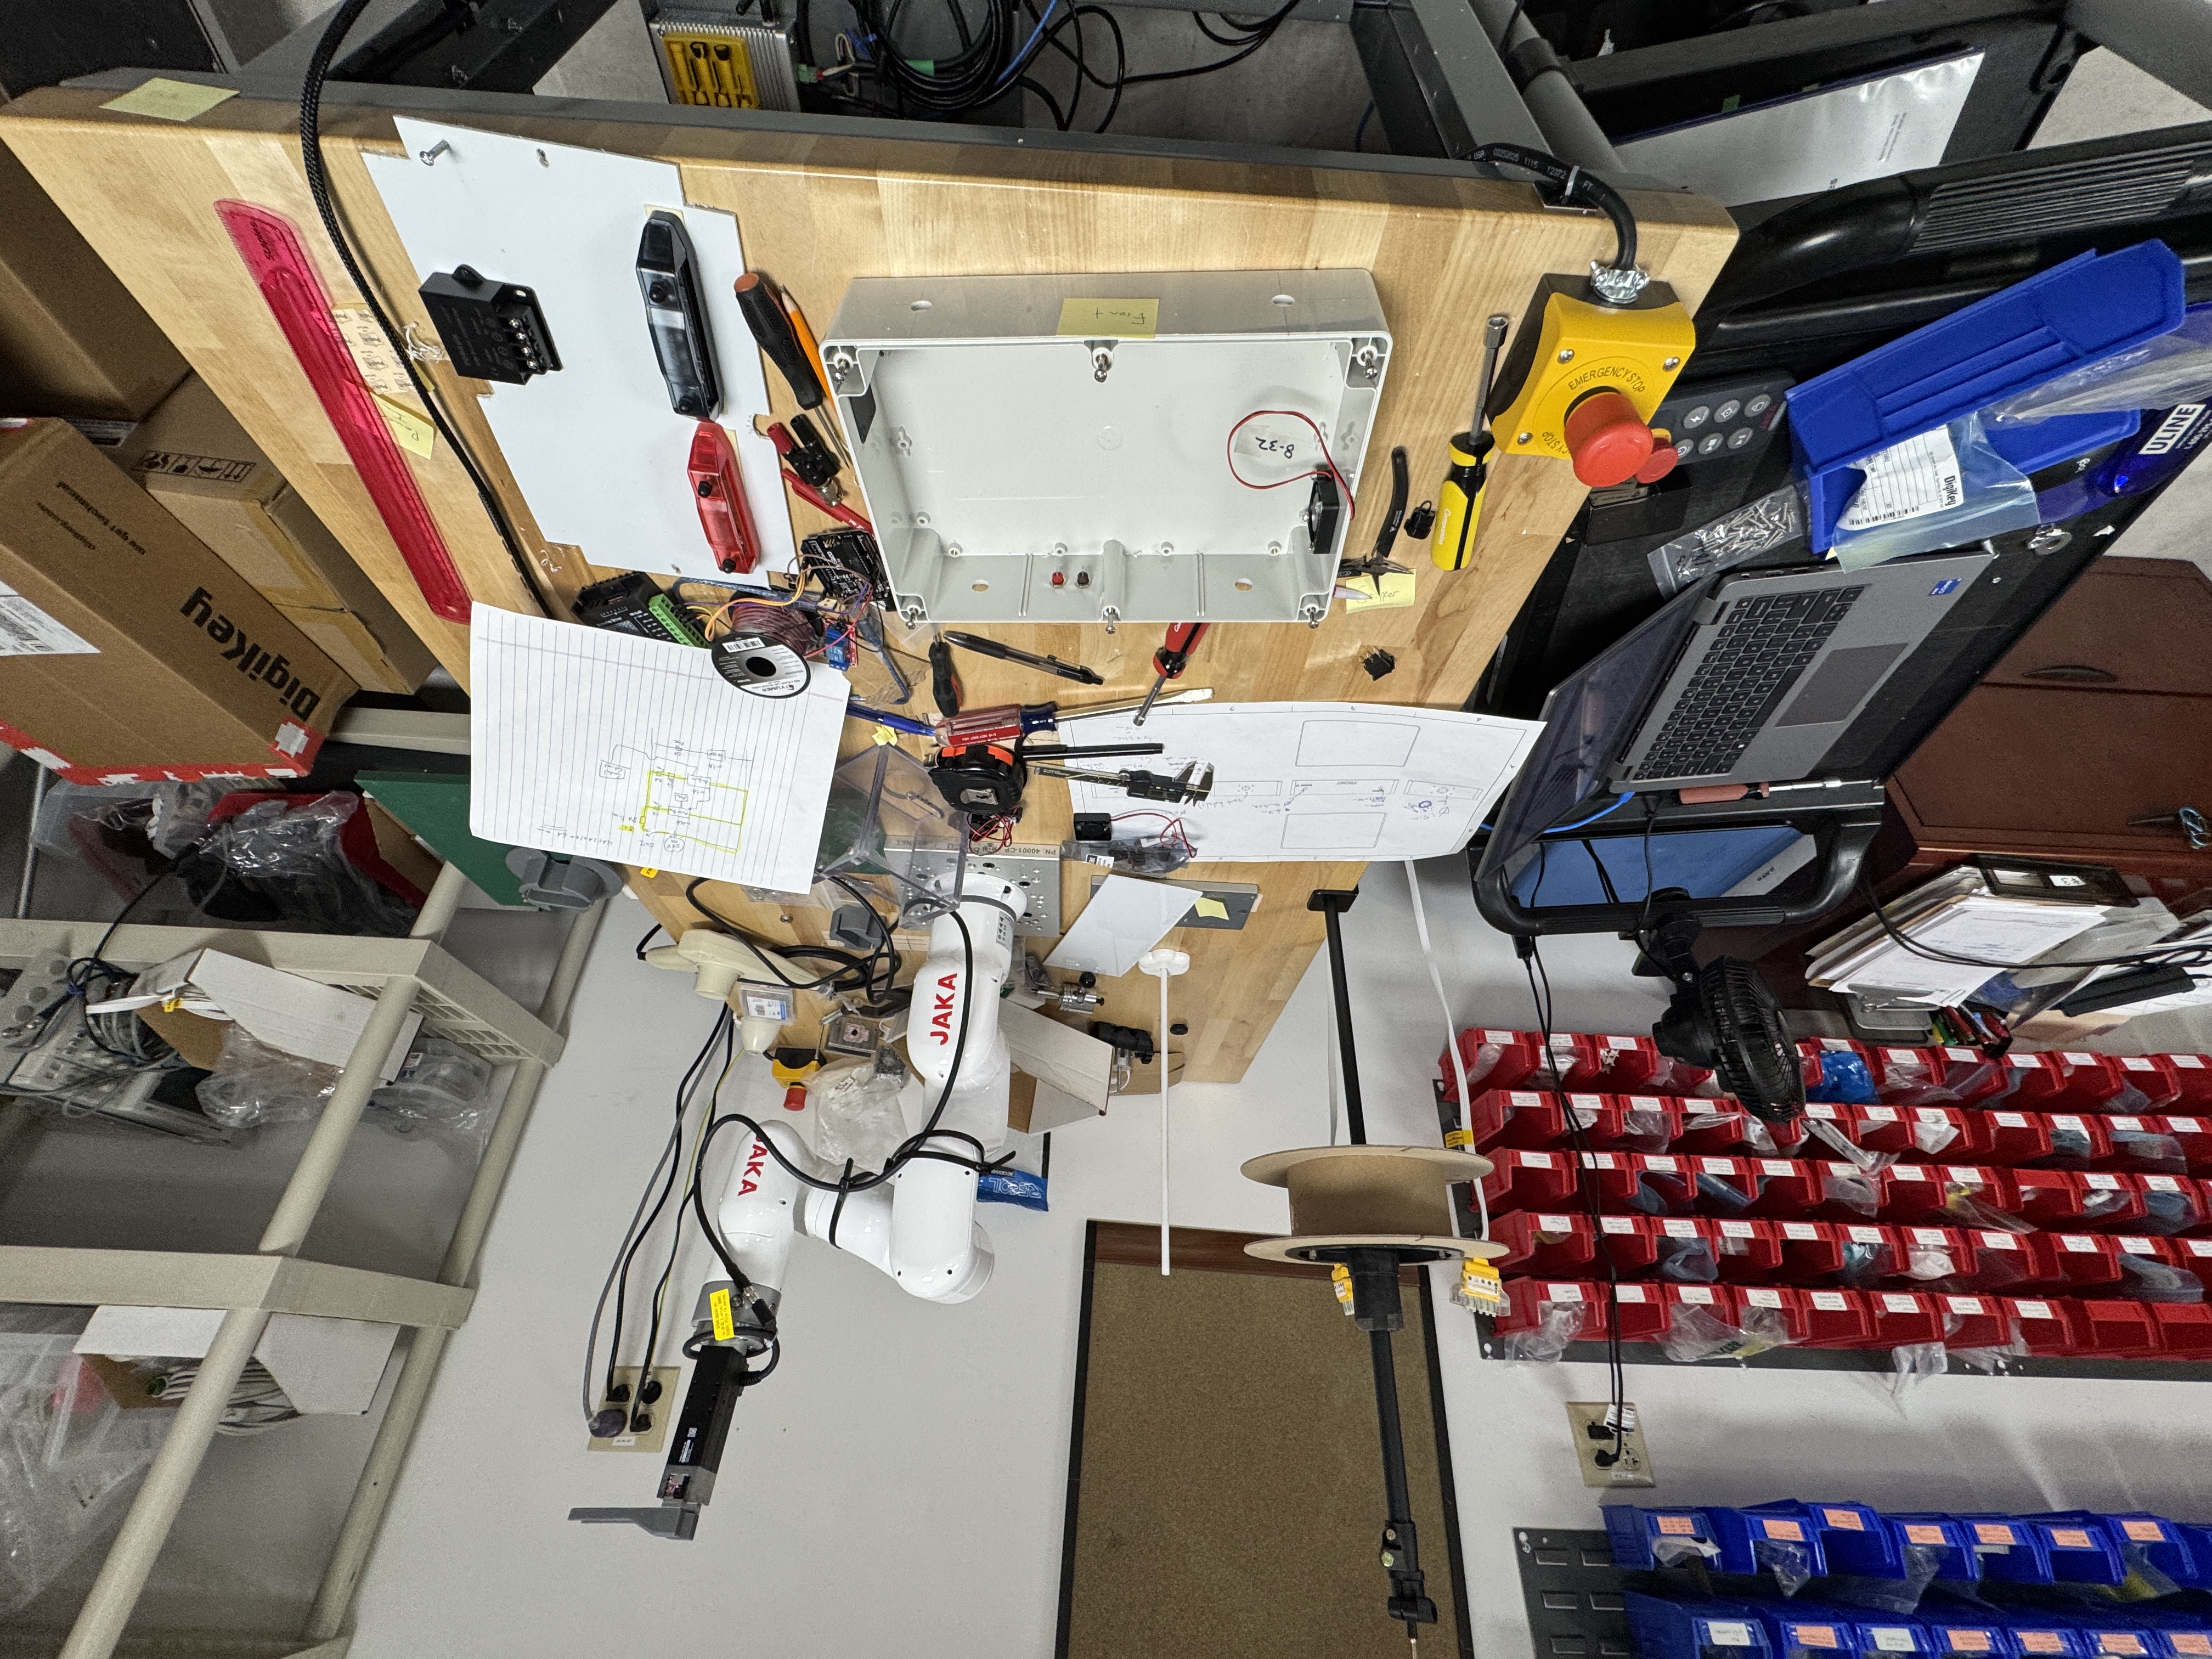
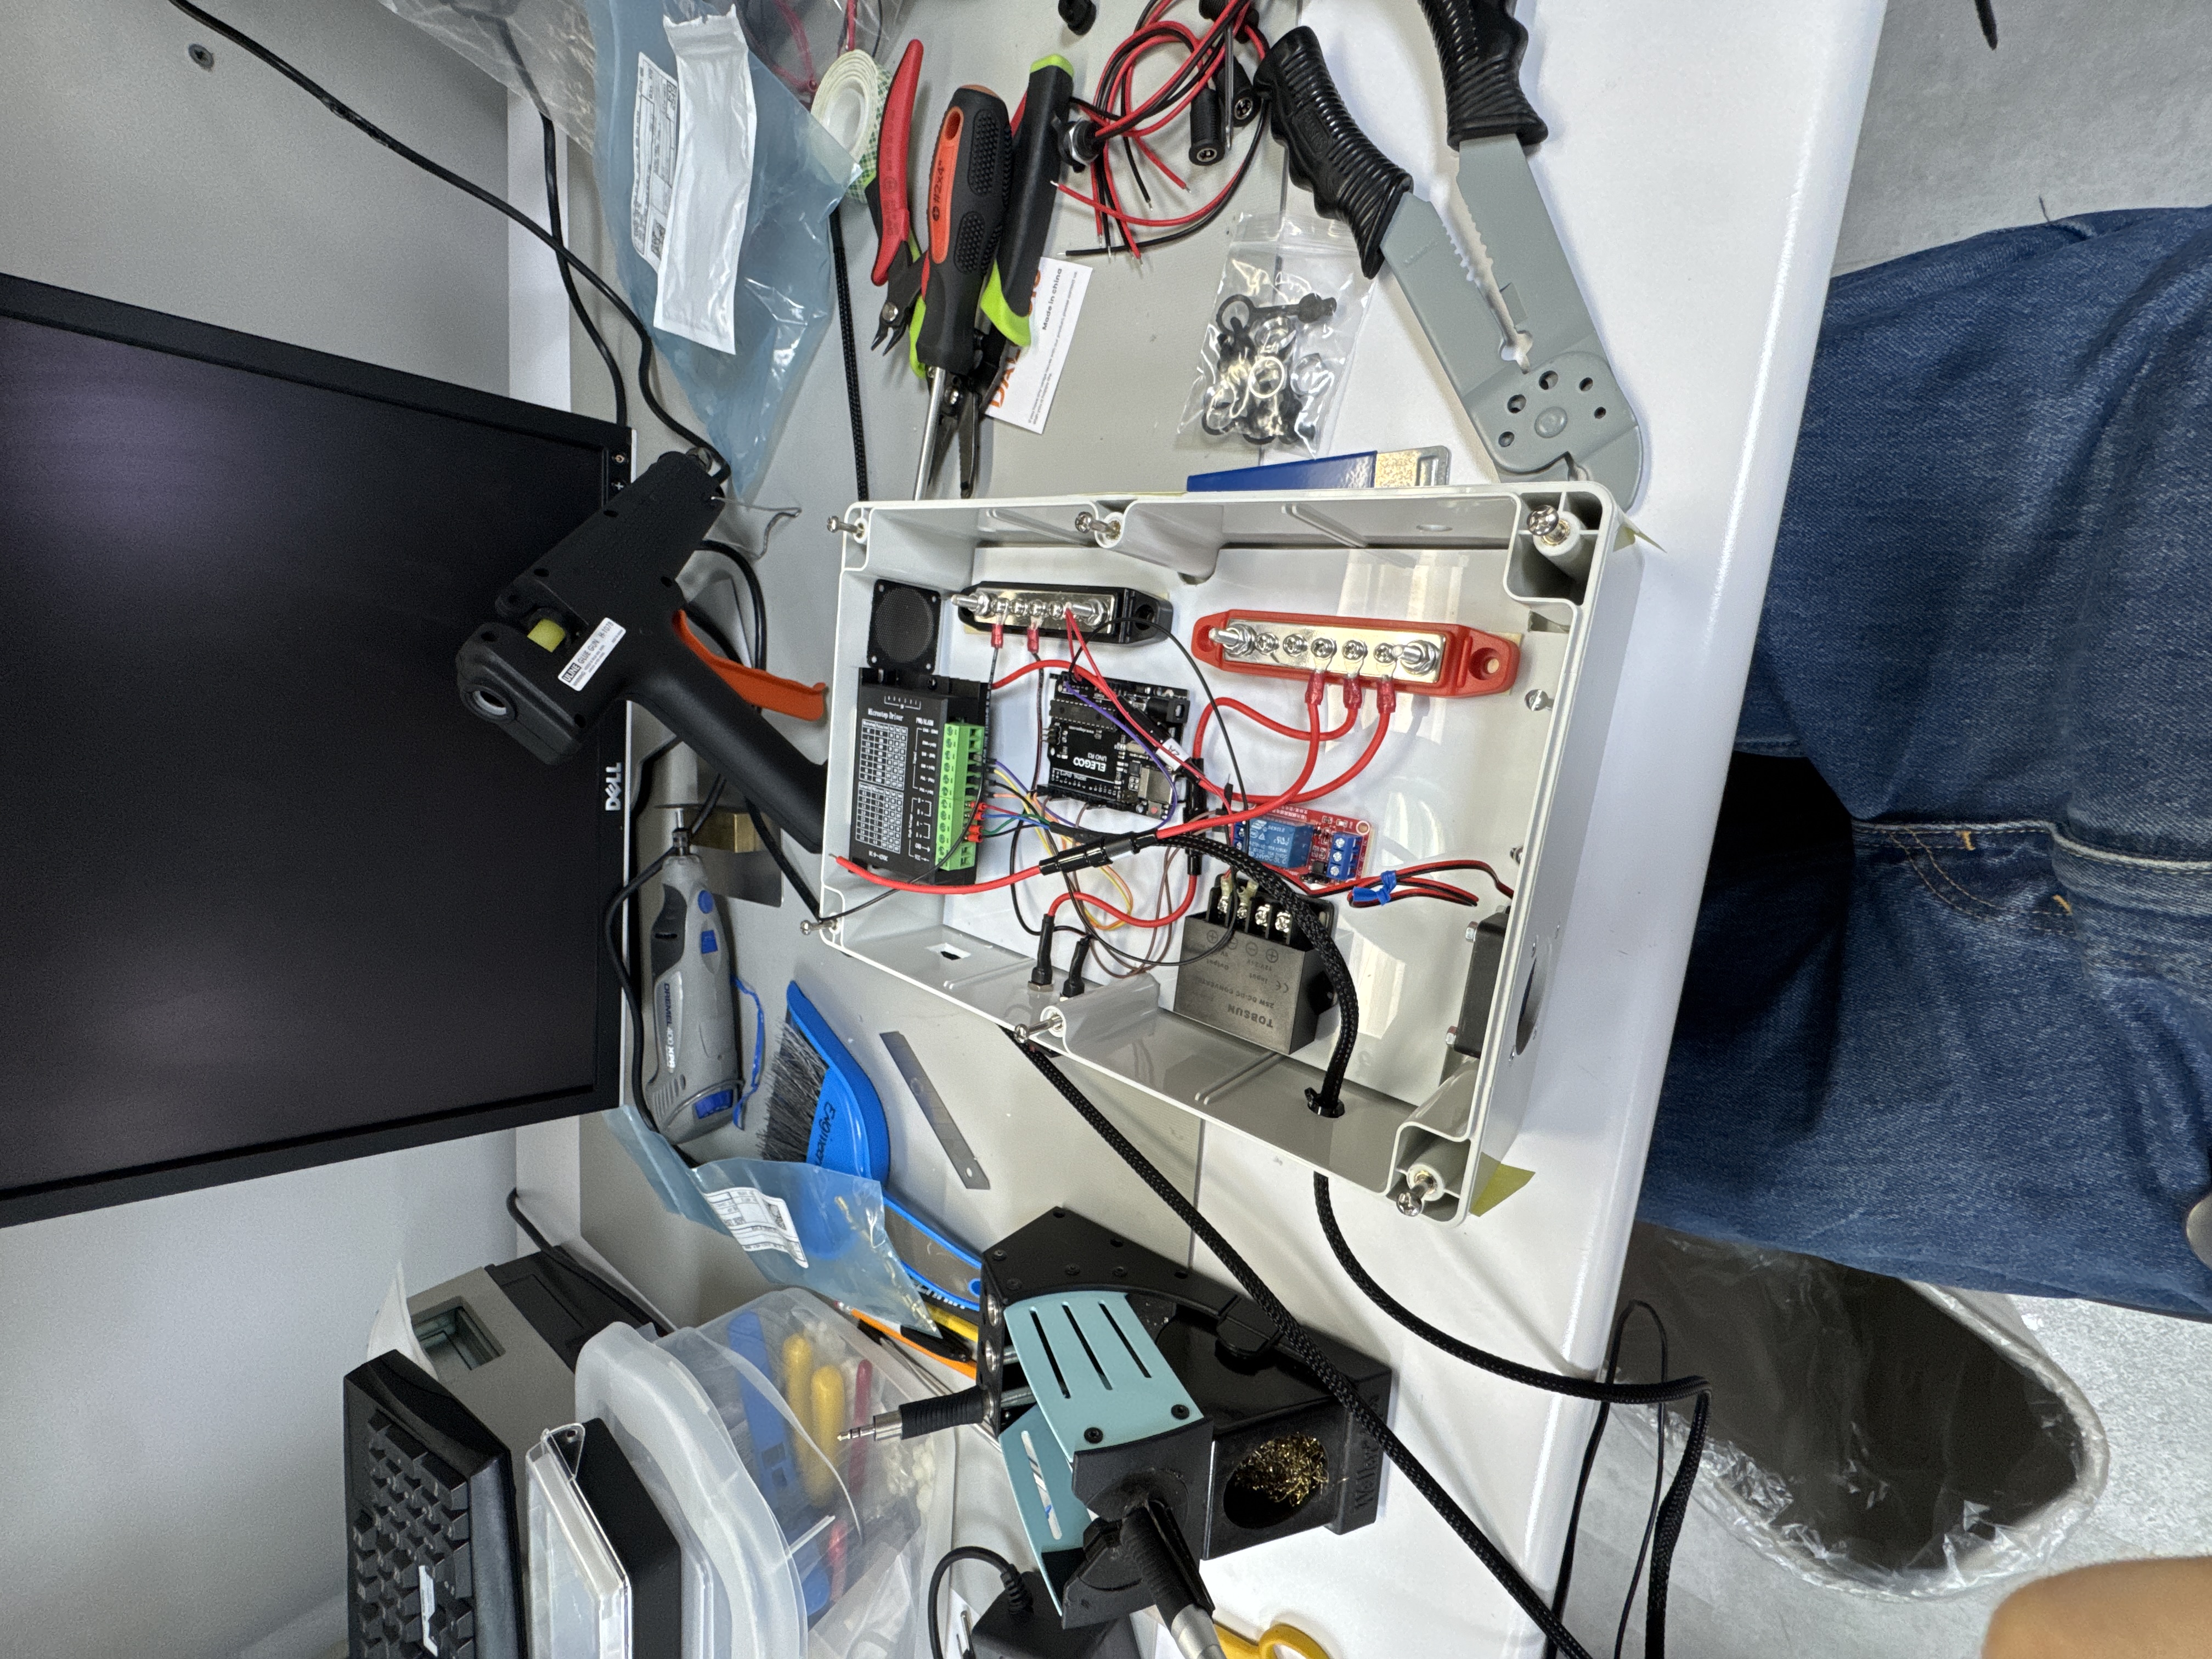
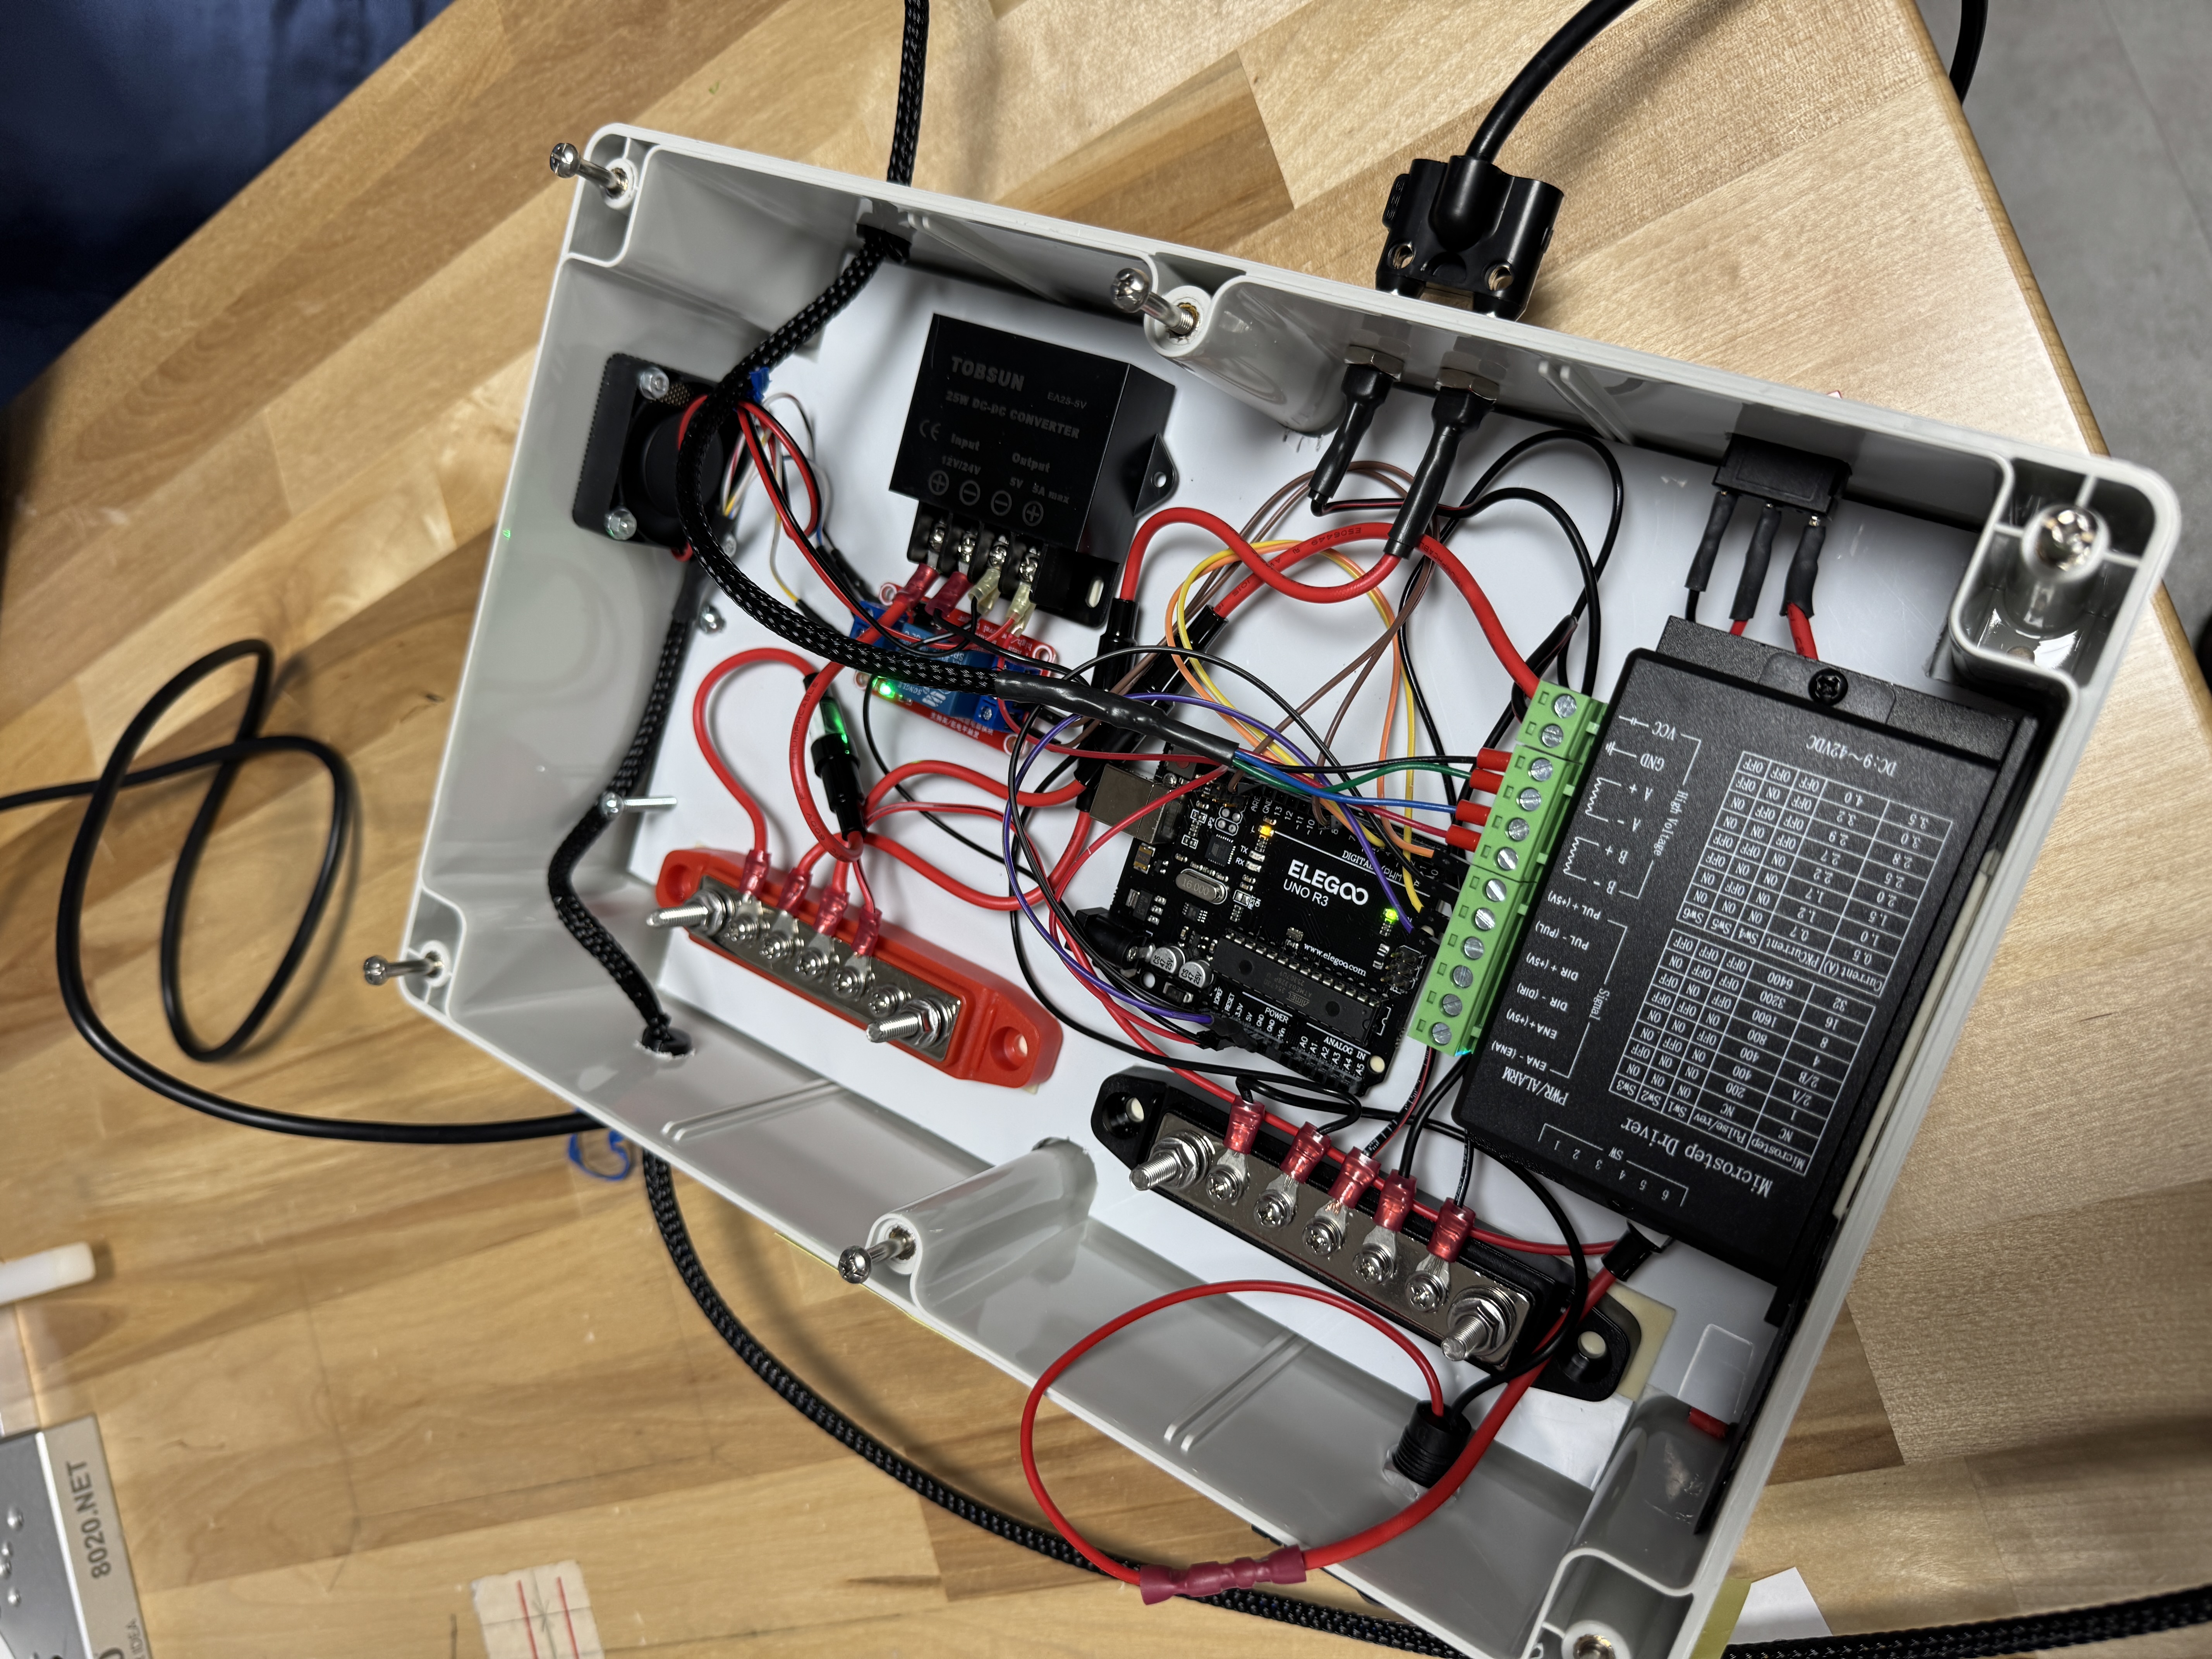
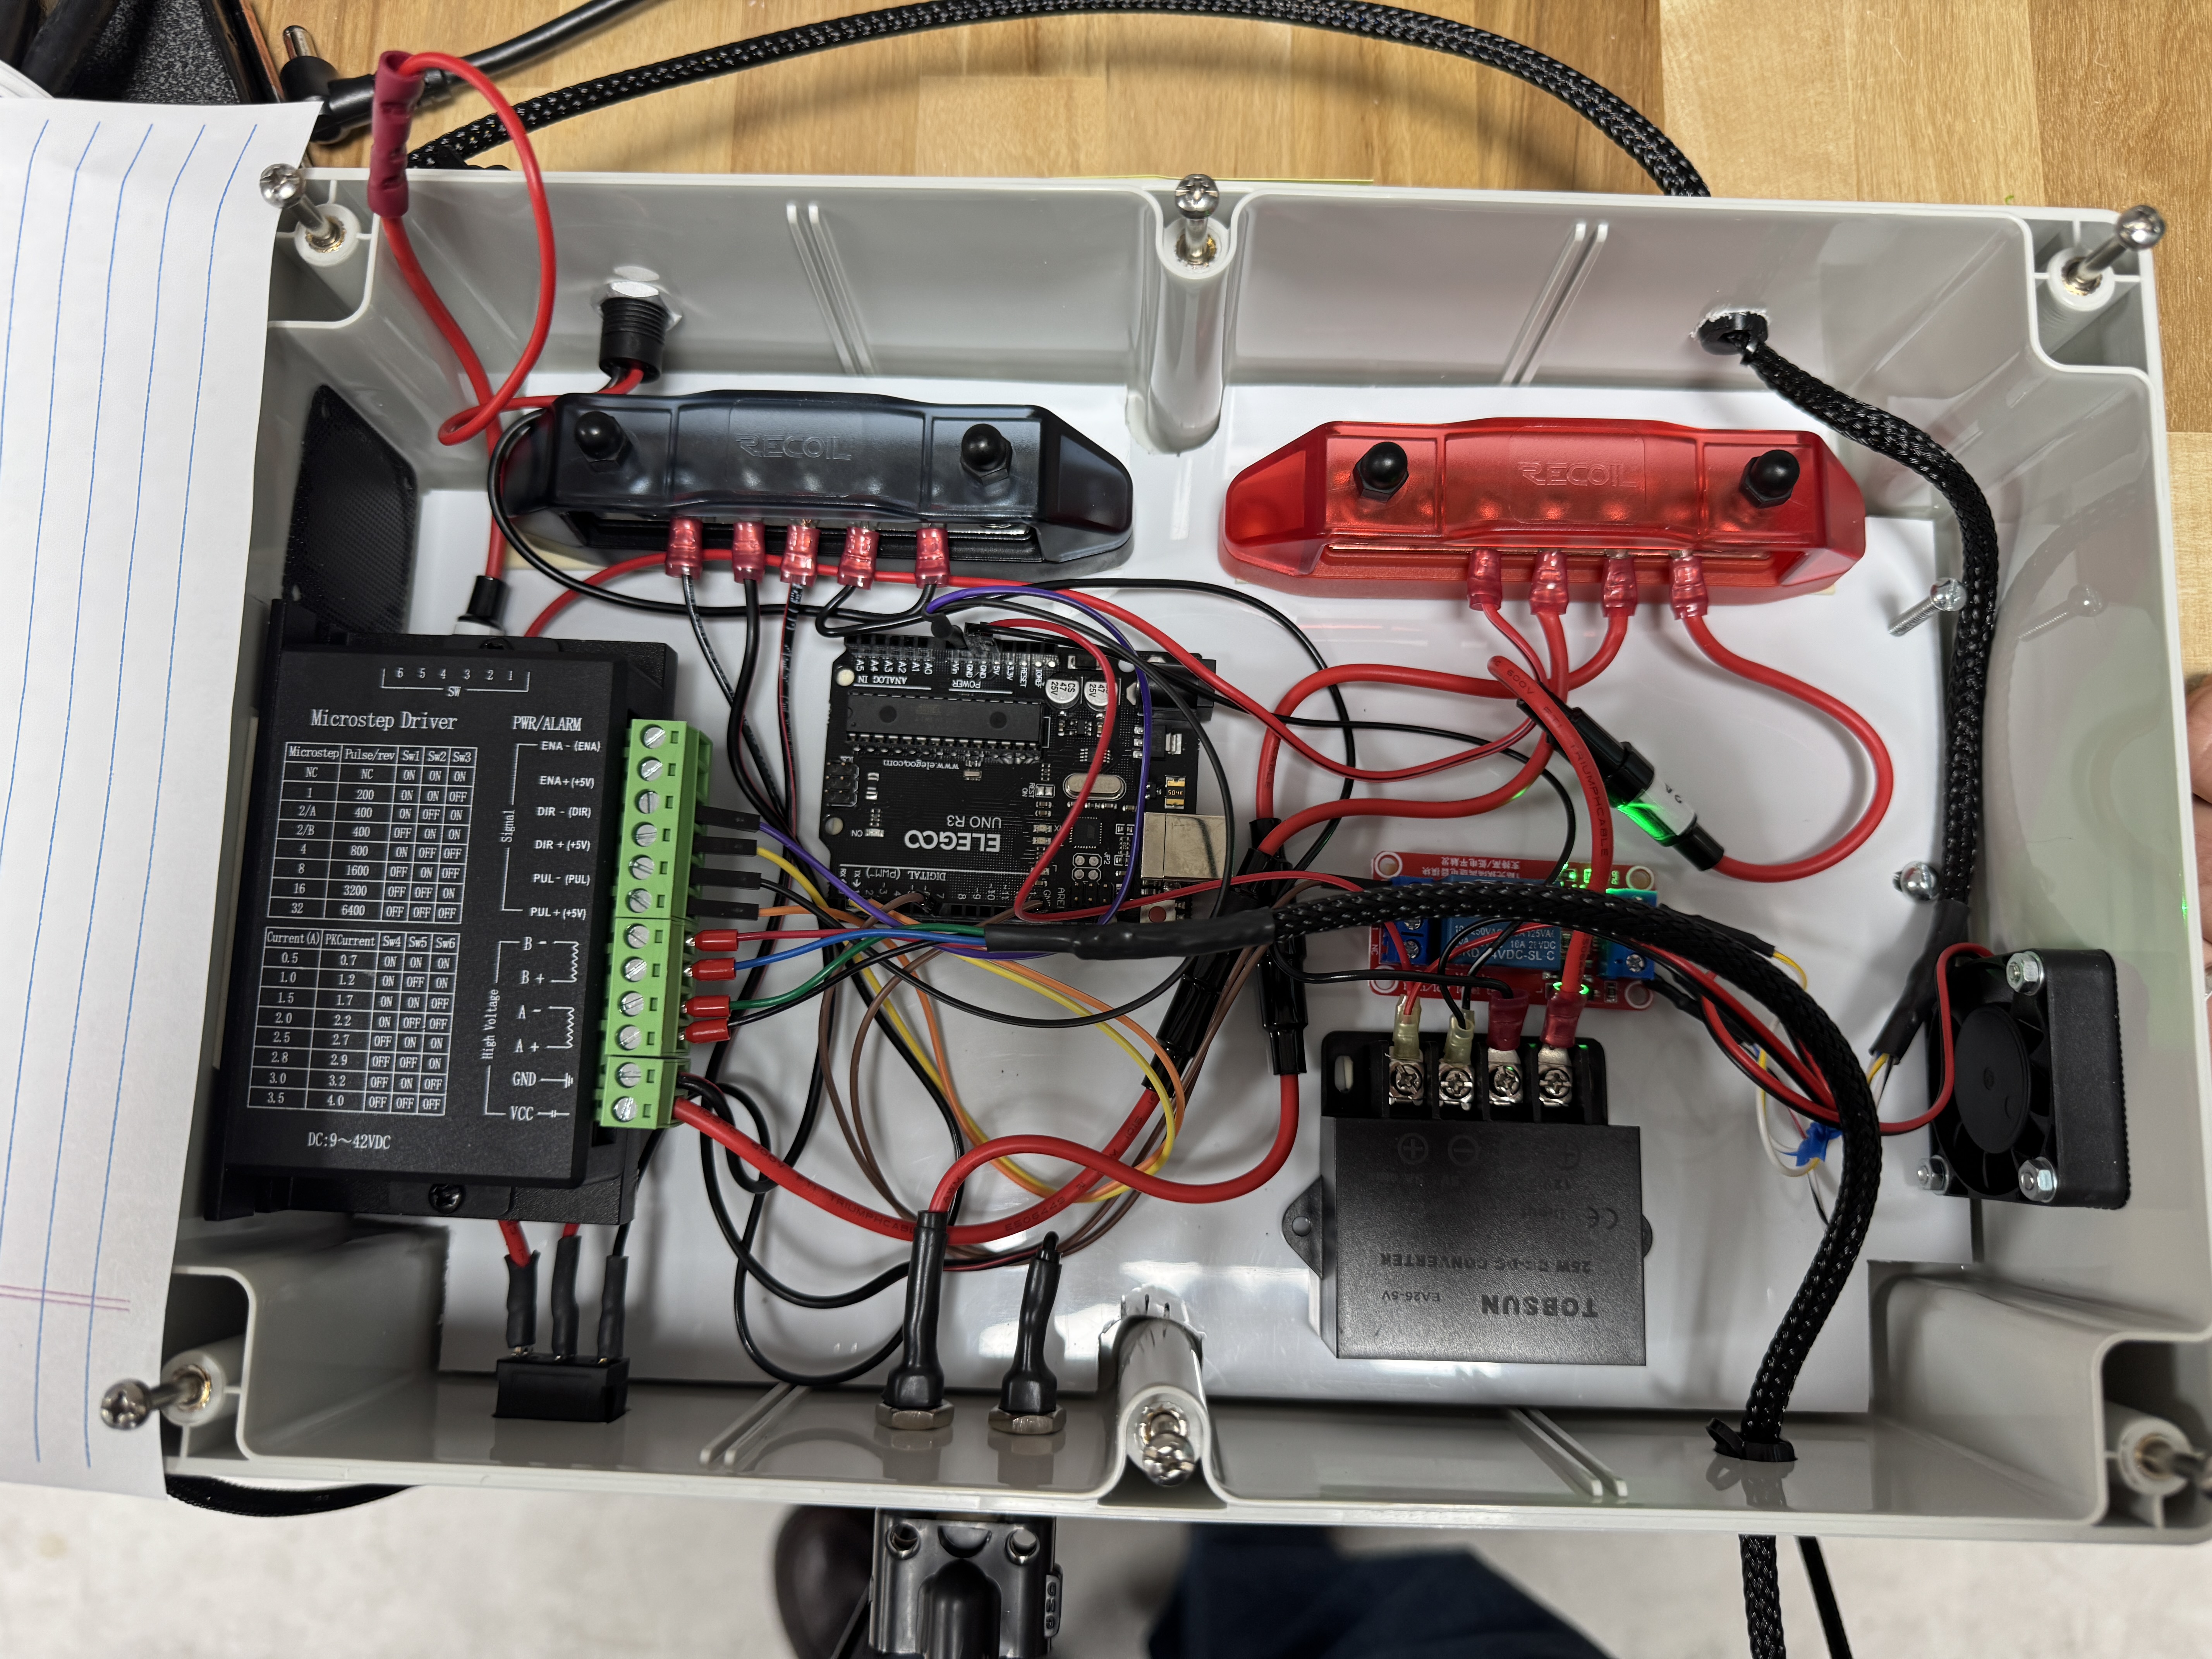
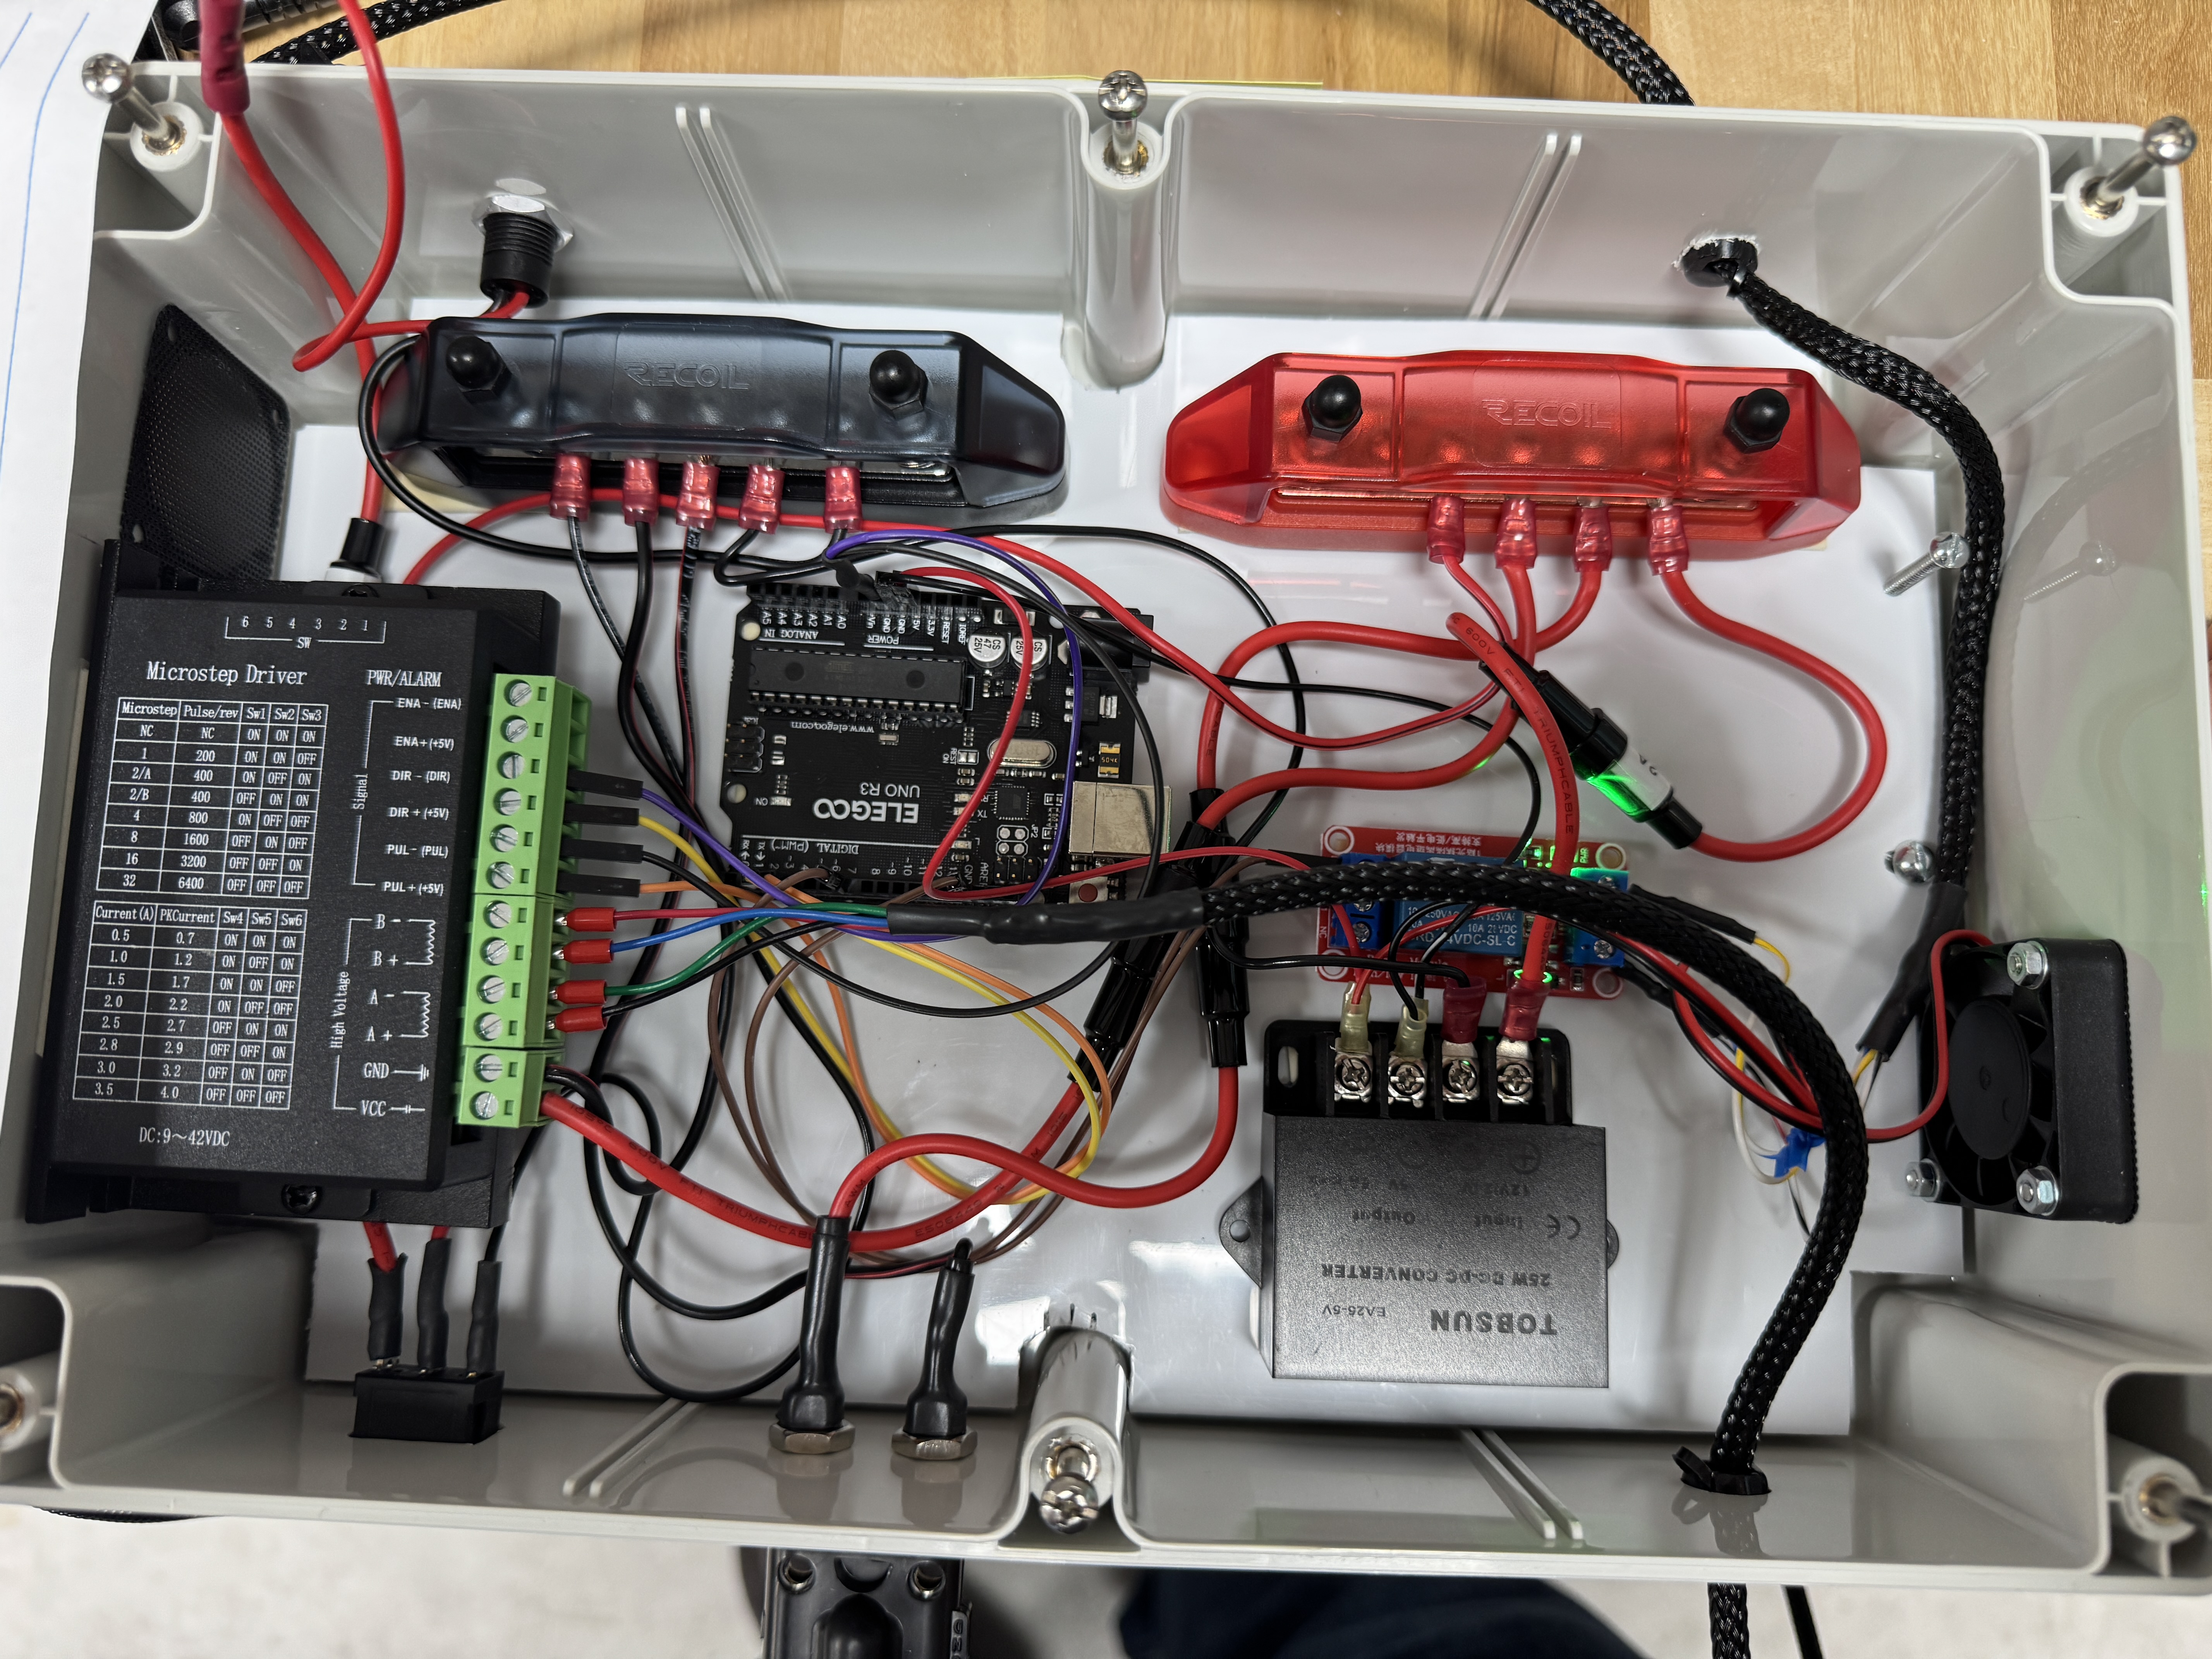
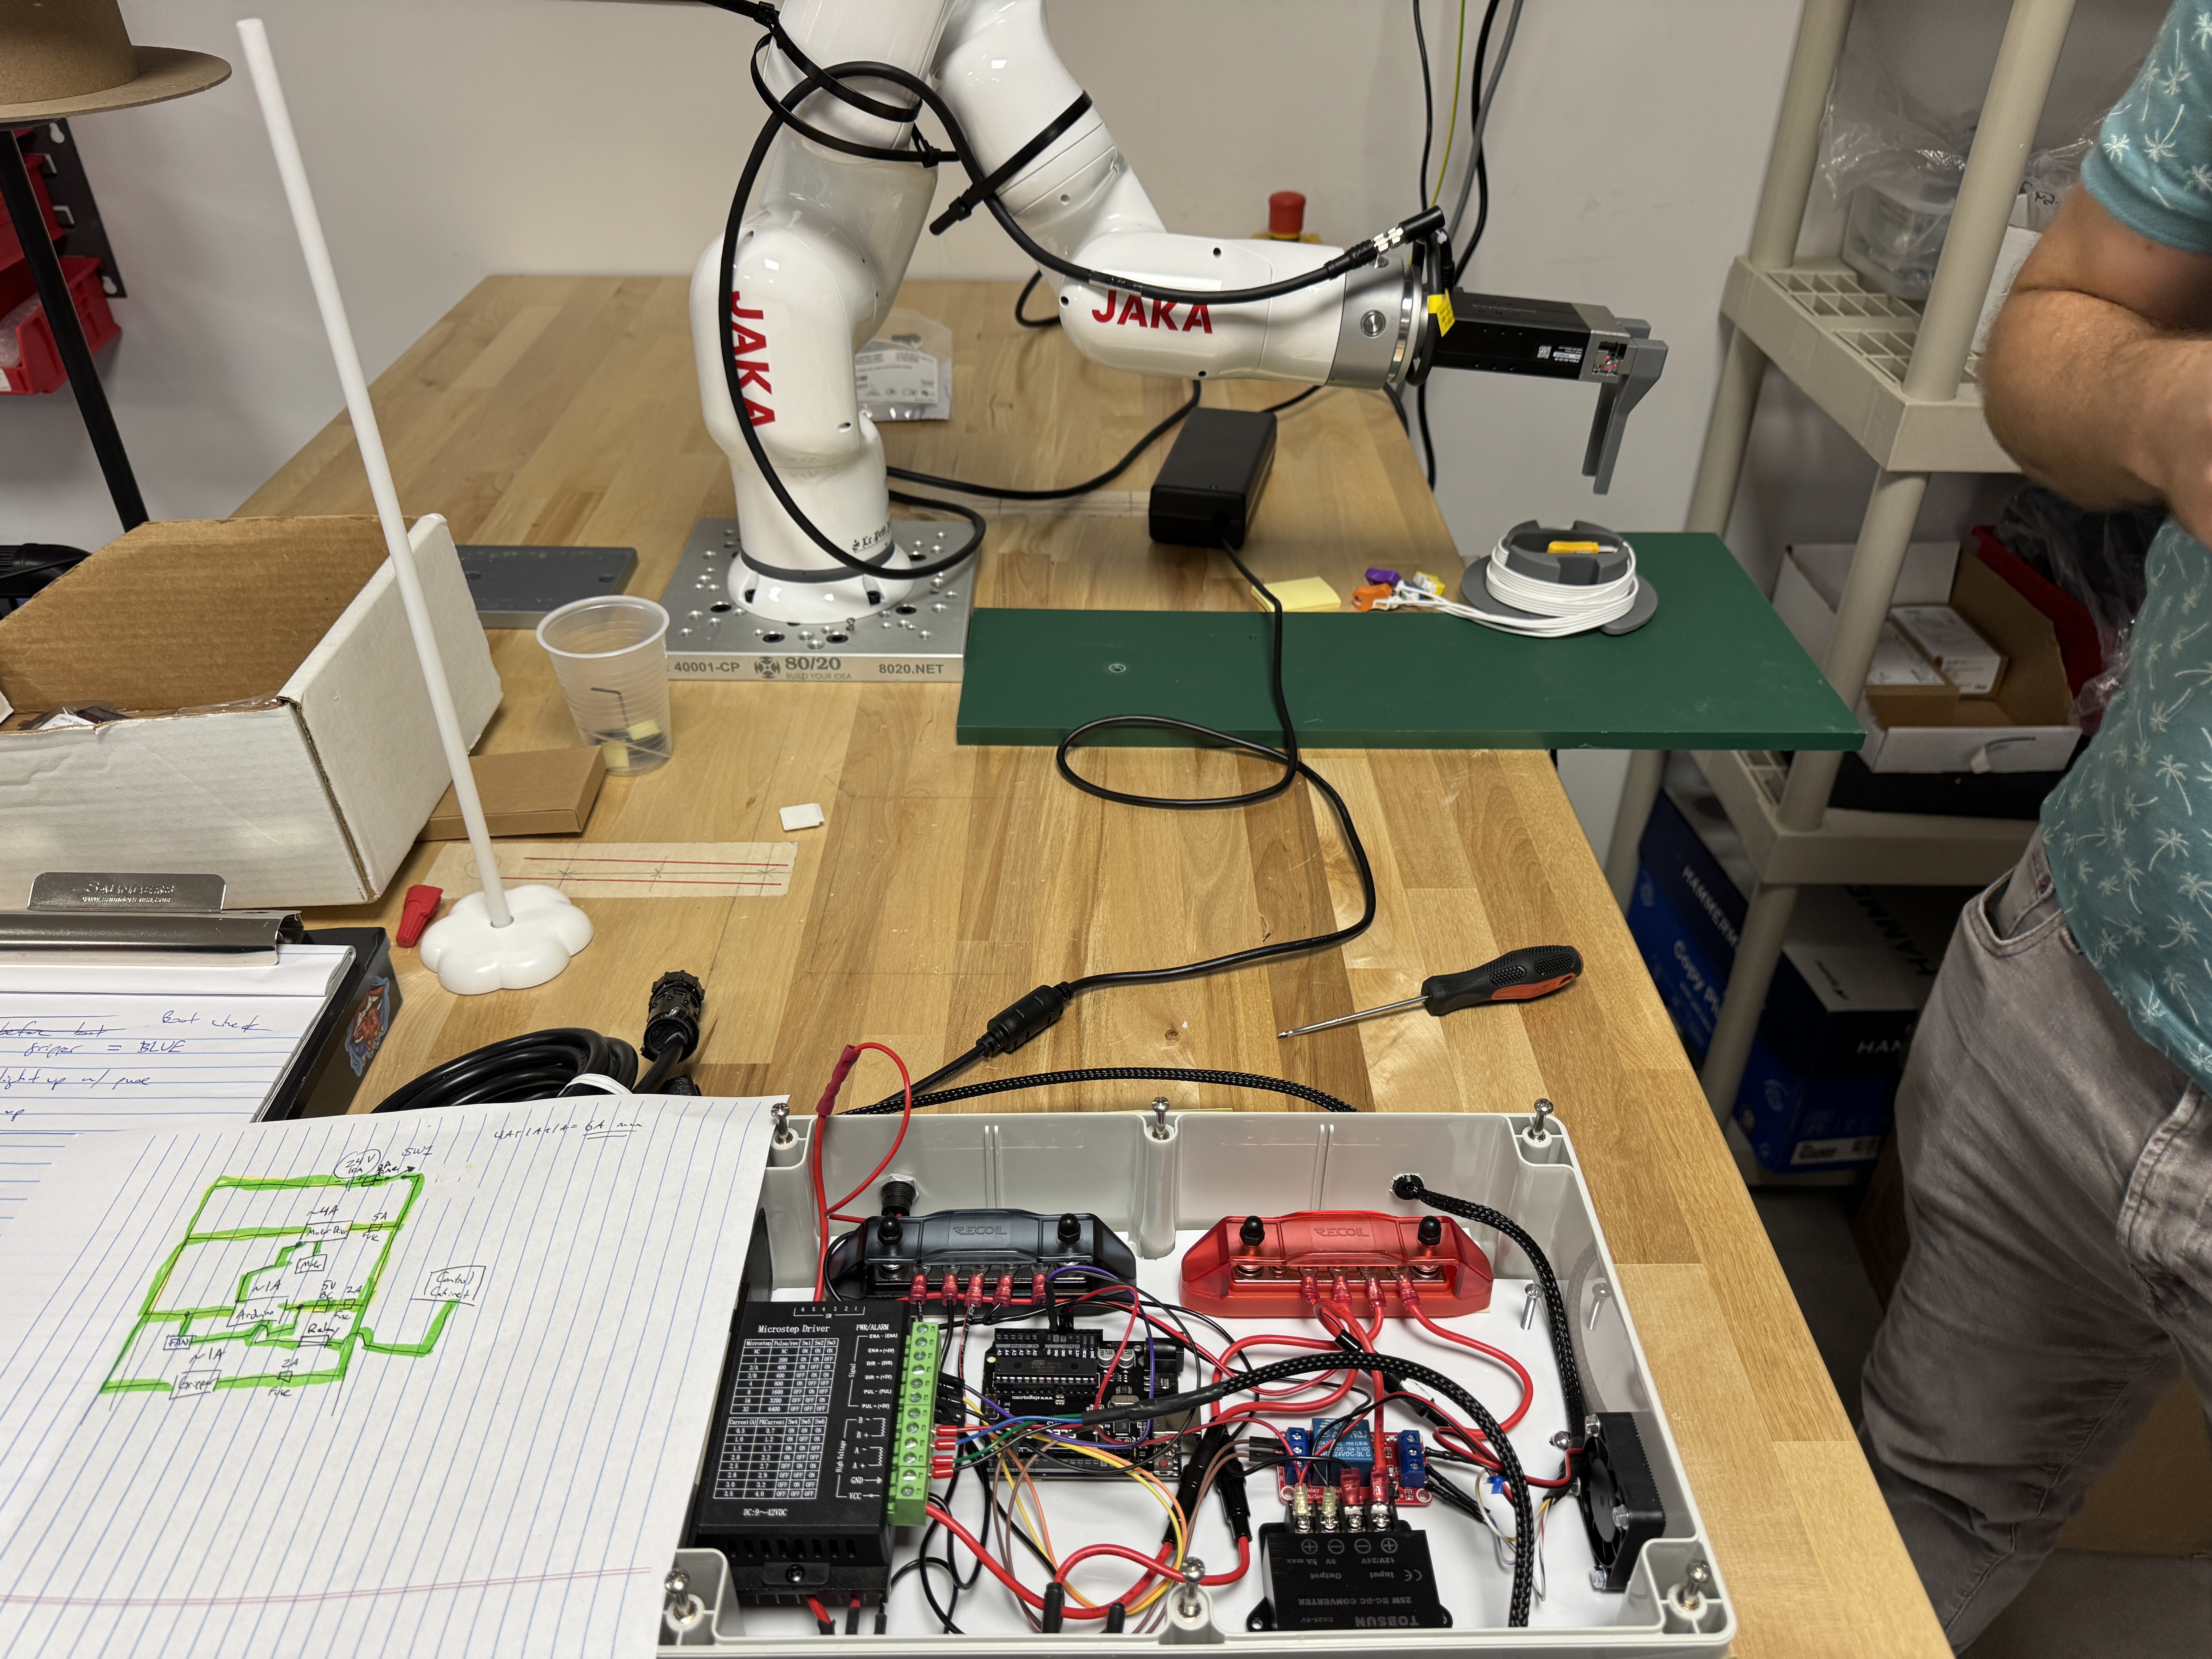
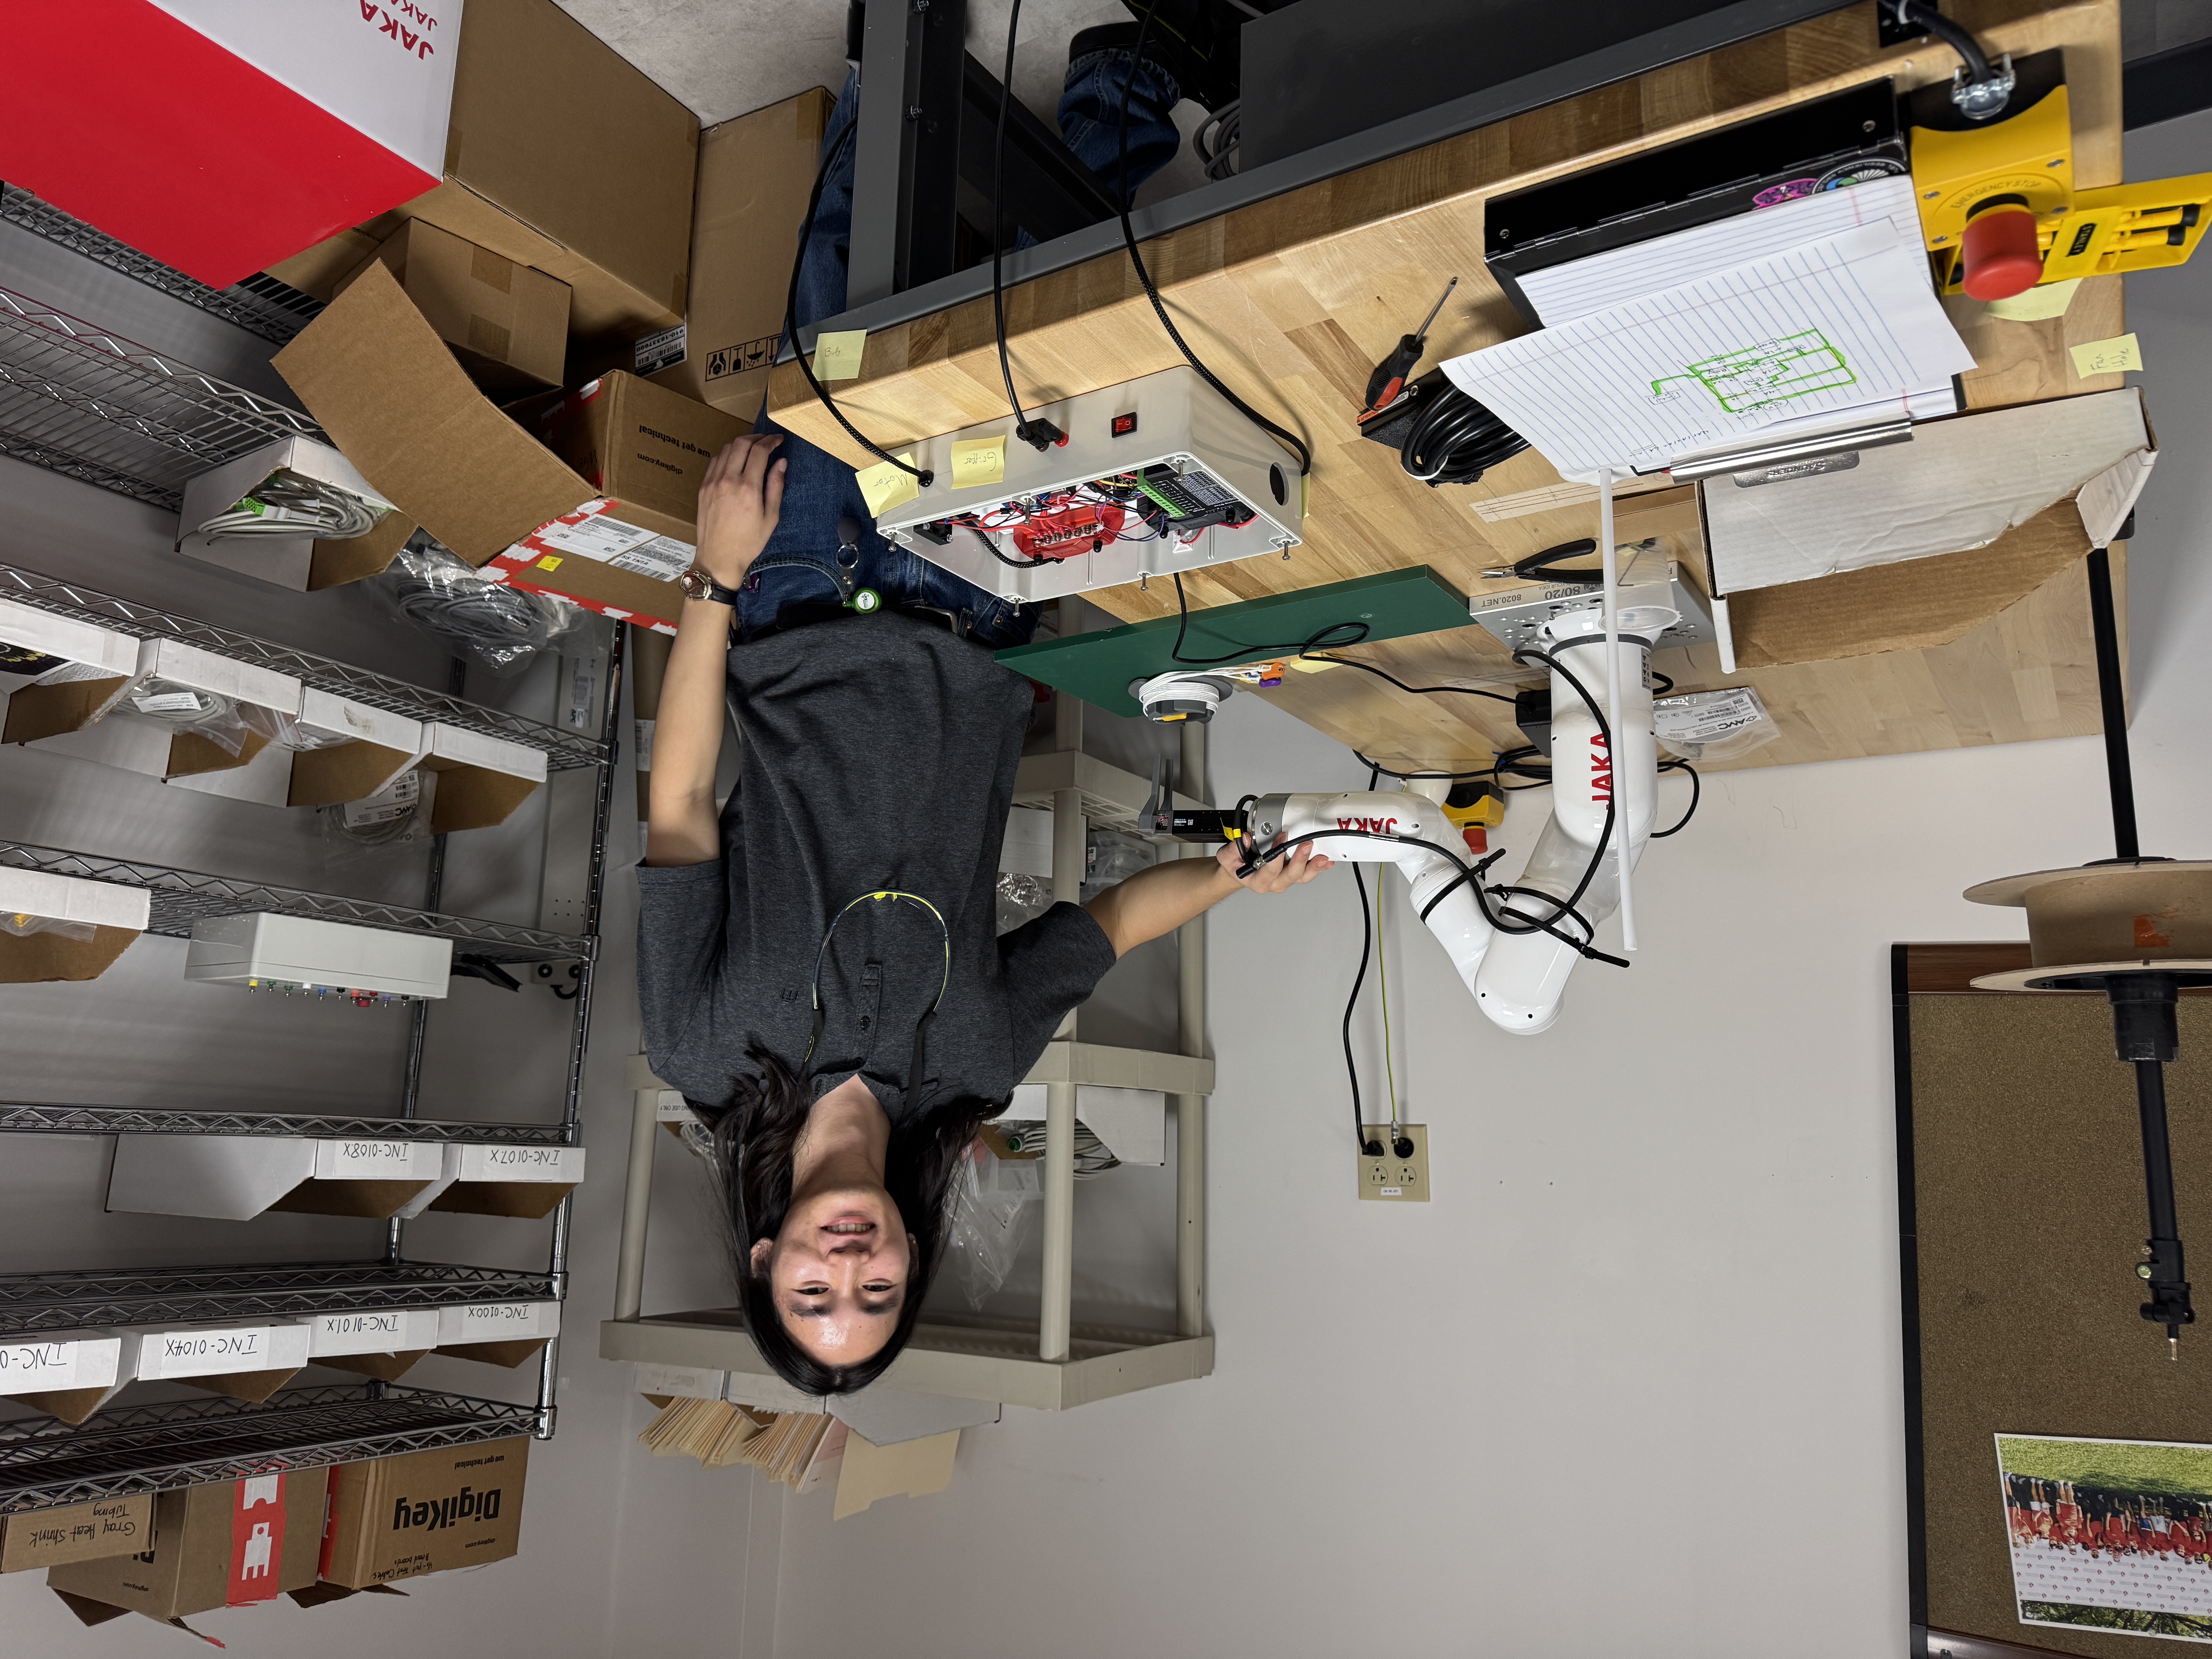
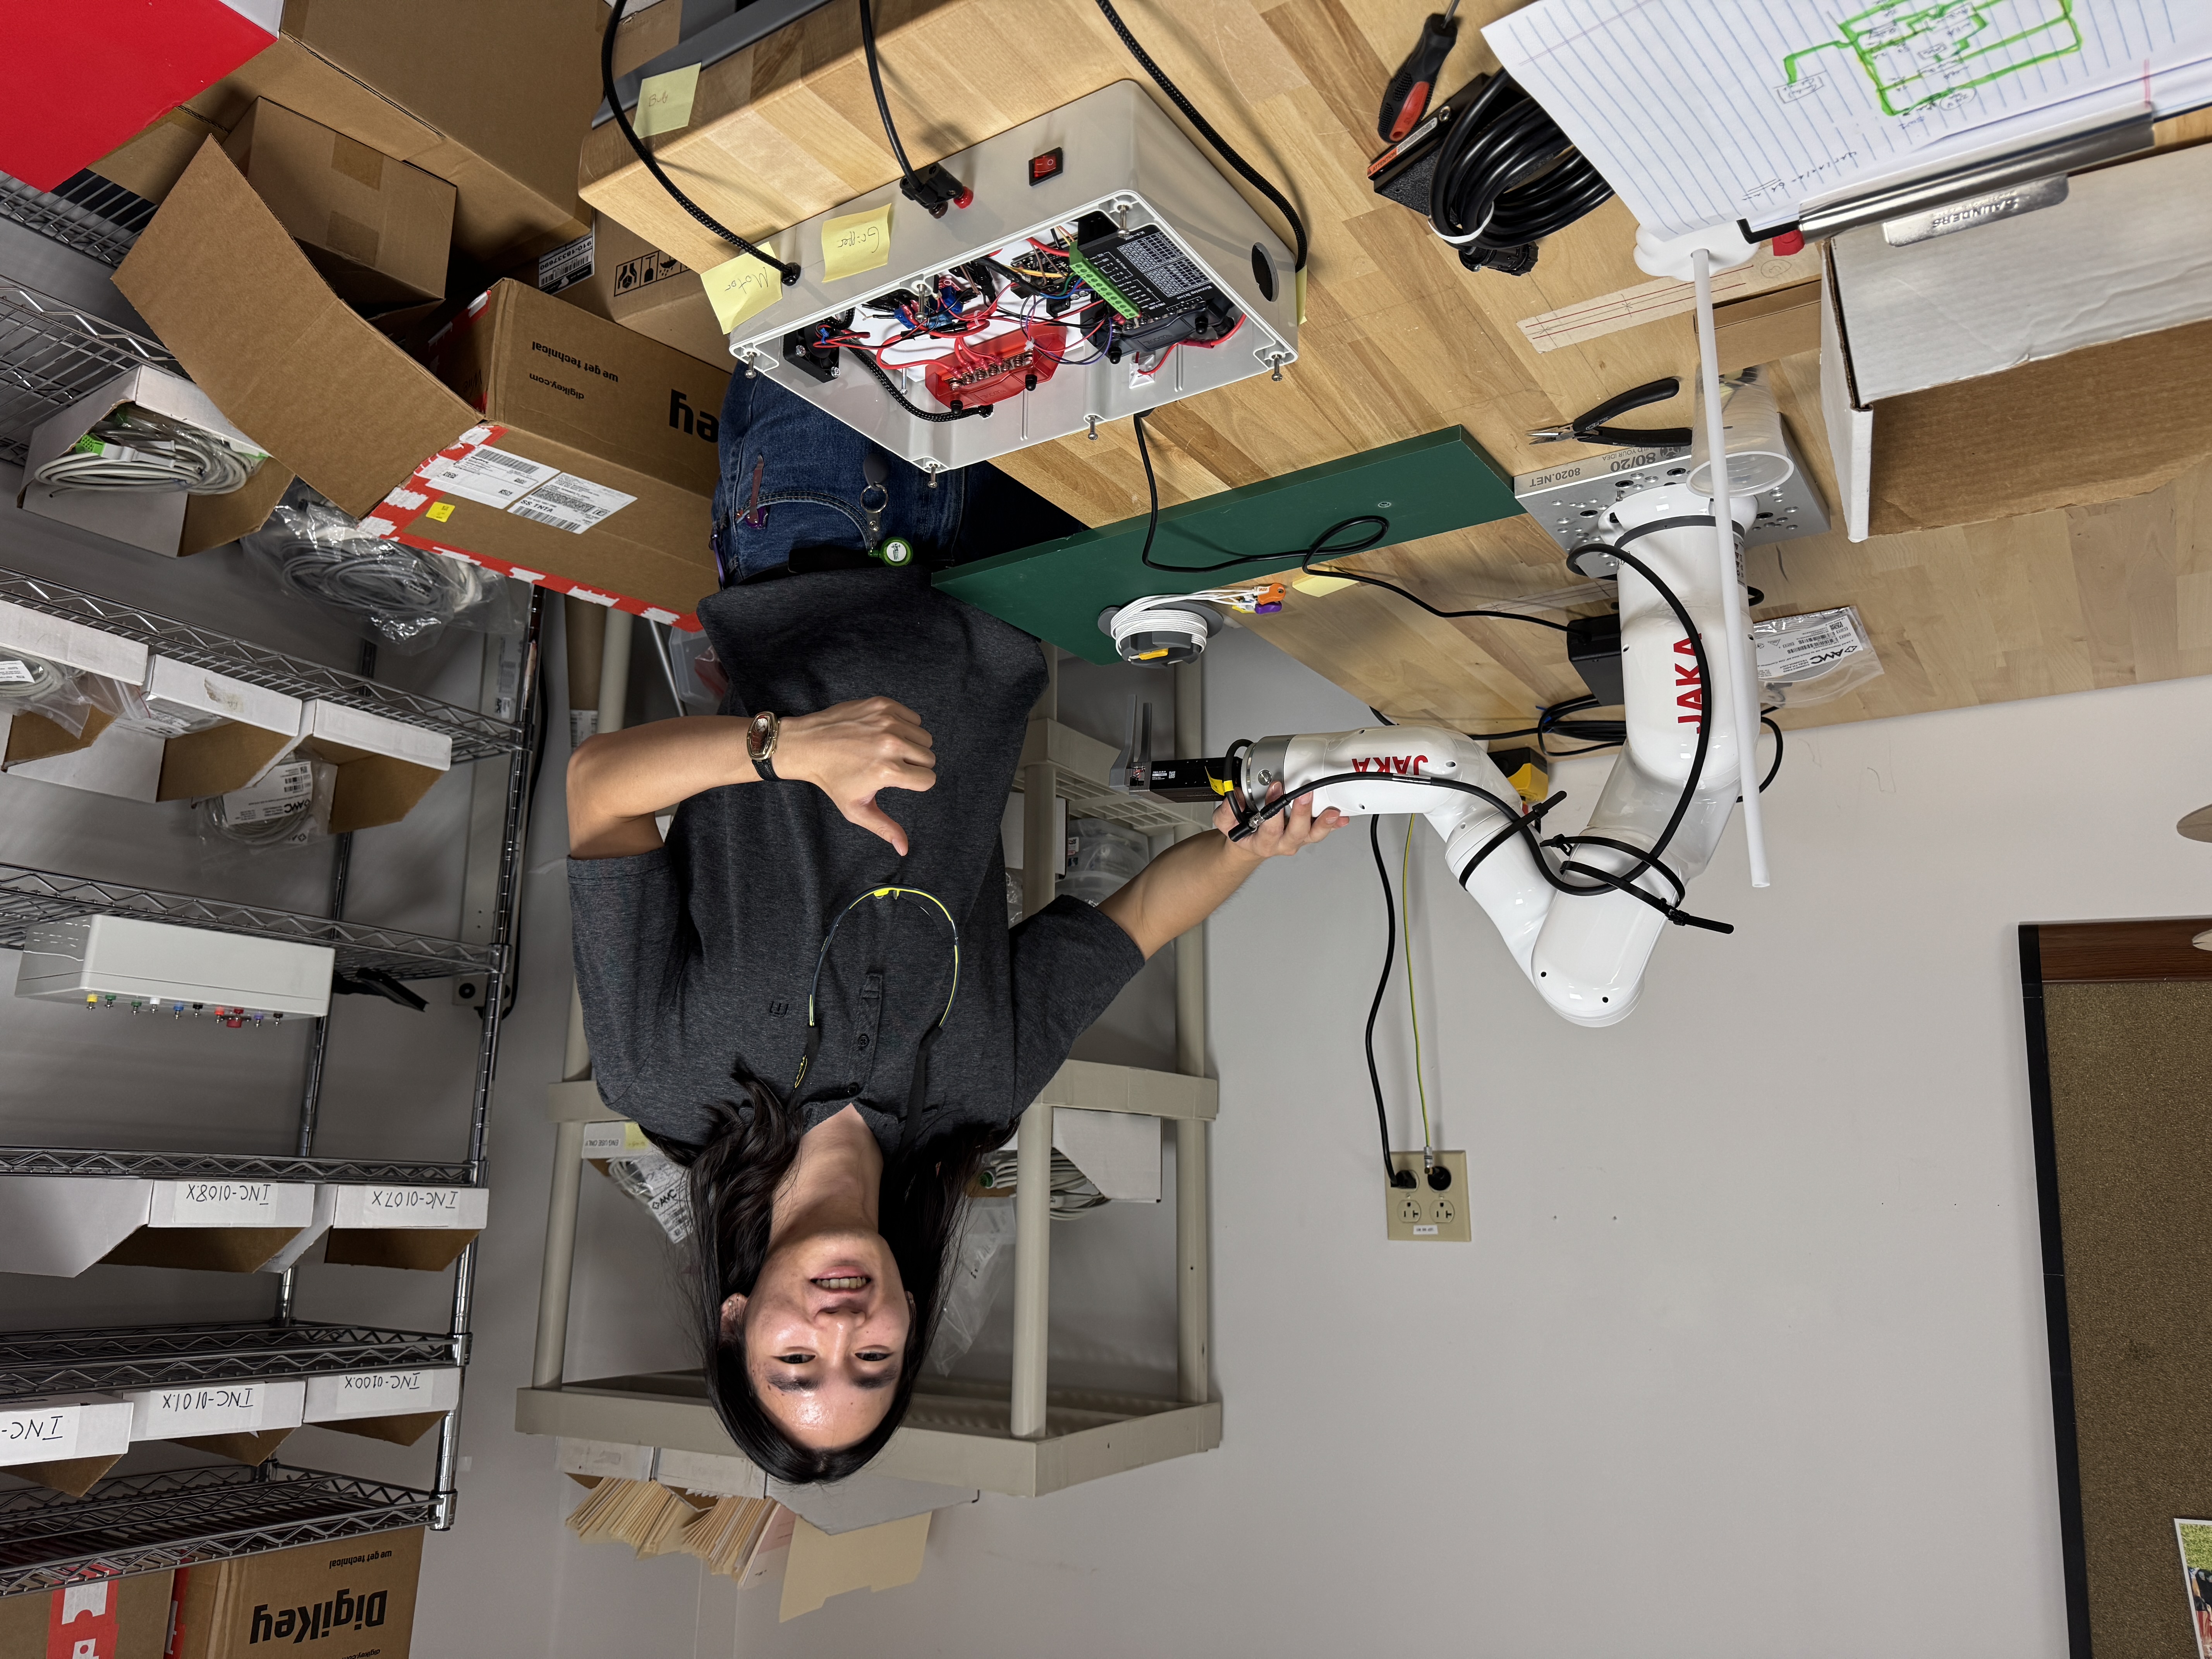
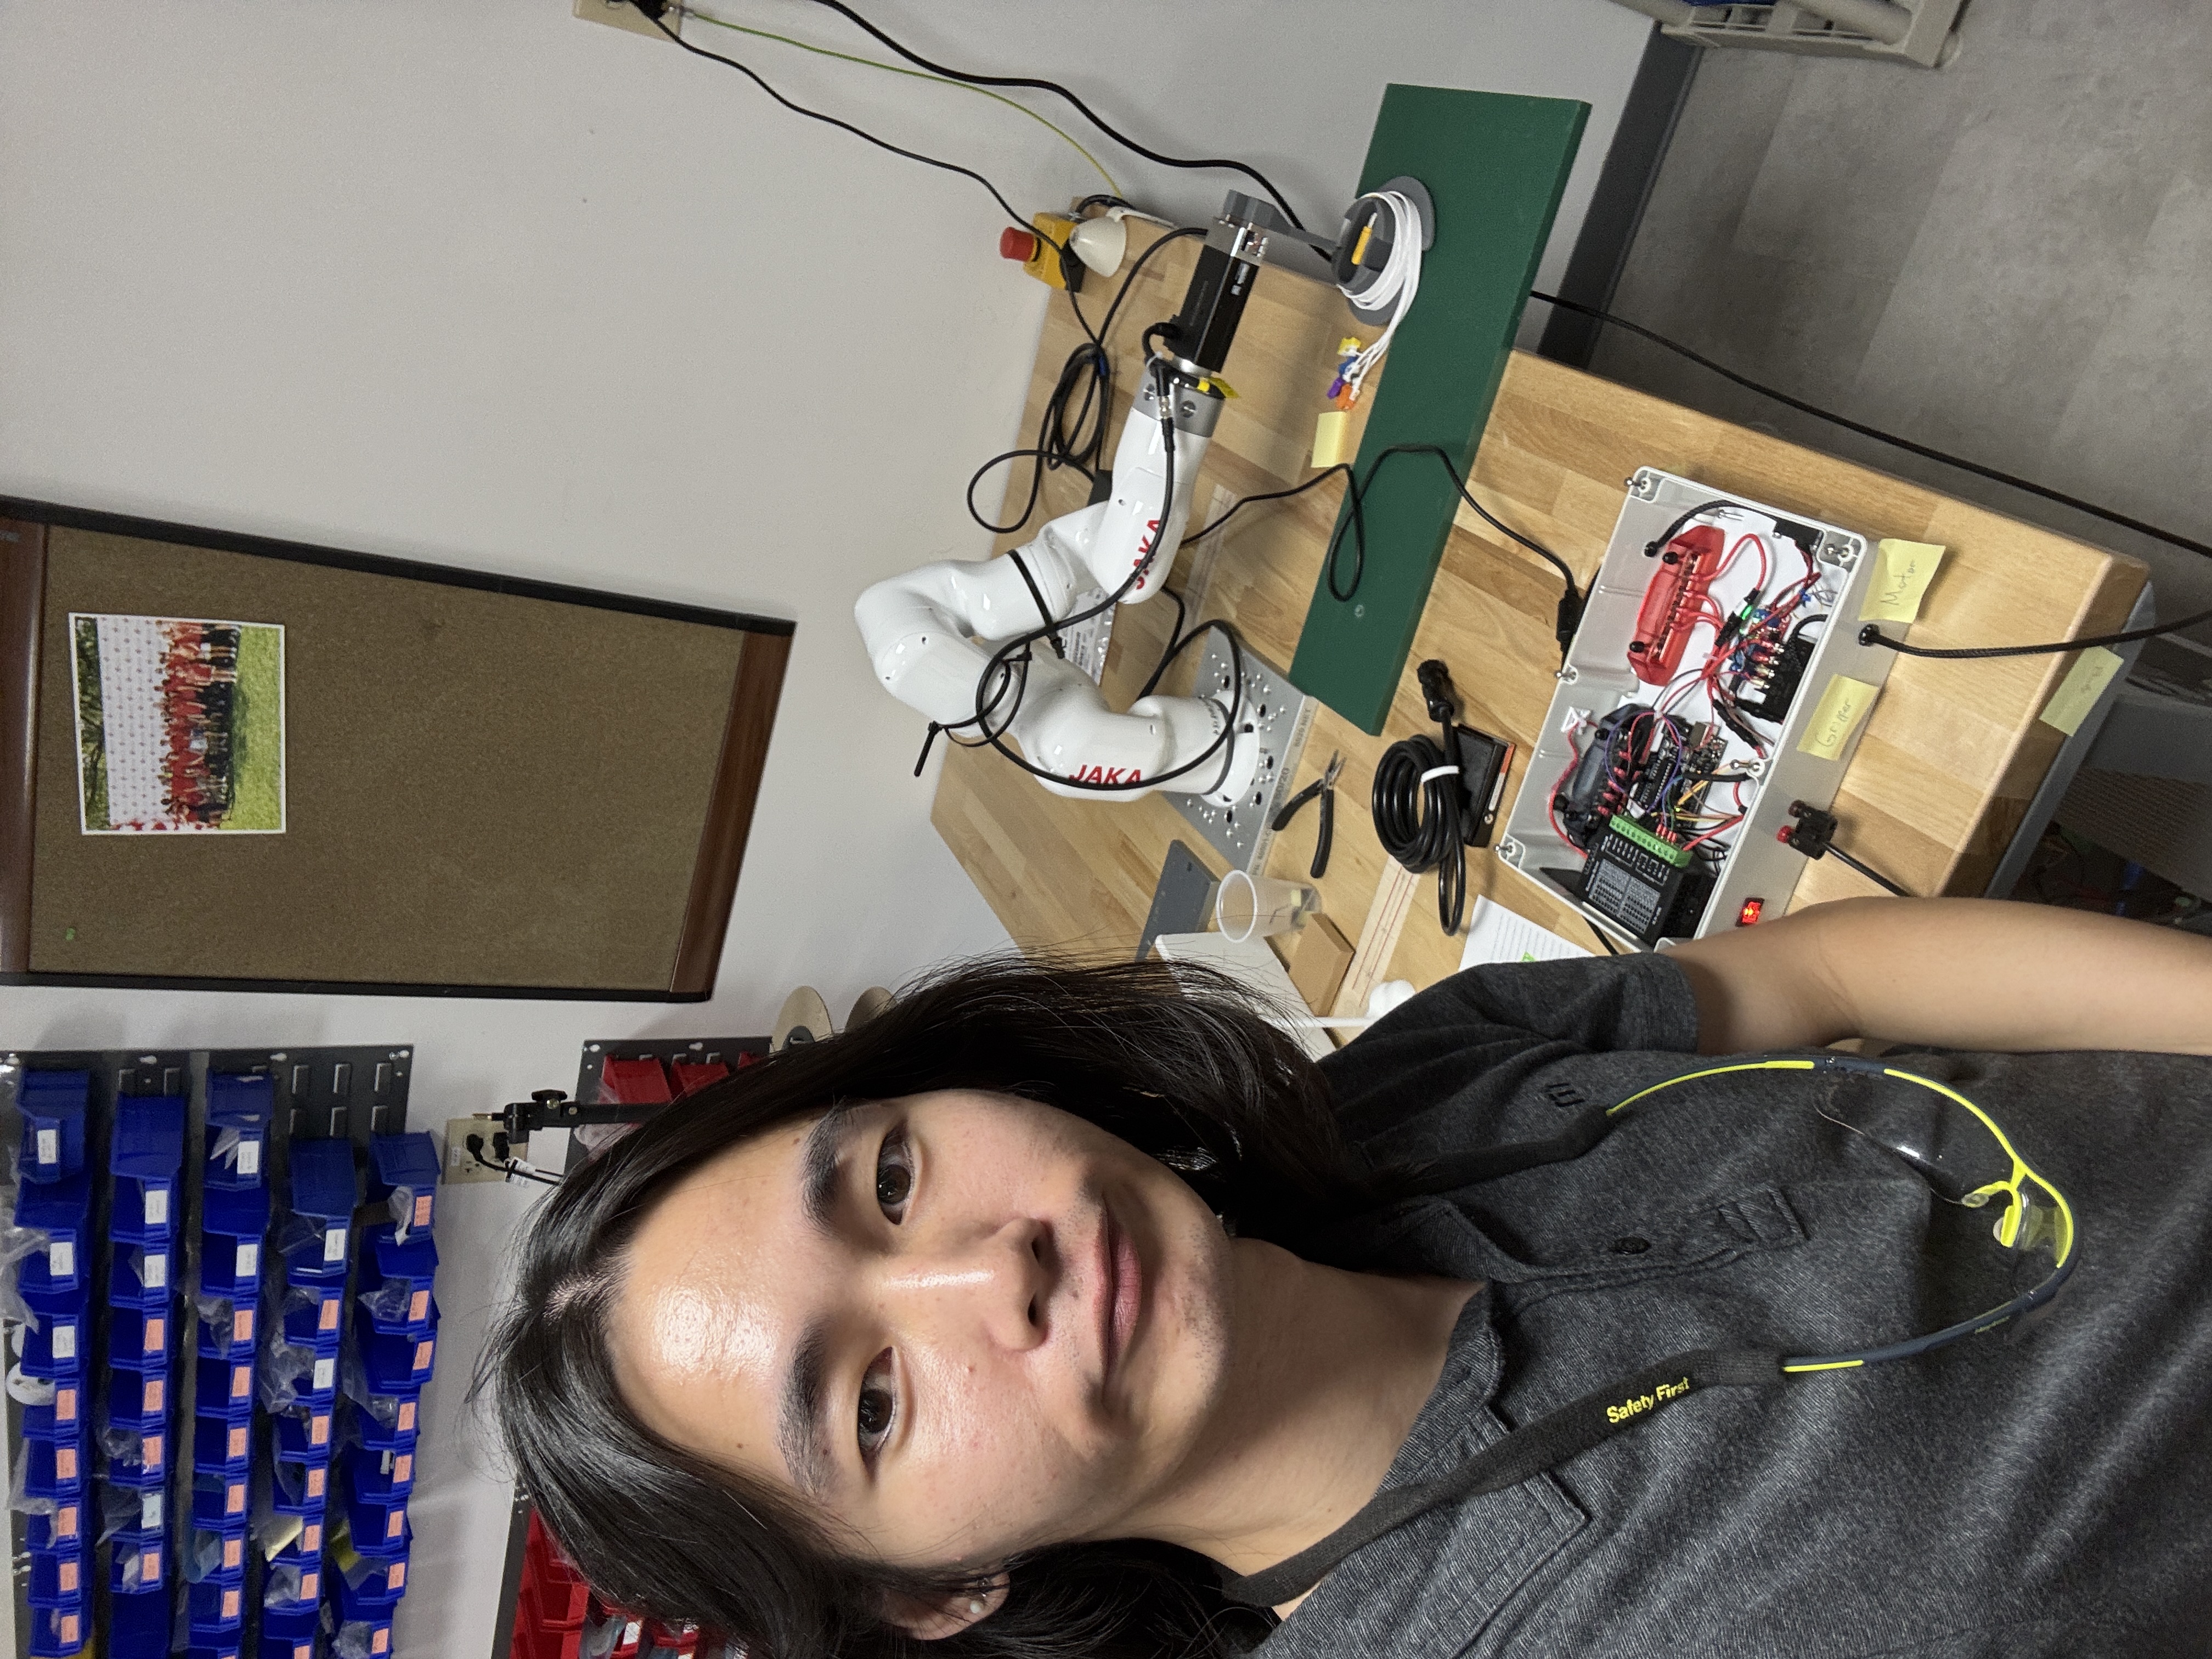
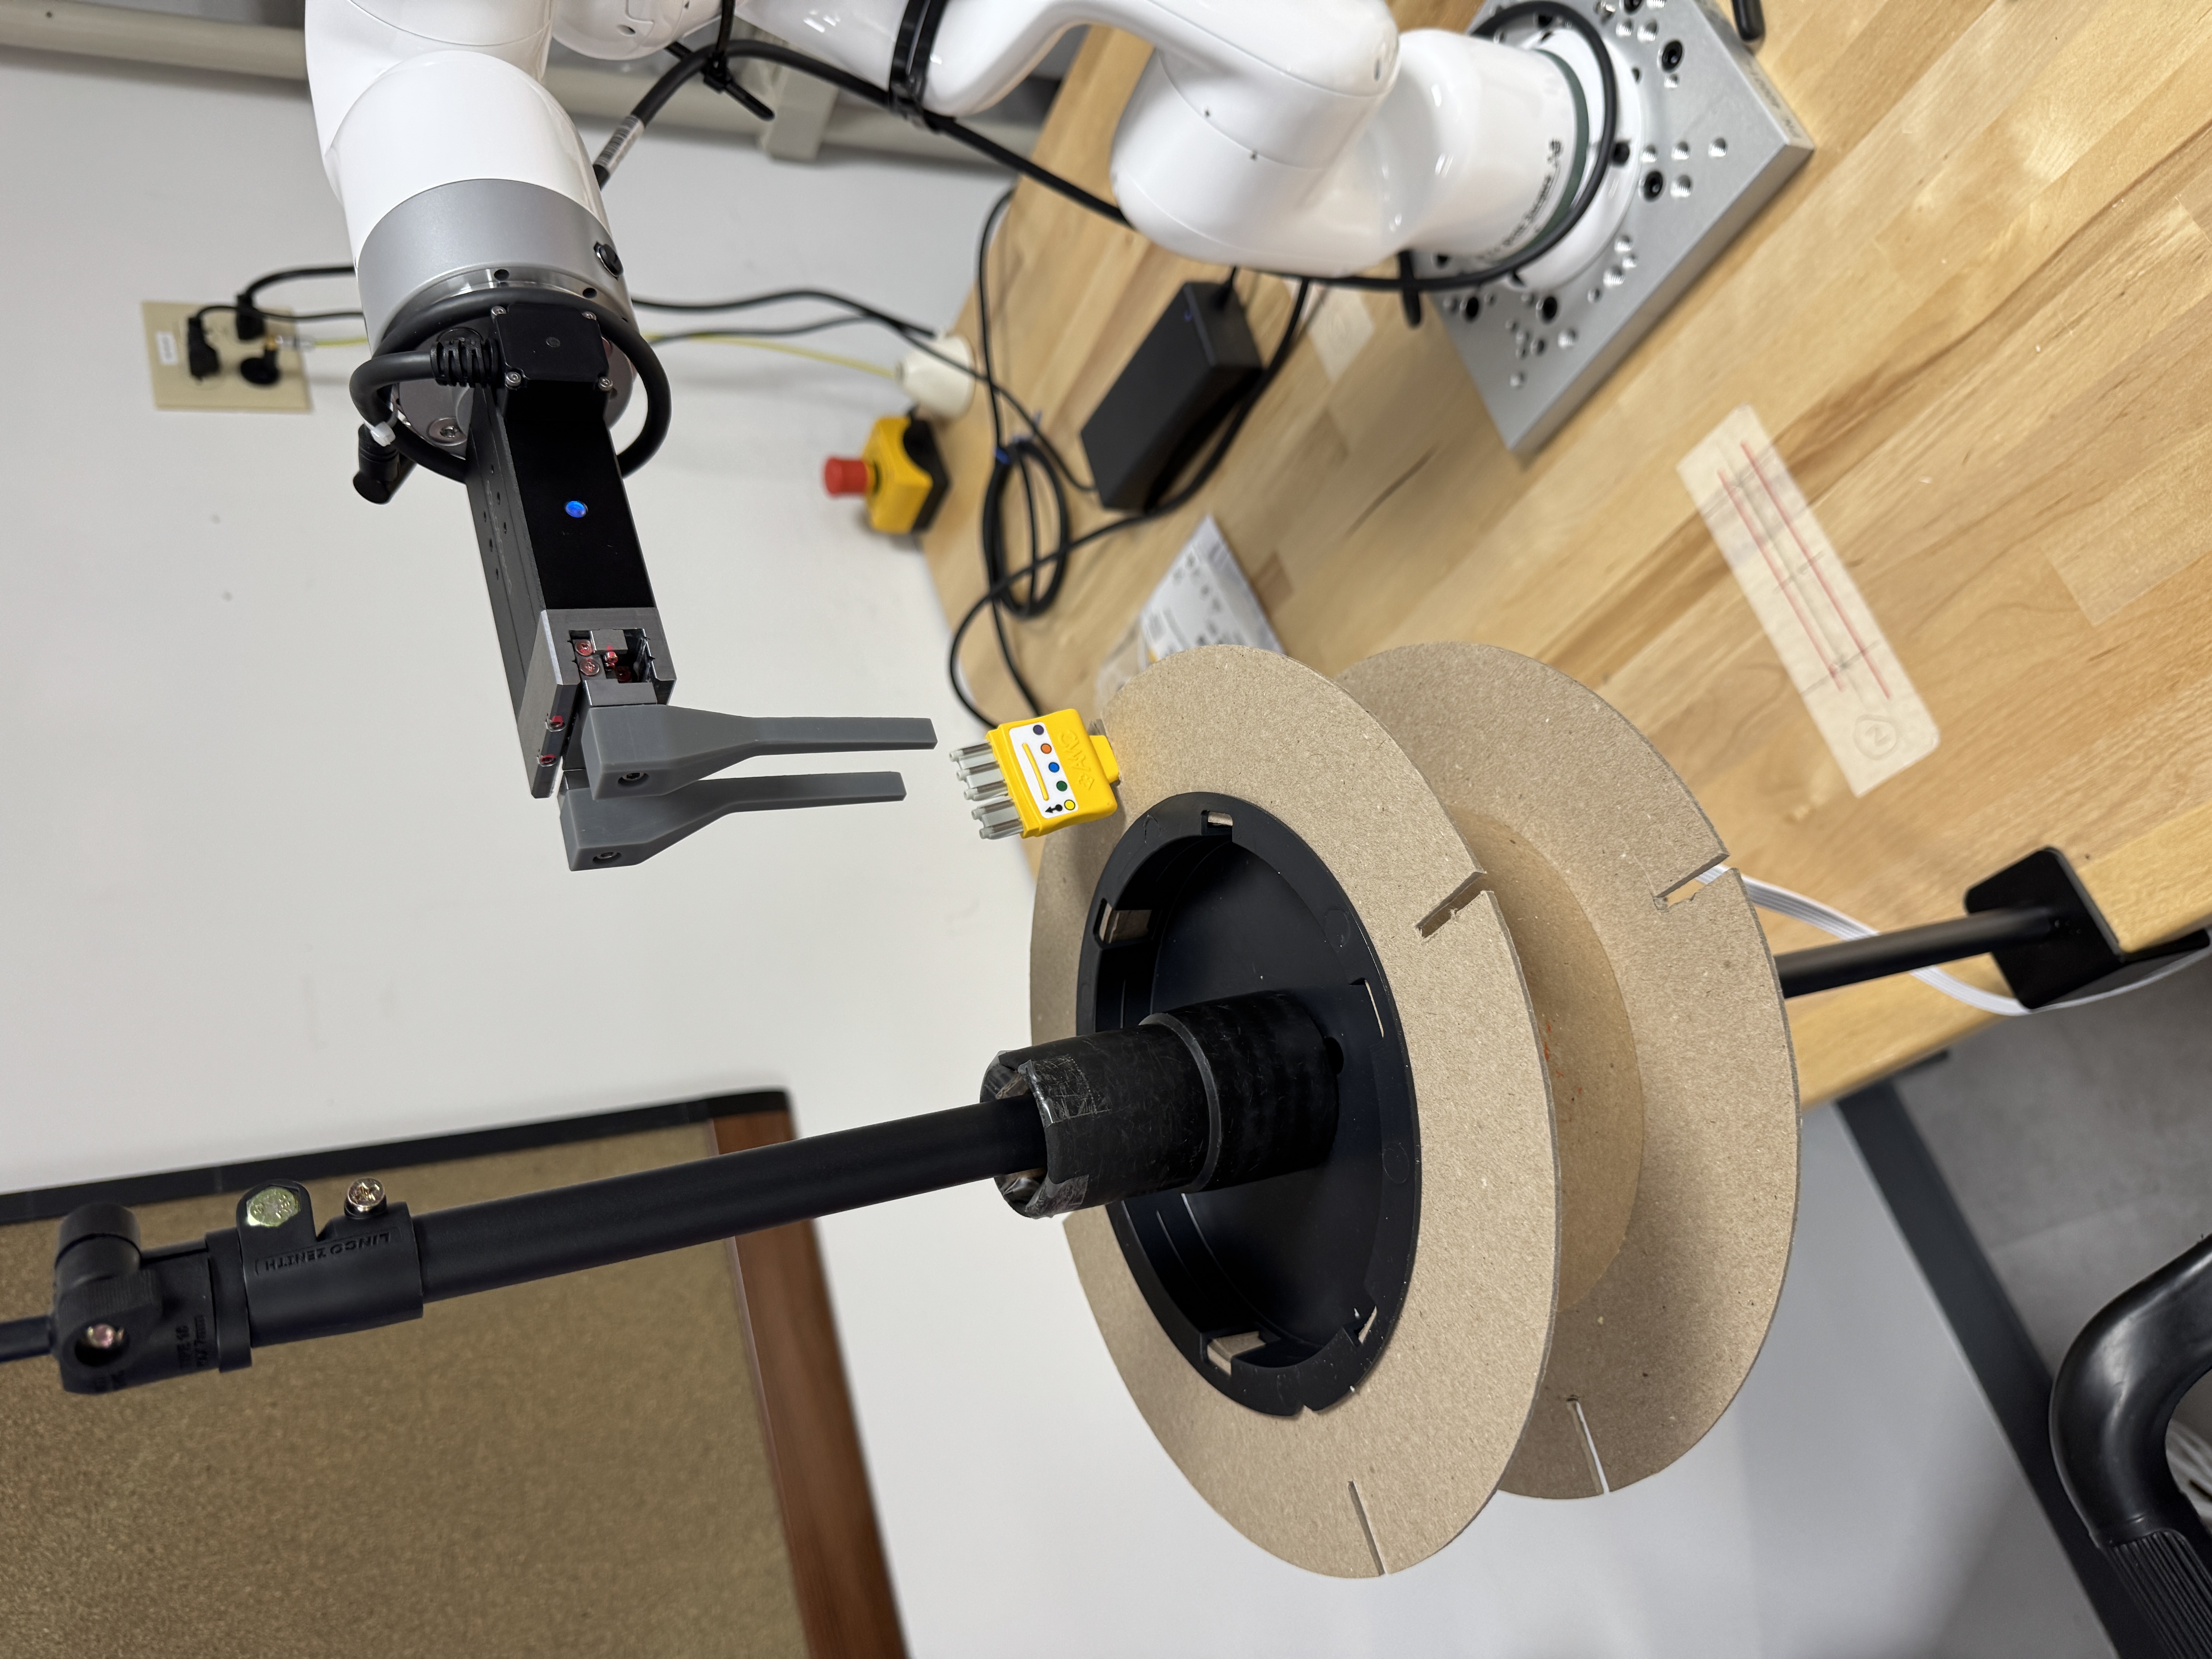
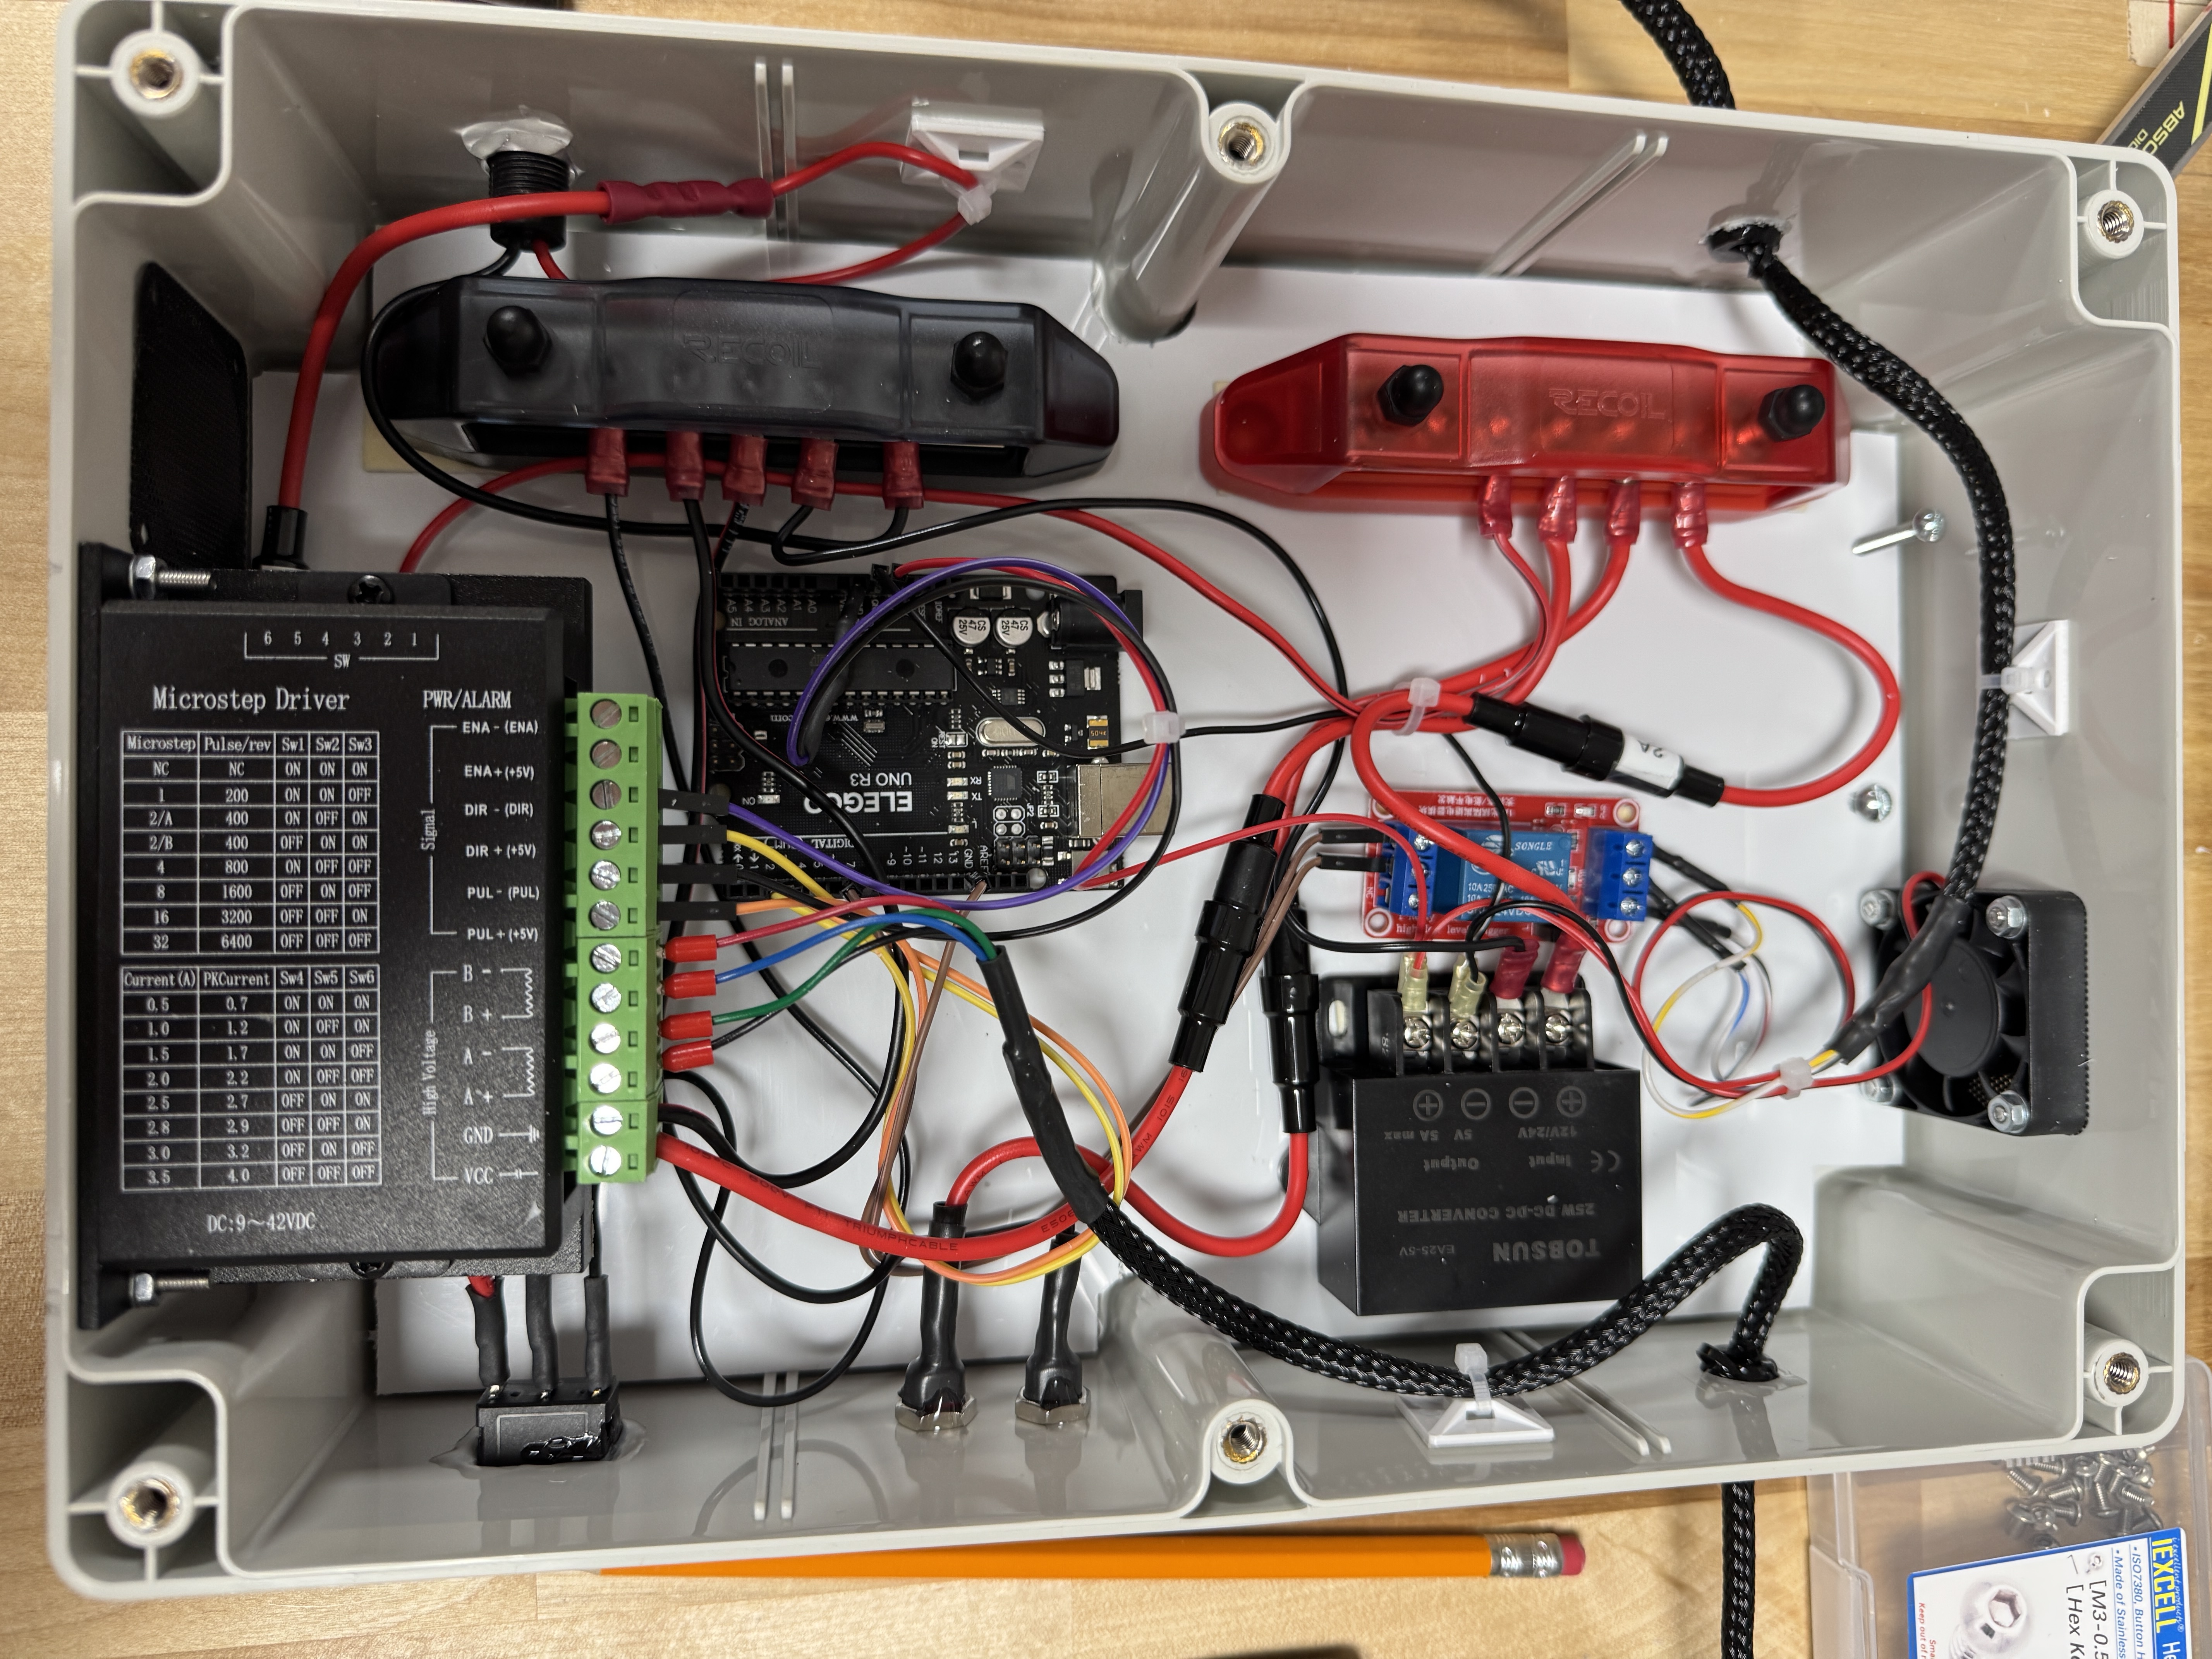
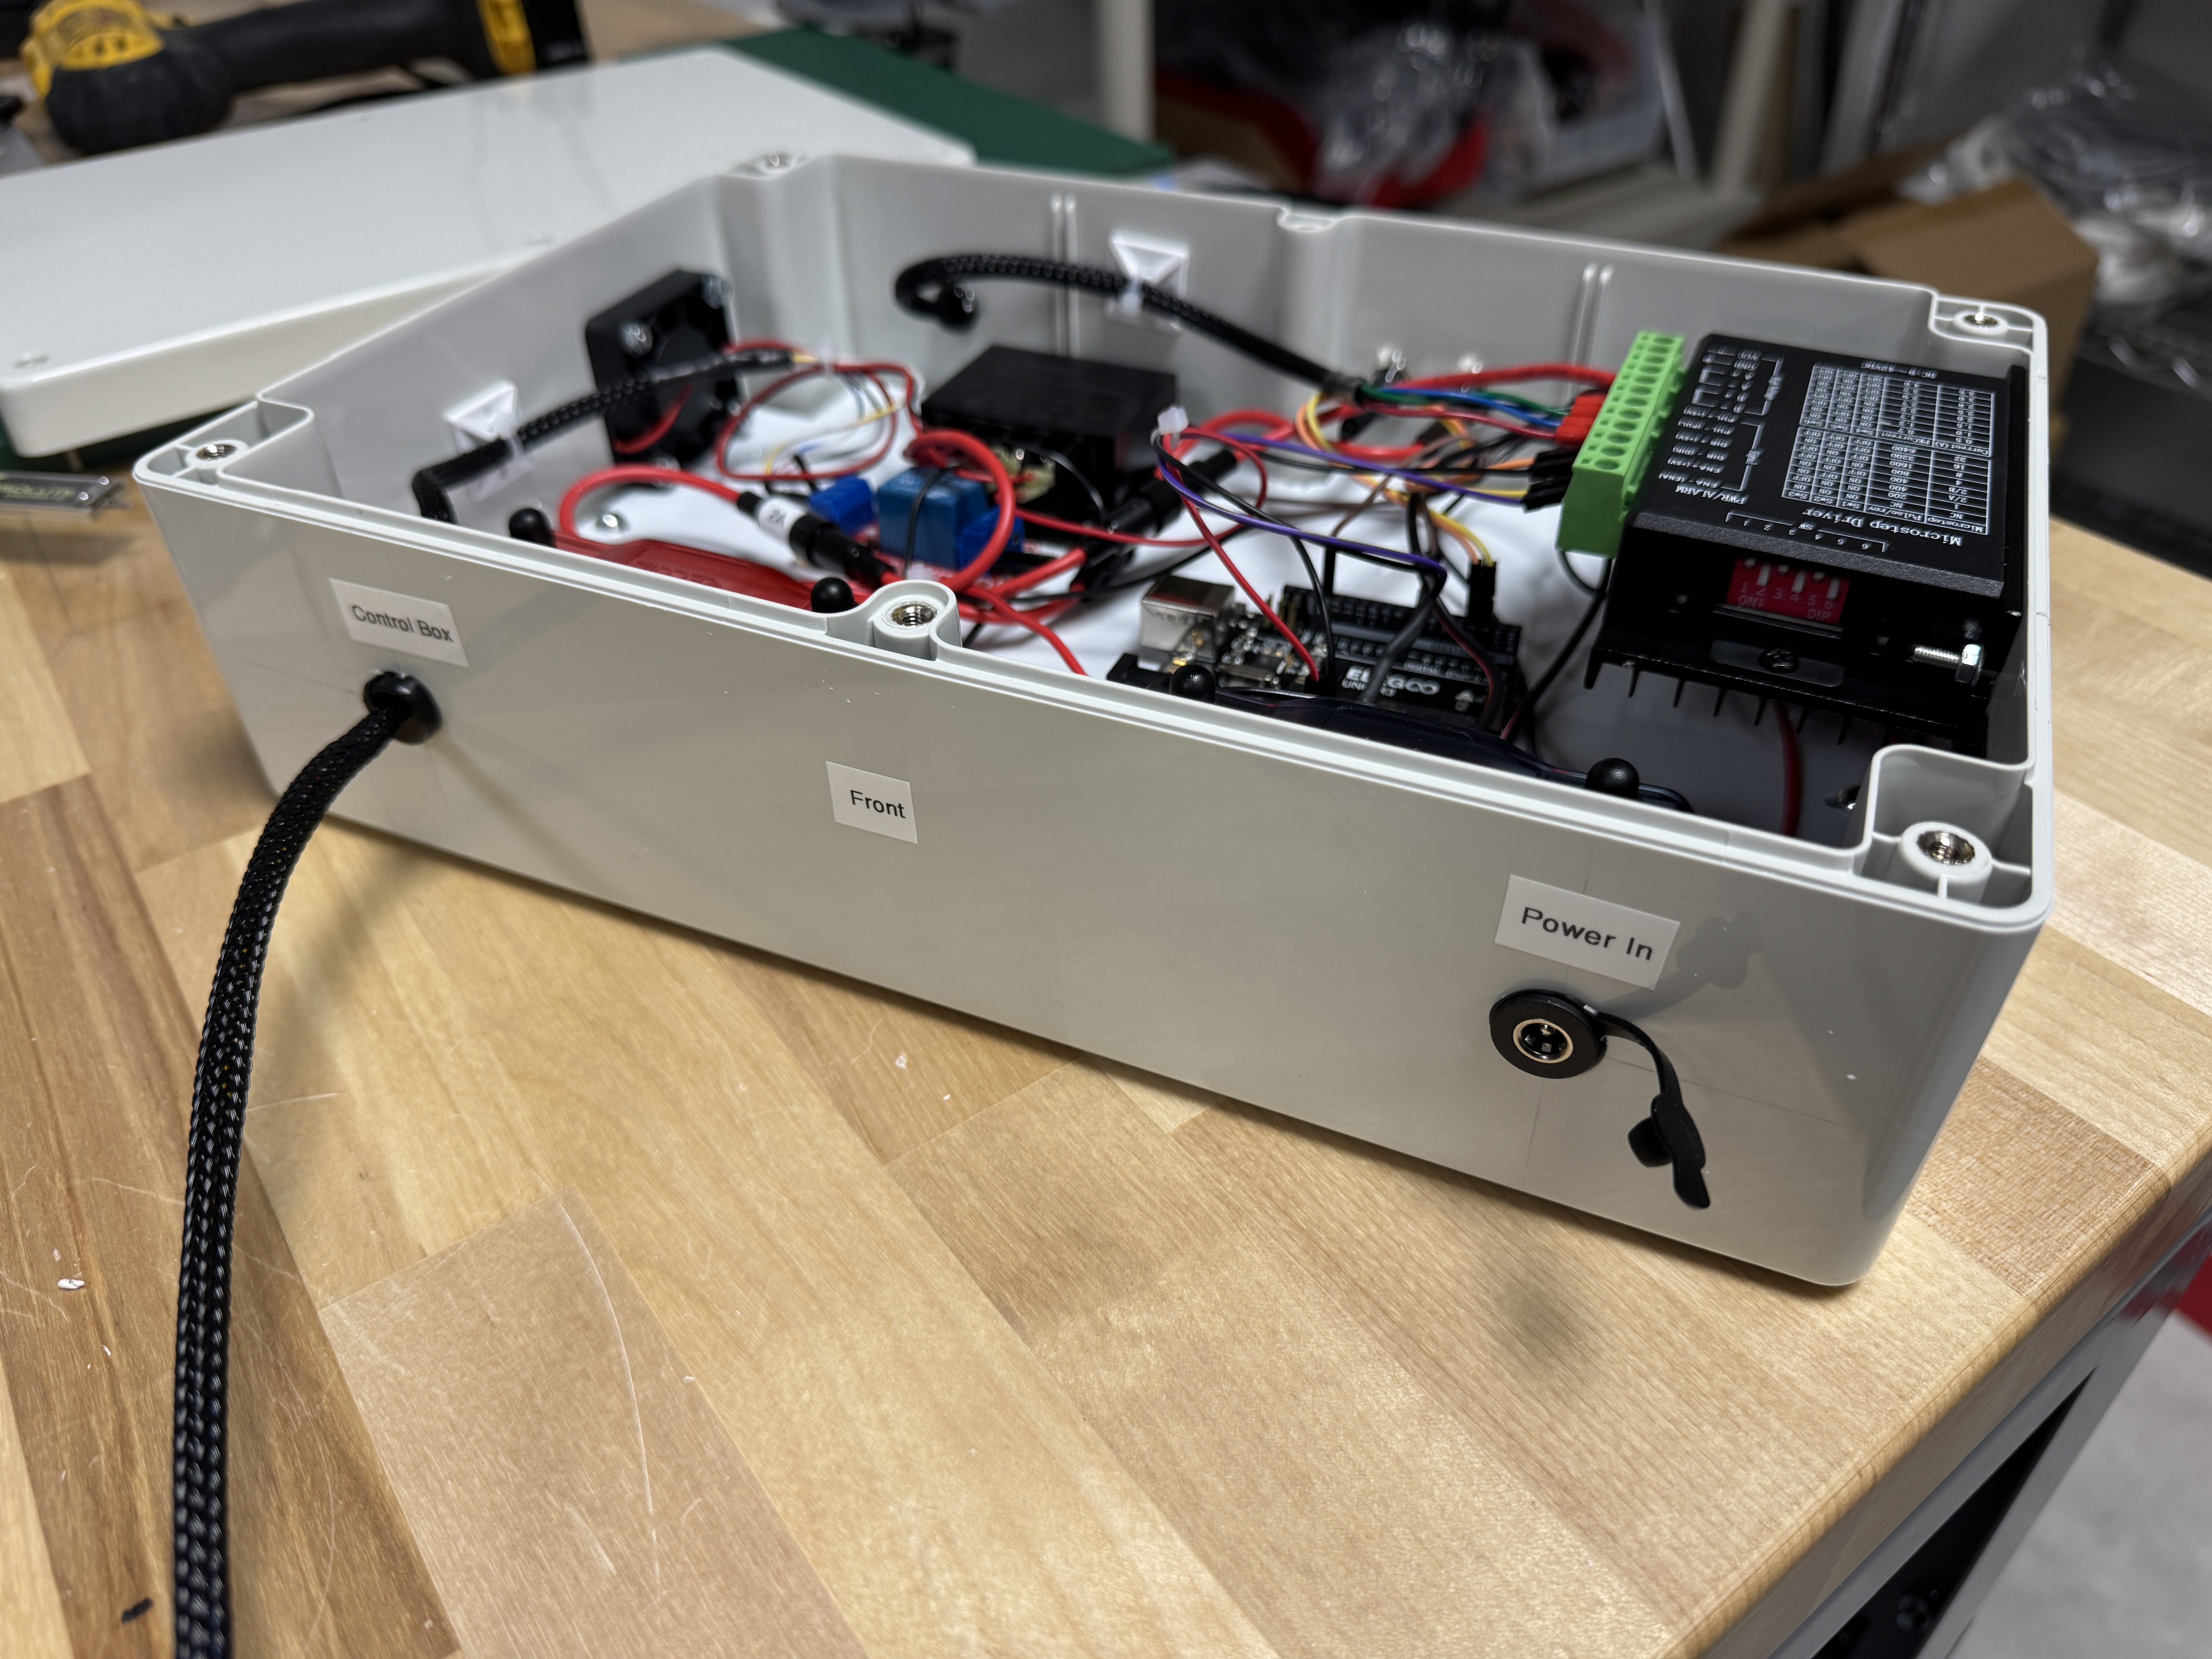
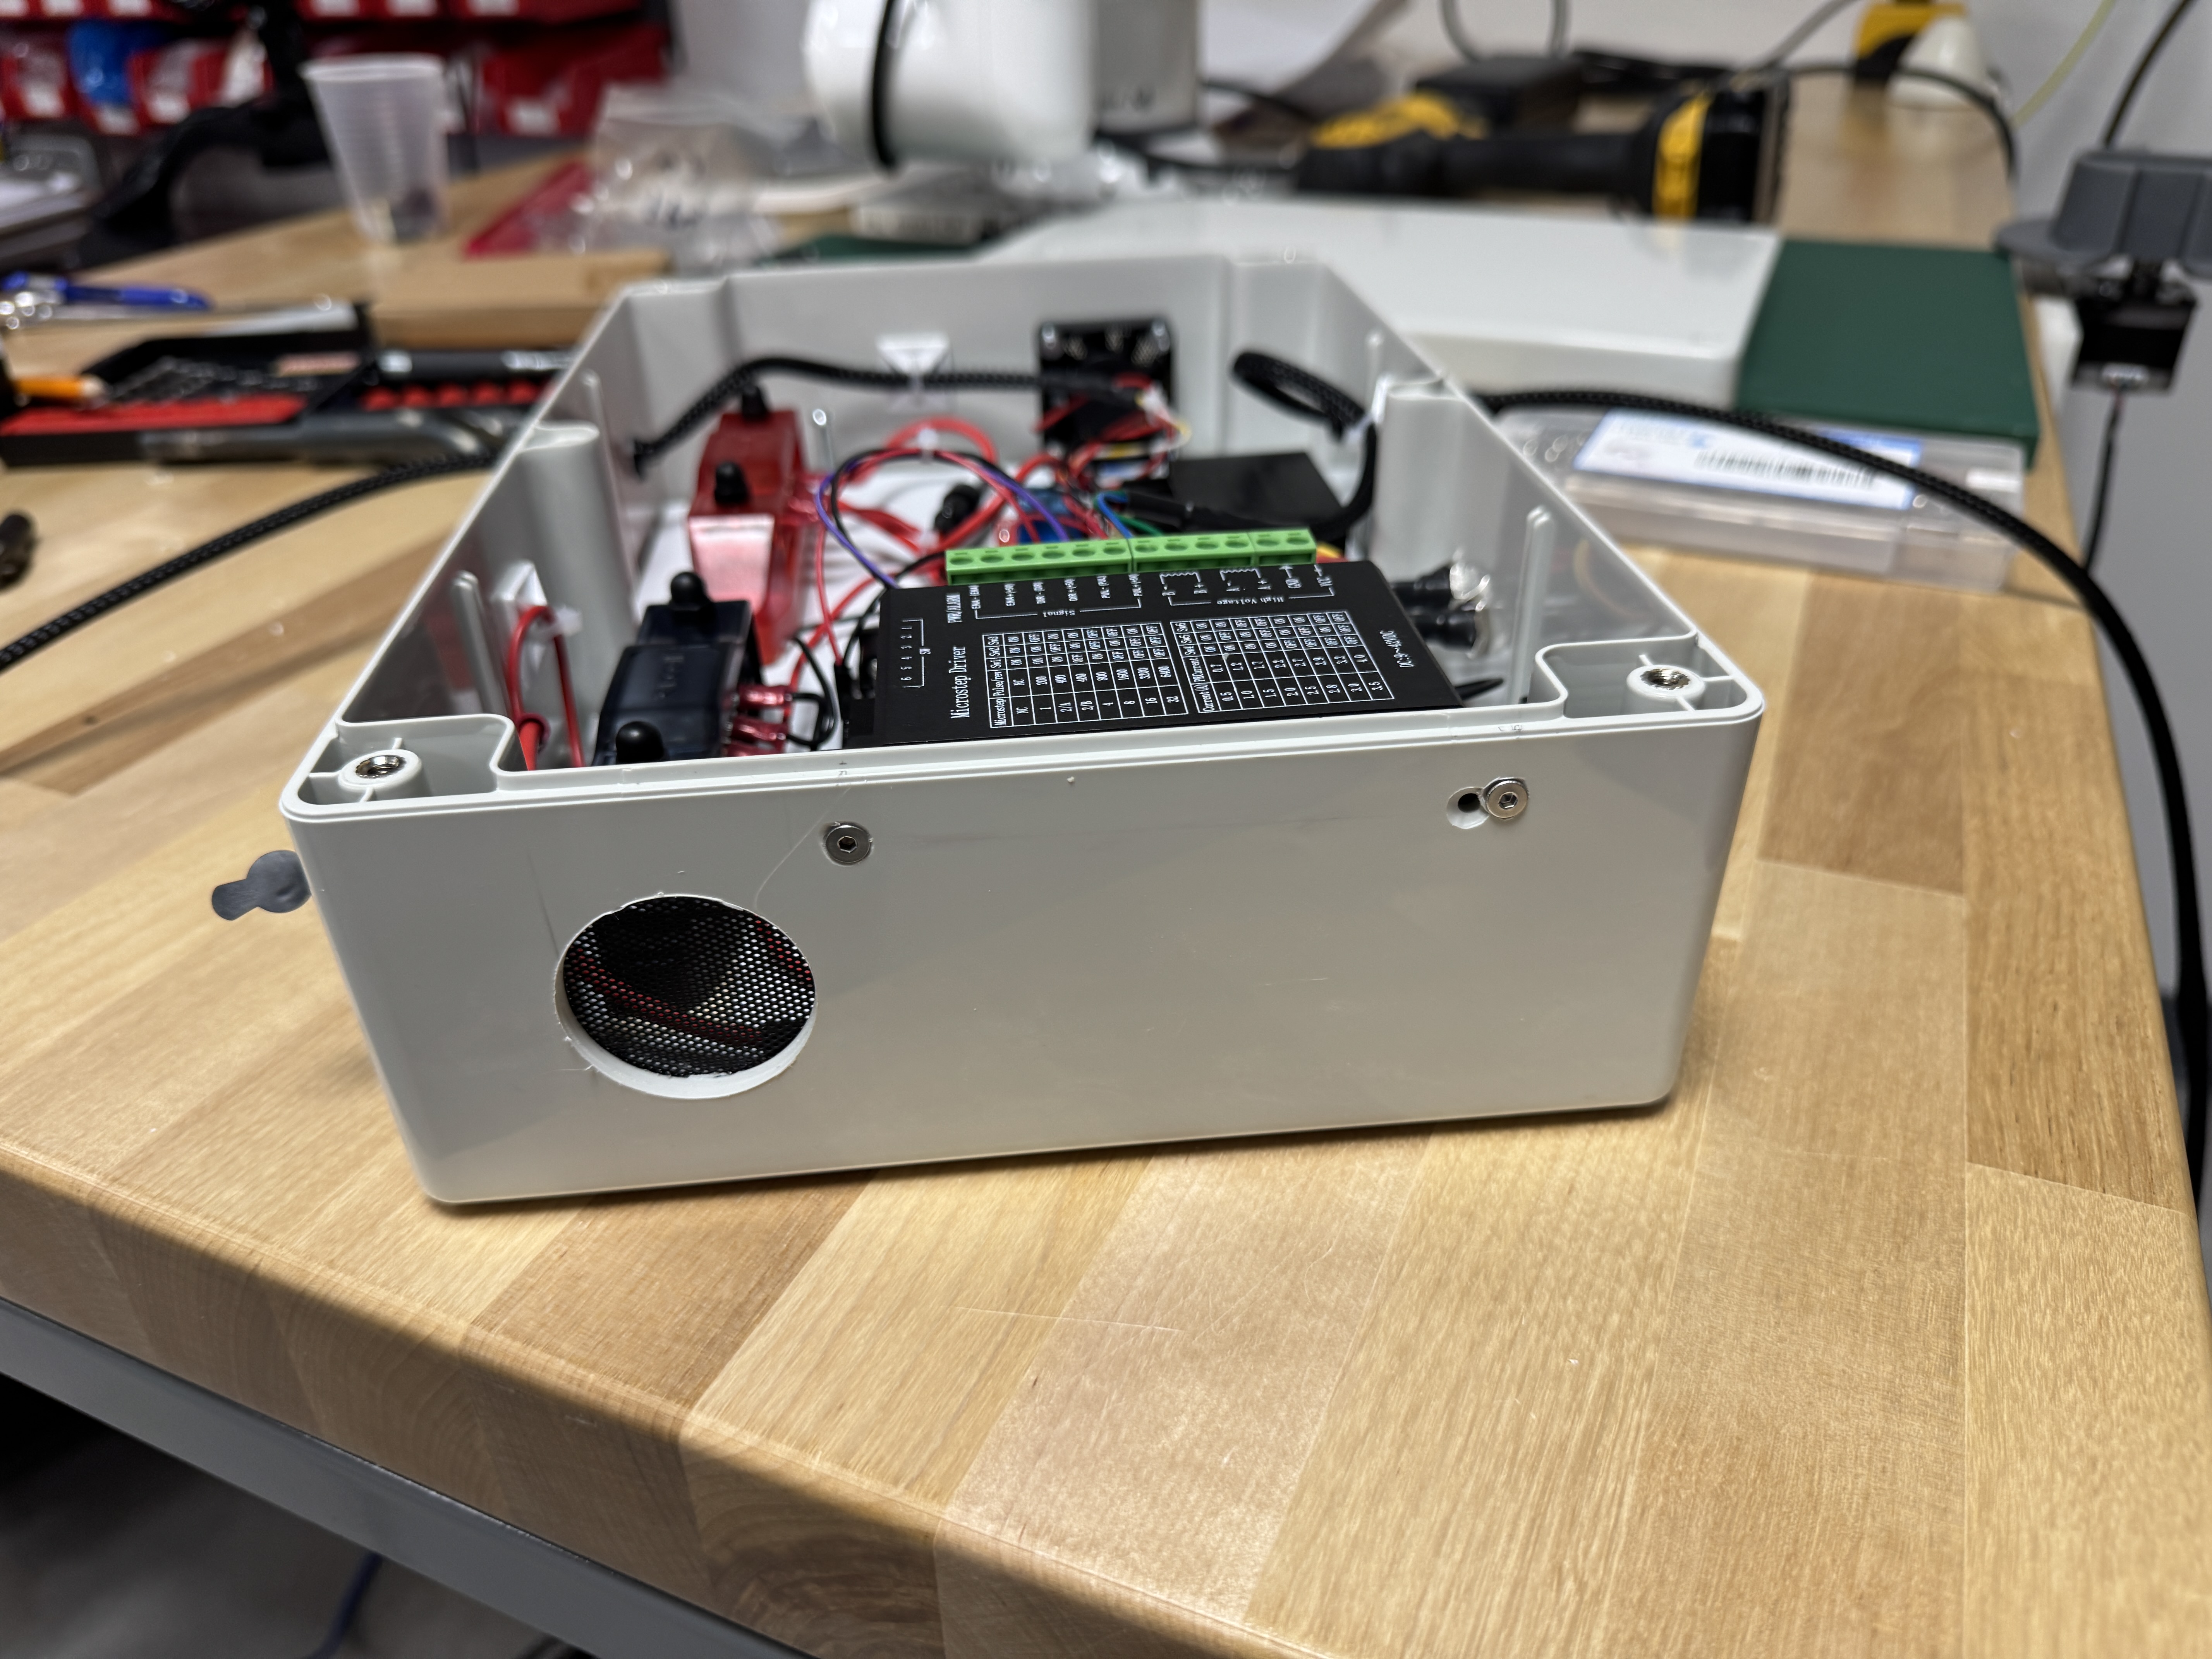
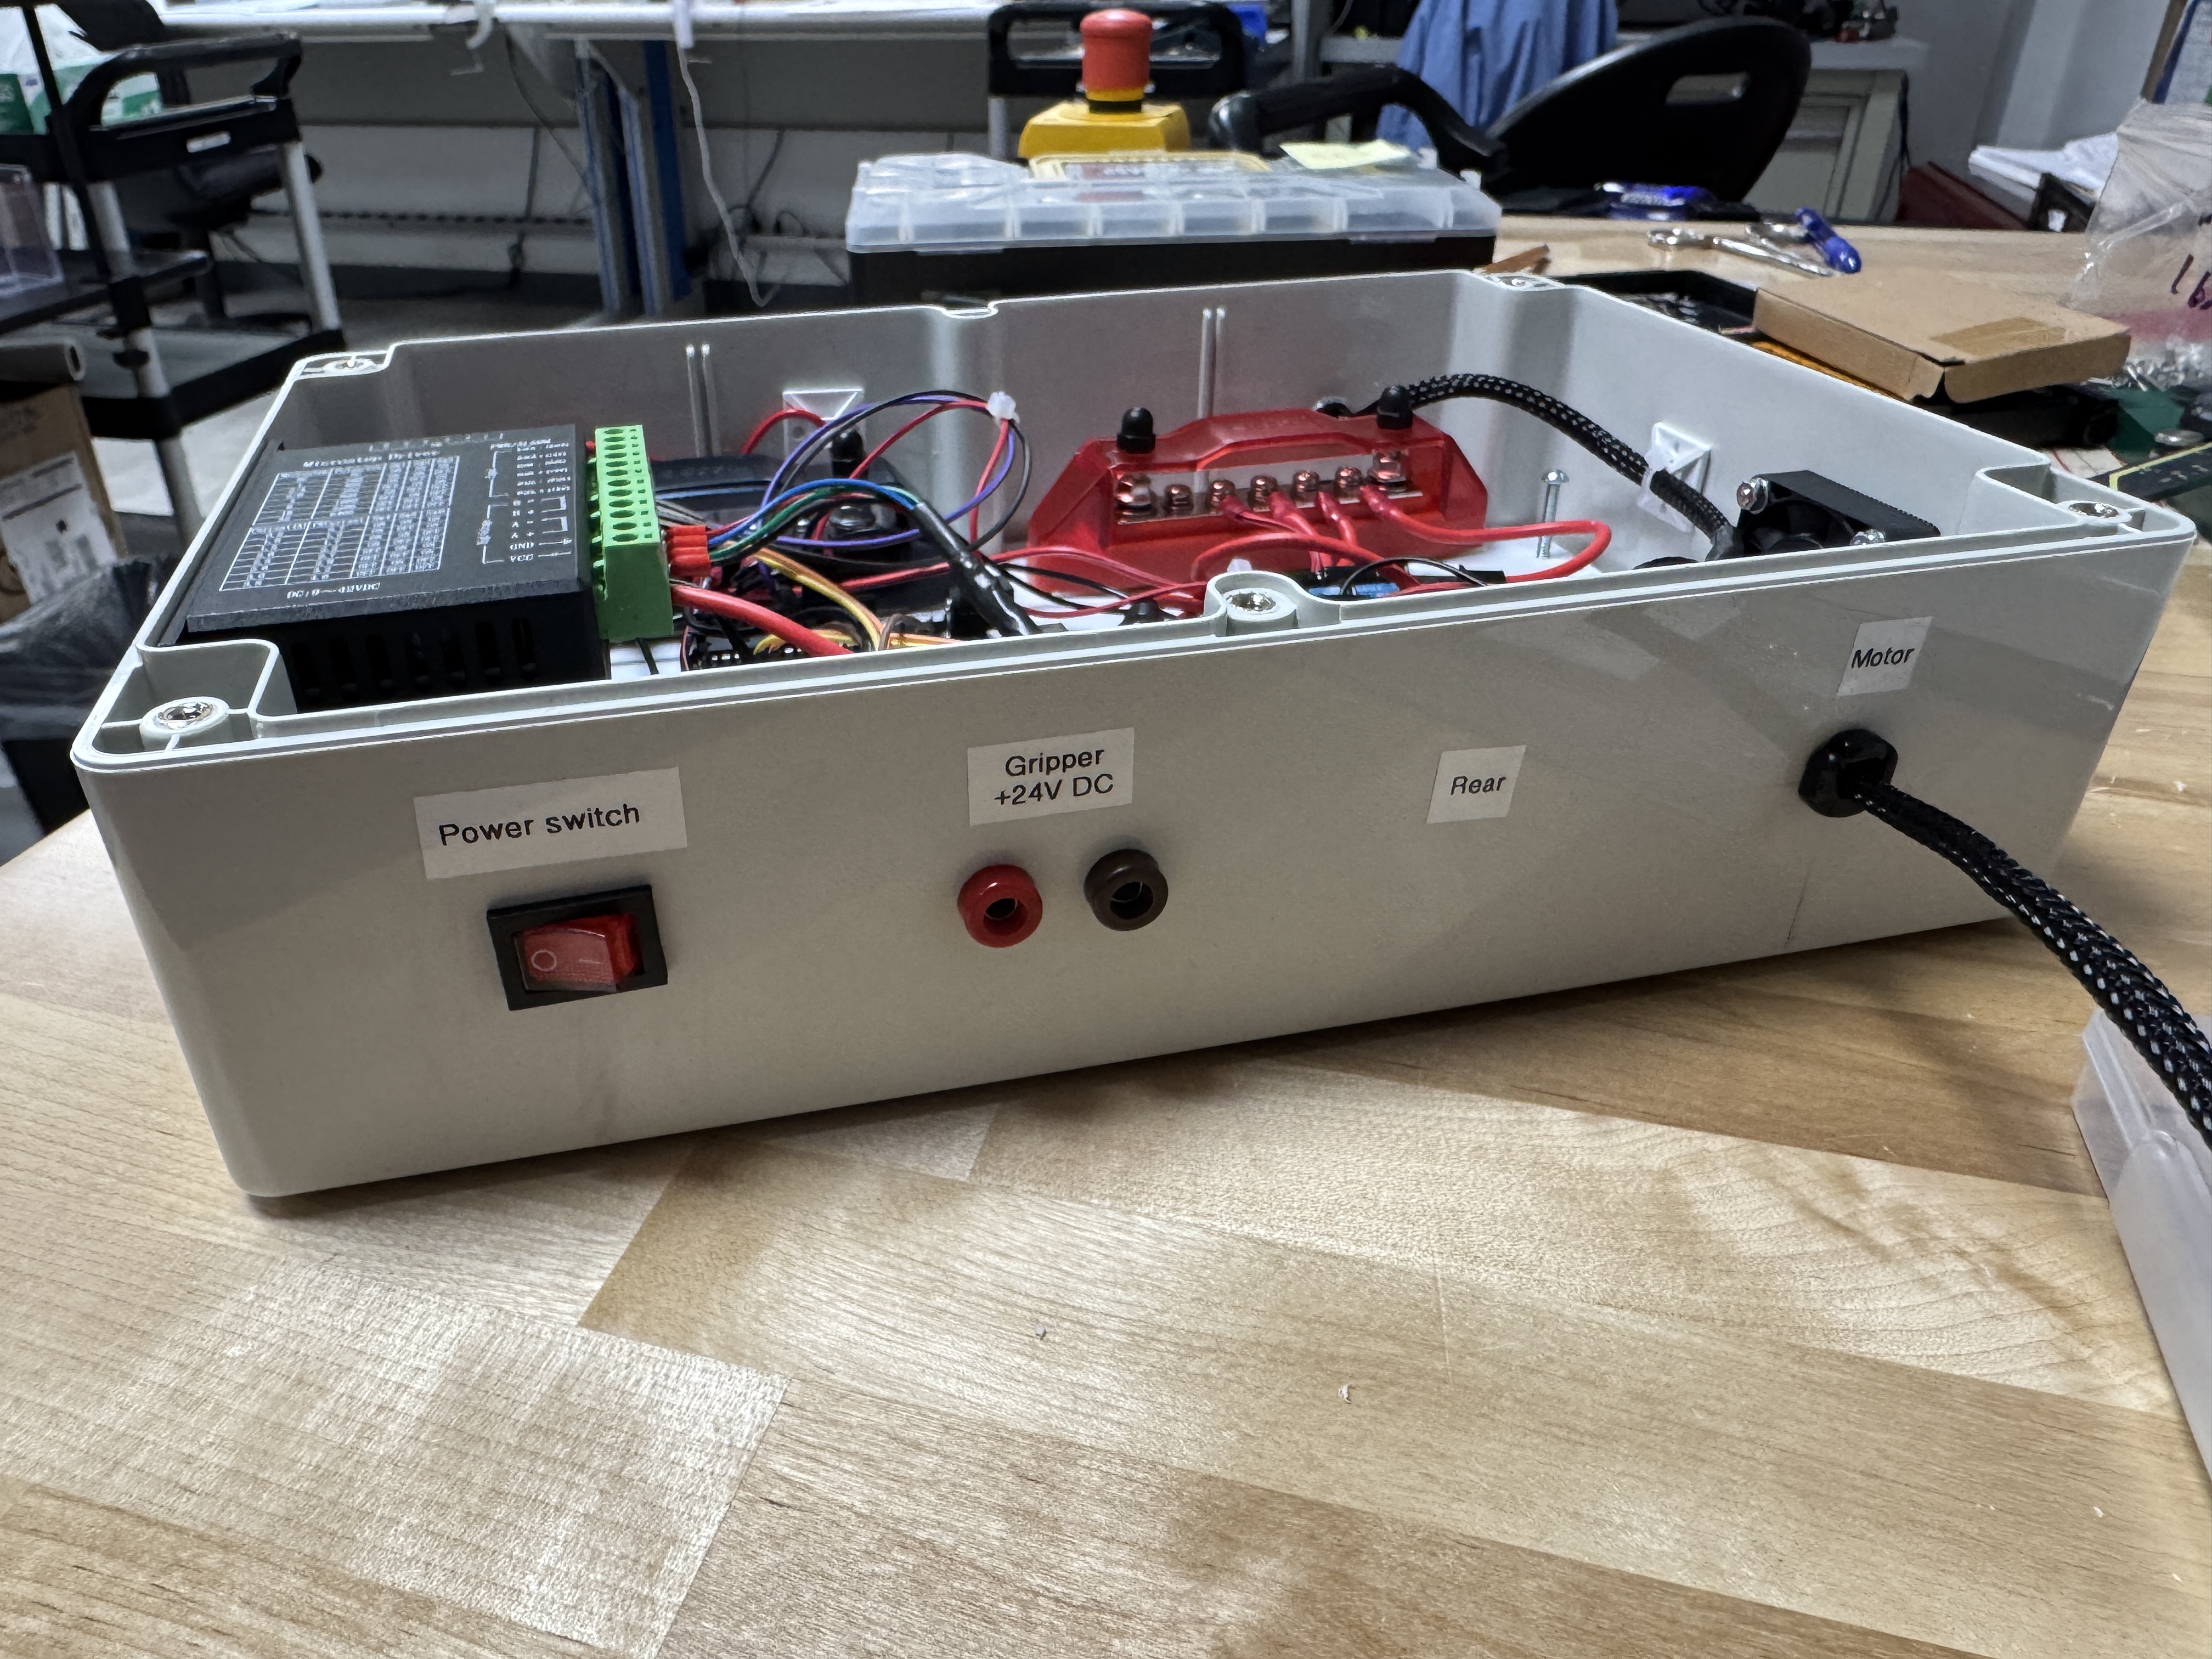
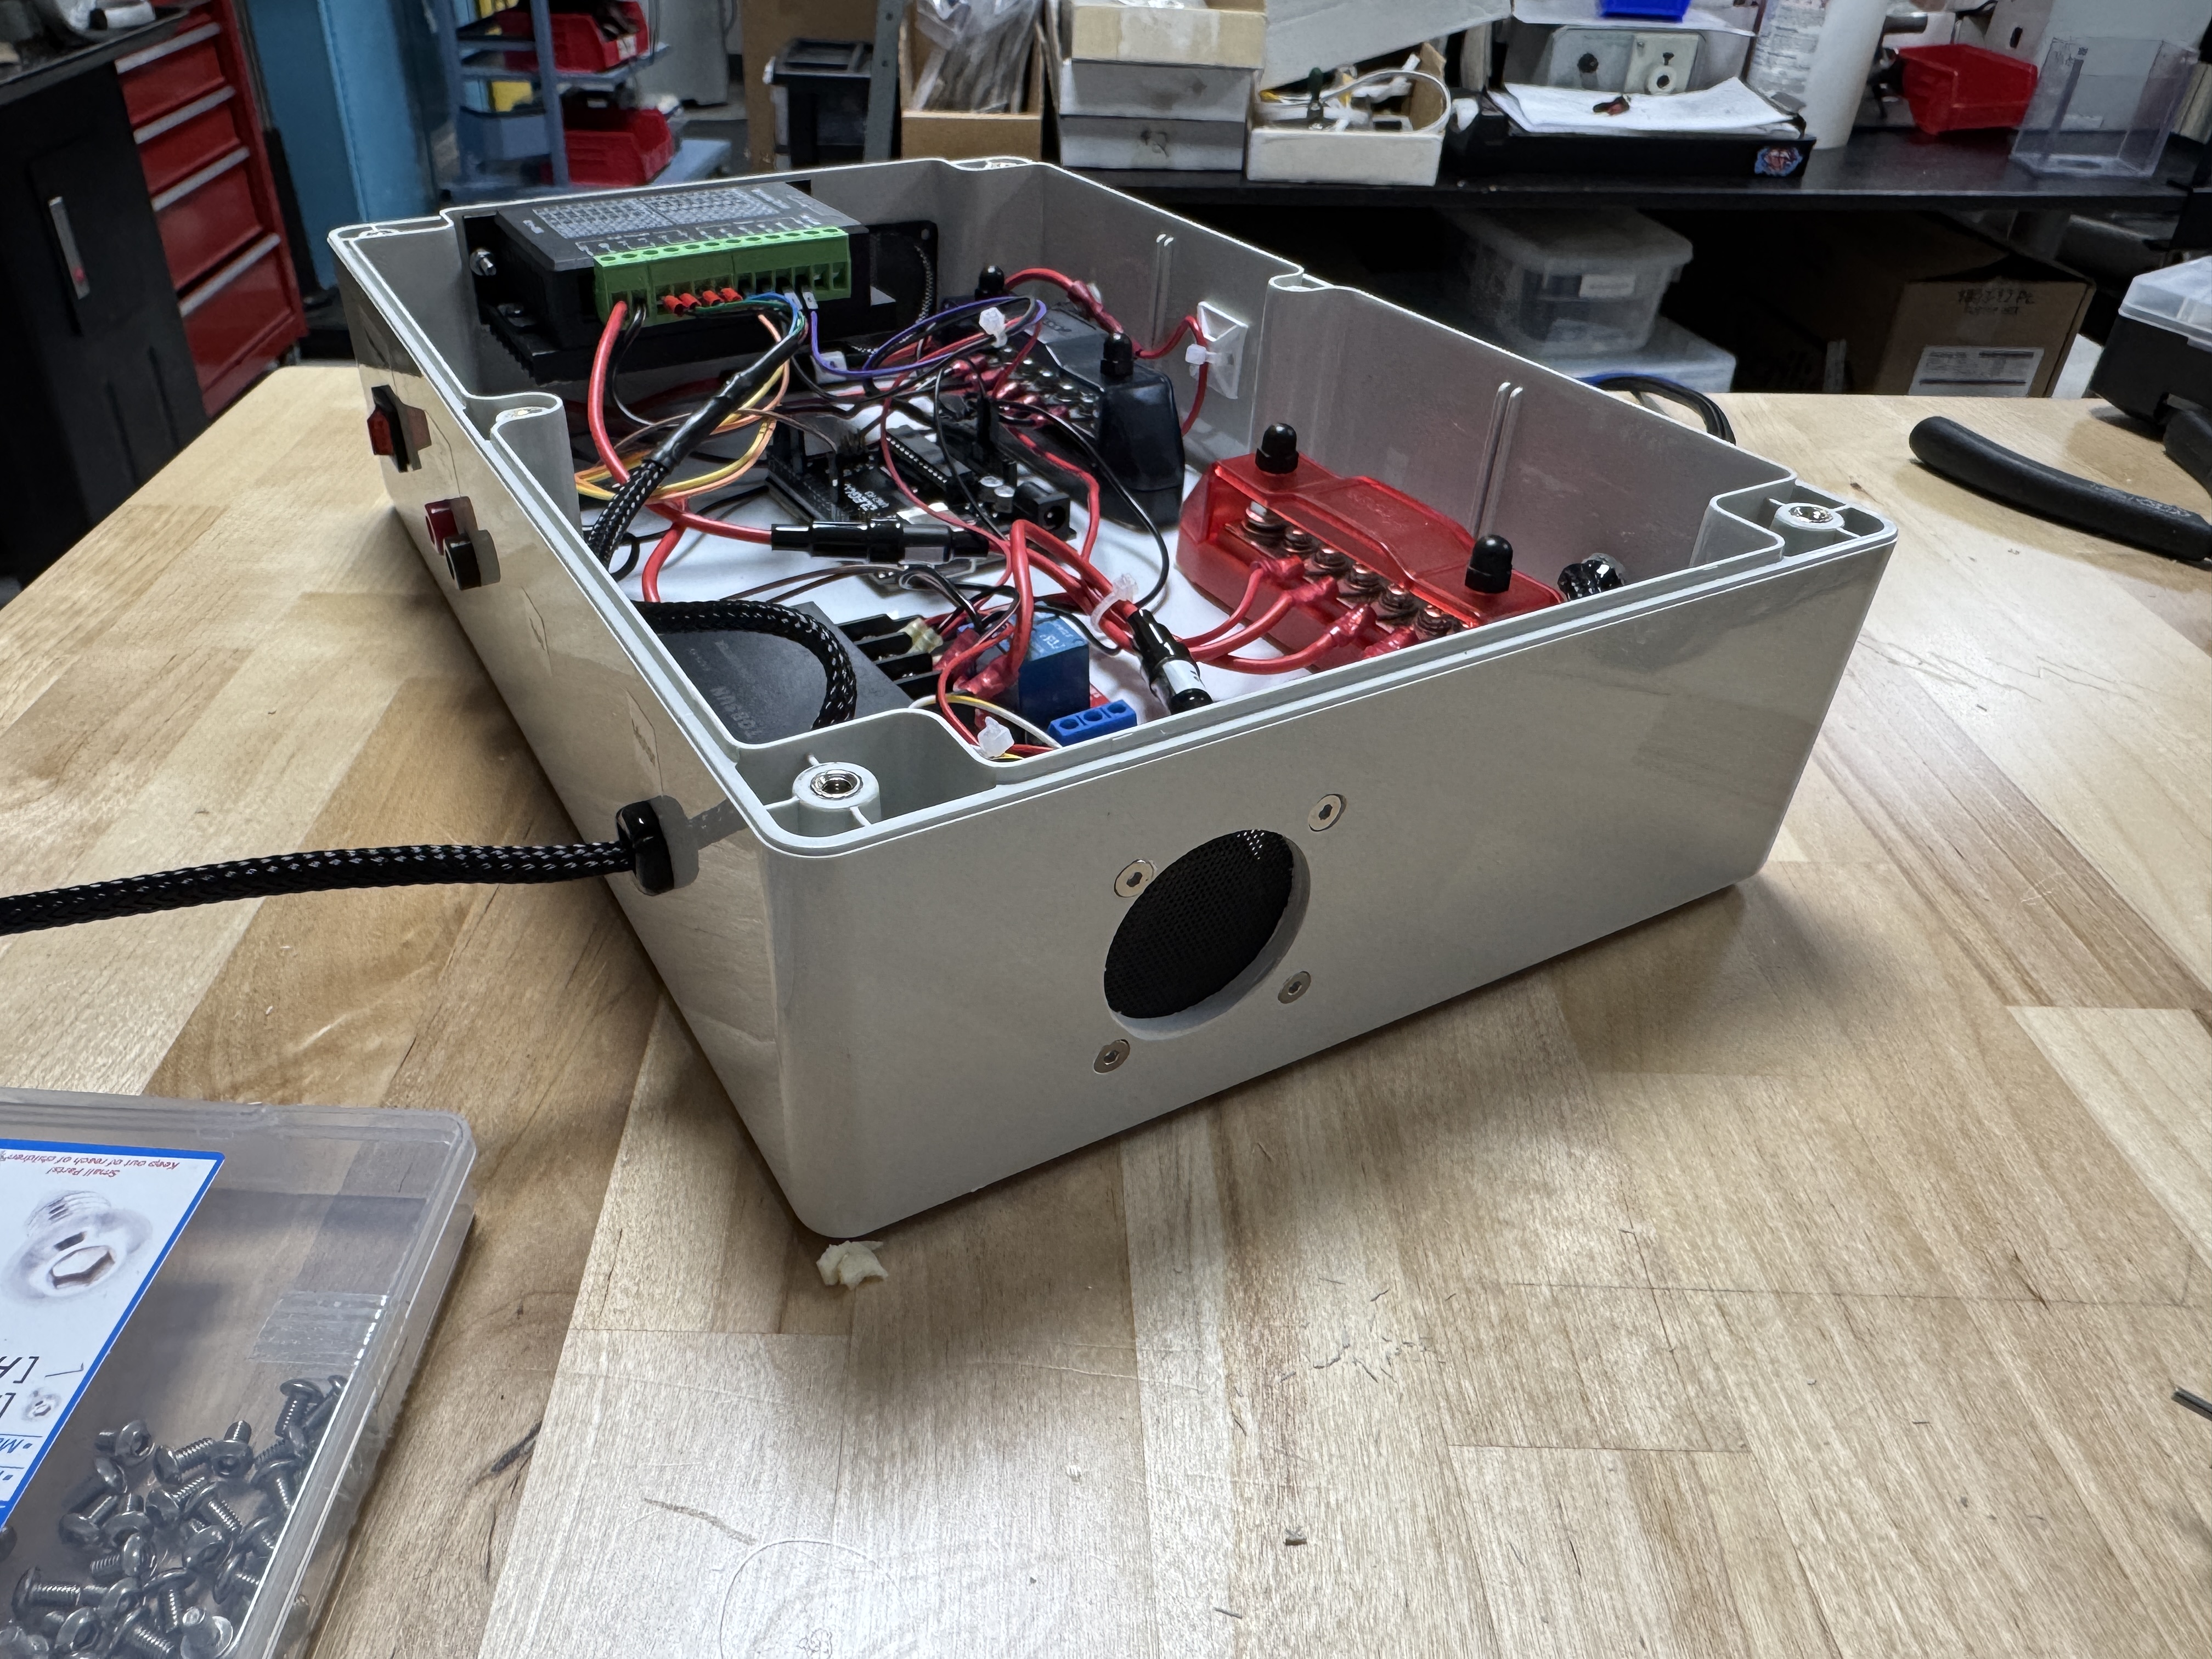
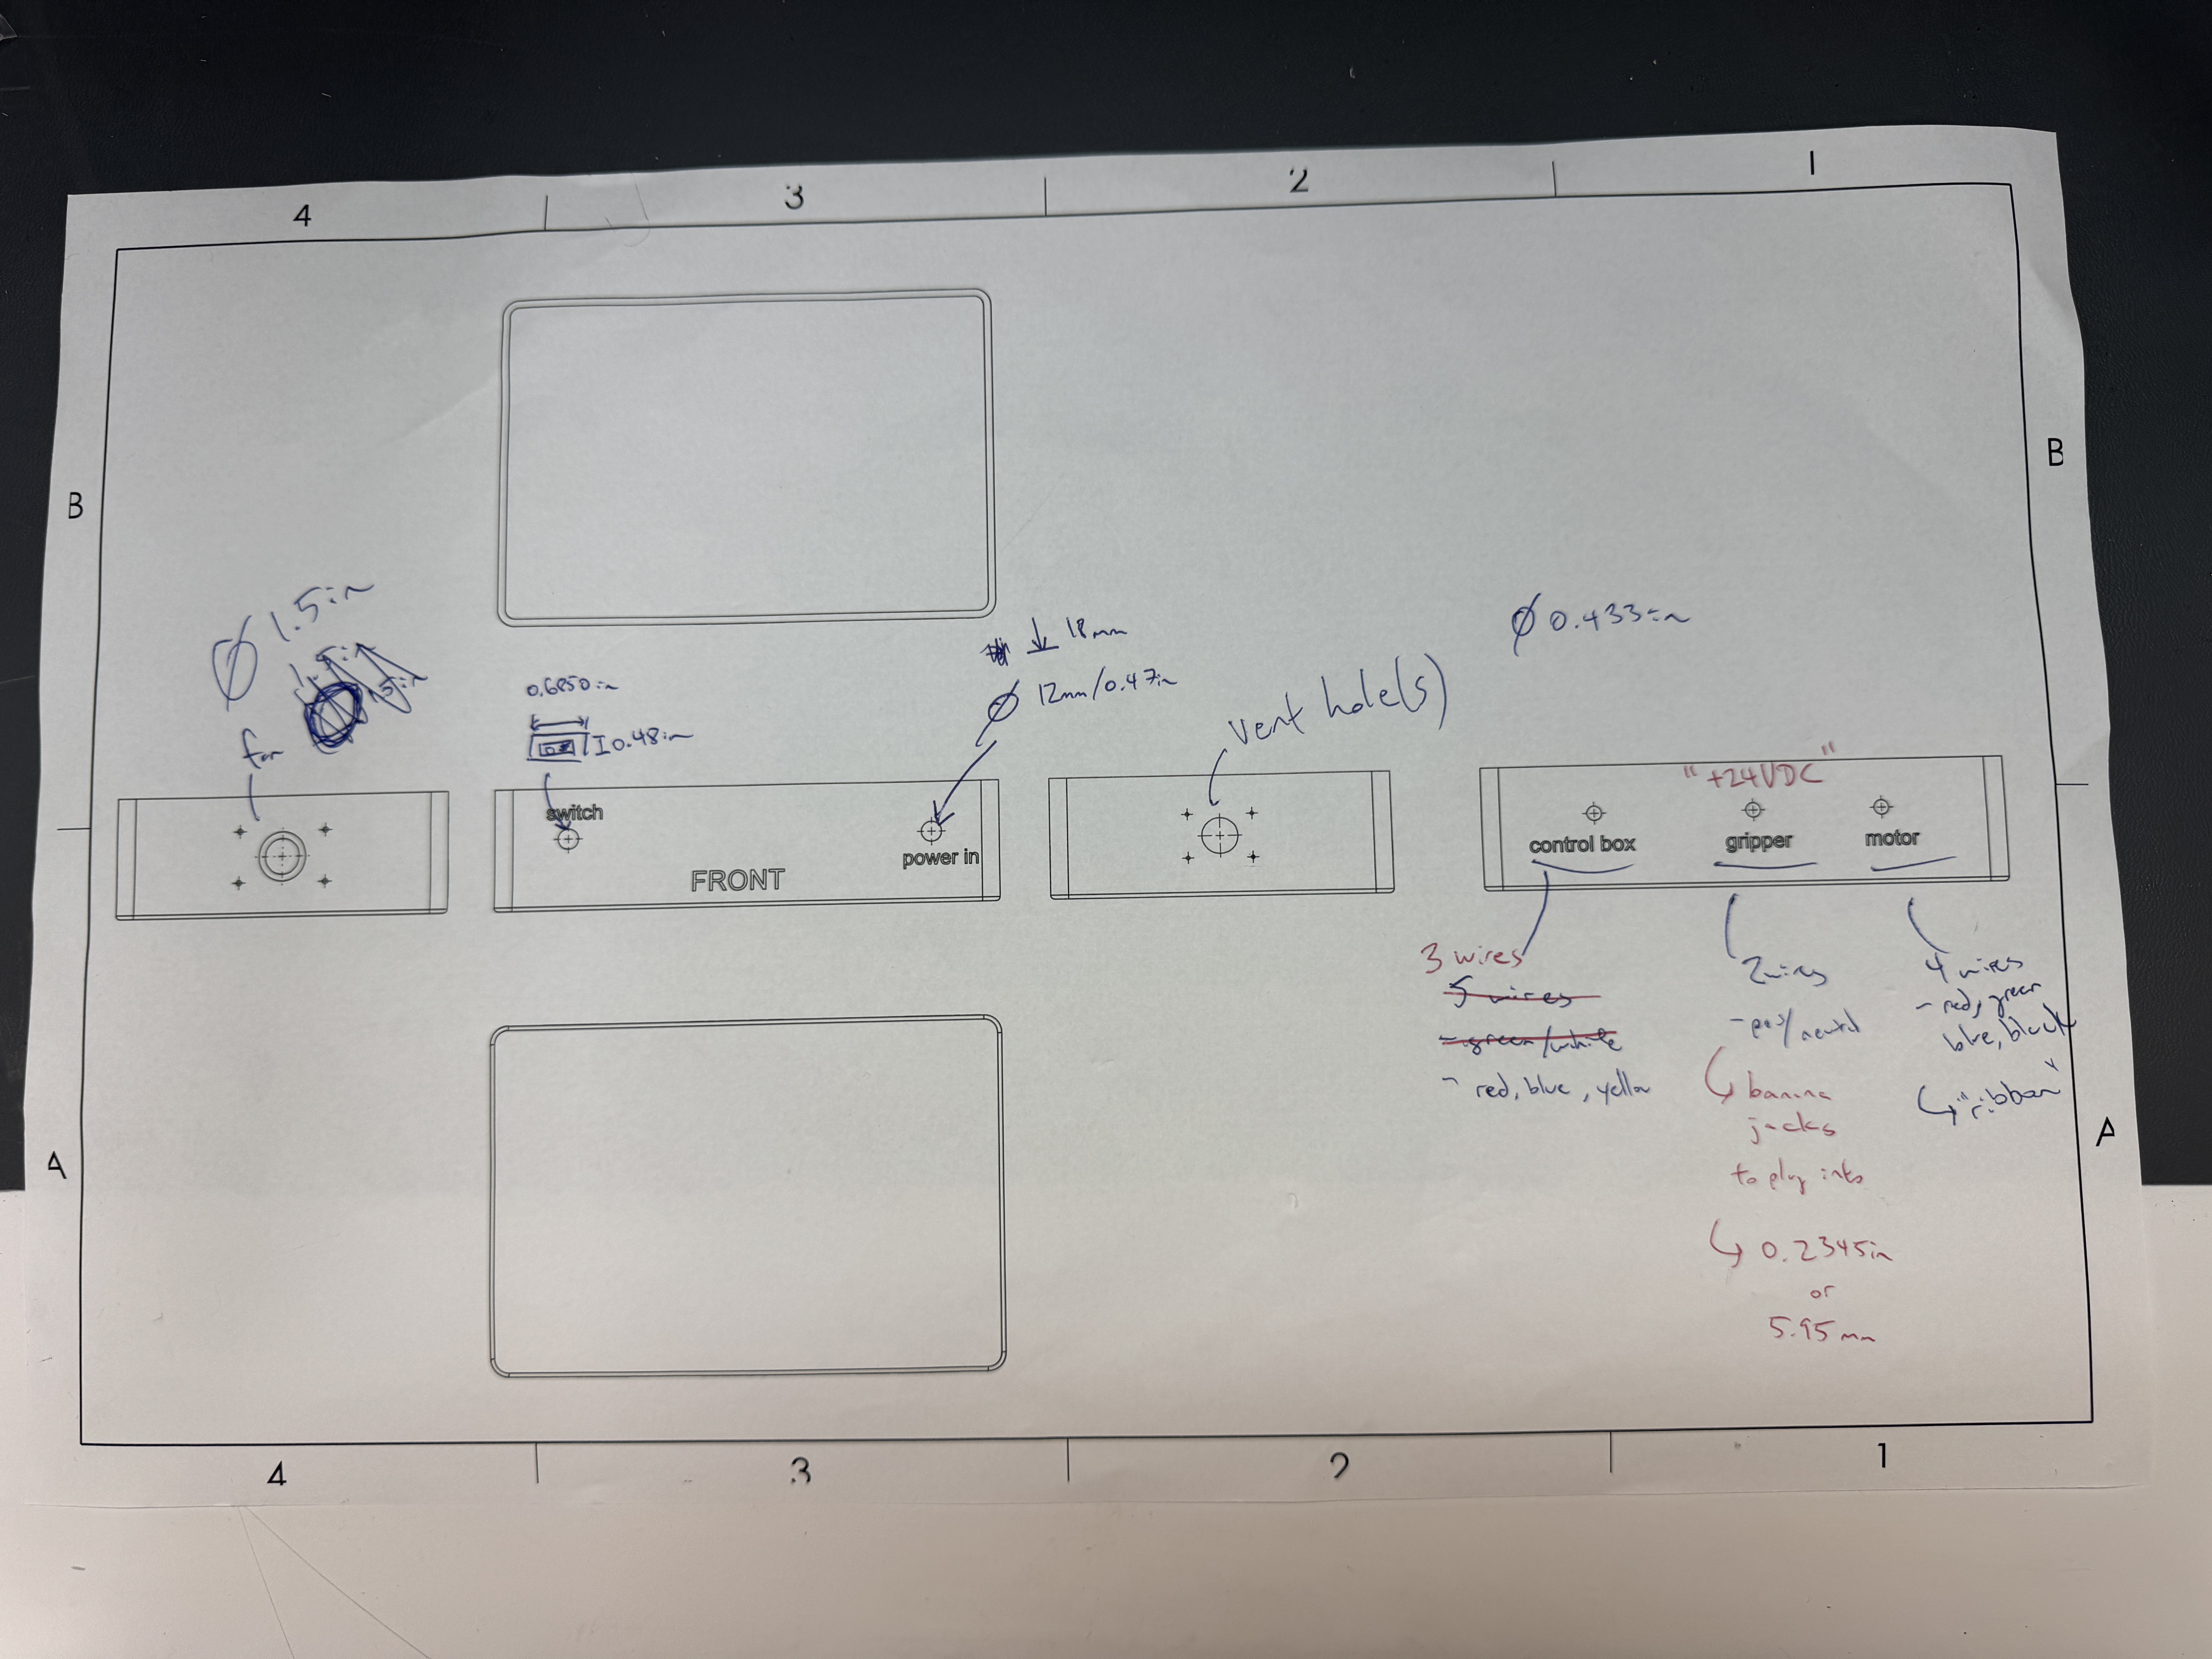
Designed and integrated a robotic system to automate the handling and winding of leadwires using a JAKA MiniCobo collaborative robot and a custom motorized winding fixture. The system combined custom gripper tooling, stepper motor control, Arduino logic, robot digital I/O, and a dedicated electronics enclosure. I developed the mechanical, electrical, and controls integration required for the robot to load a wire, initiate the winding process, retrieve it, and complete the automated cycle, preparing the leadwires for final bagging.
Company
Lifesync (Amphenol Corp.)
Location
Coral Springs, FL
Date
Summer 2026
01
Robotic Cable-Winding System
01
winderdemo1
02
03
carousel
04
05
IMG_5514 - Copy
06
IMG_5544 - Copy

07
kicad
08
IMG_5834 - Copy

09

10
IMG_5164 - Copy

11
IMG_5166 - Copy

12
IMG_5168 - Copy

13
IMG_5608 - Copy

14
IMG_5170

15
IMG_5171
16
IMG_5178

17
IMG_5577 - Copy

18
IMG_5580 - Copy

19
IMG_5621 - Copy

20
IMG_5623 - Copy

21
IMG_5630 - Copy

22
IMG_5636 - Copy

23
IMG_5698 - Copy

24
IMG_5703 - Copy

25
IMG_5705 - Copy

26
IMG_5712 - Copy

27
IMG_5713 - Copy

28
IMG_5716 - Copy

29
IMG_5721 - Copy

30
IMG_5731 - Copy

31
IMG_5732 - Copy

32
IMG_5735 - Copy

33
IMG_5737 - Copy

34
IMG_5740 - Copy

35
IMG_5754 - Copy

36
IMG_5784 - Copy

37
IMG_5787 - Copy

38
IMG_5791 - Copy

39
IMG_5792 - Copy

40
IMG_5794 - Copy

41
IMG_5797 - Copy

42
IMG_5798 - Copy

43
IMG_5801 - Copy

44
IMG_5805 - Copy

45
IMG_5821 - Copy

46
IMG_5826 - Copy

47
IMG_5827 - Copy

48
IMG_5828 - Copy

49
IMG_5829 - Copy

50
IMG_5830 - Copy
- kicad
- Robotic Cable-Winding System
- IMG_5164 - Copy
- IMG_5166 - Copy
- IMG_5168 - Copy
- IMG_5608 - Copy
- IMG_5170
- IMG_5171
- IMG_5178
- IMG_5577 - Copy
- IMG_5580 - Copy
- IMG_5621 - Copy
- IMG_5623 - Copy
- IMG_5630 - Copy
- IMG_5636 - Copy
- IMG_5698 - Copy
- IMG_5703 - Copy
- IMG_5705 - Copy
- IMG_5712 - Copy
- IMG_5713 - Copy
- IMG_5716 - Copy
- IMG_5721 - Copy
- IMG_5731 - Copy
- IMG_5732 - Copy
- IMG_5735 - Copy
- IMG_5737 - Copy
- IMG_5740 - Copy
- IMG_5754 - Copy
- IMG_5784 - Copy
- IMG_5787 - Copy
- IMG_5791 - Copy
- IMG_5792 - Copy
- IMG_5794 - Copy
- IMG_5797 - Copy
- IMG_5798 - Copy
- IMG_5801 - Copy
- IMG_5805 - Copy
- IMG_5821 - Copy
- IMG_5826 - Copy
- IMG_5827 - Copy
- IMG_5828 - Copy
- IMG_5829 - Copy
- IMG_5830 - Copy
bottom of page