Robotic Cable-Winding System
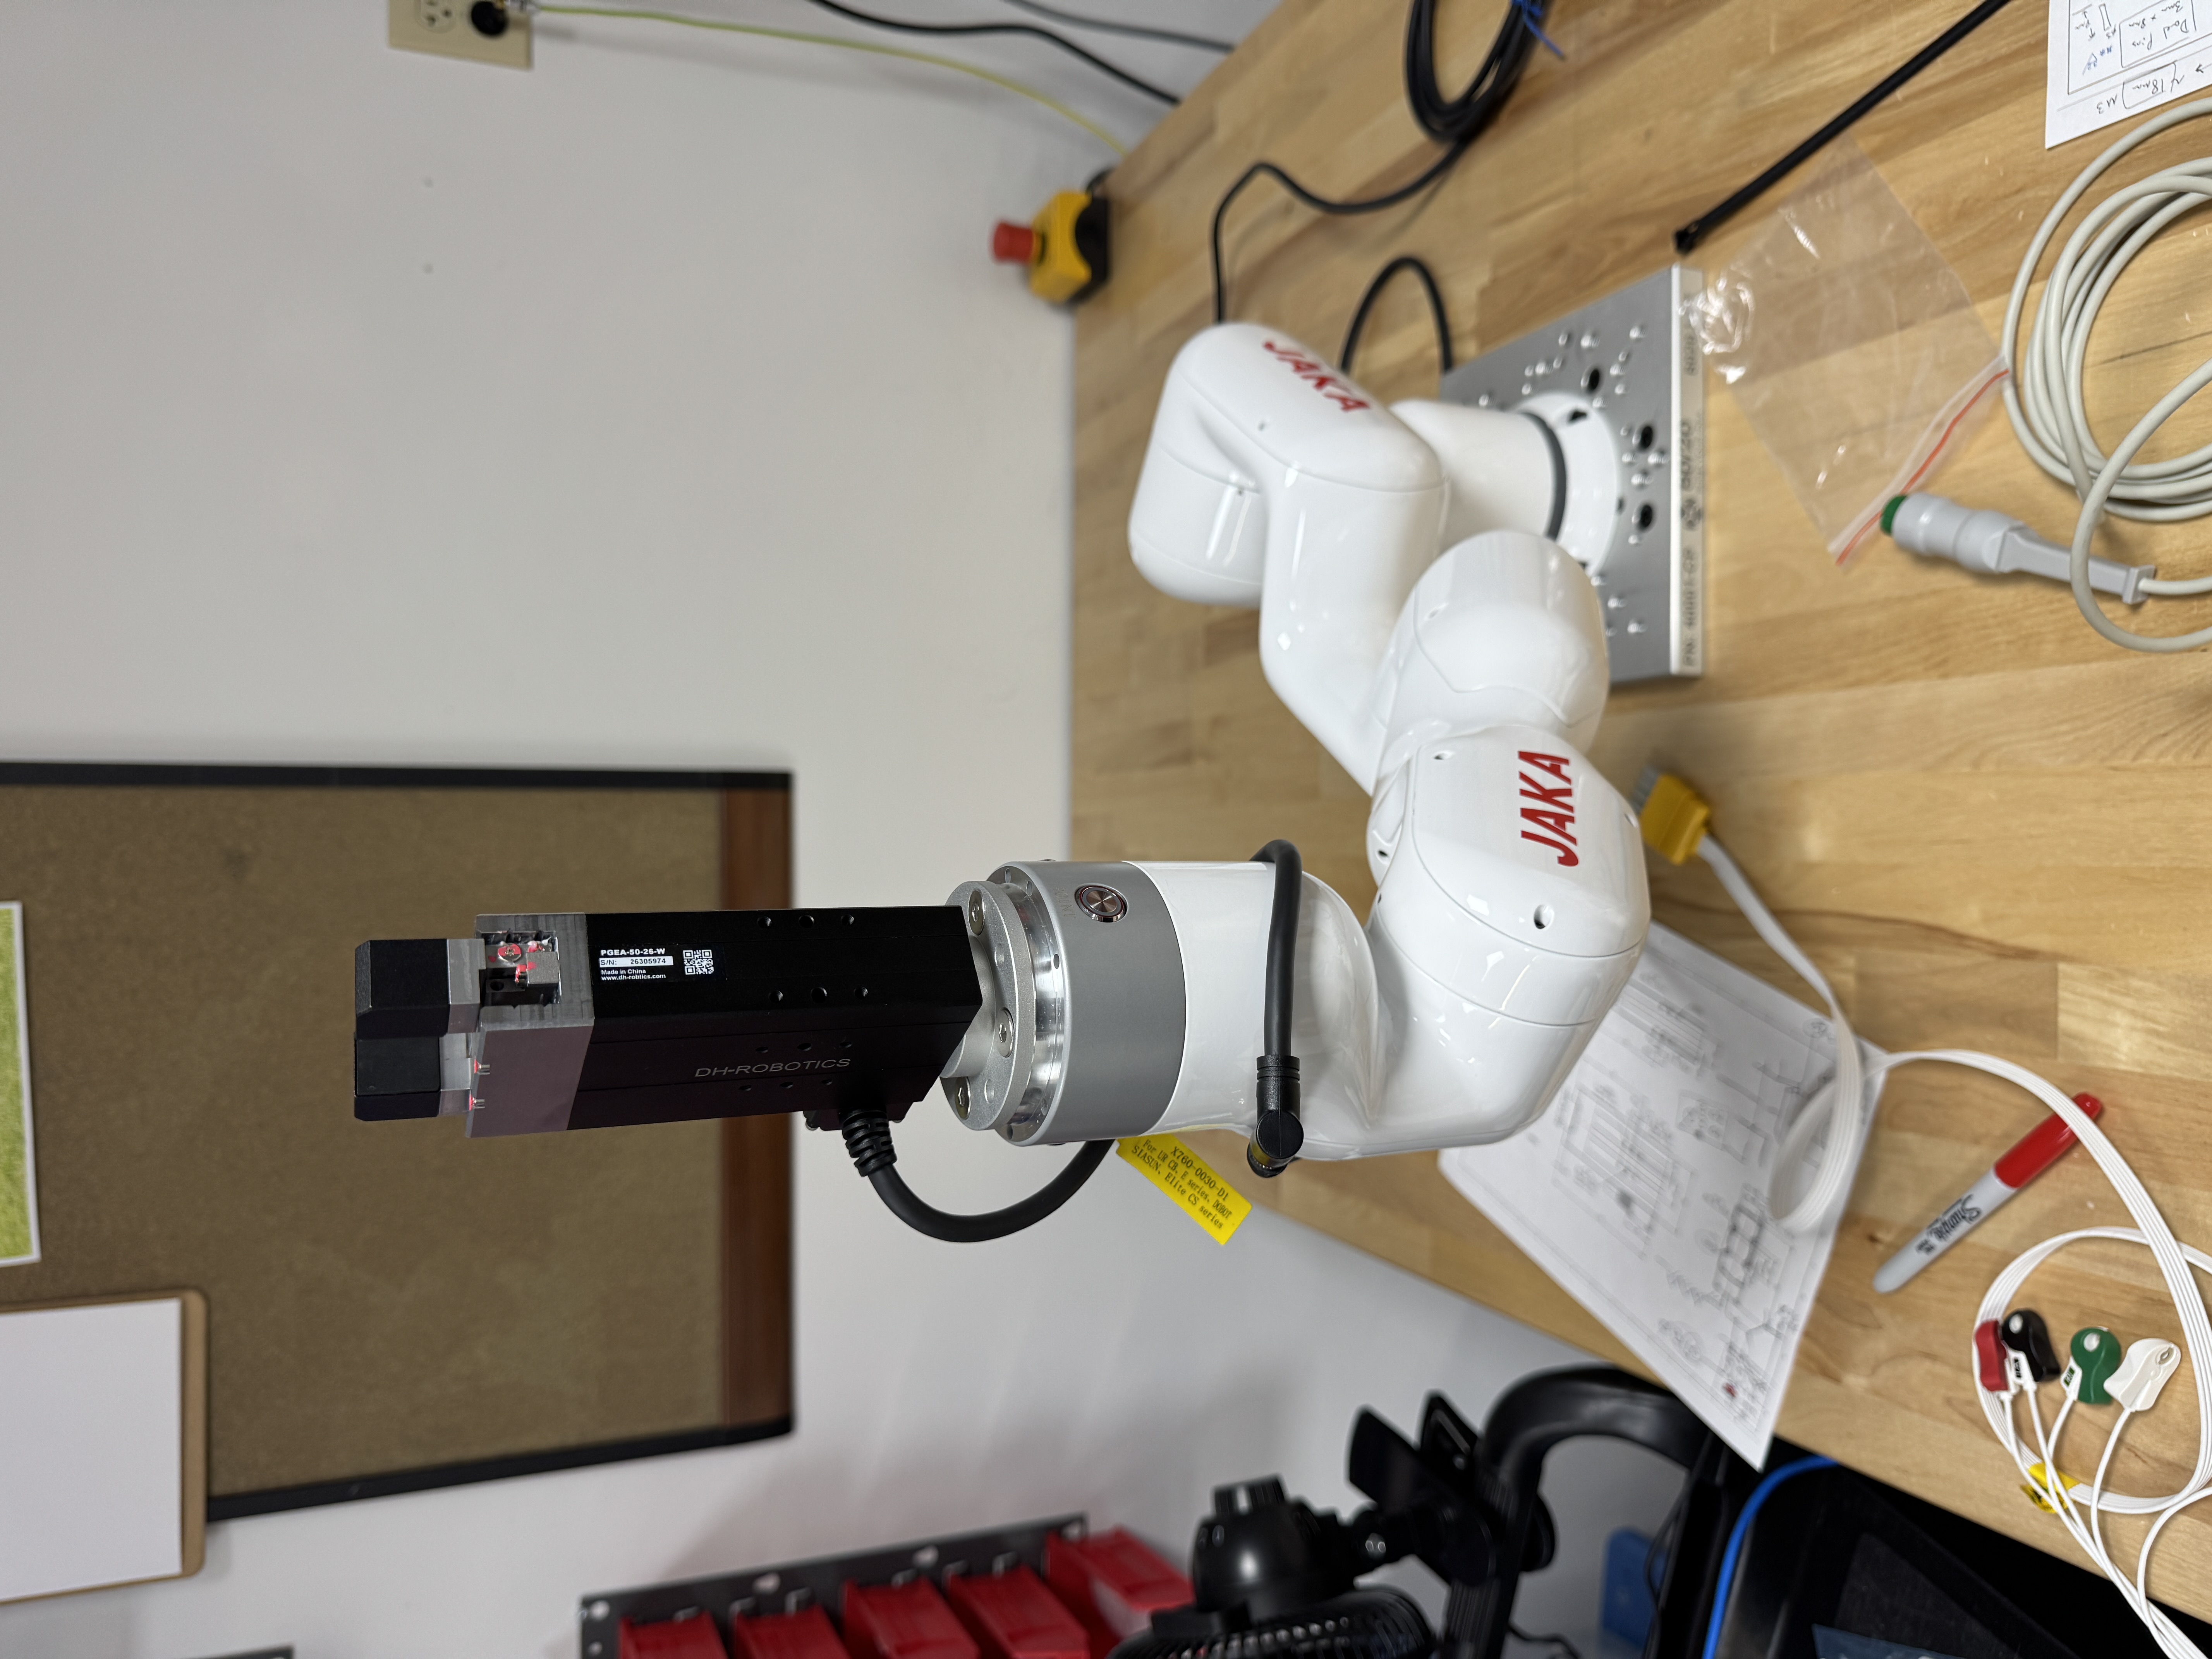
Designed and integrated a robotic system to automate the handling and winding of leadwires using a JAKA MiniCobo collaborative robot and a custom motorized winding fixture. The system combined custom gripper tooling, stepper motor control, Arduino logic, robot digital I/O, and a dedicated electronics enclosure. I developed the mechanical, electrical, and controls integration required for the robot to load a wire, initiate the winding process, retrieve it, and complete the automated cycle, preparing the leadwires for final bagging.